
RcTorch
A Pytorch toolset for creating and optimizing Reservoir Computers (RCs). See the complete RcTorch readthedocs documentation at readthedocs. Also see the preprint of our research paper on the Arkiv which demonstrates the power of our software by solving the forced pendulum.
License: 2020-2022 MIT
Authors: Hayden Joy, Marios Mattheakis (hnjoy@mac.com, mariosmat@seas.harvard.edu)
Contains:
- An RC architecture class "rc.py"
- Bayesian Optimization (BO) class "rc_bayes.py" with optimized routines for RC neural networks through
Botorch(GPU optimized), can train multiple RCs in parallel during BO- an implimentation of the TURBO algorithm as outlined in this paper: https://github.com/uber-research/TuRBO
- Capable of solving differential equations (the population equation, the bernoulli equation, a simple harmonic oscillator and a nonlinear oscillator)
Reference to prior instantiation:
This library is an extension and expansion of a previous library written by Reinier Maat: https://github.com/1Reinier/Reservoir
2018 International Joint Conference on Neural Networks (IJCNN), pp. 1-7. IEEE, 2018
https://arxiv.org/abs/1903.05071
For example usage please see the notebooks folder.
Installation
Using pip
Like most standard libraries, rctorch is hosted on PyPI. To install the latest stable release,
pip install -U rctorch # '-U' means update to latest version
Example Usages
Imports
from rctorch import *
import torch
Load data
RcTorch has several built in datasets. Among these is the forced pendulum dataset. Here we demonstrate
fp_data = rctorch.data.load("forced_pendulum", train_proportion = 0.2)

force_train, force_test = fp_data["force"]
target_train, target_test = fp_data["target"]

#Alternatively you can use sklearn's train_test_split.
Hyper-parameters
#declare the hyper-parameters
>>> hps = {'connectivity': 0.4,
           'spectral_radius': 1.13,
           'n_nodes': 202,
           'regularization': 1.69,
           'leaking_rate': 0.0098085,
           'bias': 0.49}
Setting up your very own EchoStateNetwork (pure prediction)
my_rc = RcNetwork(**hps, random_state = 210, feedback = True)

#fitting the data:
my_rc.fit(y = target_train)

#making our prediction
score, prediction = my_rc.test(y = target_test)
my_rc.combined_plot()
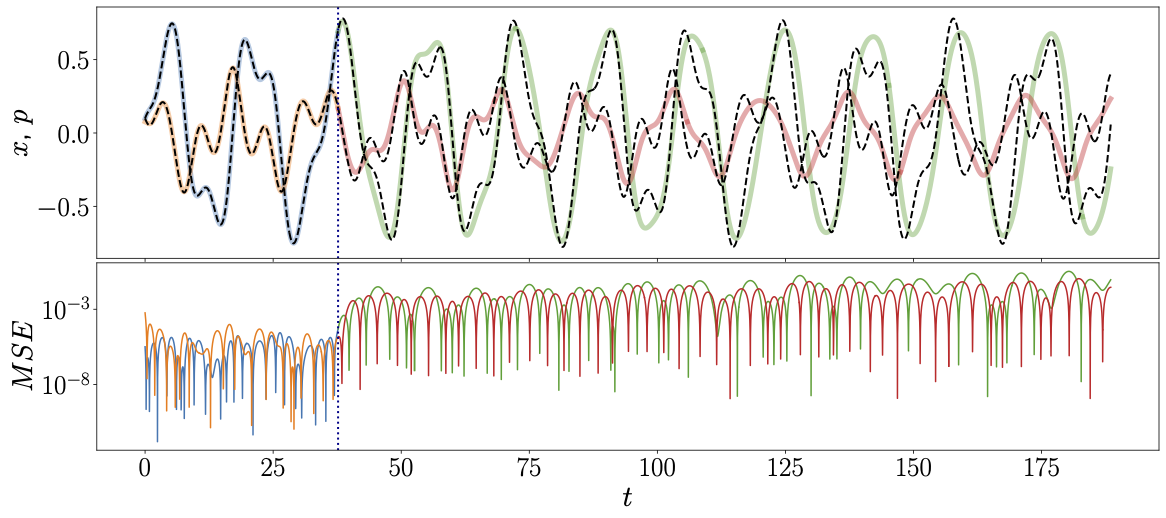
Top plot: Above the ground truth data of the forced pendulum is plotted as dashed lines. The position training set is plotted in yellow and the position prediction is plotted in red. The momentum training set prediction is plotted in blue and the test set prediction is plotted in red.
Bottom plot: The mean squared error plot. The colors correspond to the plot above. For more information see our Arkiv paper.
Note: Feedback allows the network to feed in the prediction at the previous timestep as an input. This helps the RC to make longer and more stable predictions in many situations.
Setting up your very own EchoStateNetwork (parameter-aware version)
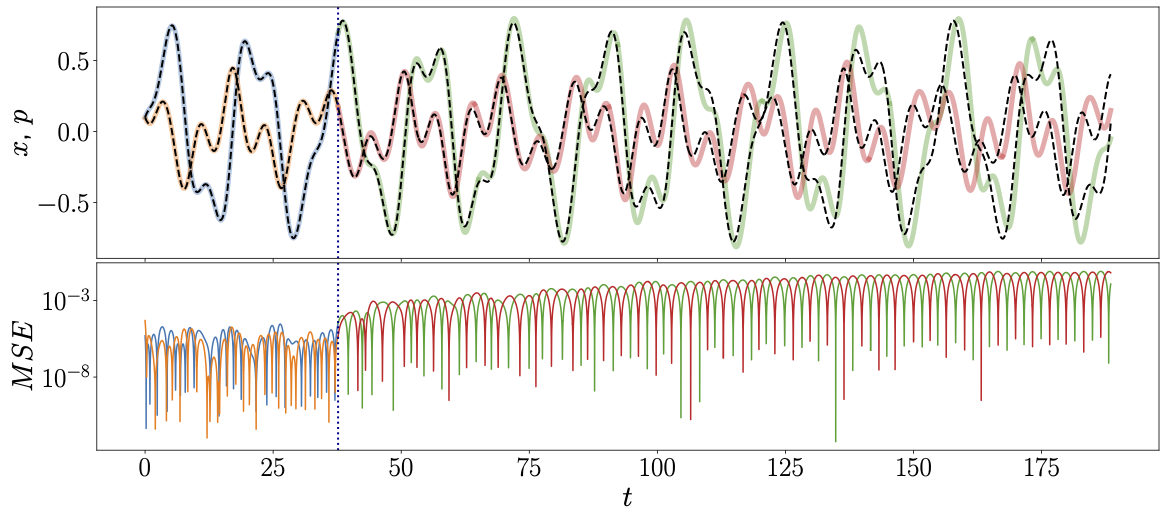
In order to add observers (see this paper, simply add X as an argument for the RC. In effect this allows the RC to take the force applied as input (this would be known in a situation where a robotic arm were programmed to push on a pendulum for example) and then learn the mapping from the force to the target (in this case the position and momentum of a pendulum).
my_rc = RcNetwork(**hps, random_state = 210, feedback = True)

#fitting the data:
my_rc.fit(X = force_train, y = target_train)

#making our prediction
score, prediction = my_rc.test(X = force_test, y = target_test)
my_rc.combined_plot()
Bayesian Optimization
Unlike most other reservoir neural network packages RcTorch is capable of automatically tune hyper-parameters, saving researchers time and energy. In addition RcTorch predictions are world class!
#any hyper parameter can have 'log_' in front of it's name. RcTorch will interpret this properly.
bounds_dict = {"log_connectivity" : (-2.5, -0.1),
               "spectral_radius" : (0.1, 3),
               "n_nodes" : (300,302),
               "log_regularization" : (-3, 1),
               "leaking_rate" : (0, 0.2),
               "bias": (-1,1),
               }
rc_specs = {"feedback" : True,
             "reservoir_weight_dist" : "uniform",
             "output_activation" : "tanh",
             "random_seed" : 209}

rc_bo = RcBayesOpt(bounds = bounds_dict,
                    scoring_method = "nmse",
                    n_jobs = 1,
                    cv_samples = 3,
                    initial_samples= 25,
                    **rc_specs
                    )
1 maintainer

Metadata
1 maintainer
Release files for rctorch 0.91
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| rctorch-0.91.tar.gz | 342.9 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| rctorch-0.91-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 420.5 kB
Release files / rctorch-0.91.tar.gz
| Download URL | rctorch-0.91.tar.gz |
|---|---|
| Size | 342.9 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
cb21ff31638087482b7a129ce0c3c766e757f82209ef678935378e450abb2f14
|
|
BLAKE2b-256 checksum How to use checksums |
acdee8fd0197207e50ed76525fb9f2577f1d1a0c53b6a43d6609d44d9160fe53
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/3.8.0 pkginfo/1.8.3 readme-renderer/35.0 requests/2.27.1 requests-toolbelt/0.9.1 urllib3/1.26.9 tqdm/4.64.0 importlib-metadata/4.12.0 keyring/23.6.0 rfc3986/2.0.0 colorama/0.4.5 CPython/3.9.13
|
Release files / rctorch-0.91-py3-none-any.whl
| Download URL | rctorch-0.91-py3-none-any.whl |
|---|---|
| Size | 77.6 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
c411c11601371239057e4f409b2f2d863d6e72194f2d47f0a874cf3d142dec18
|
|
BLAKE2b-256 checksum How to use checksums |
68da26db85d191da8db63d4f399232195f3f173ed2e3ba77f889d033d2fc13c8
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/3.8.0 pkginfo/1.8.3 readme-renderer/35.0 requests/2.27.1 requests-toolbelt/0.9.1 urllib3/1.26.9 tqdm/4.64.0 importlib-metadata/4.12.0 keyring/23.6.0 rfc3986/2.0.0 colorama/0.4.5 CPython/3.9.13
|














