
RL Toolkit



Papers
- Playing Flappy Bird Based on Motion Recognition Using a Transformer Model and LIDAR Sensor
- Soft Actor-Critic
- Generalized State-Dependent Exploration
- Reverb: A framework for experience replay
- Controlling Overestimation Bias with Truncated Mixture of Continuous Distributional Quantile Critics
- Acme: A Research Framework for Distributed Reinforcement Learning
- Dueling Network Architectures for Deep Reinforcement Learning
- Attention Is All You Need
- An Image is Worth 16x16 Words: Transformers for Image Recognition at Scale
Installation with PyPI
On PC AMD64 with Ubuntu/Debian
- Install dependences
apt update -y
apt install swig -y
- Install RL-Toolkit
pip3 install rl-toolkit[all]
- Run (for Server)
rl_toolkit rl_toolkit -c ./config/sac.yaml -a sac -e BipedalWalkerHardcore-v3 server
Run (for Agent)rl_toolkit -c ./config/sac.yaml -a sac -e BipedalWalkerHardcore-v3 agent
Run (for Learner)rl_toolkit -c ./config/sac.yaml -a sac -e BipedalWalkerHardcore-v3 learner --db_server 192.168.1.2
Run (for Tester)rl_toolkit -c ./config/sac.yaml -a sac -e BipedalWalkerHardcore-v3 tester -f save/model/actor.h5
On NVIDIA Jetson
-
Install dependences
Tensorflow for JetPack, follow instructions here for installation.sudo apt install swig -y
-
Install Reverb
Download Bazel 3.7.2 for arm64, heremkdir ~/bin mv ~/Downloads/bazel-3.7.2-linux-arm64 ~/bin/bazel chmod +x ~/bin/bazel export PATH=$PATH:~/bin
Clone Reverb with version that corespond with TF verion installed on NVIDIA Jetson !
git clone https://github.com/deepmind/reverb
cd reverb/
git checkout r0.9.0
Make changes in Reverb before building !
In .bazelrc- build:manylinux2010 --crosstool_top=//third_party/toolchains/preconfig/ubuntu16.04/gcc7_manylinux2010:toolchain + # build:manylinux2010 --crosstool_top=//third_party/toolchains/preconfig/ubuntu16.04/gcc7_manylinux2010:toolchain - build --copt=-mavx --copt=-DEIGEN_MAX_ALIGN_BYTES=64 + build --copt=-DEIGEN_MAX_ALIGN_BYTES=64
In WORKSPACE
- PROTOC_SHA256 = "15e395b648a1a6dda8fd66868824a396e9d3e89bc2c8648e3b9ab9801bea5d55"
+ # PROTOC_SHA256 = "15e395b648a1a6dda8fd66868824a396e9d3e89bc2c8648e3b9ab9801bea5d55"
+ PROTOC_SHA256 = "7877fee5793c3aafd704e290230de9348d24e8612036f1d784c8863bc790082e"
In oss_build.sh
-  bazel test -c opt --copt=-mavx --config=manylinux2010 --test_output=errors //reverb/cc/...
+  bazel test -c opt --copt="-march=armv8-a+crypto" --test_output=errors //reverb/cc/...

# Builds Reverb and creates the wheel package.
-  bazel build -c opt --copt=-mavx $EXTRA_OPT --config=manylinux2010 reverb/pip_package:build_pip_package
+  bazel build -c opt --copt="-march=armv8-a+crypto" $EXTRA_OPT reverb/pip_package:build_pip_package
In reverb/cc/platform/default/repo.bzl
urls = [
   -        "https://github.com/protocolbuffers/protobuf/releases/download/v%s/protoc-%s-linux-x86_64.zip" % (version, version),
   +        "https://github.com/protocolbuffers/protobuf/releases/download/v%s/protoc-%s-linux-aarch_64.zip" % (version, version),
]
In reverb/pip_package/build_pip_package.sh
-  "${PYTHON_BIN_PATH}" setup.py bdist_wheel ${PKG_NAME_FLAG} ${RELEASE_FLAG} ${TF_VERSION_FLAG} --plat manylinux2010_x86_64 > /dev/null
+  "${PYTHON_BIN_PATH}" setup.py bdist_wheel ${PKG_NAME_FLAG} ${RELEASE_FLAG} ${TF_VERSION_FLAG}  > /dev/null
Build and install
bash oss_build.sh --clean true --tf_dep_override "tensorflow~=2.9.1" --release --python "3.8"
bash ./bazel-bin/reverb/pip_package/build_pip_package --dst /tmp/reverb/dist/ --release
pip3 install /tmp/reverb/dist/dm_reverb-*
Cleaning
cd ../
rm -R reverb/
-
Install RL-Toolkit
pip3 install rl-toolkit
Environments
| Environment | Observation space | Observation bounds | Action space | Action bounds | Reward bounds |
|---|---|---|---|---|---|
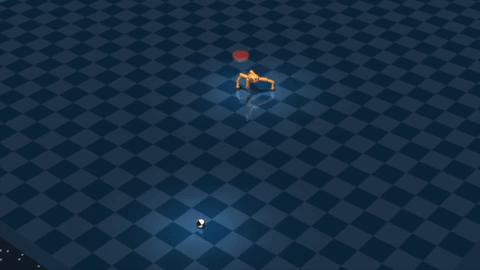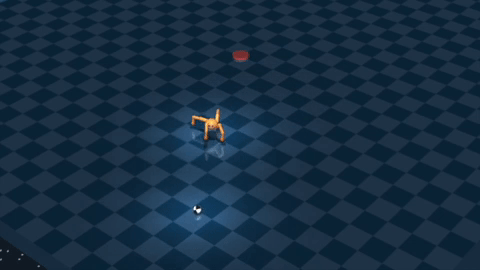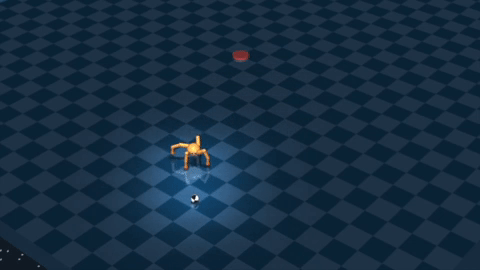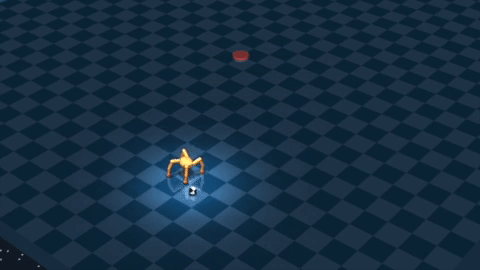
| BipedalWalkerHardcore-v3 | (24, ) | [-inf, inf] | (4, ) | [-1.0, 1.0] | [-1.0, 1.0] |
| FlappyBird-v0 | (16, 180) | [0, dmax] | (2, ) | {DO NOTHING, FLAP} | [-1.0, 1.0] |
Results
| Environment | SAC + gSDE |
SAC + gSDE + Huber loss |
SAC + TQC + gSDE |
Q-Learning | RL-Toolkit |
|---|---|---|---|---|---|
| BipedalWalkerHardcore-v3 | 13 ± 18(1) | 239 ± 118 | 228 ± 18(1) | - | 205 ± 134 |
| FlappyBird-v0 | - | - | - | 209.298(2) | 13 156 |
Releases
- SAC + gSDE + Huber loss
is stored here, branch r2.0 - SAC + TQC + gSDE + LogCosh + Reverb
is stored here, branch r4.0 - DQN + SAC agents branch r4.0
Frameworks: Tensorflow, DeepMind Reverb, Gymnasium, DeepMind Control Suite, WanDB, OpenCV
RL Toolkit
Papers
- Playing Flappy Bird Based on Motion Recognition Using a Transformer Model and LIDAR Sensor
- Soft Actor-Critic
- Generalized State-Dependent Exploration
- Reverb: A framework for experience replay
- Controlling Overestimation Bias with Truncated Mixture of Continuous Distributional Quantile Critics
- Acme: A Research Framework for Distributed Reinforcement Learning
- Dueling Network Architectures for Deep Reinforcement Learning
- Attention Is All You Need
- An Image is Worth 16x16 Words: Transformers for Image Recognition at Scale
Installation with PyPI
On PC AMD64 with Ubuntu/Debian
- Install dependences
apt update -y
apt install swig -y
- Install RL-Toolkit
pip3 install rl-toolkit[all]
- Run (for Server)
rl_toolkit rl_toolkit -c ./config/sac.yaml -a sac -e BipedalWalkerHardcore-v3 server
Run (for Agent)rl_toolkit -c ./config/sac.yaml -a sac -e BipedalWalkerHardcore-v3 agent
Run (for Learner)rl_toolkit -c ./config/sac.yaml -a sac -e BipedalWalkerHardcore-v3 learner --db_server 192.168.1.2
Run (for Tester)rl_toolkit -c ./config/sac.yaml -a sac -e BipedalWalkerHardcore-v3 tester -f save/model/actor.h5
On NVIDIA Jetson
-
Install dependences
Tensorflow for JetPack, follow instructions here for installation.sudo apt install swig -y
-
Install Reverb
Download Bazel 3.7.2 for arm64, heremkdir ~/bin mv ~/Downloads/bazel-3.7.2-linux-arm64 ~/bin/bazel chmod +x ~/bin/bazel export PATH=$PATH:~/bin
Clone Reverb with version that corespond with TF verion installed on NVIDIA Jetson !
git clone https://github.com/deepmind/reverb
cd reverb/
git checkout r0.9.0
Make changes in Reverb before building !
In .bazelrc- build:manylinux2010 --crosstool_top=//third_party/toolchains/preconfig/ubuntu16.04/gcc7_manylinux2010:toolchain + # build:manylinux2010 --crosstool_top=//third_party/toolchains/preconfig/ubuntu16.04/gcc7_manylinux2010:toolchain - build --copt=-mavx --copt=-DEIGEN_MAX_ALIGN_BYTES=64 + build --copt=-DEIGEN_MAX_ALIGN_BYTES=64
In WORKSPACE
- PROTOC_SHA256 = "15e395b648a1a6dda8fd66868824a396e9d3e89bc2c8648e3b9ab9801bea5d55"
+ # PROTOC_SHA256 = "15e395b648a1a6dda8fd66868824a396e9d3e89bc2c8648e3b9ab9801bea5d55"
+ PROTOC_SHA256 = "7877fee5793c3aafd704e290230de9348d24e8612036f1d784c8863bc790082e"
In oss_build.sh
-  bazel test -c opt --copt=-mavx --config=manylinux2010 --test_output=errors //reverb/cc/...
+  bazel test -c opt --copt="-march=armv8-a+crypto" --test_output=errors //reverb/cc/...

# Builds Reverb and creates the wheel package.
-  bazel build -c opt --copt=-mavx $EXTRA_OPT --config=manylinux2010 reverb/pip_package:build_pip_package
+  bazel build -c opt --copt="-march=armv8-a+crypto" $EXTRA_OPT reverb/pip_package:build_pip_package
In reverb/cc/platform/default/repo.bzl
urls = [
   -        "https://github.com/protocolbuffers/protobuf/releases/download/v%s/protoc-%s-linux-x86_64.zip" % (version, version),
   +        "https://github.com/protocolbuffers/protobuf/releases/download/v%s/protoc-%s-linux-aarch_64.zip" % (version, version),
]
In reverb/pip_package/build_pip_package.sh
-  "${PYTHON_BIN_PATH}" setup.py bdist_wheel ${PKG_NAME_FLAG} ${RELEASE_FLAG} ${TF_VERSION_FLAG} --plat manylinux2010_x86_64 > /dev/null
+  "${PYTHON_BIN_PATH}" setup.py bdist_wheel ${PKG_NAME_FLAG} ${RELEASE_FLAG} ${TF_VERSION_FLAG}  > /dev/null
Build and install
bash oss_build.sh --clean true --tf_dep_override "tensorflow~=2.9.1" --release --python "3.8"
bash ./bazel-bin/reverb/pip_package/build_pip_package --dst /tmp/reverb/dist/ --release
pip3 install /tmp/reverb/dist/dm_reverb-*
Cleaning
cd ../
rm -R reverb/
-
Install RL-Toolkit
pip3 install rl-toolkit
Environments
| Environment | Observation space | Observation bounds | Action space | Action bounds | Reward bounds |
|---|---|---|---|---|---|
| BipedalWalkerHardcore-v3 | (24, ) | [-inf, inf] | (4, ) | [-1.0, 1.0] | [-1.0, 1.0] |
| FlappyBird-v0 | (16, 180) | [0, dmax] | (2, ) | {DO NOTHING, FLAP} | [-1.0, 1.0] |
Results
| Environment | SAC + gSDE |
SAC + gSDE + Huber loss |
SAC + TQC + gSDE |
Q-Learning | RL-Toolkit |
|---|---|---|---|---|---|
| BipedalWalkerHardcore-v3 | 13 ± 18(1) | 239 ± 118 | 228 ± 18(1) | - | 205 ± 134 |
| FlappyBird-v0 | - | - | - | 209.298(2) | 13 156 |
Releases
- SAC + gSDE + Huber loss
is stored here, branch r2.0 - SAC + TQC + gSDE + LogCosh + Reverb
is stored here, branch r4.0 - DQN + SAC agents branch r4.0
Frameworks: Tensorflow, DeepMind Reverb, Gymnasium, DeepMind Control Suite, WanDB, OpenCV
1 maintainer

Metadata
1 maintainer
Release files for rl-toolkit 5.0.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | |
|---|---|---|---|---|
| rl-toolkit-5.0.0.tar.gz | 20.3 kB | Without provenance | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| rl_toolkit-5.0.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 44.1 kB
Release files / rl-toolkit-5.0.0.tar.gz
| Download URL | rl-toolkit-5.0.0.tar.gz |
|---|---|
| Size | 20.3 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
8d64faf5ebdf5bcbdb8fcd76c6b9a6c9e6b2cf33801c73bf69d0e6b07a39de5d
|
|
BLAKE2b-256 checksum How to use checksums |
9e9fed0d42035d06eca2c09eca4e5079f1019ddaa4735eebc356c9eb9b87e895
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.0.1 CPython/3.10.16
|
Release files / rl_toolkit-5.0.0-py3-none-any.whl
| Download URL | rl_toolkit-5.0.0-py3-none-any.whl |
|---|---|
| Size | 23.8 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
1544438396d539ee0d101eeed6dc6b5fd1a4d94e930d429f1394f2664530df63
|
|
BLAKE2b-256 checksum How to use checksums |
0da8c98dfc5d9163873690a312923d2e5f6bd8797d2a54983b2b39b506185f2a
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.0.1 CPython/3.10.16
|
Security for rl-toolkit 5.0.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














