
ROS-Lab: Docker-Based Robot Operating System Virtual Lab
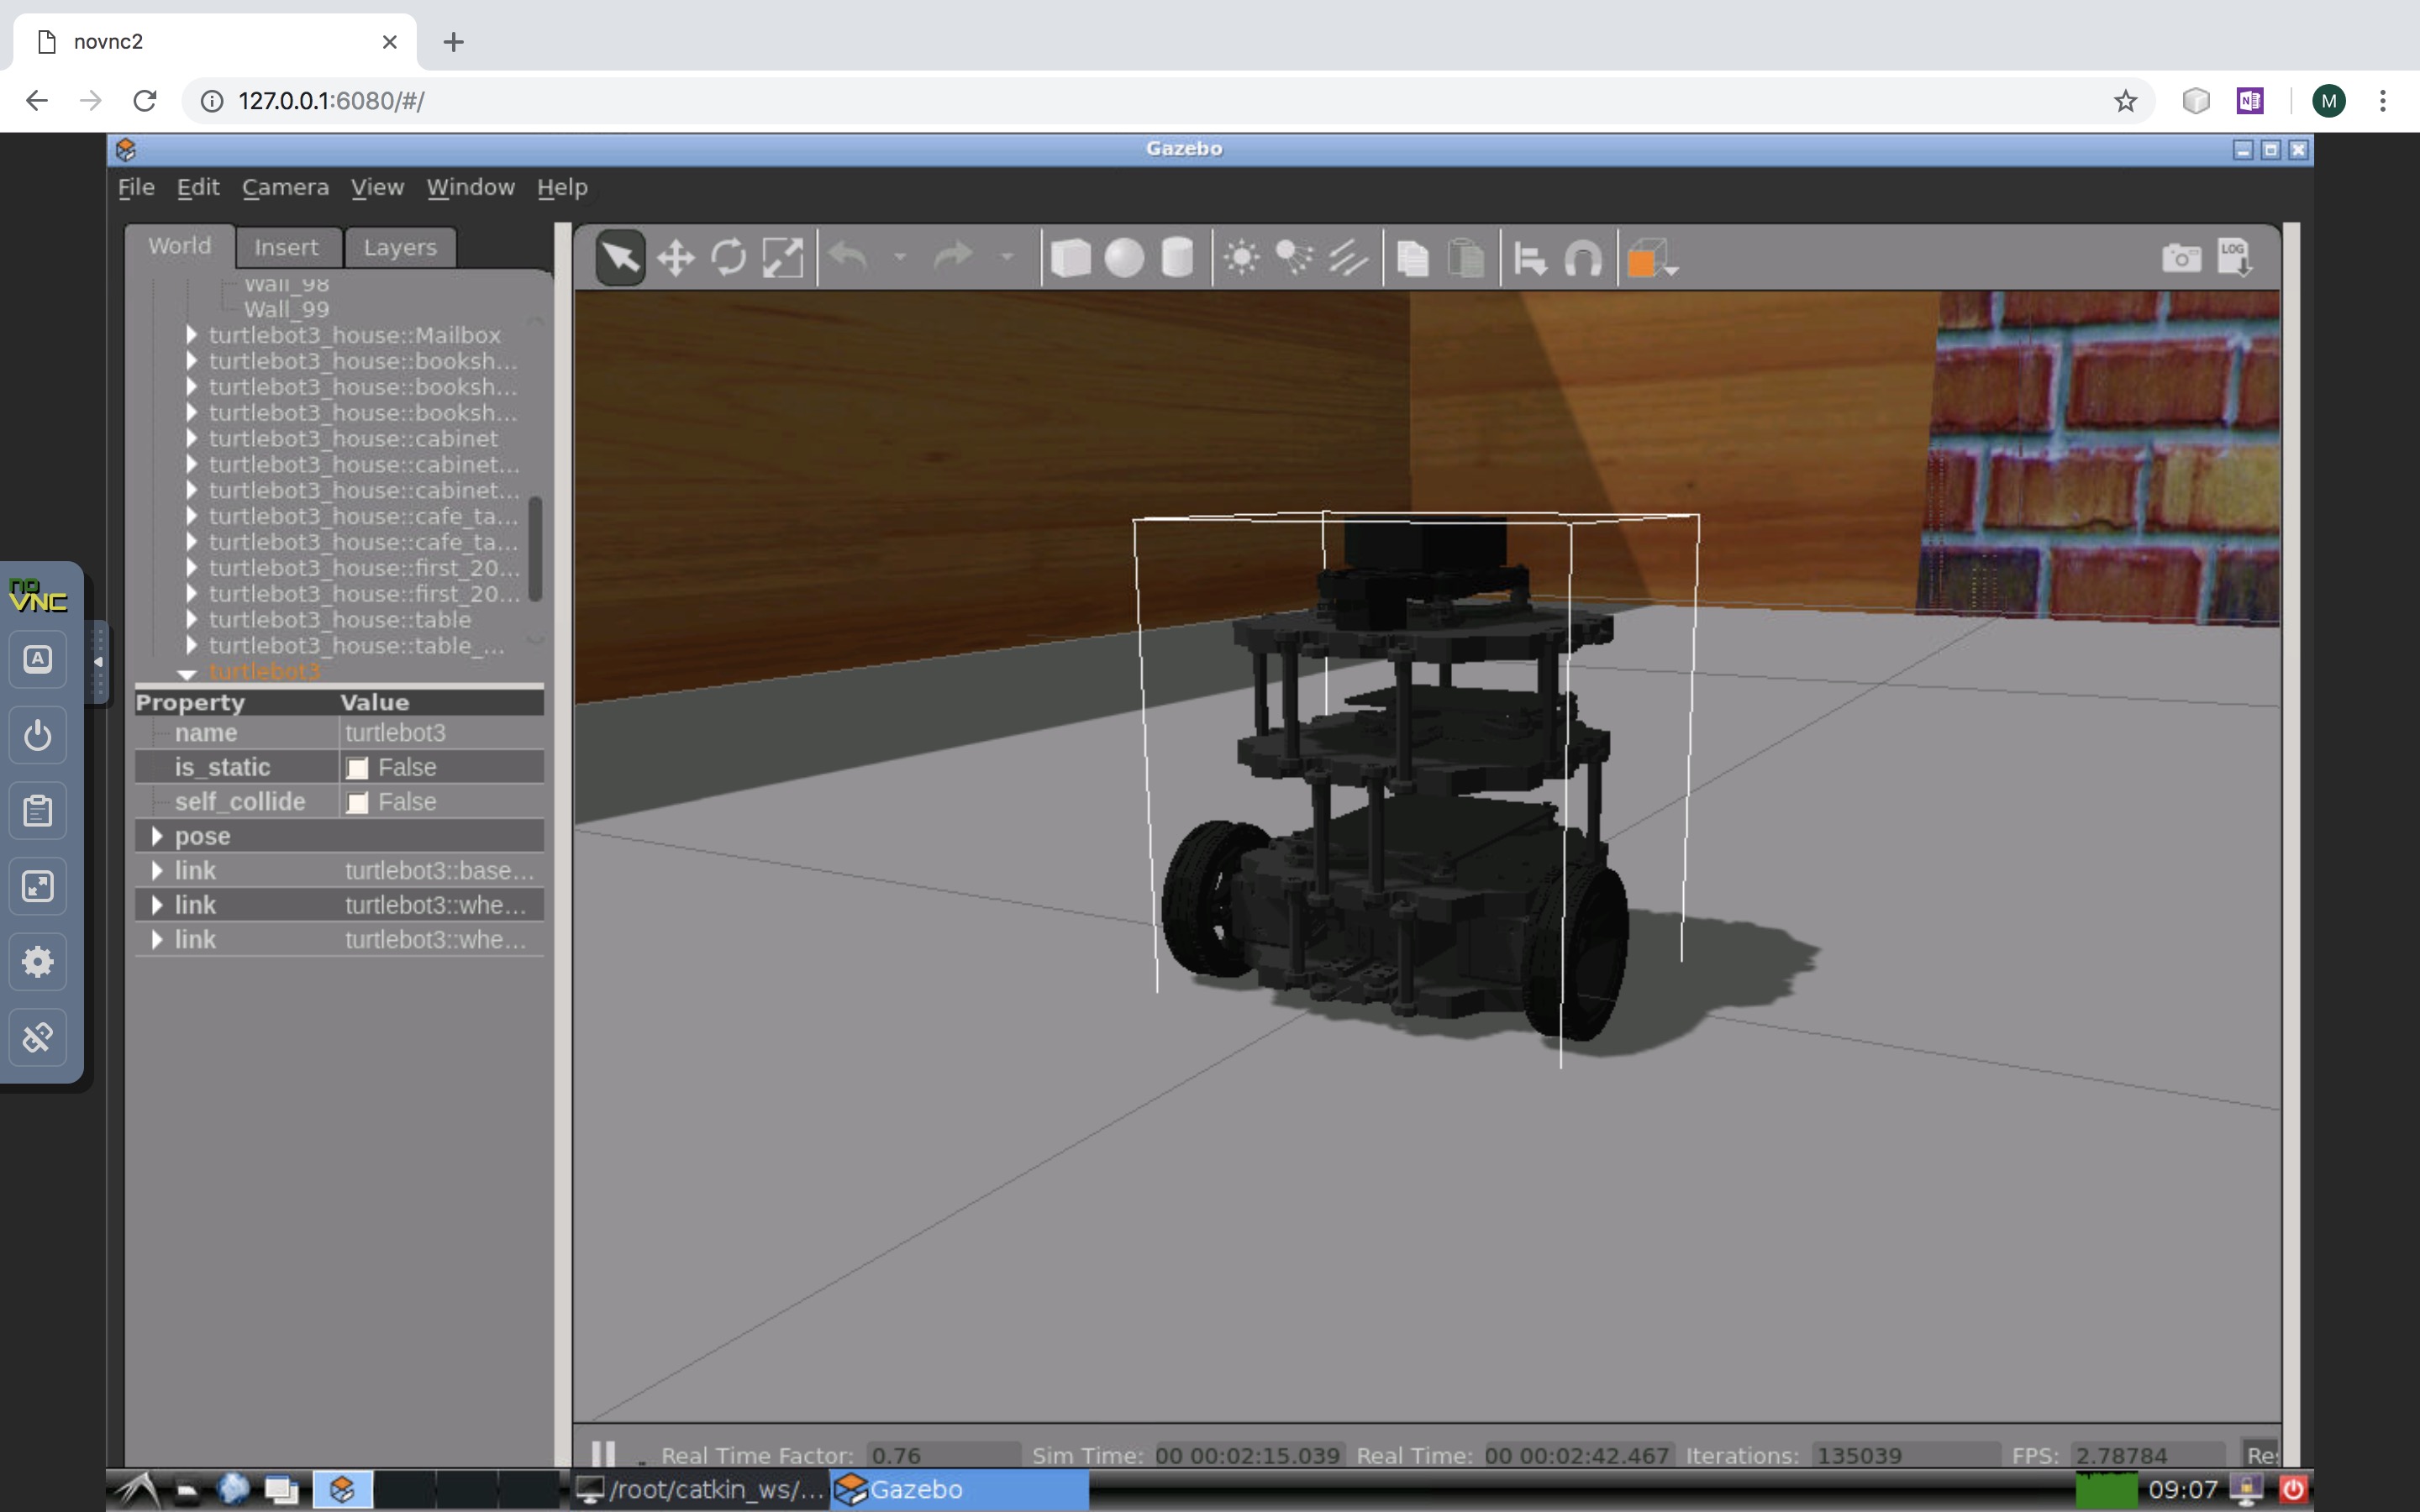
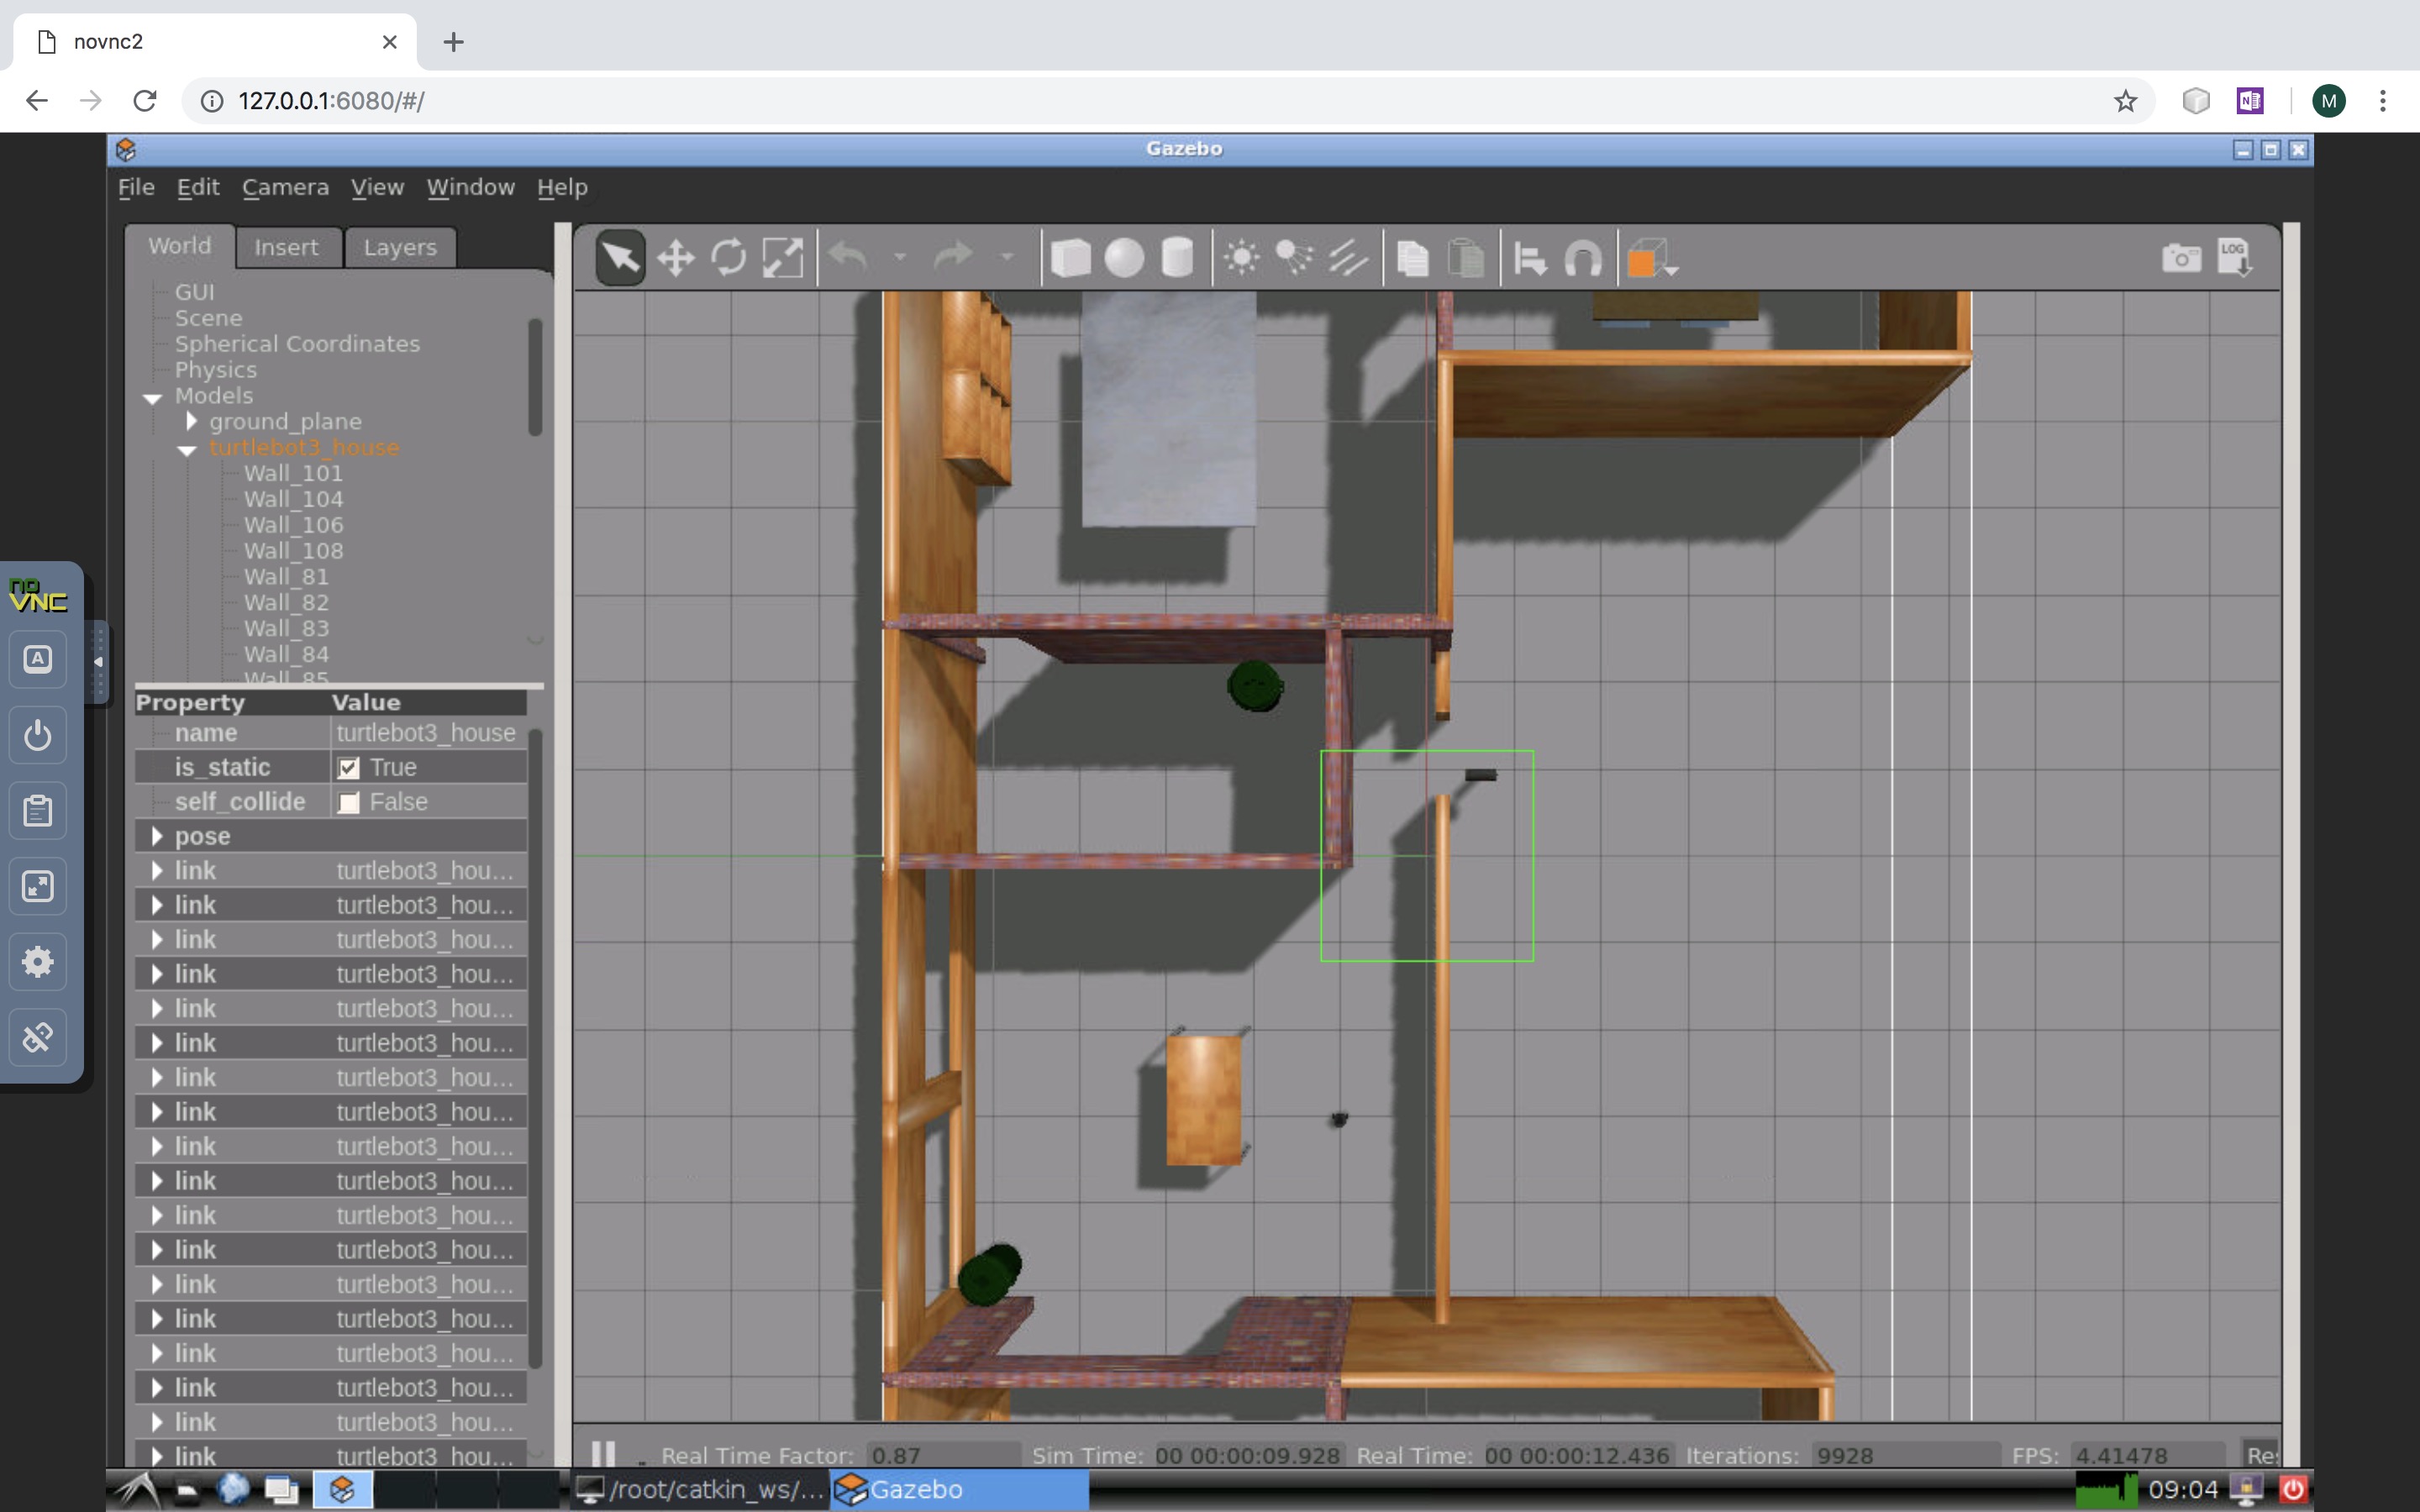
A Docker-based virtual lab of Robot Operating System to help beginners learn and practise. It's based on docker image "muchensun/ros_turtlebot3_vnc", which is built on another docker image "dorowu/ubuntu-desktop-lxde-vnc". This lab is wrapped by a command line tool to simplify operations.
Installation
It's highly recommended to create a conda Python3 environment before installation.
You can use pip to install(remember to use Python3), type the following command:
pip install ros-lab
How to use
- Type
ros-labin command line, you will enter ros-lab. - Input
helpor?for command information. - Have fun with ros-lab !
Several tips
- For Ubuntu user, you may need to configure Docker before you start. If you have problems about user permission, please try the first answer here.
- After executing the "start_lab" command, it may take sime time to start the lab. You can try to refresh the page.
Useful links
- This work is finished in Distributed & Embedded System Lab, Lanzhou University.
- ROS Official Tutorial.
- TurtleBot3 Official Manual.
- A very helpful ROS course held by ETH.
1 maintainer

Metadata
1 maintainer
Release files for ros-lab 0.0.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| ros-lab-0.0.0.tar.gz | 3.2 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| ros_lab-0.0.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 19.6 kB
Release files / ros-lab-0.0.0.tar.gz
| Download URL | ros-lab-0.0.0.tar.gz |
|---|---|
| Size | 3.2 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
08103680f7cb4a6c4b893dee457adb3f9a29f3c0a8efbb807ddb5c10e88c2ae8
|
|
BLAKE2b-256 checksum How to use checksums |
cb16787b2b6162957b5cc65914eb3a500c0103215ef592b5d80f0b955bfff061
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/1.13.0 pkginfo/1.5.0.1 requests/2.21.0 setuptools/40.8.0 requests-toolbelt/0.9.1 tqdm/4.31.1 CPython/3.6.8
|
Release files / ros_lab-0.0.0-py3-none-any.whl
| Download URL | ros_lab-0.0.0-py3-none-any.whl |
|---|---|
| Size | 16.4 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
5bf3125aa23e1ff82d802cd883d1523fcb87735e46bf5440e5d2ab53e0737157
|
|
BLAKE2b-256 checksum How to use checksums |
a585daecfb9cda680f3690be332513c43c047fb05cb556a4f091e699b95acdeb
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/1.13.0 pkginfo/1.5.0.1 requests/2.21.0 setuptools/40.8.0 requests-toolbelt/0.9.1 tqdm/4.31.1 CPython/3.6.8
|













