


🪰 Overview
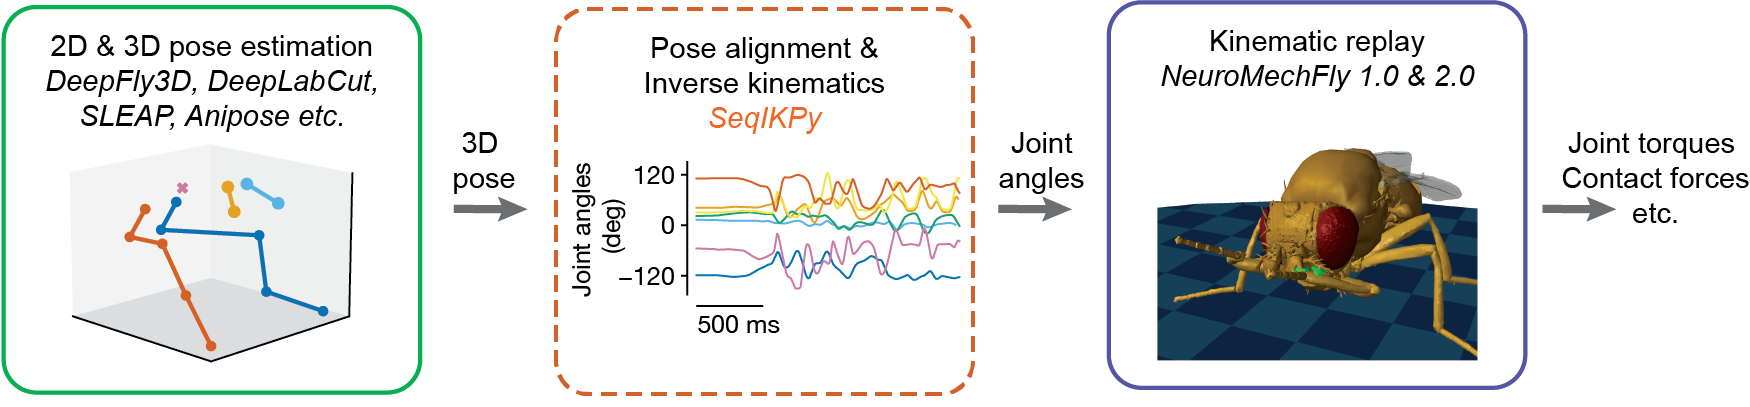
SeqIKPy is a Python package that provides an implementation of inverse kinematics (IK) that is based on the open-source Python package IKPy. In constrast to the current IK approaches that aims to match only the end-effector, SeqIKPy is designed to calculate the joint angles of the fly body parts to align the 3D pose of the entire kinematic chain to a desired 3D pose. In particular, you can use SeqIKPy in the pipeline shown below.
📐 Features
- Pose alignment: Align of 3D pose data to a fly biomechanical model, e.g., NeuroMechFly.
- Leg inverse kinematics: Calculate leg joint angles using sequential inverse kinematics.
- Head inverse kinematics: Calculate head and antenna joint angles using the vector dot product method.
- Visualization and animation: Visualize and animate the results in 3D.
🗂️ Summary of directories
.
├── data: Folder containing the sample data.
├── docs: Documentation for the website.
├── examples: Examples and tutorials on how to use the package.
├── seqikpy: Main package.
└── tests: Tests for the package.
📚 Documentation
Documentation can be found here.
🛠️ Installation
If you aim to purely use SeqIKPy as a dependency for your project, you can install the newest version of the package manually by running the following line in the terminal:
# Optionally create/activate a virtual environment first. Then,
$ pip install seqikpy
If you plan to follow the tutorial or help develop SeqIKPy, you should download the data/ directory, which contains sample data for demonstration and testing. In this case, you should clone this GitHub repository and installing it locally instead of downloading it from PyPI:
# Optionally create/activate a virtual environment first. Then,
$ git clone git@github.com:NeLy-EPFL/sequential-inverse-kinematics.git
# ... or with HTTP: git clone https://github.com/NeLy-EPFL/sequential-inverse-kinematics.git
$ cd sequential-inverse-kinematics/

# Install the package locally (development mode)
$ pip install -e ".[dev]" --config-settings editable_mode=compat
# ... where editable_mode=compat helps static code analyzers in IDEs parse your code better

# Alternatively, use uv for faster dependency resolution (`pip install uv` first)
$ uv pip install -e ".[dev]"
🏁 Quick Start
Please see the quick start guide here.
💻 Contributing
We welcome contributions from the community. If you would like to contribute to the project, please refer to the contribution guidelines. Also, read our code of conduct. If you have any questions, please feel free to open an issue or contact the developers.
📖 License
This project is licensed under the Apache 2.0 License.
🐞 Issues
If you encounter any bugs or request a new feature, please open an issue in our issues page.
💬 Citing
If you find this package useful in your research, please consider citing it using the following BibTeX entry:
@article{ozdil2026seqikpy,
  title={SeqIKPy: a Python package for inverse kinematics in insects},
  author={{\"O}zdil, Pembe Gizem and Wang-Chen, Sibo and Ning, Chuanfang and Ijspeert, Auke and Ramdya, Pavan},
  journal={Journal of Open Source Software},
  volume={11},
  number={117},
  pages={8557},
  year={2026}
}


Release files for seqikpy 1.1.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | |
|---|---|---|---|---|
| seqikpy-1.1.0.tar.gz | 49.1 kB | Without provenance | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| seqikpy-1.1.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 91.0 kB
Release files / seqikpy-1.1.0.tar.gz
| Download URL | seqikpy-1.1.0.tar.gz |
|---|---|
| Size | 49.1 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
d0e7e4a681679b329c7e757b380c35e8827fa66eaa1294cf57a5c9bff41355db
|
|
BLAKE2b-256 checksum How to use checksums |
ef33d4e35e5c799961ac630b15dcfd40cc9e59d67e23ff0fe2e8c82744275cc9
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
uv/0.9.21 {"installer":{"name":"uv","version":"0.9.21","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":{"name":"Ubuntu","version":"24.04","id":"noble","libc":null},"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":null}
|
Release files / seqikpy-1.1.0-py3-none-any.whl
| Download URL | seqikpy-1.1.0-py3-none-any.whl |
|---|---|
| Size | 41.8 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
5a42c2f874f64dcae26c06f6b8328061f6c04b686f3473ab7e16dfa93eec0849
|
|
BLAKE2b-256 checksum How to use checksums |
e037f1e0426a33c7e361509752614297554d1e687aebe69128a7a1d394b17c93
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
uv/0.9.21 {"installer":{"name":"uv","version":"0.9.21","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":{"name":"Ubuntu","version":"24.04","id":"noble","libc":null},"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":null}
|
Security for seqikpy 1.1.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














