
Turn a written lab protocol into a robot program, and rehearse it before it touches a real bench.

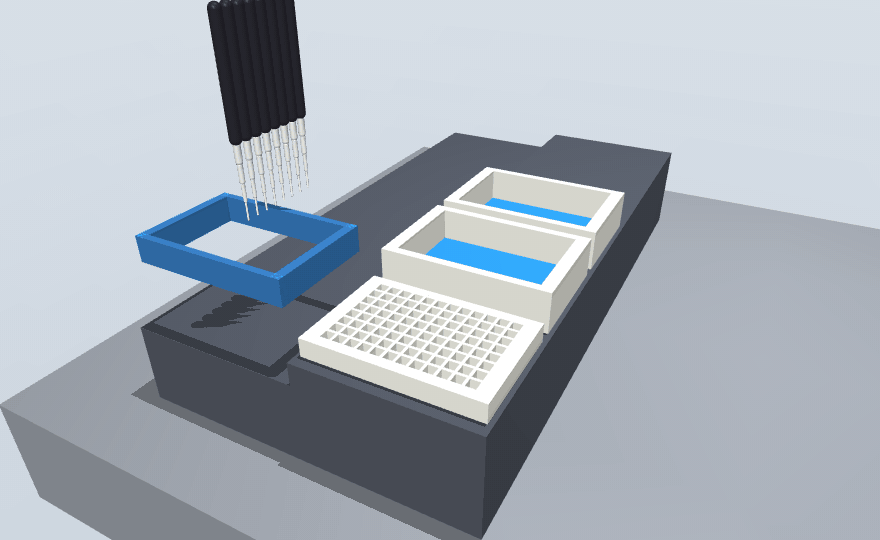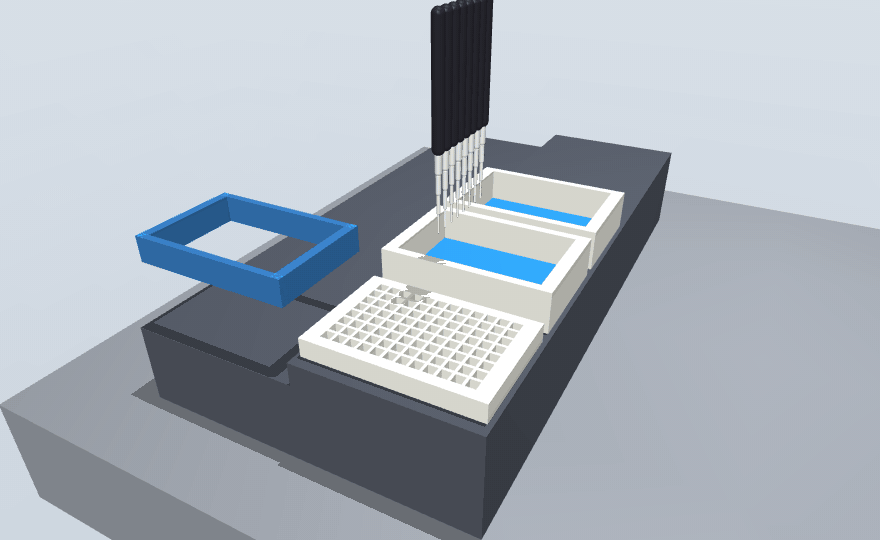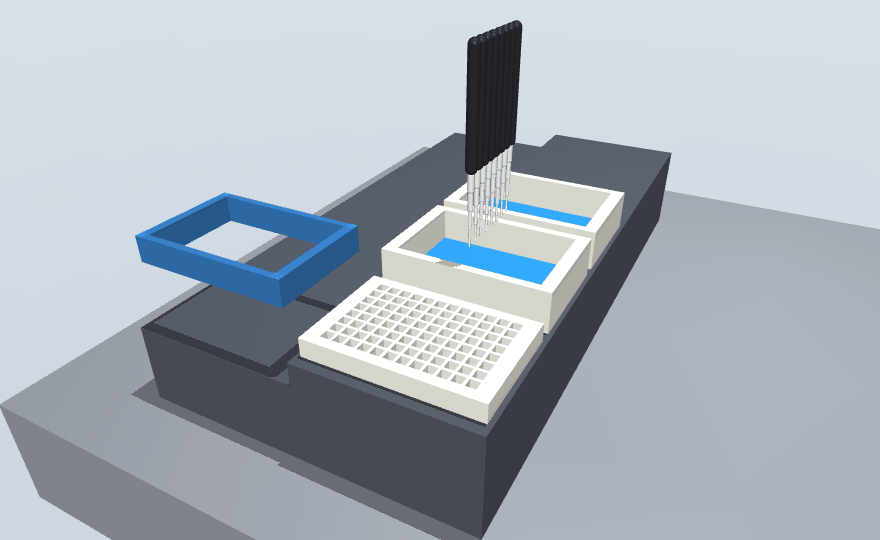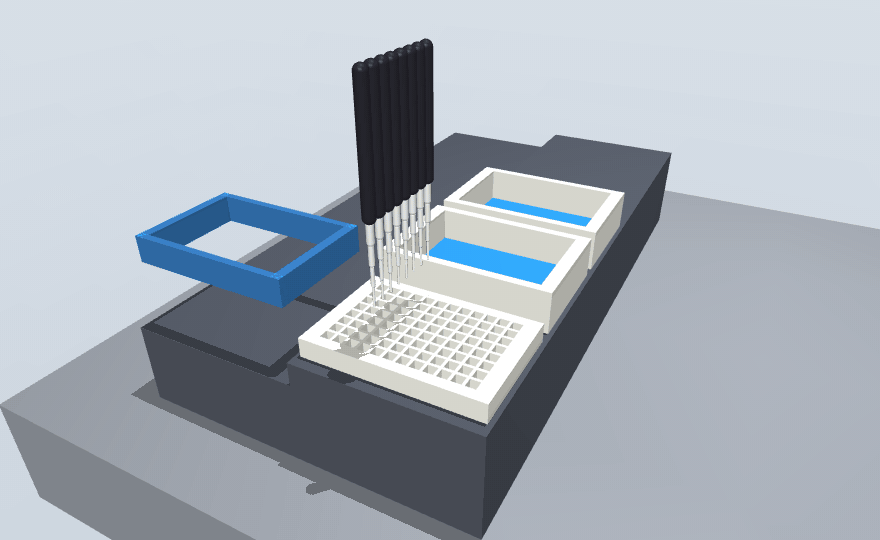
Write what you want done in a short protocol file that names no robot, or have a language model draft that file from your notes or a kit manual. steadyhand checks that the liquid adds up, plans the run for the robot you pick, replays every move in a MuJoCo scene built from the same deck, and writes the program that does exactly what was rehearsed.
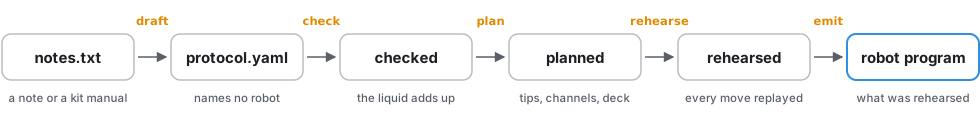
Pre-alpha. The whole path runs for pipetting protocols on a Hamilton STARlet, an Opentrons Flex and an Opentrons OT-2, but nothing has been compared with a real robot yet. It is not a tool to trust with a real run. See what it does not do yet.
| Hamilton STARlet | Opentrons Flex | Opentrons OT-2 | |
|---|---|---|---|
| Program it writes | PyLabRobot script | Opentrons Python protocol | Opentrons Python protocol |
| Physics replay of every move | yes | yes | yes |
| The maker's own simulator | yes | yes, a release that still takes OT-2 files | |
| Magnet for bead cleanups | magnetic plate adapter | Magnetic Block | Magnetic Module |
| Planted mistakes stopped | 24 of 26 | 18 of 21 | 18 of 21 |
Try it
pip install steadyhand
steadyhand demo
demo rehearses a small protocol that ships inside the package. To run the examples in this
repository:
git clone https://github.com/dundysm/steadyhand && cd steadyhand
pip install -e .
steadyhand rehearse examples/serial_dilution.yaml
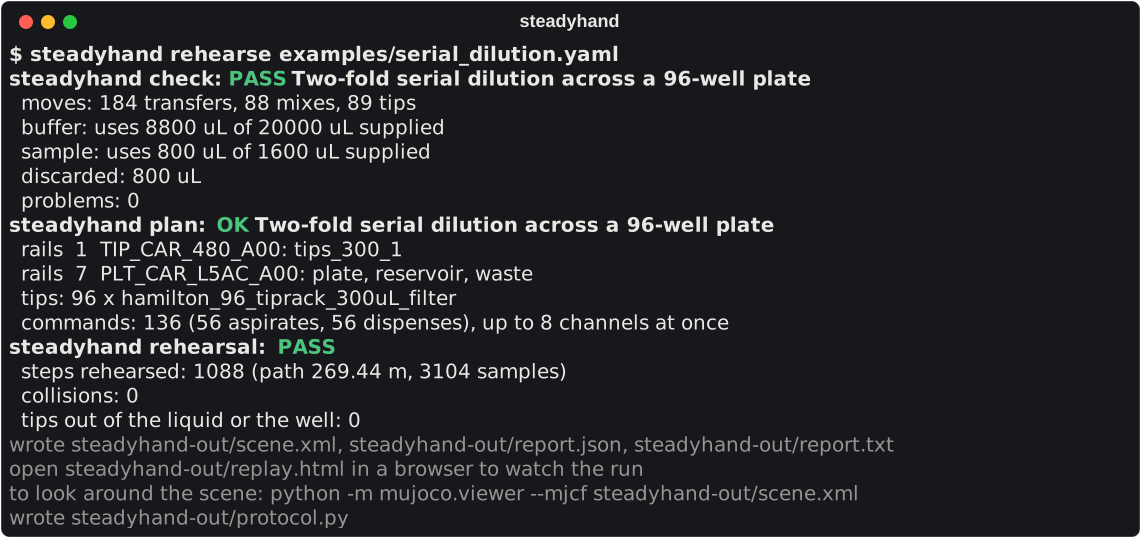
steadyhand-out/ then holds protocol.py (the PyLabRobot script), replay.html (the run played
back, below), scene.xml (open it with python -m mujoco.viewer --mjcf steadyhand-out/scene.xml),
a report as text and JSON, and two pictures when the machine can render offscreen. Every command exits with status 1 when
something is wrong, so it can gate a script or a CI job.
The protocol file
The protocol in the run above is this file:
steadyhand: 0.1
name: Two-fold serial dilution across a 96-well plate
labware:
  plate:     {type: Cor_96_wellplate_360ul_Fb}
  reservoir: {type: nest_1_troughplate_195000uL_Vb}
liquids:
  buffer: {in: reservoir/A1, volume: 20 mL}
  sample: {in: plate/A1:H1, volume: 200 uL}
steps:
  - transfer: {from: reservoir/A1, to: plate/A2:H12, volume: 100 uL, tips: reuse}
  - serial_dilution:
      start: plate/A1:H1
      steps: 11
      direction: right
      volume: 100 uL
      mix: {times: 3, volume: 80 uL}
It says what to do and nothing about how a robot does it. Every amount carries a unit, unknown fields are errors, and every problem is reported at once with its place in the file. The format is a draft: see docs/protocol-format.md.
Draft it from your notes
steadyhand draft notes.txt --robot opentrons-flex -o protocol.yaml --decide "24 samples, in triplicate"
draft is the only place a language model is used. The model writes the protocol file; steadyhand
then checks, plans and rehearses that file exactly as if you had written it, and sends whatever
stops it back to the model, up to three times. The file lists what your text left open and the
model decided under chose, and --decide settles any of it up front. More in
docs/drafting.md.
What it stops, measured
A dry run that passes says little unless you know what it would have failed on.
| Measured | Result |
|---|---|
| Known mistakes planted in a working protocol, and stopped | 24 of 26 on the Hamilton, 18 of 21 on the Flex and on the OT-2 |
| Drafts from manufacturers' kit manuals that stand as rehearsed programs with no hand edits | 121 of 146, from 71 manuals in ten sets |
| Automated tests | 200 |
| Runs compared with a real robot | none yet |
steadyhand faults runs the first row yourself; the tables are in docs/faults.md
and a test pins them, so a change in either direction shows. What gets through is named there
too: a tip carried down a dilution series, and a plate on the deck that is not the plate in the
plan. The drafting numbers, with every manual, every caveat and what the agents found unclear,
are in evals/RESULTS.md. The sets are small and were read by the project
itself, not by someone who runs these kits.
Read more
| The commands | check, plan, rehearse, emit, faults: what each catches and decides, how to change the plan, and the replay page |
| The protocol file | Every field: transfers, dilutions, mixes, waits, pauses, the magnet, needs, chose |
| Robots | What differs on the Flex and the OT-2, and what Opentrons' simulator adds |
| Drafting from text | Using your own model, what the model is told, and how a draft is fed back |
| Rehearsing a PyLabRobot script you already have | The recording backend, and how the scene is built |
| What it does not do yet | Read this before relying on anything here |
| Measurements | Every drafting run, newest first |
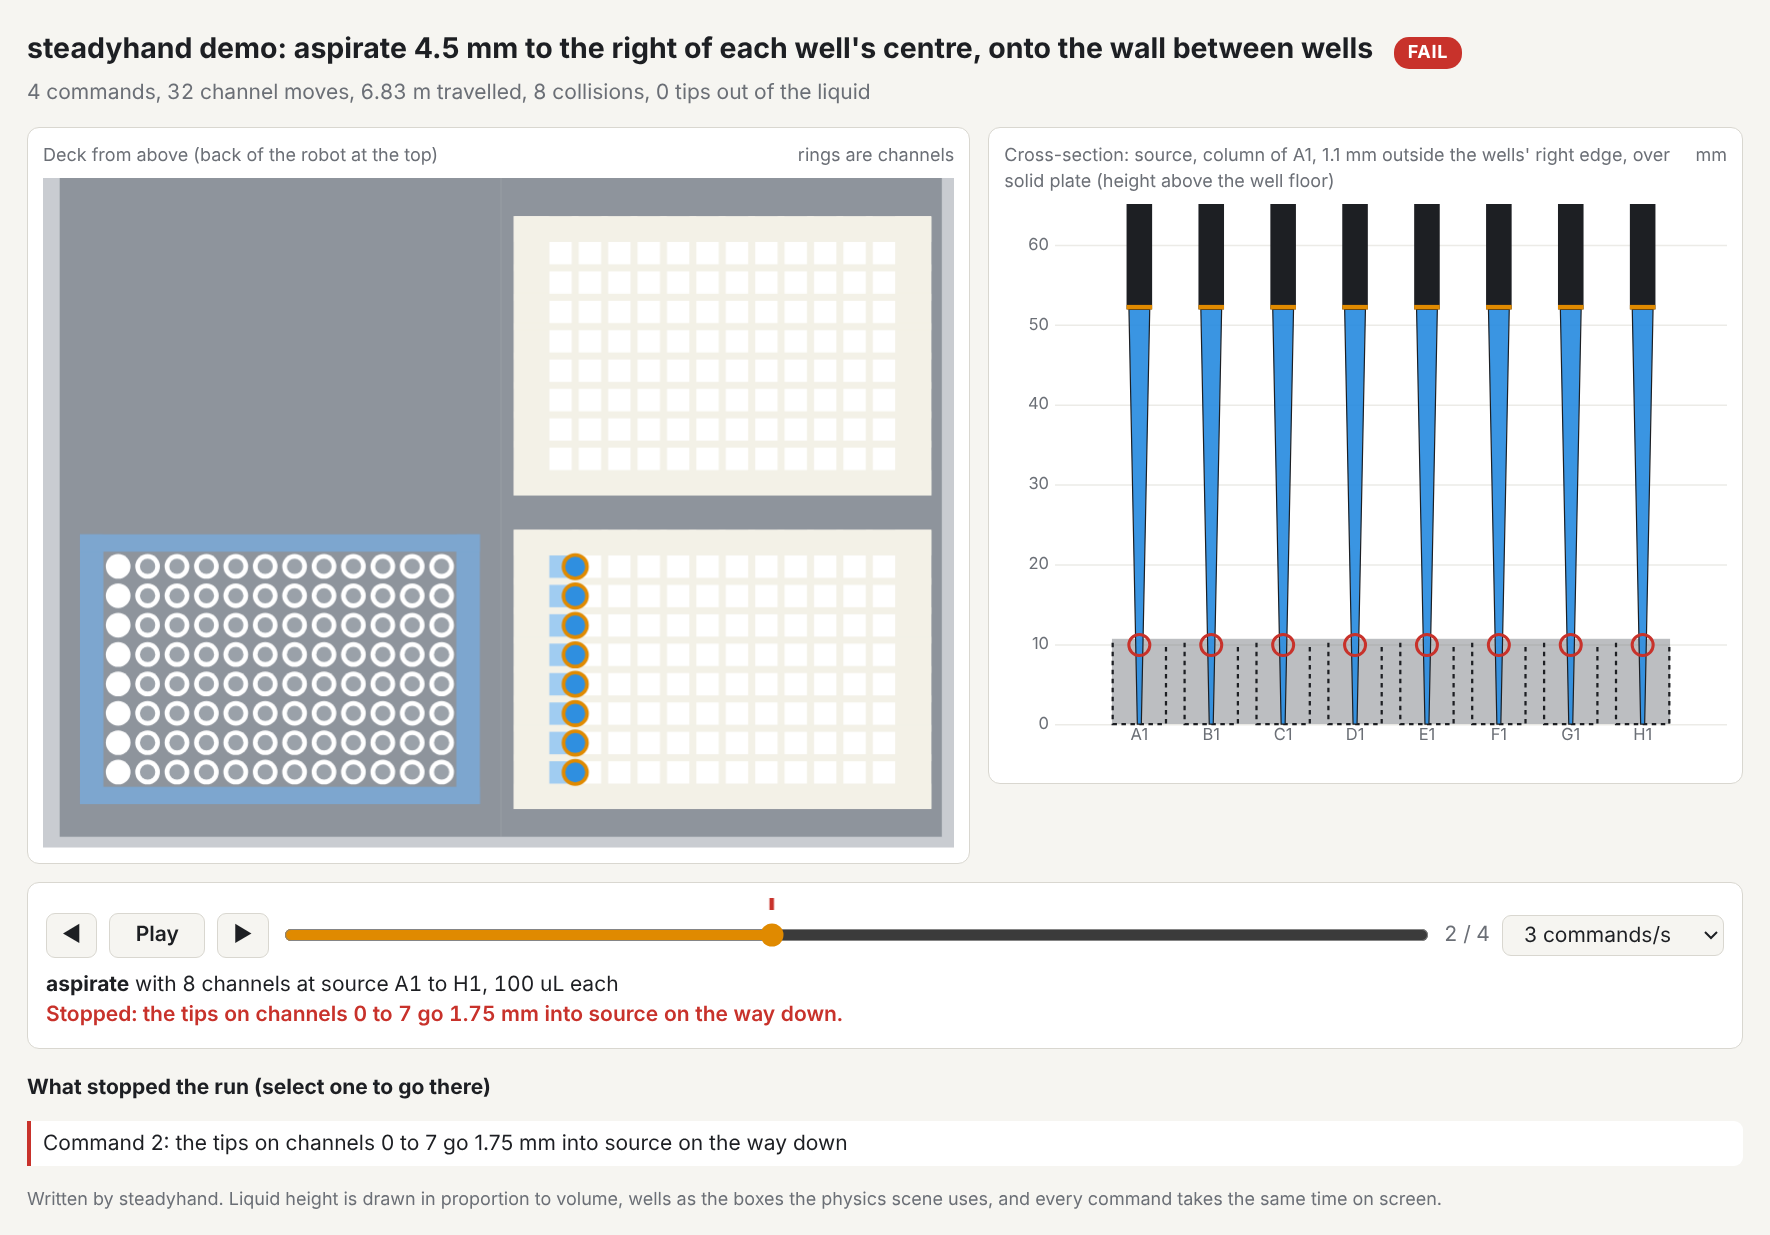
Every rehearsal writes a single replay.html that plays the run back and opens at whatever stopped it.
Development
pip install -e ".[dev]"
pytest
Earlier commits and notes call this project drybench; it was renamed at 0.14.0.
License
Apache-2.0. See LICENSE.
1 maintainer

Metadata
1 maintainer
Release files for steadyhand 0.37.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| steadyhand-0.37.0.tar.gz | 3.0 MB | With provenance | Details for steadyhand-0.37.0.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| steadyhand-0.37.0-py3-none-any.whl | Python 3 | none | any | Details for steadyhand-0.37.0-py3-none-any.whl |
Total release size: 3.1 MB
Release files / steadyhand-0.37.0.tar.gz
| Download URL | steadyhand-0.37.0.tar.gz |
|---|---|
| Size | 3.0 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
56e4b47cfe45b0795670ca8a265e91342e3f35cbdf839831ad4d35b6119e7535
|
|
BLAKE2b-256 checksum How to use checksums |
198d004679ca4bab9c5c996d517956b5848e6e8d2aad05cc6317f8761eab28ba
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Nov 15, 2026.
Transparency logRelease files / steadyhand-0.37.0-py3-none-any.whl
| Download URL | steadyhand-0.37.0-py3-none-any.whl |
|---|---|
| Size | 122.6 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
69e84bb841223a83e30284513682072c1346d21834823675398bc664ce5bb5e8
|
|
BLAKE2b-256 checksum How to use checksums |
7066242044c392f05edd8fdbbc4e0e40b2041d9874ffce9311fcbe002787265a
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Nov 15, 2026.
Transparency logSecurity for steadyhand 0.37.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
Full provenance
Both files in this release have been uploaded with provenance metadata.
Attestation for steadyhand-0.37.0.tar.gz
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Nov 15, 2026.
Transparency logA note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














