
This release is a pre-release and may not be stable for production use.
Supervision, except the numbers have finally been informed that GPUs exist.
SuperiorVision is Roboflow's tensor-native, inference-focused fork of
Supervision. It preserves the
import supervision as sv API used by
Roboflow Inference, while keeping
rectangular numeric state in torch.Tensor objects throughout the supported
code paths.
If detections begin as tensors, converting them to NumPy so the next operation can turn them back into tensors is not "compatibility." It is cardio. SuperiorVision declines the workout.



Same API. Fewer NumPy vacations.
For the external multi-object trackers used by Inference, pair SuperiorVision
with the Tracktors package. The
dependency points one way—Tracktors consumes tensor-native sv.Detections—so
SuperiorVision keeps its existing sv.ByteTrack compatibility API without a
circular package dependency.
📑 Table of Contents
👋 Hello
The familiar computer-vision toolkit, now with fewer surprise trips to the CPU. From tensor-native detections to real-time zone counting, SuperiorVision keeps the compatible building blocks used by Inference while letting GPUs do the job they were purchased to do. 🤝
💻 Install
Install the SuperiorVision distribution in a Python>=3.10 environment. The published version is currently a development release, so pin it explicitly:
pip install superiorvision==0.30.0.dev3
For an editable checkout:
git clone git@github.com:roboflow/superiorvision.git
cd superiorvision
pip install -e .
Both imports are supported:
import supervision as sv       # existing Inference code
import superiorvision as sv    # cheekier spelling, same API
The PyPI distribution is named superiorvision, but it intentionally provides
the supervision import namespace for drop-in compatibility. Install it as a
replacement for upstream Supervision, not beside it. Two distributions cannot
both own the same trench coat and pretend everything is fine.
The upstream documentation below remains useful for the compatible API surface.
🔥 Quickstart
Models
SuperiorVision preserves Supervision's model-agnostic API. Just plug in any classification, detection, or segmentation model. The compatible connectors cover popular libraries such as Ultralytics, Transformers, MMDetection, and Inference. Other integrations, including rfdetr, already return sv.Detections directly.
Install the optional dependencies for this example with pip install pillow rfdetr.
import supervision as sv
from PIL import Image
from rfdetr import RFDETRSmall

image = Image.open("path/to/image.jpg")
model = RFDETRSmall()
detections = model.predict(image, threshold=0.5)

len(detections)
# 5
👉 more model connectors
-
inference
Running with Inference requires a Roboflow API KEY.
import supervision as sv
from PIL import Image
from inference import get_model

image = Image.open("path/to/image.jpg")
model = get_model(model_id="rfdetr-small", api_key="ROBOFLOW_API_KEY")
result = model.infer(image)[0]
detections = sv.Detections.from_inference(result)

len(detections)
# 5
Annotators
SuperiorVision retains the wide range of customizable annotators from its upstream API, allowing you to compose the visualization your use case needs.
import cv2
import supervision as sv

image = cv2.imread("path/to/image.jpg")
# Assuming detections are obtained from a model
detections = sv.Detections(...)

box_annotator = sv.BoxAnnotator()
annotated_frame = box_annotator.annotate(scene=image.copy(), detections=detections)
https://github.com/roboflow/supervision/assets/26109316/691e219c-0565-4403-9218-ab5644f39bce
Datasets
SuperiorVision retains the compatible dataset utilities for loading, splitting, merging, and saving supported formats. Dataset and image I/O remain deliberate CPU boundaries; tensor-native runtime paths do not need to cosplay as JPEG encoders.
import supervision as sv
from roboflow import Roboflow

project = Roboflow().workspace("WORKSPACE_ID").project("PROJECT_ID")
dataset = project.version("PROJECT_VERSION").download("coco")

ds = sv.DetectionDataset.from_coco(
    images_directory_path=f"{dataset.location}/train",
    annotations_path=f"{dataset.location}/train/_annotations.coco.json",
)

path, image, annotation = ds[0]
# loads image on demand

for path, image, annotation in ds:
    # loads image on demand
    pass
👉 more dataset utils
-
load
dataset = sv.DetectionDataset.from_yolo(
    images_directory_path=...,
    annotations_directory_path=...,
    data_yaml_path=...,
)

dataset = sv.DetectionDataset.from_pascal_voc(
    images_directory_path=...,
    annotations_directory_path=...,
)

dataset = sv.DetectionDataset.from_coco(
    images_directory_path=...,
    annotations_path=...,
)
-
split
train_dataset, test_dataset = dataset.split(split_ratio=0.7)
test_dataset, valid_dataset = test_dataset.split(split_ratio=0.5)

len(train_dataset), len(test_dataset), len(valid_dataset)
# (700, 150, 150)
-
merge
ds_1 = sv.DetectionDataset(...)
len(ds_1)
# 100
ds_1.classes
# ['dog', 'person']

ds_2 = sv.DetectionDataset(...)
len(ds_2)
# 200
ds_2.classes
# ['cat']

ds_merged = sv.DetectionDataset.merge([ds_1, ds_2])
len(ds_merged)
# 300
ds_merged.classes
# ['cat', 'dog', 'person']
-
save
dataset.as_yolo(
    images_directory_path=...,
    annotations_directory_path=...,
    data_yaml_path=...,
)

dataset.as_pascal_voc(
    images_directory_path=...,
    annotations_directory_path=...,
)

dataset.as_coco(
    images_directory_path=...,
    annotations_path=...,
)
-
convert
sv.DetectionDataset.from_yolo(
    images_directory_path=...,
    annotations_directory_path=...,
    data_yaml_path=...,
).as_pascal_voc(
    images_directory_path=...,
    annotations_directory_path=...,
)
🎬 Tutorials
Want to learn the compatible API? Explore the upstream how-to guides, end-to-end examples, cheatsheet, and cookbooks!
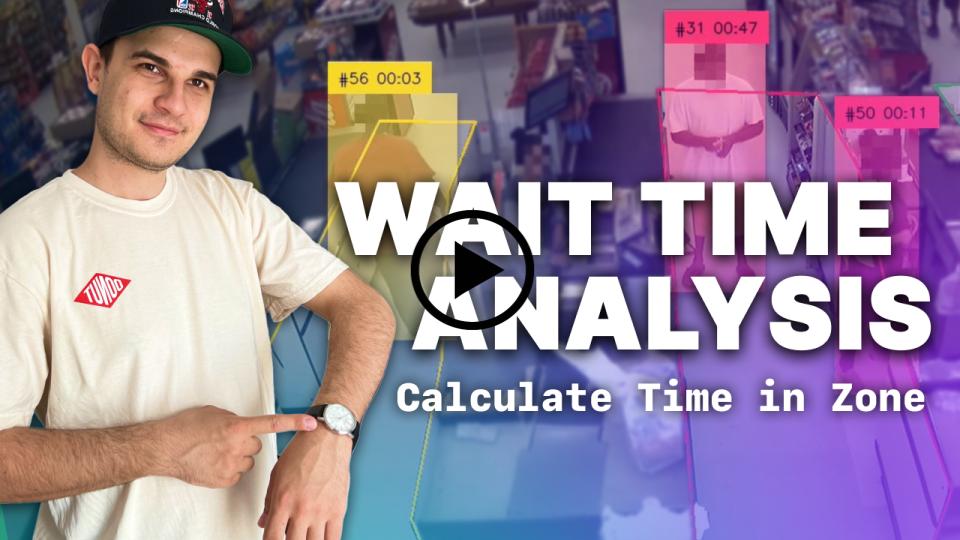
Learn how to use computer vision to analyze wait times and optimize processes. This tutorial covers object detection, tracking, and calculating time spent in designated zones. Use these techniques to improve customer experience in retail, traffic management, or other scenarios.
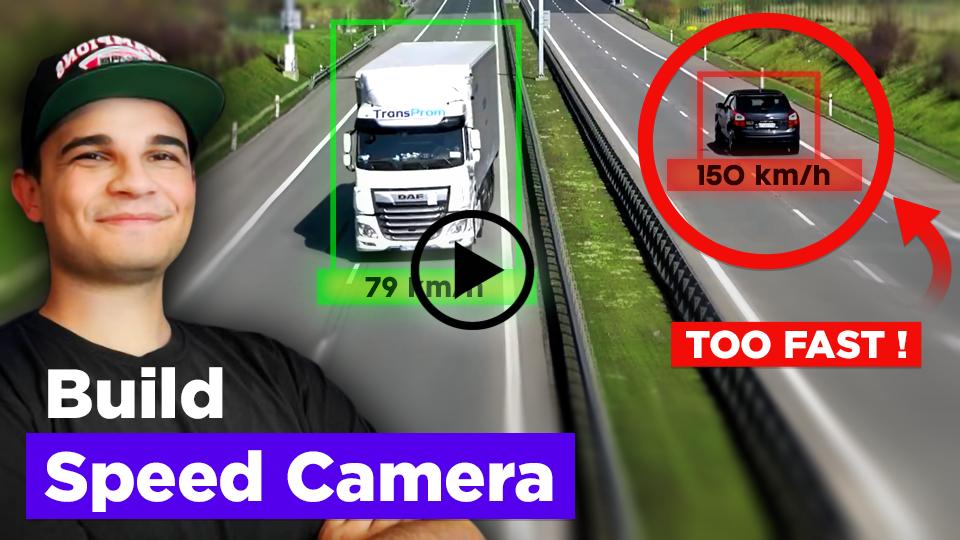
Learn how to track and estimate the speed of vehicles using YOLO, ByteTrack, and Roboflow Inference. This comprehensive tutorial covers object detection, multi-object tracking, filtering detections, perspective transformation, speed estimation, visualization improvements, and more.
💜 Built with the API
Did you build something cool using the compatible supervision API? Tell us in the SuperiorVision repository.
https://github.com/roboflow/supervision/assets/26109316/c9436828-9fbf-4c25-ae8c-60e9c81b3900
https://github.com/roboflow/supervision/assets/26109316/3ac6982f-4943-4108-9b7f-51787ef1a69f
📚 Documentation
The upstream Supervision documentation describes the compatible API. Fork-specific tensor coverage and Inference compatibility are tracked in this repository and the Inference API surface audit.
🏆 Contribution
We love your input! Please see our contributing guide to get started. The fork lives at roboflow/superiorvision; upstream-compatible changes may still belong in Supervision. Thank you 🙏 to all our contributors!


1 maintainer

Metadata
1 maintainer
Release files for superiorvision 0.30.0.dev4
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| superiorvision-0.30.0.dev4.tar.gz | 376.7 kB | Without provenance | Details for superiorvision-0.30.0.dev4.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| superiorvision-0.30.0.dev4-py3-none-any.whl | Python 3 | none | any | Details for superiorvision-0.30.0.dev4-py3-none-any.whl |
Total release size: 795.1 kB
Release files / superiorvision-0.30.0.dev4.tar.gz
| Download URL | superiorvision-0.30.0.dev4.tar.gz |
|---|---|
| Size | 376.7 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
e46fd4a7d9d45253f5156c5af6ff3f63d4e11b35227174939e1316721a41e87a
|
|
BLAKE2b-256 checksum How to use checksums |
cdfd7cbd51c57d5c02ddaf67f3d06ef3c7f45a1953da8fbc99fbb77b40f11d6f
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.1.0 CPython/3.12.9
|
Release files / superiorvision-0.30.0.dev4-py3-none-any.whl
| Download URL | superiorvision-0.30.0.dev4-py3-none-any.whl |
|---|---|
| Size | 418.3 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
34034482a6e2a94005b5133f6bb39e6ac09cddfa9cc5cabc859eb063698979f7
|
|
BLAKE2b-256 checksum How to use checksums |
f2de4e6a5c1d308e0881c8ed34a2cb2b9e6d5a853e819c268f3de964a7e7a4e8
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.1.0 CPython/3.12.9
|
Security for superiorvision 0.30.0.dev4
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














