
This release is a pre-release and may not be stable for production use.
Tesseract Python (nanobind)
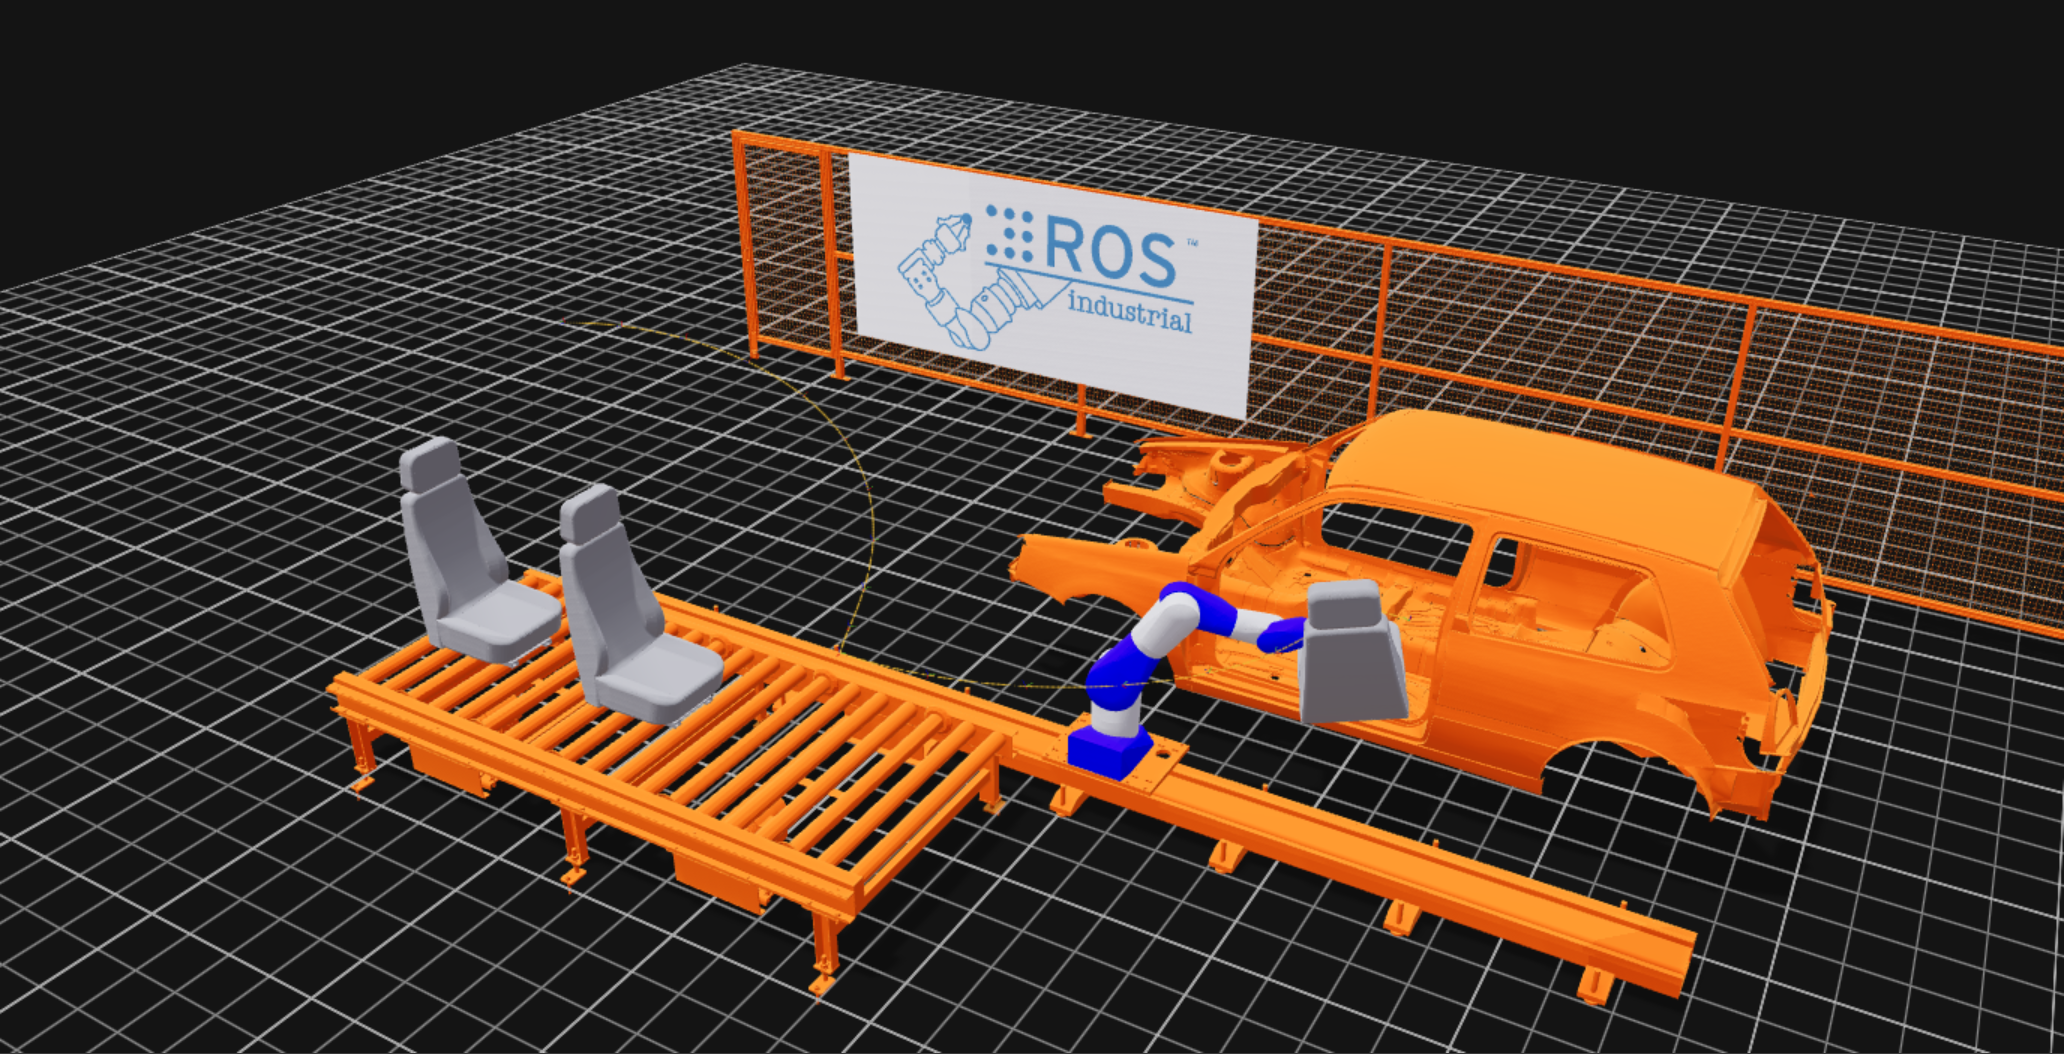


Python bindings for Tesseract, the ROS-Industrial motion planning framework. Load a robot, check collisions, solve kinematics and plan collision-free trajectories from Python, without ROS.
The bindings cover the Tesseract C++ libraries module by module:
environmentandscene graph,kinematics(KDL, OPW, UR),collision checking(Bullet, FCL)OMPLmotion-planning,TrajOpt-Ifopt,Descartesand simple planners.time parameterization(TOTG, ISP, constant TCP speed, Ruckig) and thetask composer
A Python layer adds a planning API, constraints written in Python for the
online SQP solver (trajopt_ifopt.python_constraints)
A browser viewer and controller program emitters (ABB RAPID, KUKA KRL, Fanuc TP, Yaskawa INFORM, Universal Robots URScript).
Over 4,300 tests run against every wheel CI builds.
Installation
pip install --pre "tesseract-robotics-nanobind[support]"
--pre selects the current release candidate, 0.36.0.0rc1; drop it once 0.36.0.0 is final. The [support] extra adds tesseract's example robots and meshes (tesseract-robotics-nanobind-support), which the examples and the Quick Start load. Leave it out if you only use your own robots.
One cp312-abi3 wheel per platform covers Python 3.12 to 3.15:
- Linux: x86_64 and aarch64,
manylinux_2_39(Ubuntu 24.04+, Debian 13+) - macOS: arm64 and x86_64, macOS 15.0 or later
- Windows: x86_64
Examples
Recorded examples play in the browser, inline on the documentation pages. Orbit, scrub and change speed without installing anything.
- Planning: car seat, pick and place, raster, Cartesian, freespace and a 9-DOF toolpath
- Online planning: replanning around a moving obstacle
- Python constraints: constraints written in Python, solved in a live loop
- Basics, collision and geometry: scene graphs, point clouds, signed distance fields and shapes
The source is in src/tesseract_robotics/examples. Each example installs as a console script, such as tesseract_car_seat_example.
Quick Start
Plan a motion for the ABB IRB 2400 and play it in the browser:
from tesseract_robotics import get_tesseract_resource_path
from tesseract_robotics.common import GeneralResourceLocator
from tesseract_robotics.planning import (
    CartesianTarget, JointTarget, MotionProgram, Pose, Robot, plan_freespace,
)
from tesseract_robotics.viewer import TesseractViewer

locator = GeneralResourceLocator(paths=[get_tesseract_resource_path()])
robot = Robot.from_tesseract_support("abb_irb2400", locator)

# All-zero joints (rad) to a tool-down pose of tool0 in base_link: metres, [qx, qy, qz, qw]
program = (
    MotionProgram("manipulator", tcp_frame="tool0", working_frame="base_link")
    .move_to(JointTarget([0.0] * 6))
    .move_to(CartesianTarget(Pose.from_xyz_quat(0.8, -0.2, 0.8, 0.0, -1.0, 0.0, 0.0)))
)
result = plan_freespace(robot, program)
assert result.successful, result.message

with TesseractViewer() as viewer:
    viewer.update_environment(robot.env)
    viewer.update_trajectory(result.raw_results)
    input(f"{len(result.trajectory)} states, {result.trajectory[-1].time:.2f} s: open {viewer.url}, Enter quits")
plan_freespace runs the TrajOptPipeline: TrajOpt, a discrete collision check of every state, and time parameterization. The quickstart goes on to kinematics, collision checks and the other planners.
Documentation
The documentation has the concepts, user guide, API reference and breaking changes; its sources are in docs/.
Versioning
Version follows 0.A.B.C: A.B is the Tesseract series the bindings wrap and C is the nanobind patch number; a pre-release appends rcN. Releases up to 0.35.0.x wrap a tagged Tesseract release. The 0.36 series builds tesseract, trajopt and tesseract_planning from upstream master plus the open upstream pull requests we carry (tesseract_robotics.build_identity.UPSTREAM_SOURCES lists the exact commits), until the 0.36 tags exist upstream.
See CHANGELOG.md for release notes.
Development
Setup, tasks, tests and wheel builds are in the developer guide.
Acknowledgments
This project builds upon the excellent work of John Wason and the Tesseract Robotics team. The original tesseract_python SWIG bindings laid the foundation for this nanobind implementation.
License
Apache 2.0. Attribution notices are in NOTICE.
1 maintainer

Metadata
1 maintainer
Release files for tesseract-robotics-nanobind 0.36.0.0rc1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Built distributions (wheels)
Total release size: 120.4 MB
Release files / tesseract_robotics_nanobind-0.36.0.0rc1-cp312-abi3-win_amd64.whl
| Download URL | tesseract_robotics_nanobind-0.36.0.0rc1-cp312-abi3-win_amd64.whl |
|---|---|
| Size | 20.8 MB |
| Tags | CPython 3.12 Windows x86-64 abi3 |
|
SHA-256 checksum How to use checksums |
5fee2c5086bfacf26176ce7270d4352b8e535d50a756f68df1756cf03cafb921
|
|
BLAKE2b-256 checksum How to use checksums |
f564ffb62d2fbbd9d07524eb80555f4e5c37e1c95b43e47ffe78bbc8068d4b1b
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Nov 16, 2026.
Transparency logRelease files / tesseract_robotics_nanobind-0.36.0.0rc1-cp312-abi3-manylinux_2_39_x86_64.whl
| Download URL | tesseract_robotics_nanobind-0.36.0.0rc1-cp312-abi3-manylinux_2_39_x86_64.whl |
|---|---|
| Size | 29.7 MB |
| Tags | CPython 3.12 Linux glibc 2.39+ x86-64 abi3 |
|
SHA-256 checksum How to use checksums |
f5d446f42d3c118444b750e1bf703a1e5ca376f915f2106bb70cf3b4574f0165
|
|
BLAKE2b-256 checksum How to use checksums |
ce655e7e7a48e3750098ecf97cb32dbb58ea6a7ce90fc7a075be10a21ba98937
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Nov 16, 2026.
Transparency logRelease files / tesseract_robotics_nanobind-0.36.0.0rc1-cp312-abi3-manylinux_2_39_aarch64.whl
| Download URL | tesseract_robotics_nanobind-0.36.0.0rc1-cp312-abi3-manylinux_2_39_aarch64.whl |
|---|---|
| Size | 28.2 MB |
| Tags | CPython 3.12 Linux glibc 2.39+ ARM64 abi3 |
|
SHA-256 checksum How to use checksums |
f6c8ed7b4cbfff66e9f8c1421d5db7640ce7e66df9bc1a3cd8ddc26591531142
|
|
BLAKE2b-256 checksum How to use checksums |
f0eeaa663dd652e8326baf506d7a0cd9e900a5f9072c52b7c9db0789682adb39
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Nov 16, 2026.
Transparency logRelease files / tesseract_robotics_nanobind-0.36.0.0rc1-cp312-abi3-macosx_15_0_x86_64.whl
| Download URL | tesseract_robotics_nanobind-0.36.0.0rc1-cp312-abi3-macosx_15_0_x86_64.whl |
|---|---|
| Size | 22.4 MB |
| Tags | CPython 3.12 abi3 macOS 15.0+ x86-64 |
|
SHA-256 checksum How to use checksums |
132edf27c2eadc9db84241b2008c086b90f046d699c9824b53086cd9eebae446
|
|
BLAKE2b-256 checksum How to use checksums |
f6d455ef09112c1f99136699a74f864da092b3b7070e4d40b2a27b707228e76f
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Nov 16, 2026.
Transparency logRelease files / tesseract_robotics_nanobind-0.36.0.0rc1-cp312-abi3-macosx_15_0_arm64.whl
| Download URL | tesseract_robotics_nanobind-0.36.0.0rc1-cp312-abi3-macosx_15_0_arm64.whl |
|---|---|
| Size | 19.2 MB |
| Tags | CPython 3.12 abi3 macOS 15.0+ ARM64 |
|
SHA-256 checksum How to use checksums |
beff0efe90054991d0305d4da90f13b2c678228fa9d127ef72abc7f00f5d0e01
|
|
BLAKE2b-256 checksum How to use checksums |
b0e3afce9ab3b4b48c301debf84881b45a3ee93e67a0149d77021d8da4c4ff58
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Nov 16, 2026.
Transparency logSecurity for tesseract-robotics-nanobind 0.36.0.0rc1
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
Full provenance
All 5 files in this release have been uploaded with provenance metadata.
Attestation for tesseract_robotics_nanobind-0.36.0.0rc1-cp312-abi3-win_amd64.whl
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Nov 16, 2026.
Transparency logA note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














