
Trajectopy - Trajectory Evaluation in Python


Trajectopy is a Python package with an optional graphical user interface for empirical trajectory evaluation.
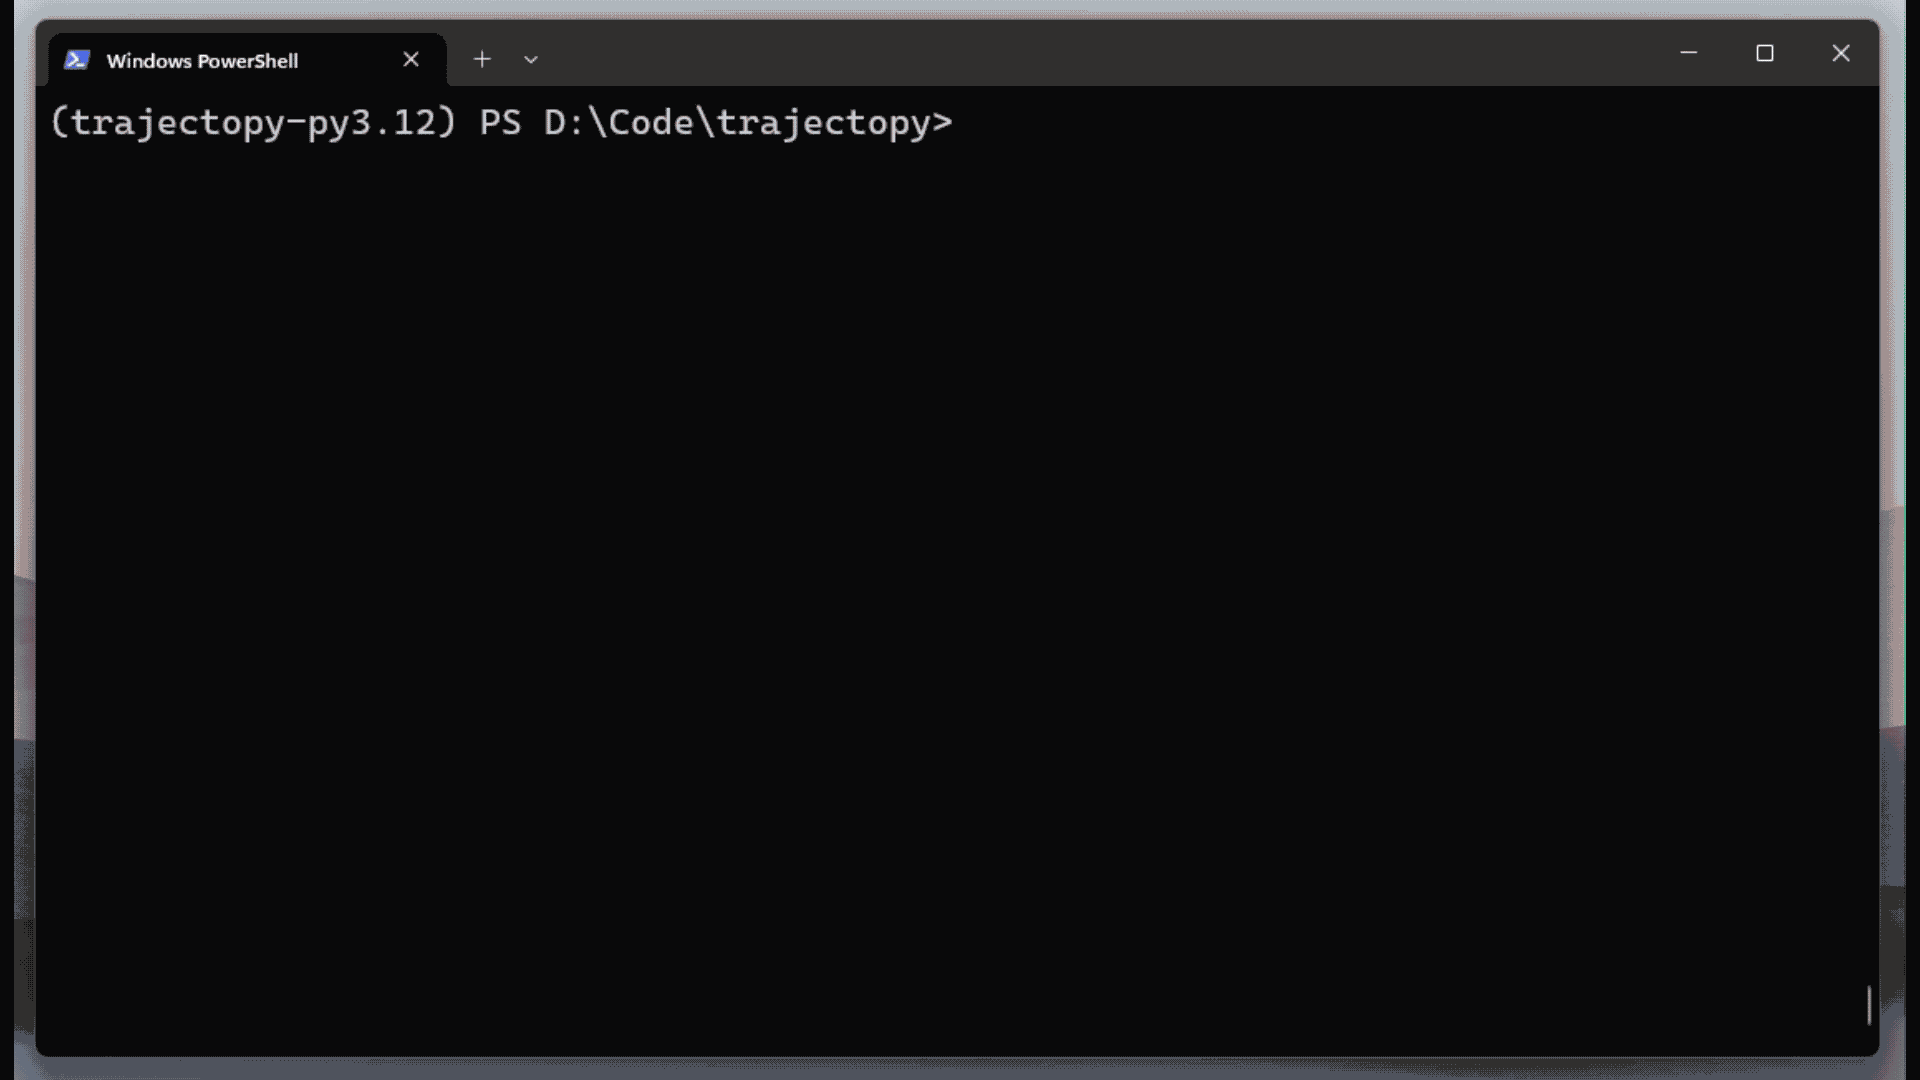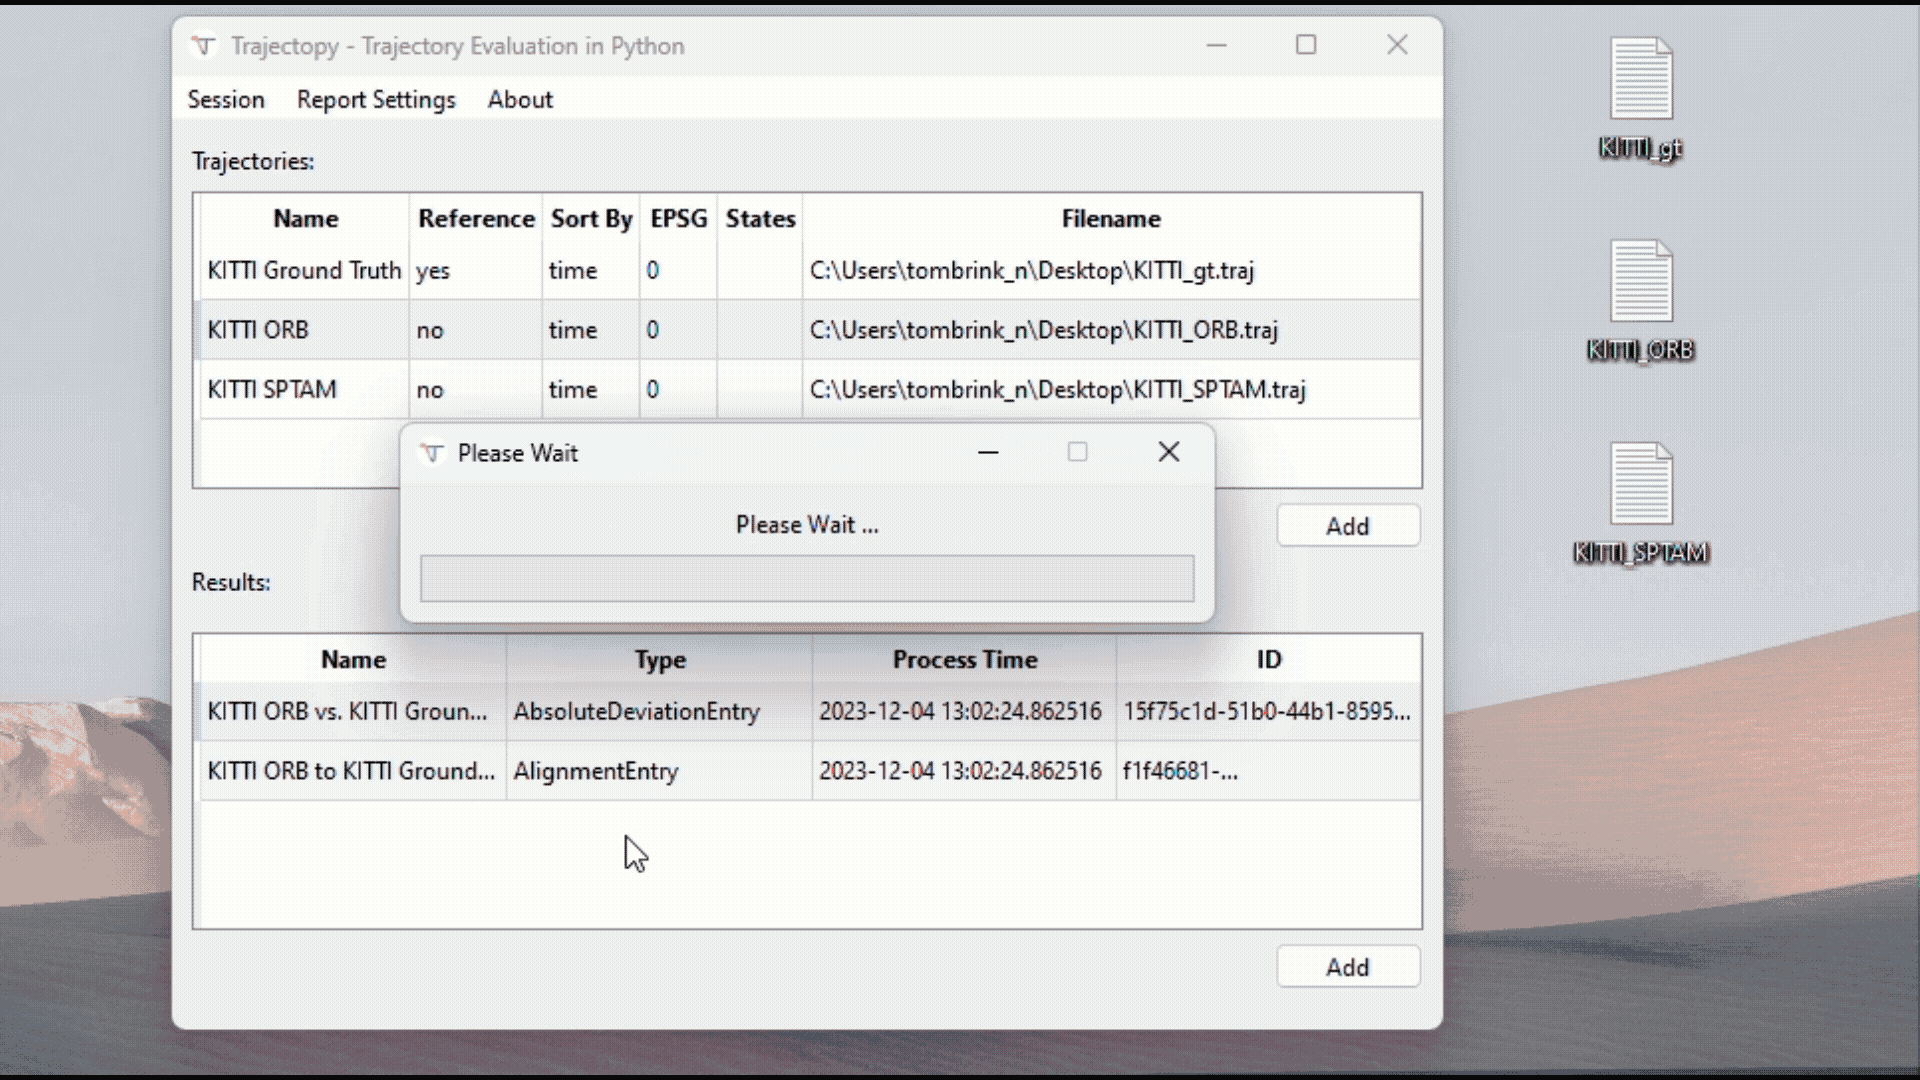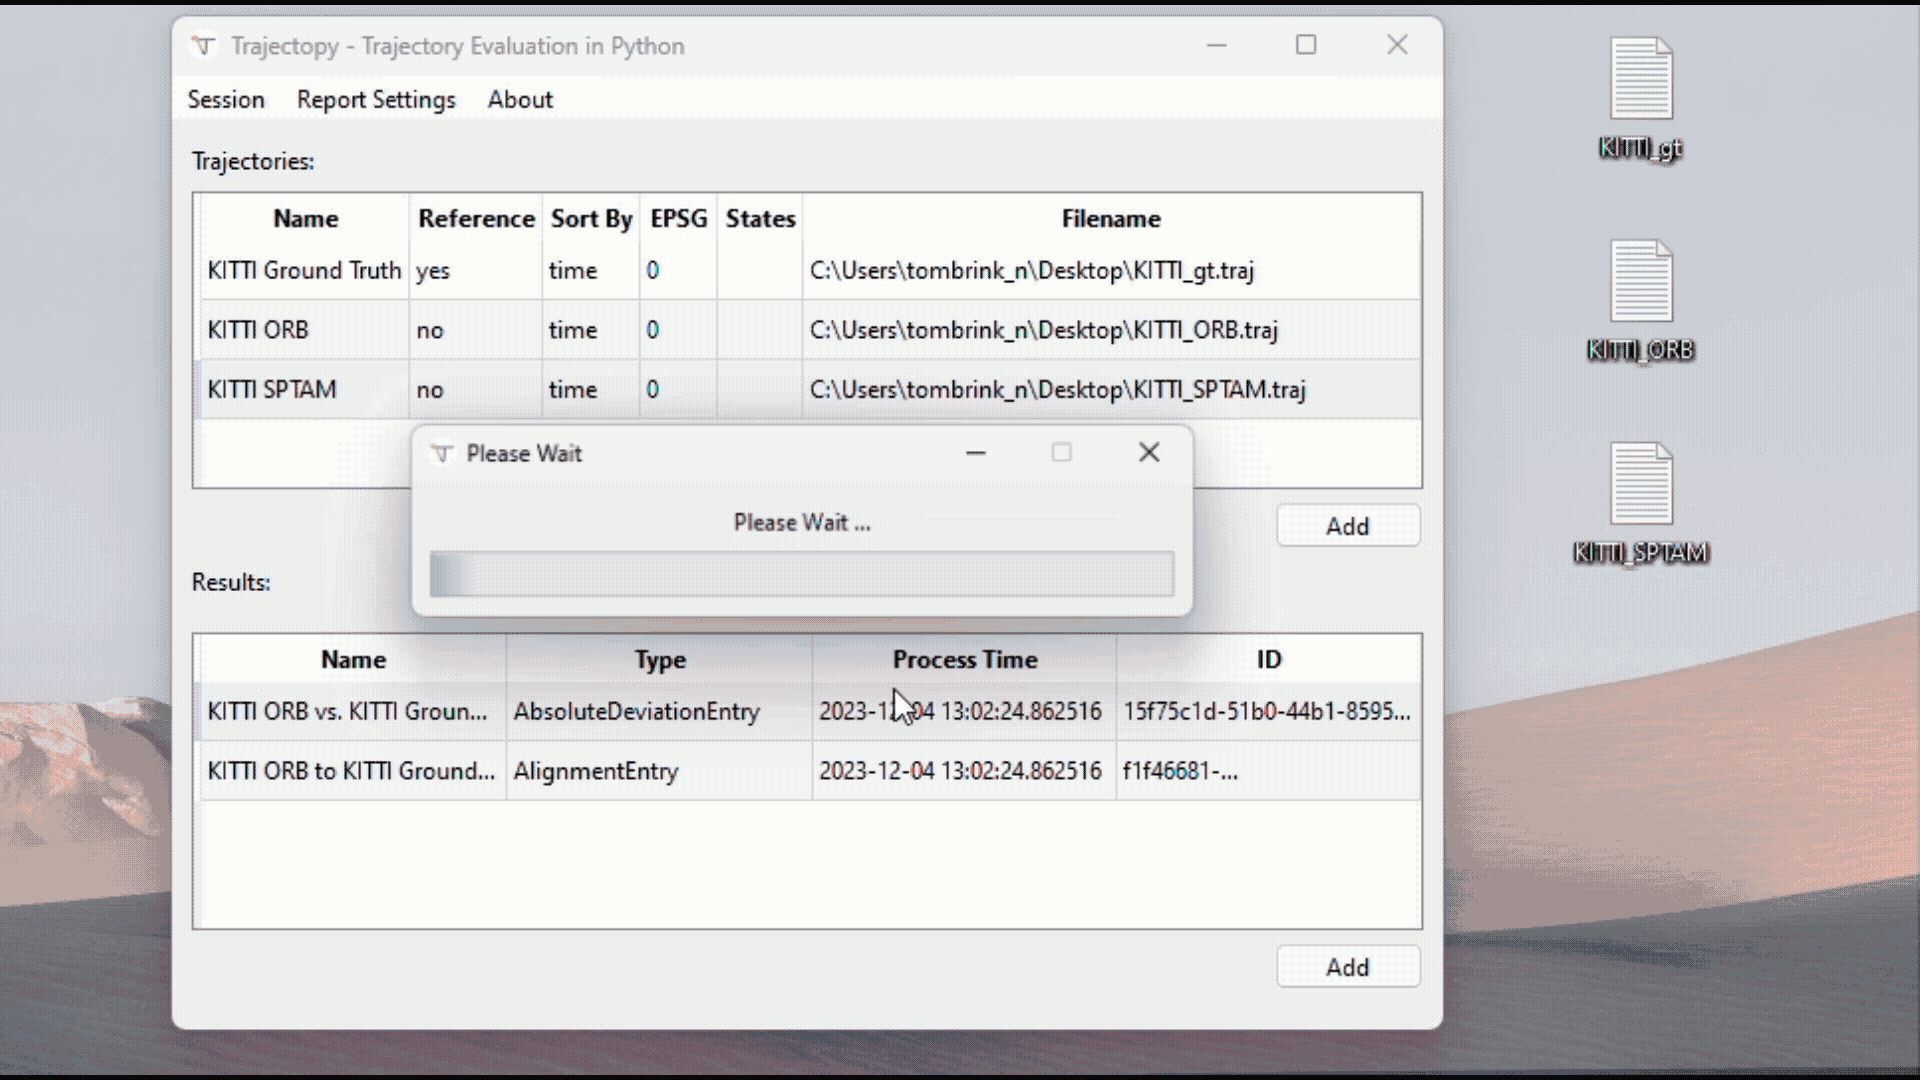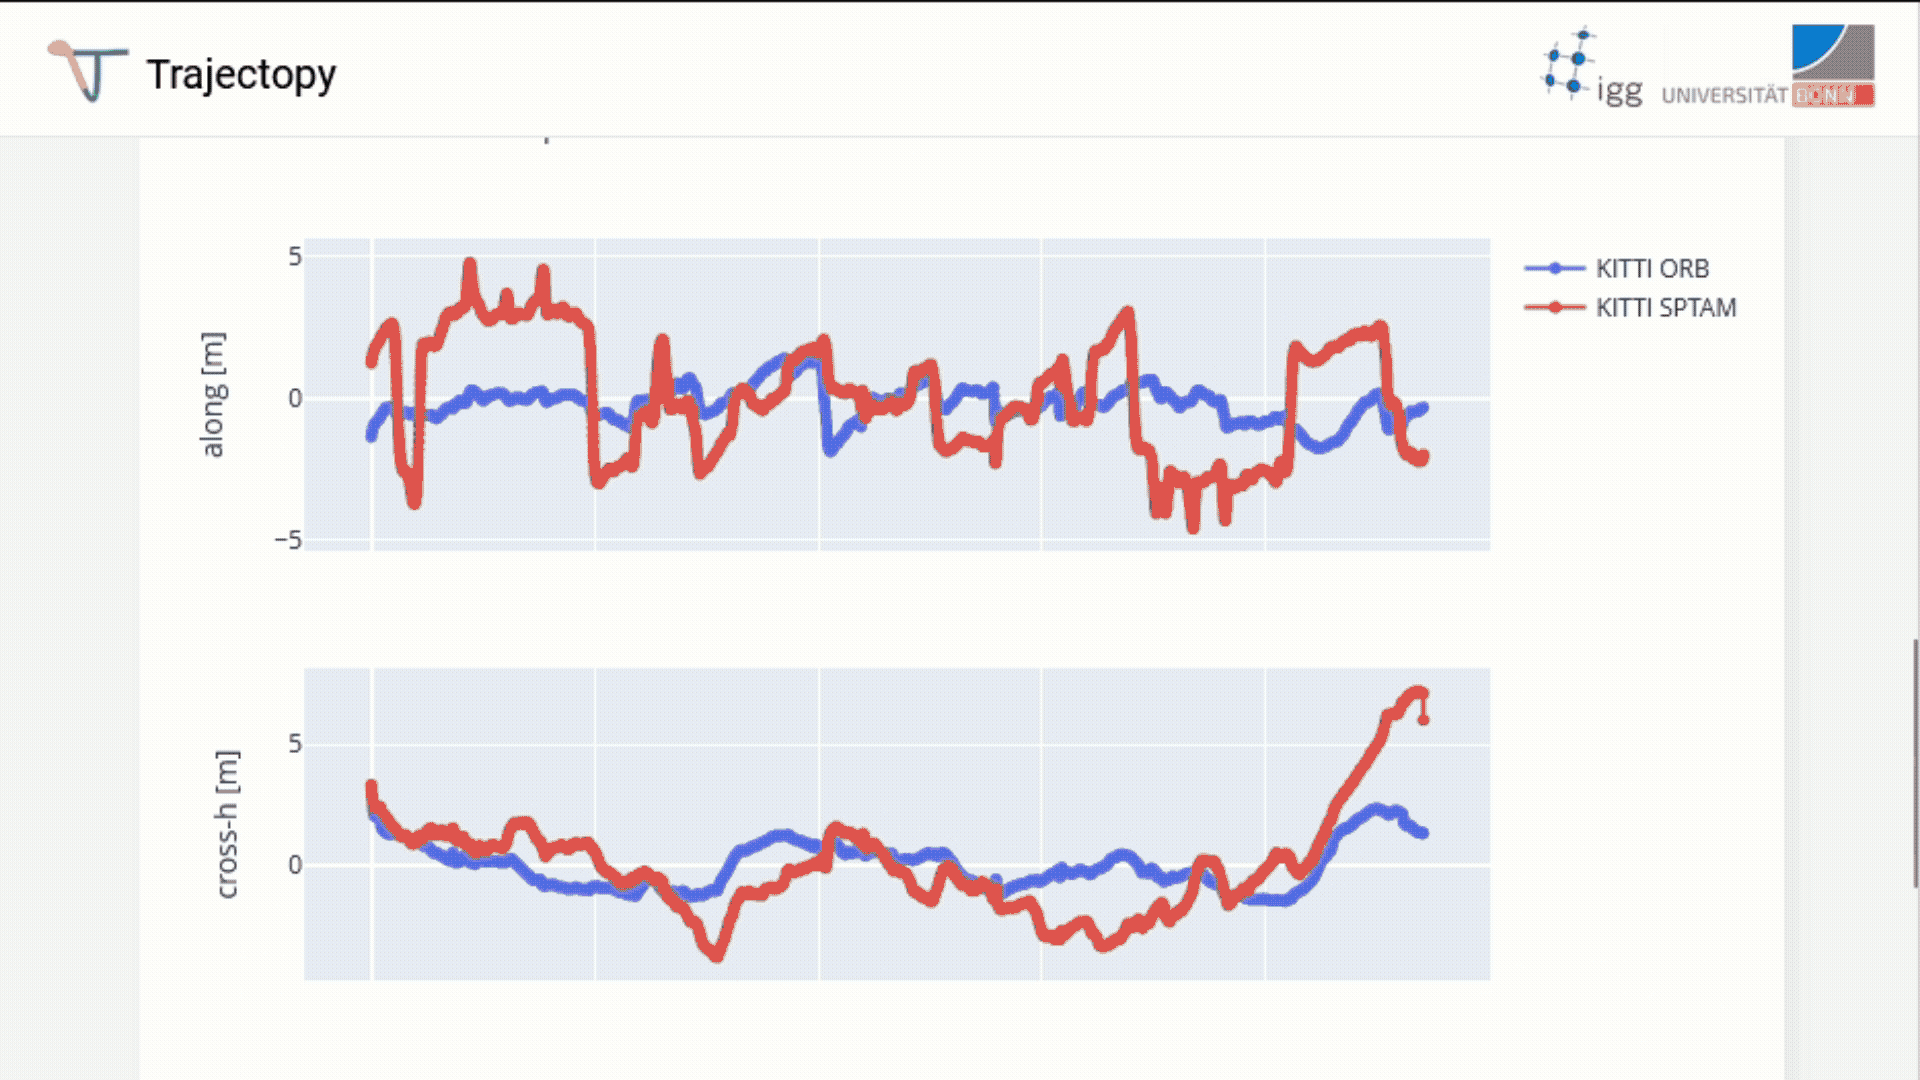
Using Mapbox, you can visualize your trajectories on a map:

Installation
Full version (with GUI):
pip install "trajectopy[gui]"
Python package only:
pip install trajectopy
Documentation
https://gereon-t.github.io/trajectopy/
Key Features
Trajectopy offers a range of features, including:
- Interactive GUI: A user-friendly interface that enables seamless interaction with your trajectory data, making it easy to visualize, align, and compare trajectories.
- Alignment: An advanced trajectory alignment algorithm that can be tailored to the specific application and supports a similarity transformation, a leverarm and a time shift estimation.
- Comparison: Absolute and relative trajectory comparison metrics (ATE and RPE) that can be computed using various pose-matching methods.
- Data Import/Export: Support for importing and exporting data, ensuring compatibility with your existing workflows.
- Customizable Visualization: Powered by Plotly or Matplotlib, trajectopy offers a range of interactive plots that can be customized to your needs. (Demo)
Web Application (Docker)
A simple web application is available at gereon-t/trajectopy-web that allows you to use the core functionality of Trajectopy using Docker.
Citation
If you use this library for any academic work, please cite our original paper.
@article{Tombrink2024,
url = {https://doi.org/10.1515/jag-2024-0040},
title = {Spatio-temporal trajectory alignment for trajectory evaluation},
author = {Gereon Tombrink and Ansgar Dreier and Lasse Klingbeil and Heiner Kuhlmann},
journal = {Journal of Applied Geodesy},
doi = {doi:10.1515/jag-2024-0040},
year = {2024},
codeurl = {https://github.com/gereon-t/trajectopy},
}
1 maintainer

Metadata
1 maintainer
Release files for trajectopy 4.4.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| trajectopy-4.4.0.tar.gz | 3.1 MB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| trajectopy-4.4.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 3.6 MB
Release files / trajectopy-4.4.0.tar.gz
| Download URL | trajectopy-4.4.0.tar.gz |
|---|---|
| Size | 3.1 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
1ceccc45437e4b3cbbe1026e0a1035acb74c1f92e88d8c7bb3c293a6455ab180
|
|
BLAKE2b-256 checksum How to use checksums |
fede8f6e49f20503abac87e7df7c863a160ec75c2998501e0547b3316b7e03db
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
uv/0.11.6 {"installer":{"name":"uv","version":"0.11.6","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":null,"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":null}
|
Release files / trajectopy-4.4.0-py3-none-any.whl
| Download URL | trajectopy-4.4.0-py3-none-any.whl |
|---|---|
| Size | 437.6 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
ade5c62cb1b5575b2050e809d20a4c54b859c6bb6b63508a9ed9d5a6f97a167e
|
|
BLAKE2b-256 checksum How to use checksums |
4865a4d63151e6cb4f5fc7e68e8374d5dbb93b4a68ca6ea9b9c32ff4c02f3d3d
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
uv/0.11.6 {"installer":{"name":"uv","version":"0.11.6","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":null,"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":null}
|














