
TwinOps
GitOps control plane for industrial digital twins (OpenUSD + Omniverse).



Evidence: docs/EVIDENCE.md
Install
pip install twinops

TwinOps lifecycle — Desired PLM/Git → Rendered OpenUSD → Observed telemetry → Drift → Reconcile → SYNCED
(MP4 for smoother local playback)
Case study: TwinOps Control Plane · Andrey Lesnikov
What it does
- Reconciles PLM metadata, OpenUSD scene composition, and live telemetry into a versioned digital-twin runtime
- Runs a Kubernetes operator over
DigitalTwinCRs with immutable output revisions (ConfigMap / OCI / S3) - Detects three-way drift (desired vs rendered vs observed) and drives reconcile toward SYNCED
Why
- Digital-twin pipelines need GitOps-style desired state, not one-off scene exports
- Operators need observable drift and deterministic builds without treating Omniverse Kit as mandatory
Quickstart
make install
make live-demo
make live-demo-smoke
Architecture
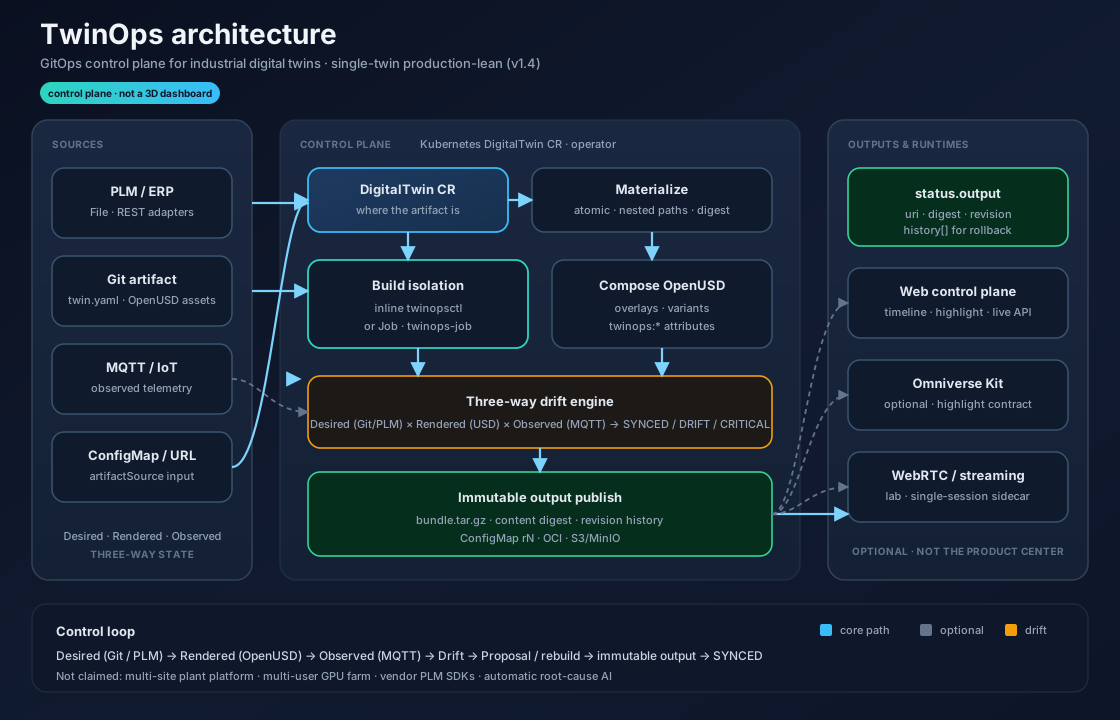
Control plane first: materialize → compose (inline or Job) → three-way drift → immutable output revisions. Kit / WebRTC are optional runtimes.
flowchart LR
  subgraph Sources
    PLM[PLM / ERP]
    Git[Git twin.yaml + USD]
    MQTT[MQTT / IoT]
  end

  subgraph ControlPlane["Control plane (the product)"]
    CR[DigitalTwin CR]
    Mat[Materialize + digest]
    Build["Build: inline | Job"]
    USD[OpenUSD compose]
    Drift[Three-way drift]
    Out[Immutable publish]
  end

  subgraph Durable
    CM["ConfigMap rN"]
    OCI[OCI registry]
    S3[S3 / MinIO]
  end

  subgraph Optional["Optional runtimes"]
    Web[Web UI / live API]
    Kit[Omniverse Kit]
    RTC[WebRTC sidecar]
  end

  PLM --> Git
  Git --> CR
  CR --> Mat --> Build --> USD --> Drift --> Out
  MQTT --> Drift
  Out --> CM
  Out --> OCI
  Out --> S3
  Drift --> Web
  Out --> Kit
  Out --> RTC
Full one-pager: docs/architecture-one-pager.md · operator: docs/operator.md · release: docs/release-1.4.md
Why this exists
Most Omniverse demos show a beautiful 3D scene.
Most Kubernetes demos show Helm, Terraform, and autoscaling.
TwinOps is not “Omniverse in Kubernetes” and not “USD files + Grafana”. It is a control plane: reconcile desired PLM / rendered OpenUSD / observed telemetry into GitOps artifacts, then drive optional runtimes (Kit, web UI, lab WebRTC) through a stable highlight contract — including on a laptop without a GPU.
TwinOps connects both worlds:
| DevOps | TwinOps |
|---|---|
| Kubernetes manifest | DigitalTwin manifest |
| container image | USD asset |
| configuration overlay | USD layer |
| environment | scene variant |
| GitOps reconciliation | stage composition |
| deployment rollout | twin revision rollout |
| runtime metrics | telemetry and scene state |
| drift detection | PLM / scene / IoT drift |
| rollback | previous USD composition |
The distinctive feature is three-way drift detection (see diagram above):
| Plane | Source | Role |
|---|---|---|
| Desired | Git + PLM mappings | Engineering intent |
| Rendered | Composed OpenUSD | What the twin scene encodes |
| Observed | MQTT / IoT | Live factory signal |
Frozen contracts: docs/stability.md.
2-minute live demo
No GPU required.
git clone https://github.com/justrunme/twinops-control-plane.git
cd twinops-control-plane
make install
make live-demo
1. Trigger heat spike      → CRITICAL / DRIFT + scene highlight
2. Apply reconciliation    → USD overlay + healed telemetry
3. Twin returns to SYNCED  → timeline + mock Kit viewport calm
Smoke check without a browser:
make live-demo-smoke
Canonical productization scenario (persist + replay + artifacts):
make e2e-demo
make streaming-sidecar-smoke
Full walkthrough: docs/demo.md · docs/e2e-demo.md · docs/streaming-sidecar.md
Demo
Terminal capture of the CI end-to-end flow (scripts/e2e_demo.sh): heat spike → CRITICAL → reconcile → SYNCED → incident replay.
Offline self-healing compose demo:
make demo
Live UI demo: docs/demo.md · E2E walkthrough: docs/e2e-demo.md
Results
Measured numbers from CI (not estimates). Full table: docs/results.md · machine-readable: docs/results.json.
| Metric | Value | Source run |
|---|---|---|
| Smoke: spike → SYNCED | 0.43 s | 38066458460 (Python 3.12) |
| E2E: spike → replay → persistence | 1.90 s | same run |
| Reconcile changes to SYNCED | 3 | same run (reconcile.json) |
| Incident replay verified | true (stepsPlayed=6) |
same run (replay-verify.json) |
Quickstart extras
Offline CLI demo
make demo
Produces composed USDA layers, a drift HTML report, and a GitOps reconciliation proposal.
MQTT publish + ingest
make mqtt-smoke
twinopsctl mqtt topics
Starts Mosquitto, publishes simulator telemetry, injects an external PLC heat spike, and asserts CRITICAL drift.
Topic catalog: examples/assembly-line/mqtt-topics.json / GET /api/mqtt/topics.
Mock PLM adapter
twinopsctl plm show
twinopsctl plm get 1004711 --catalog examples/assembly-line/plm-catalog.json
twinopsctl plm compare
See docs/plm-adapter.md.
Omniverse highlight contract (no GPU)
make serve
# other terminal:
make scene-live      # fetch + validate /api/scene
make scene-highlight # Kit stub client
make scene           # offline JSON + HTML highlight report
See docs/omniverse.md.
Local DX probes
make doctor
make live-status
make timeline
twinopsctl proposal
twinopsctl live spike
twinopsctl live reconcile
twinopsctl incident export --from-url http://127.0.0.1:8080 --out /tmp/incident.json
twinopsctl incident replay examples/assembly-line/incident-heat-spike.json \
  --desired examples/assembly-line/desired.yaml \
  --stage examples/assembly-line/generated/root.usda \
  --observed examples/assembly-line/telemetry.json --json
make scene-live
twinopsctl openapi --out /tmp/twinops-openapi.json
make verify-all
Docs index: docs/README.md. Security: SECURITY.md.
Dev UI (Vite hot reload)
make serve      # terminal 1 — API :8080
make web-dev    # terminal 2 — UI  :5173
Kubernetes operator
make operator-demo              # out-of-cluster manager (k3d/kind)
make operator-incluster-e2e     # docker build → kind load → Helm → restart recovery
make operator-demo-cleanup
In-cluster path publishes a durable bundle.tar.gz on the twin (status.output.uri).
See docs/operator.md, docs/images.md.
Tests
make test
make go-test
make verify-all
See CONTRIBUTING.md.
Two documents, two roles
TwinOps uses the same apiVersion family for two different documents. Do not mix them up.
1) Twin manifest (compiler input — lives inside the artifact)
Stored as twin.yaml in a ConfigMap / tarball. Consumed by twinopsctl build.
# twin.yaml — what to compose (OpenUSD + PLM + telemetry mappings)
apiVersion: twinops.io/v1alpha1
kind: TwinManifest   # conceptual name; file may say DigitalTwin historically
metadata:
  name: assembly-line-a
spec:
  source:
    baseStage: assets/root.usda   # nested paths preserved in URL/tar artifacts
  configuration:
    variant: high-throughput
  telemetry:
    provider: mqtt
    endpoint: mqtt://factory-broker
    mappings:
      - topic: factory/robot-01/temperature
        prim: /World/Factory/LineA/Robot01
        attribute: twinops:temperature
  plm:
    provider: mock
    mappings:
      - itemId: "1004711"
        revision: "C"
        prim: /World/Factory/LineA/Robot01
2) DigitalTwin CR (Kubernetes — tells the operator where the artifact is)
# DigitalTwin CR — operator control loop, not the scene itself
apiVersion: twinops.io/v1alpha1
kind: DigitalTwin
metadata:
  name: assembly-line-a
  namespace: twinops-system
spec:
  artifactSource:
    configMapName: assembly-line-inputs   # or url: https://…/bundle.tar.gz
    # expectedDigest: sha256:…
  intervalSeconds: 30
  # outputPublish.enabled defaults true → status.output.uri = configmap://…/assembly-line-a-output
The compiler turns the manifest into OpenUSD overlay layers with twinops:* attributes.
The CR drives materialize → build → drift → durable bundle.tar.gz publish.
Repository layout
twinops-control-plane/
├── python/twinops/          # Compiler, drift, live API, PLM mock, CLI
├── examples/assembly-line/  # Demo factory line + sample USDA + PLM/MQTT catalogs
├── scripts/                 # live-demo / mqtt-smoke / operator-demo / sync helpers
├── docs/                    # Architecture, USD model, ADRs, roadmap
├── api/                     # DigitalTwin CRD types (Go)
├── controllers/             # Kubernetes operator controllers
├── cmd/manager/             # Operator manager entrypoint
├── deploy/helm/             # Helm chart for the operator
├── Dockerfile.live          # Demo live API + web UI image
├── Dockerfile.operator      # Operator manager image
├── extensions/              # Omniverse Kit highlight stub
└── web/                     # Live control-plane UI + mock Kit viewport
Compiler, drift engine, operator, GitOps, observability, and mock adapters run without an NVIDIA GPU. A GPU is required only for Kit rendering and the host NVENC streaming bridge.
Demo story: Self-Healing Production Line
Robot → Conveyor → Scanner → Packaging
- Change desired robot revision in Git
- TwinOps compiles a new USD overlay layer
- Drift engine compares desired / rendered / observed state
- Scene metadata highlights revision or telemetry drift
- A reconciliation proposal restores the desired composition
Milestones 1–2 deliver composition, drift detection, HTML report, and a reconciliation proposal. The Kubernetes operator reconciles DigitalTwin CRs via twinopsctl.
Roadmap (summary)
| Track | Focus | Status |
|---|---|---|
| 0–5 | Compiler, drift, live API, web demo | done |
| Operator | CRD, Helm, durable ConfigMap/OCI/S3 output, Job isolation, in-cluster E2E | done (1.4.3) |
| Kit / media | Highlight contract, lab WebRTC, single-session NVENC ingest | lab / optional |
| Next | Multi-site fleet, large non-ConfigMap Job inputs | not claimed |
See full docs/roadmap.md and docs/architecture.md.
What we will not claim yet
Honest positioning: single-twin pilot / reference control plane, not a plant platform.
This project does not claim:
- multi-site / multi-tenant enterprise readiness
- NVCF or production Omniverse App Streaming
- vendor-specific PLM product SDKs (generic File/REST adapters only)
- multi-user GPU streaming farm
PLM integration ships as mock + File/REST adapters.
Author
Andrey Lesnikov — Senior DevOps & AI Platform Engineer
ORCID: https://orcid.org/0009-0004-7583-4314
License
Apache License 2.0 — see LICENSE.
1 maintainer

Metadata
1 maintainer
Release files for twinops 1.5.1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| twinops-1.5.1.tar.gz | 132.4 kB | With provenance | Details for twinops-1.5.1.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| twinops-1.5.1-py3-none-any.whl | Python 3 | none | any | Details for twinops-1.5.1-py3-none-any.whl |
Total release size: 262.1 kB
Release files / twinops-1.5.1.tar.gz
| Download URL | twinops-1.5.1.tar.gz |
|---|---|
| Size | 132.4 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
c85c098186d2a34ca7d731d2e2d6bfe4c2c5fe44fcd9781b6391342a7017daa0
|
|
BLAKE2b-256 checksum How to use checksums |
4c9290889a9807bbab8f7f12f500414c7bbd0bf045f96d4272530391a1b3070e
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Nov 22, 2026.
Transparency logRelease files / twinops-1.5.1-py3-none-any.whl
| Download URL | twinops-1.5.1-py3-none-any.whl |
|---|---|
| Size | 129.7 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
71db6c31e0b8d93d02587f2285d34ef1e4374d459836181edeccc7c7951067e8
|
|
BLAKE2b-256 checksum How to use checksums |
61c840f20a86304618b5ab7801f0175e4e197fdfe8d992a1c472b3475cf177c8
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Nov 22, 2026.
Transparency logSecurity for twinops 1.5.1
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
Full provenance
Both files in this release have been uploaded with provenance metadata.
Attestation for twinops-1.5.1.tar.gz
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Nov 22, 2026.
Transparency logA note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.













