
UrbanMARL: Vectorized Urban Multi-Agent Reinforcement Learning



UrbanMARL is a high-performance, GPU-vectorized, data-driven multi-agent reinforcement learning (MARL) framework and digital twin simulator tailored for 6G geospatial radio environments, Unmanned Aerial Vehicles (UAVs), Mobile Edge Computing (MEC) networks, and other emerging applications.
UrbanMARL is built natively on TorchRL, PyTorch, TensorDict, and BenchMARL, vectorizes 3D spatial ray-casting of Line-of-Sight (LoS) paths, ITU-R P.1410 urban map procedural generation, mmWave radio propagation, and M/M/c queuing dynamics across hundreds of concurrent environments.
UrbanMARL is developed to extend the PhD research project titled "Three-Dimensional Mobility for Multi-UAV Assisted Multi-Access Edge Computing" conducted by Dr. Basheer Raddwan under the supervision of Prof. Ibrahim Al-Baltah, at the Department of Information Technology, Faculty of Computer and Information Technology, Sana’a University, Yemen, by refactoring the Panda5gSim project into a fully vectorized, data-driven, GPU-accelerated, and TorchRL-compatible MARL framework.
🎥 Video Overview
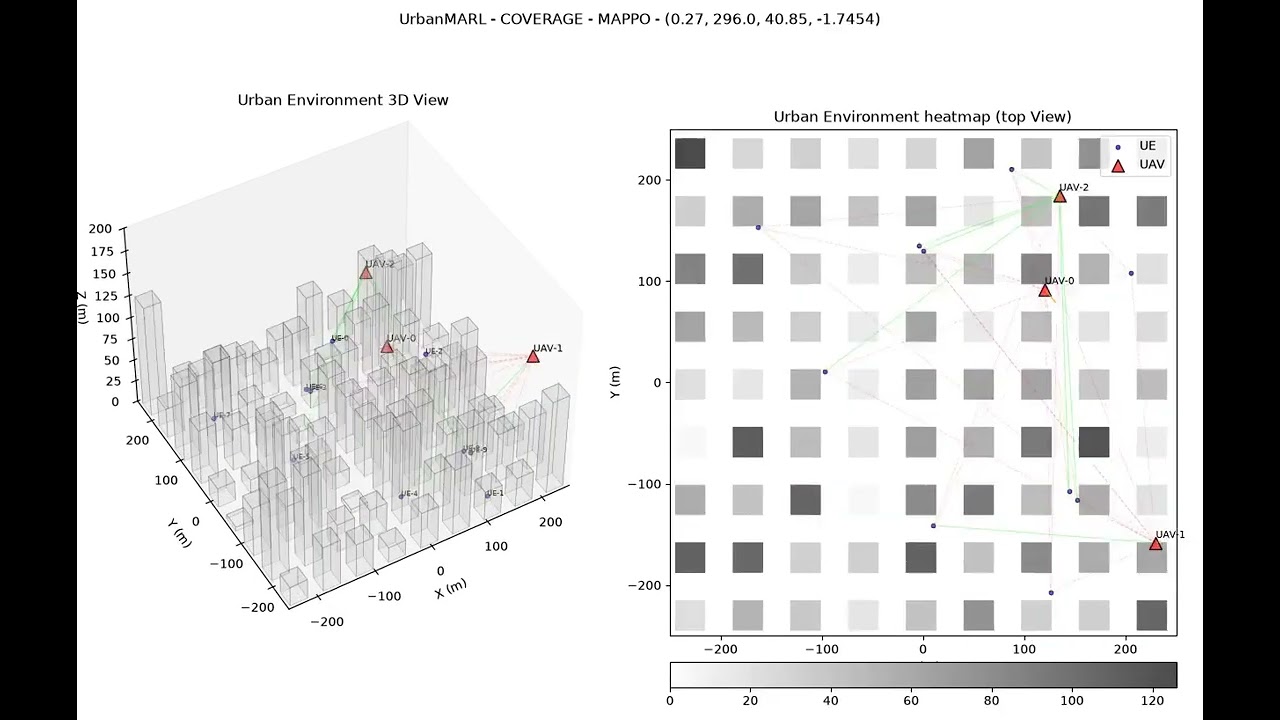
Rendering example of 3D and 2D geospatial and building heatmap during training of 6 MARL algorithms with 3 task scenarios; using 3 UAV-BS and 10 UE. Orange lines show UAV trajectories, green and red lines show LoS/NLoS conditions.
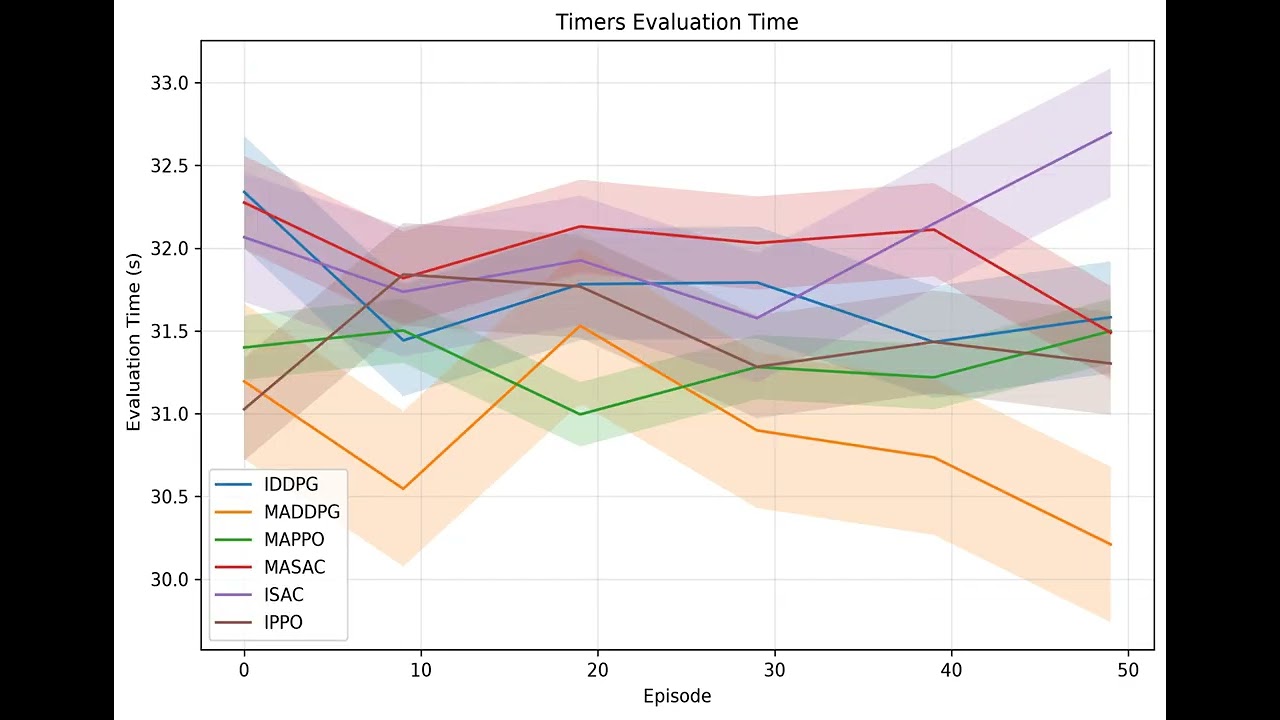
Example of analysis and result evaluation images rendered in a single video.
💡 Key Features
- ⚡ 100% Vectorized PyTorch Core: Batched 3D spatial movement, line-of-sight (LoS) calculations, building collision detection, radio propagation, and queuing systems run natively on GPU/CPU without python-loop bottlenecks.
- 🏢 ITU-R P.1410 3D Procedural Urban Maps: Realistic 3D urban environments parameterized by building coverage ($\alpha$), building density ($\beta$), height distribution ($\gamma$), street width, and building dimensions using Poisson Point Processes.
- 📡 Vectorized mmWave Radio Channel Model: Computes Friis path loss, LoS/NLoS attenuation exponent shifts, Signal-to-Interference-plus-Noise Ratio (SINR), and Shannon channel capacity for 29 GHz / 6G networks.
- 🖥️ Vectorized M/M/c MEC Queue Model: Pure PyTorch tensor implementation of M/M/c queuing theory calculating server utilization, average queue lengths, waiting times, and total response delay.
- 🤖 BenchMARL & TorchRL Native: Fully compatible with BenchMARL task APIs (
UrbanEnvTask). Supports SOTA MARL algorithms (MAPPO, MADDPG, MASAC, IPPO, IDDPG, ISAC, QMIX). - 🎬 3D Rendering & Analytics Suite: Includes interactive Matplotlib/MP4 3D trajectory rendering, CSV/TensorBoard logging, and evaluation plotters.
🎮 Scenarios Overview
UrbanMARL features a comprehensive suite of multi-agent urban scenarios covering navigation, wireless communications, edge computing, user mobility, and sensor perception:
| Scenario Key | Scenario Class | Primary Objective & Description | Action Space | Observation Space |
|---|---|---|---|---|
uav_navigation |
NavigationScenario |
Multi-UAV swarm 3D waypoint navigation and obstacle avoidance across procedural urban canyons. | Continuous velocity $(v_h, \phi, v_z)$ | UAV Position $(x,y,z)$ & Battery level |
uav_ue_los |
UavUeLosScenario |
Maintain dynamic unblocked Line-of-Sight (LoS) links to ground IoT users for aerial relay networks. | Continuous velocity $(v_h, \phi, v_z)$ | UAV Position $(x,y,z)$ & Battery level |
coverage |
CoverageScenario |
Maximize 3D geospatial mmWave coverage over ground users with inter-UAV separation safety constraints. | Continuous velocity $(v_h, \phi, v_z)$ | UAV Position $(x,y,z)$ & Battery level |
uavmec_offloading |
UAVMECScenario |
Joint UAV trajectory planning and M/M/c computation offloading under latency deadlines and sojourn time. | Continuous velocity $(v_h, \phi, v_z)$ | UAV Position, Battery, MEC Queue & LoS |
uav_mobile_ue |
UavMobileUeScenario |
Persistent aerial tracking of dynamic ground users moving under Gauss-Markov, Manhattan Grid, and Hotspot flocking models. | Continuous velocity $(v_h, \phi, v_z)$ | UAV Position, Battery, UE Pos & LoS |
uav_lidar_navigation |
UavLidarNavigationScenario |
POMDP safe urban navigation using batched 360° LiDAR ray-casting rangefinder beams and proximity margin penalties. | Continuous velocity $(v_h, \phi, v_z)$ | Target Vector, Velocity & 360° LiDAR Beams |
uavmec_advanced_physics |
UavMecAdvancedPhysicsScenario |
High-fidelity rotary-wing aerodynamic propulsion power dissipation (Zeng et al.), 3GPP 38.901 3D directional antennas, and multi-core MEC digital twin. | Continuous velocity $(v_h, \phi, v_z)$ | UAV Kinematics, Battery, Directional Rates & Queues |
default |
DefaultScenario |
Baseline urban MARL template for rapid prototyping and custom scenario development. In future updates, we will add more examples and scenarios. | Continuous velocity $(v_h, \phi, v_z)$ | UAV Position $(x,y,z)$ & Battery level |
🔬 Core Concepts & Theoretical Formulations
1. 3D Procedural Urban Maps (ITU-R P.1410)
Urban topographies are procedurally generated in parallel using statistical parameters defined by the International Telecommunication Union (ITU-R P.1410):
- Building Coverage Ratio ($\alpha$): Fraction of land area covered by buildings.
- Building Density ($\beta$): Average number of buildings per square kilometer.
- Rayleigh Height Scale ($\gamma$): Scale parameter governing building height distributions: $$f(h) = \frac{h}{\gamma^2} \exp\left(-\frac{h^2}{2\gamma^2}\right), \quad h \ge 0$$
2. Sojourn Time & Dynamic LoS Channels
Quantifies consecutive Line-of-Sight connection durations between aerial UAVs and moving ground users:
- LoS Ray-Casting: Efficient segment-to-heightmap checking in pure PyTorch tensors without ray-triangle intersections.
- Sojourn Bonus: Formulated by Dr. Raddwan (Ad Hoc Networks 2025, IEEE Access 2025) to encourage UAVs to maintain stable, persistent coverage over mobile ground clusters: $$R_{\text{sojourn}} = w_{\text{sojourn}} \cdot \tanh(0.1 \cdot \text{Sojourn Time})$$
3. Multi-Core MEC Queuing Theory (M/M/c)
Simulates edge computation queues on GPU:
- Each UAV hosts $c$ parallel CPU processing cores operating at clock frequency $f_{\text{uav}}$.
- Tasks arrive stochastically with payload size $D_k$ (bits) and computational density $X_k$ (CPU cycles/bit).
- Computes server utilization $\rho = \frac{\lambda}{c \mu}$, waiting time in queue $W_q$, and system sojourn delay $W_s = W_q + \frac{1}{\mu}$.
4. High-Fidelity Rotary-Wing Aerodynamic Power Model
Accurately models flight energy dissipation as a function of 3D velocity $\mathbf{V}$ (Zeng et al., IEEE TWC): $$P(V) = P_0 \left(1 + \frac{3 V^2}{U_{\text{tip}}^2}\right) + P_i \left(\sqrt{1 + \frac{V^4}{4 v_0^4}} - \frac{V^2}{2 v_0^2}\right)^{1/2} + \frac{1}{2} d_0 \rho s A V^3$$ where $P_0$ is blade profile power in hover, $P_i$ is induced power in hover, $U_{\text{tip}}$ is rotor tip speed, $v_0$ is mean rotor induced velocity, $d_0$ is fuselage drag ratio, and $s$ is rotor solidity.
5. 360° LiDAR Ray-Casting Rangefinder
Provides depth perception for urban canyon navigation under Partial Observability (POMDP):
- Casts $K$ radial rangefinder beams covering $360^\circ$ around each UAV.
- Detects obstacle proximity distances $d_k$ across building heightmaps.
- Applies proximity margin safety penalties $c_{\text{prox}} \cdot \max(0, d_{\text{safe}} - \min_k d_k)$ to prevent collisions before they happen.
6. Dynamic Scenario Auto-Registration
Scenarios located in urbanmarl/scenarios/ are automatically discovered and registered at runtime:
- No need to manually edit
__init__.pywhen creating new scenarios. - Any subclass of
UrbanScenariodefining aScenarioclass is immediately available viaload_scenario("my_scenario")orUrbanEnv(scenario="my_scenario").
⚙️ Installation
Prerequisites
- Python: $\ge 3.10$ tested on 3.12
- PyTorch: $\ge 2.12.0$ (CUDA recommended for large batch sizes)
Installation using uv (Recommended)
uv is an extremely fast Python package installer. UrbanMARL's configuration is optimized for uv, allowing it to automatically route PyTorch dependencies to the correct hardware-specific index without requiring manual URL flags.
First, ensure uv is installed on your system:
curl -LsSf https://astral.sh/uv/install.sh | sh
Once installed, the pyproject.toml is configured to enable uv detecting your available hardware (CPU, GPU). Just run the following commands to install UrbanMARL.
Clone the UrbanMARL repository:
git clone https://github.com/yemenlinux/vUrbanMARL.git

cd vUrbanMARL
Create Python virtual environment and activate it:
    uv venv --python 3.12

    source .venv/bin/activate
Option 1: Install from PyPi index:
uv pip install urbanmarl
Option 2: Install for development from the source:
uv pip install -e .[test,docs]
If you got a dependency conflict with benchmarl, install benchmarl from our compatible fork.
uv pip install urbanmarl https://github.com/yemenlinux/BenchMARL.git
More installation methods in the documents.
Documentation
Read documentation here.
🚀 Quick Start
1. Direct PyTorch / TorchRL Usage
You can instantiate and step through UrbanEnv directly using TorchRL semantics:
import torch
from urbanmarl.envs.base_env import UrbanEnv

# Initialize environment with 64 parallel batched environments on GPU/CPU
env = UrbanEnv(
    num_envs=64,
    scenario="uav_navigation",
    num_uavs=3,
    num_ues=50,
    device="cuda" if torch.cuda.is_available() else "cpu",
)

# Reset environment
tensordict = env.reset()
print("Initial Observation:", tensordict["agents", "observation"].shape)

# Sample action and step
actions = env.action_spec.sample()
tensordict.update(actions)
next_tensordict = env.step(tensordict)

print("Reward:", next_tensordict["next", "agents", "reward"].shape)
print("Done:", next_tensordict["next", "done"].shape)
2. Multi-UAV MEC Advanced Physics with 6G Digital Twin
Run the high-fidelity aerodynamic flight and multi-core MEC digital twin:
import torch
from urbanmarl.envs.base_env import UrbanEnv

# 32 parallel environments with high-fidelity aerodynamics and MEC queuing
env = UrbanEnv(
    num_envs=32,
    scenario="uavmec_advanced_physics",
    num_uavs=3,
    num_ues=10,
    frequency_ghz=29.0,
    device="cuda" if torch.cuda.is_available() else "cpu",
)

td = env.reset()
action = env.full_action_spec.rand()
td = env.step(td.update(action))

# Access real-time Network Digital Twin telemetry
print("Telemetry info:", td.get("info", {}))
# Render 3D environment frame with HUD overlay
frame = env.render(mode="rgb_array")
print("Rendered frame size:", frame.shape)
3. Dynamic Ground User Mobility Tracking
Simulate aerial UAV relays tracking moving ground users with Gauss-Markov or Manhattan Grid dynamics:
from urbanmarl.envs.base_env import UrbanEnv

env = UrbanEnv(
    num_envs=16,
    scenario="uav_mobile_ue",
    num_uavs=3,
    num_ues=20,
    mobility_model="gauss_markov",  # or "manhattan", "hotspot", "rwp"
)

td = env.reset()
for step in range(50):
    action = env.full_action_spec.rand()
    td = env.step(td.update(action))
4. Running MARL Benchmarks via BenchMARL
Train SOTA MARL algorithms (MAPPO, MADDPG, MASAC) on any UrbanMARL task:
from benchmarl.algorithms import MaddpgConfig
from benchmarl.environments import UrbanEnvTask
from benchmarl.experiment import Experiment, ExperimentConfig
from benchmarl.models.mlp import MlpConfig

task = UrbanEnvTask.UAVMEC_ADVANCED_PHYSICS.get_from_yaml()
experiment = Experiment(
    task=task,
    algorithm_config=MaddpgConfig.get_from_yaml(),
    model_config=MlpConfig.get_from_yaml(),
    critic_model_config=MlpConfig.get_from_yaml(),
    seed=0,
    config=ExperimentConfig.get_from_yaml(),
)
experiment.run()
5. Defining Custom Scenarios with Auto-Registration
Creating a new scenario requires zero configuration. Simply define a new file in urbanmarl/scenarios/ inheriting from UrbanScenario:
# urbanmarl/scenarios/my_custom_task.py
from urbanmarl.scenarios.base import UrbanScenario
import torch

class Scenario(UrbanScenario):
    """Custom research scenario."""
    def reset(self, env, tensordict=None, **kwargs):
        env.uav_agents_pos = env._env.gen_pos(num_pos=env.n_uavs, min_z=30.0, max_z=100.0, outdoor=True)
        # Initialize custom variables...

    def process_actions(self, env, tensordict):
        # Update flight dynamics...
        pass

    def reward(self, env, group):
        # Calculate custom research reward...
        return torch.zeros((env.batch_size[0], env.n_uavs, 1), device=env.device)
The new scenario is immediately recognized:
from urbanmarl.envs.base_env import UrbanEnv
env = UrbanEnv(scenario="my_custom_task", num_envs=4)
📊 Evaluation & Visualization
- Interactive Notebooks: Explore evaluate.ipynb and test_renderer.ipynb for plotting scalar metrics and rendering 3D UAV trajectories over procedurally generated building maps.
- Result Processing: Utilities in urbanmarl/eval_results.py format CSV/TensorBoard outputs into publication-ready figures.
📄 License
This project is released under the MIT License.
Affiliation and Sponsors
Department of Information Technology, Faculty of Computer and Information Technology, Sana’a University, Yemen.
✍️ Authors & Citation
Created by: Dr. Basheer Raddwan
Supervised by: Prof. Ibrahim Al-Baltah
If you use UrbanMARL in your research, please cite:
@inproceedings{raddwan_urbanmarl_2026,
location = {Sana'a, Yemen},
title = {{UrbanMARL}: A Vectorized Urban Simulator for Multi-Agent Reinforcement Learning},
url = {https://www.researchgate.net/doi/10.13140/RG.2.2.17864.69122},
booktitle = {1st International Conference on Intelligent, Dependable, Emerging, Autonomous, and Sustainable Engineering Technology ({IDEASET}2026)},
author = {{Raddwan, Basheer and Al-Baltah, Ibrahim and Zahary, Ammar and Alshamery, Anwar}},
date = {2026-12-01},
}
Related work
@article{RADDWAN2025104019,
title = {Quantify the joint effect of mobility and urban environment on computation offloading to multi-UAV MEC network: Sojourn time},
journal = {Ad Hoc Networks},
volume = {179},
pages = {104019},
year = {2025},
issn = {1570-8705},
doi = {https://doi.org/10.1016/j.adhoc.2025.104019},
url = {https://www.sciencedirect.com/science/article/pii/S1570870525002677},
author = {Raddwan, Basheer and Al-Baltah, Ibrahim}
}

@ARTICLE{11050367,
  author={Raddwan, Basheer and Al-Baltah, Ibrahim},
  journal={IEEE Access},
  title={Mobility-Aware Bivariate Line-of-Sight Probability for Air-to-Ground Communications Using Millimeter and Terahertz Waves},
  year={2025},
  volume={13},
  number={},
  pages={123913-123930},
  keywords={Air to ground communication;Atmospheric modeling;Layout;Geometry;Line-of-sight propagation;Directional antennas;Ray tracing;Communication channels;Buildings;ITU;Line-of-sight probability;mobility;air-to-ground communication;multi-access edge computing;ray-tracing;unmanned aerial vehicles;service time;sojourn time;urban;simulation},
  doi={10.1109/ACCESS.2025.3582890}}

@INPROCEEDINGS{10777167,
  author={Raddwan, Basheer and Al-Baltah, Ibrahim and Ghaleb, Mukhtar},
  booktitle={2024 1st International Conference on Emerging Technologies for Dependable Internet of Things (ICETI)},
  title={Environment-Aware 3D Mobility Simulation for the 5G and 6G Wireless Networks},
  year={2024},
  volume={},
  number={},
  pages={1-8},
  keywords={Three-dimensional displays;Mobility models;Biological system modeling;Wireless networks;Urban areas;Interference;Ray tracing;Throughput;3GPP;Signal to noise ratio;urban;5G;6G;mobility;ray-tracing;simulation;open-source;handover rate;framework;multi-access edge computing;unmanned aerial vehicle;3D mobility;3D environment},
  doi={10.1109/ICETI63946.2024.10777167}}
Contributors:
- Dr. Basheer Raddwan
- Prof. Ibrahim Al-Baltah
1 maintainer

Download files
Download the file for your platform. If you're not sure which to choose, learn more about installing packages.
Source Distribution
Built Distribution
Filter files by name, interpreter, ABI, and platform.
If you're not sure about the file name format, learn more about wheel file names.
Copy a direct link to the current filters
File details
Details for the file urbanmarl-0.3.1.tar.gz.
File metadata
- Download URL: urbanmarl-0.3.1.tar.gz
- Upload date:
- Size: 72.4 kB
- Tags: Source
- Uploaded using Trusted Publishing? No
- Uploaded via:
uv/0.12.7 {"installer":{"name":"uv","version":"0.12.7","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":{"name":"Ubuntu","version":"26.04","id":"resolute","libc":null},"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":null}
File hashes
| Algorithm | Hash digest | |
|---|---|---|
| SHA256 |
e507dad0a6b974e7c0c0e4bb2a7d148bd62e4306866fd3843889bd3f1a7298ac
|
|
| MD5 |
a0536d4f2a74ab9299ee3feb034ca66a
|
|
| BLAKE2b-256 |
0080563b8045613a92b7e6f05f092571aa29387ab5bf9b7099a95a0e4b469d20
|
File details
Details for the file urbanmarl-0.3.1-py3-none-any.whl.
File metadata
- Download URL: urbanmarl-0.3.1-py3-none-any.whl
- Upload date:
- Size: 94.0 kB
- Tags: Python 3
- Uploaded using Trusted Publishing? No
- Uploaded via:
uv/0.12.7 {"installer":{"name":"uv","version":"0.12.7","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":{"name":"Ubuntu","version":"26.04","id":"resolute","libc":null},"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":null}
File hashes
| Algorithm | Hash digest | |
|---|---|---|
| SHA256 |
79e8ec27ba2f7883150228bbb08f9a1229b007894dec3360aa10acbef5316f77
|
|
| MD5 |
ae8cb2f0ba844d3dab07af27818ef215
|
|
| BLAKE2b-256 |
8f0d58a259aee5a54aa0fd221f0e25c646e7dd69c3155f8d262776772adca538
|














