
vfmap
vfmap is a Python package for delineating valley floors from digital elevation models (DEMs).
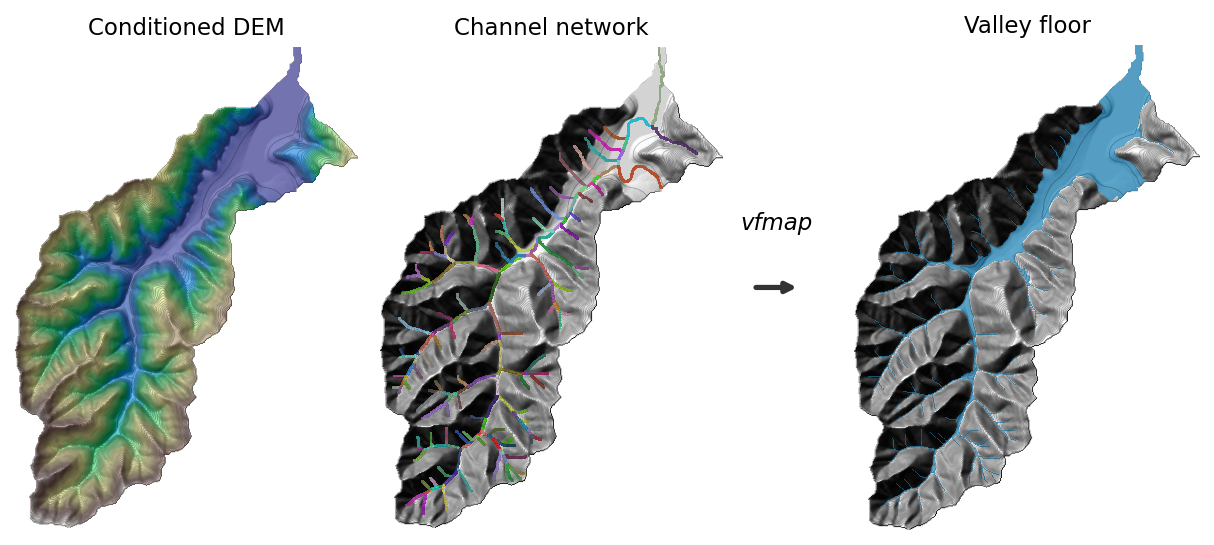
Valley floors are the topographic region between valley walls shaped mainly by fluvial
processes, composed of floodplains, terraces, alluvial fans, and channels. From a
hydrologically conditioned DEM and a reach-labeled channel network, vfmap produces a
binary valley floor raster.
The method combines two components:
- Region growing — low-slope pixels connected to the channel network. Captures wider, unconfined valley floors with multiple channels and floodplains.
- Reach flooding — reach-specific relative elevation thresholds derived from cross-section analysis. Captures narrow, confined valley floors bounded by steep hillslopes.
Installation
pip install vfmap
Usage
With your own conditioned DEM and channel network (both xarray.DataArrays on
the same grid). dem must be hydrologically conditioned - D8 flow directions
are computed from it internally, channel_network (a reach-labeled raster)
must align with the hydro conditioned dem.
from vfmap import map_valley_floor, Parameters

valley_floor = map_valley_floor(
    dem=dem,
    channel_network=channel_network,
    params=Parameters(),   # optional; defaults shown in the table below
)
Parameters
from vfmap import Parameters

params = Parameters(
    region_slope_threshold=2.0,   # degrees, tighter region growing
    flood_percentile=90.0,        # higher flood threshold per reach
    min_hole_size=20_000,         # m², smaller holes filled
)
valley_floor = map_valley_floor(dem, channel_network, params=params)
Parameters can be saved and reloaded as JSON with params.to_json(path) and
Parameters.from_json(path).
Configuration parameters
All parameters live on the Parameters dataclass, grouped by pipeline stage.
Headwater filtering
| Parameter | Default | Unit | Description |
|---|---|---|---|
headwater_min_length |
1,000 | m | Tip reaches shorter than this are treated as headwaters and dropped from valley-floor mapping (their channel pixels are reattached at the end). |
headwater_max_mean_slope |
5.0 | degrees | Tip reaches whose mean channel slope exceeds this are treated as headwaters and dropped. |
Region growing
| Parameter | Default | Unit | Description |
|---|---|---|---|
region_smooth_sigma |
90 | m | Gaussian smoothing length applied to the slope surface before region growing; larger values bridge small rough patches. |
region_slope_threshold |
3.0 | degrees | Maximum slope for a pixel to be grown into the valley floor from the channel network; lower values give tighter, more confined floors. |
Cross-section sampling
| Parameter | Default | Unit | Description |
|---|---|---|---|
xs_interval_distance |
100 | m | Spacing between cross-sections sampled along each reach. |
xs_length |
1,500 | m | Total length of each cross-section (extends this far to either side of the channel). |
xs_point_spacing |
10 | m | Spacing between elevation sample points along each cross-section. |
Reach flooding
| Parameter | Default | Unit | Description |
|---|---|---|---|
flood_steep_slope |
10.0 | degrees | Minimum DEM slope (direction-independent, not measured along the cross-section line) for a point to count as part of a valley wall when detecting slope breaks. |
flood_slope_window |
30.0 | m | Distance over which the DEM slope raster is smoothed before slope breaks are detected, converted internally to a pixel window based on the DEM's resolution; damps single-cell noise that would otherwise interrupt an otherwise-steep run. Set to 0 to disable. |
flood_min_elevation_gain |
10.0 | m | Minimum elevation gain across a steep segment to confirm it as a valley wall (slope-break point). |
flood_default_hand |
10 | m | Fallback elevation-gain threshold used for a reach when too few valid slope-break points are found. |
flood_percentile |
85.0 | percentile | Percentile of slope-break elevation-gain values used as the reach's flood threshold; higher values flood wider. |
flood_min_points |
10 | count | Minimum number of valid slope-break points a reach needs before its threshold is computed from data instead of the default. |
Postprocessing
| Parameter | Default | Unit | Description |
|---|---|---|---|
min_hole_size |
40,000 | m² | Holes in the valley floor smaller than this are filled; set to 0 to disable hole filling. |
max_slope |
15.0 | degrees | Pixels steeper than this are removed from the final valley floor. |
1 maintainer

Release files for vfmap 1.3.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| vfmap-1.3.0.tar.gz | 760.8 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| vfmap-1.3.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 1.1 MB
Release files / vfmap-1.3.0.tar.gz
| Download URL | vfmap-1.3.0.tar.gz |
|---|---|
| Size | 760.8 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
26851c99f684190f79d163dacf5e34ea720f935aff815e17b26a198c5050a909
|
|
BLAKE2b-256 checksum How to use checksums |
977735967de45ea43ac94e0ba49e77953467df4508ed33442b863c1a6b1ecc35
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
uv/0.12.1 {"installer":{"name":"uv","version":"0.12.1","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":{"name":"Ubuntu","version":"24.04","id":"noble","libc":null},"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":true}
|
Release files / vfmap-1.3.0-py3-none-any.whl
| Download URL | vfmap-1.3.0-py3-none-any.whl |
|---|---|
| Size | 314.7 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
09740ec72eb926cb19a02b5478f1bf094aa6a4f348b0b6424b8eff29ff02378f
|
|
BLAKE2b-256 checksum How to use checksums |
8cb08237fb3fce6558a0833fe21cfe565775f2256dd0cf6b1618b36ce46d0b99
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
uv/0.12.1 {"installer":{"name":"uv","version":"0.12.1","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":{"name":"Ubuntu","version":"24.04","id":"noble","libc":null},"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":true}
|













