
Executable UML Repository Populator
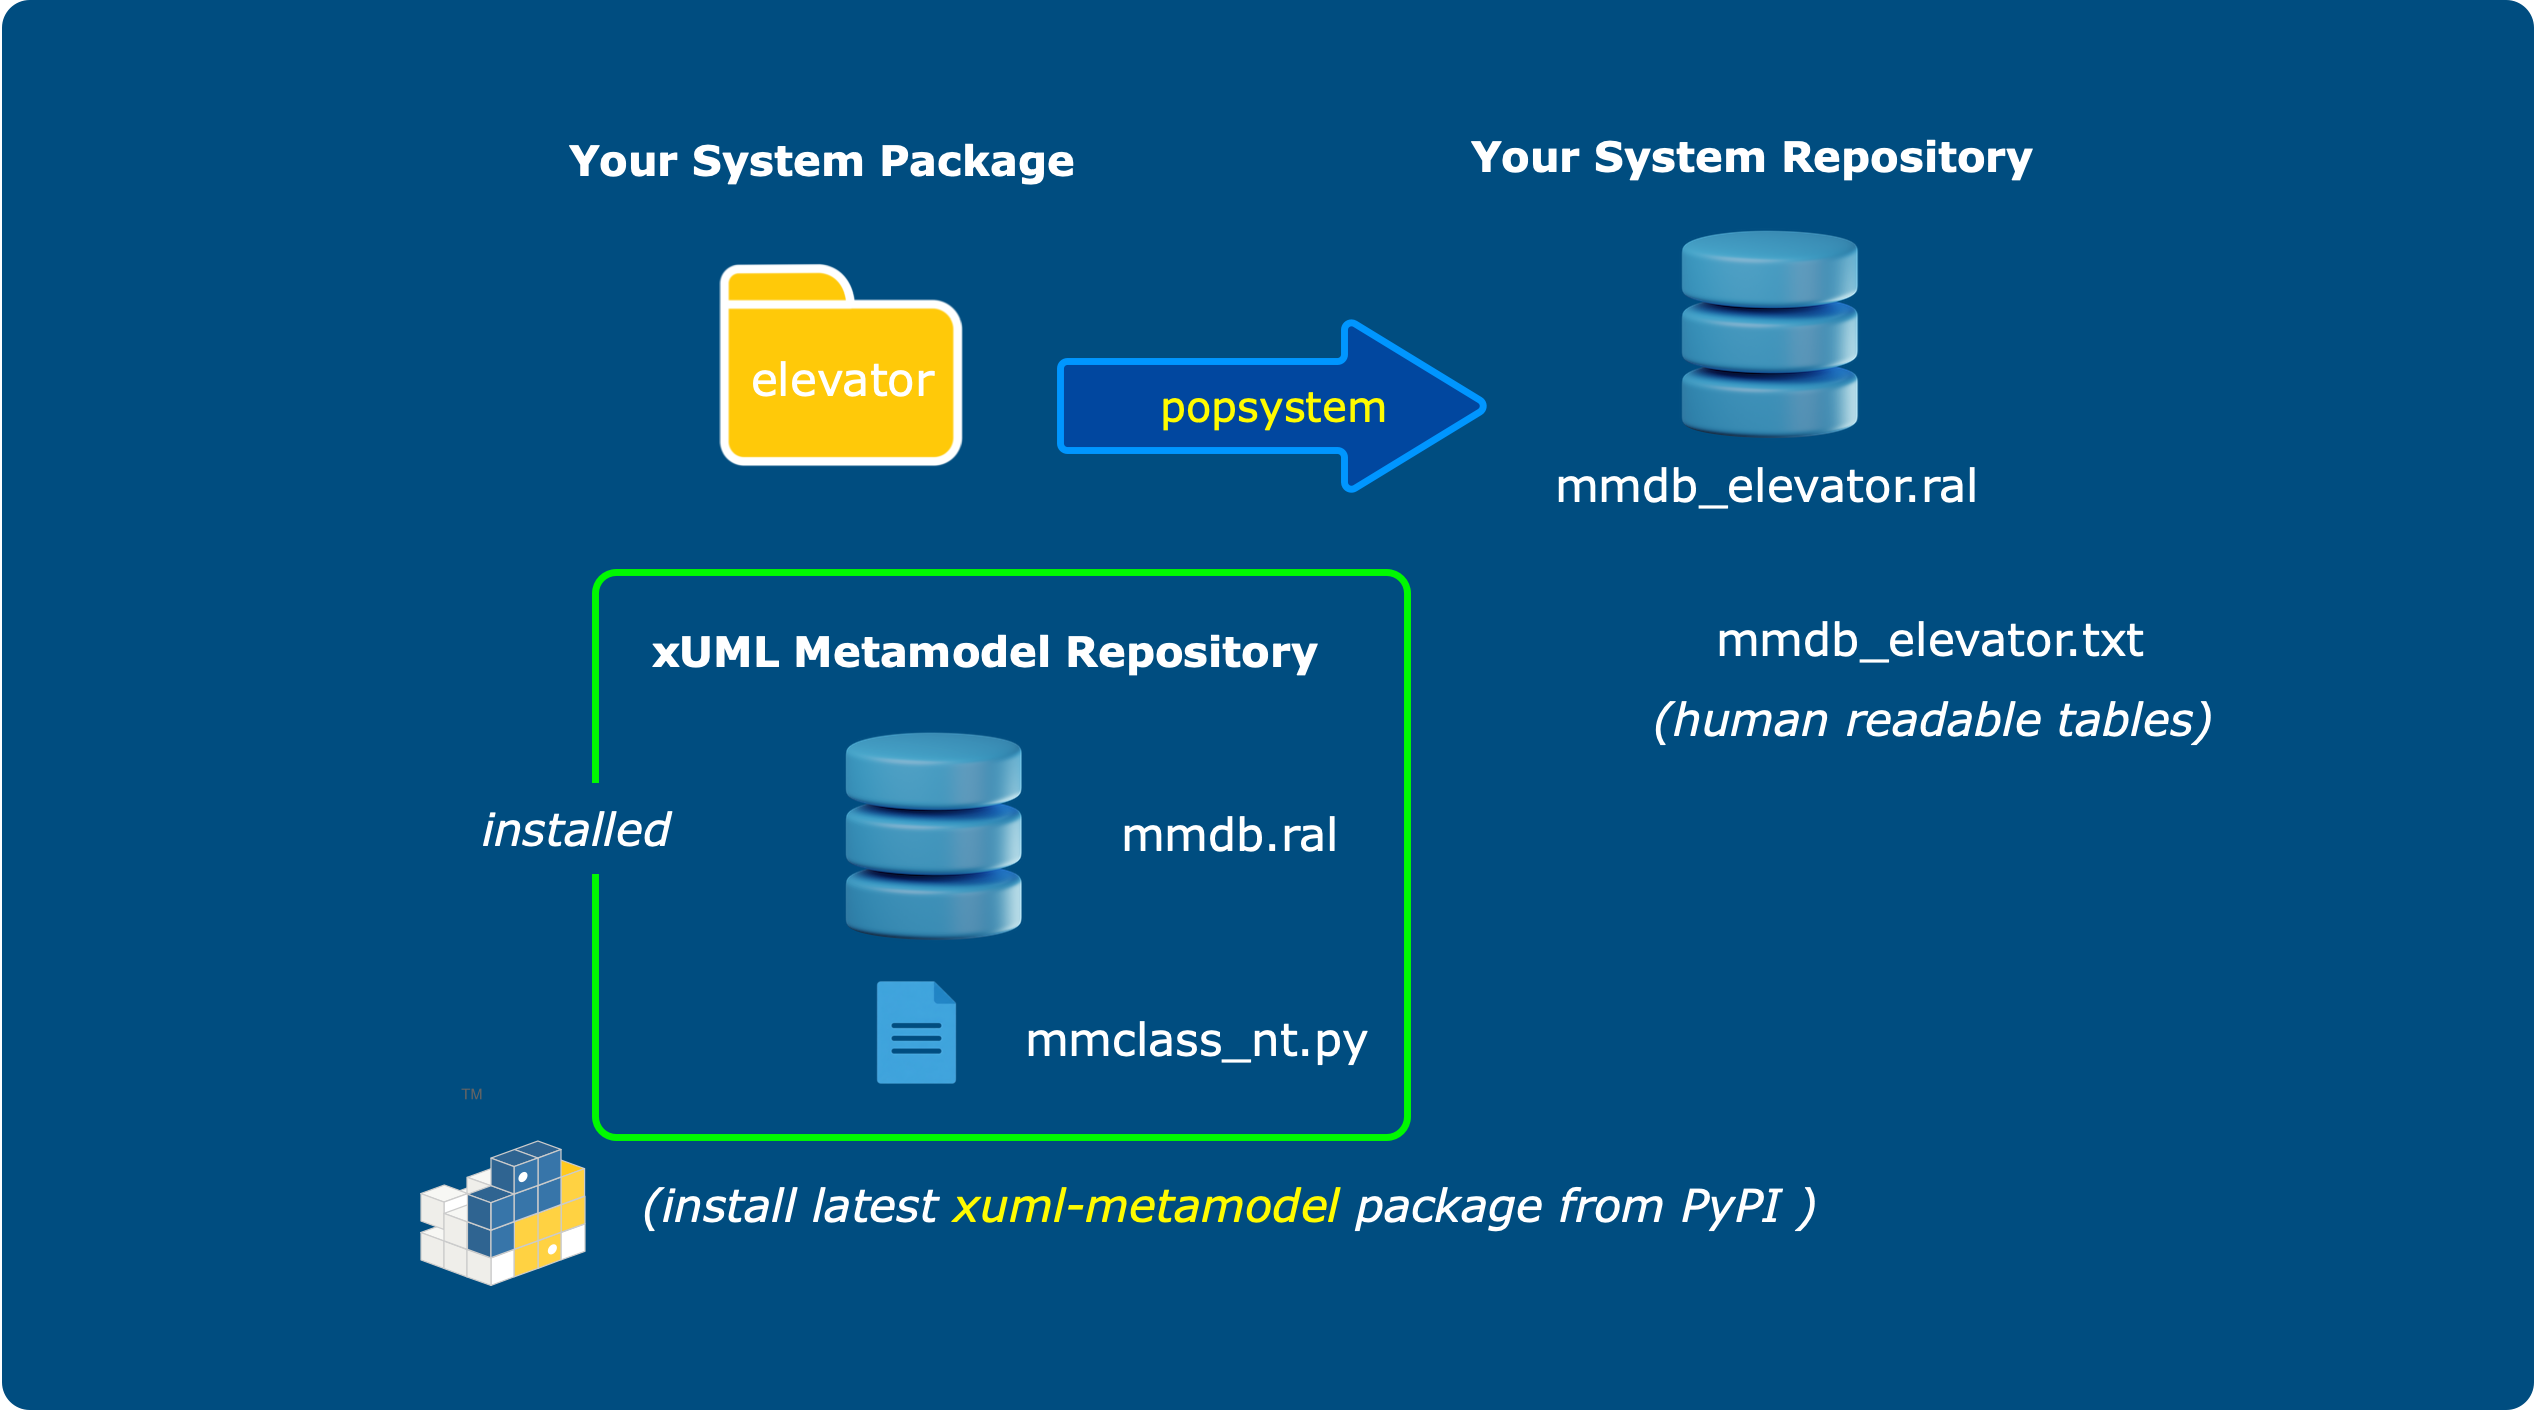
This package populates a Shlaer-Mellor Executable UML metamodel repository with your modeled system. Here, we'll use the Elevator Case Study system as an example.
The two inputs are: 1) an empty metmaodel repository and 2) your modeled (or partially modeled) system. The populator outputs a metamodel database populated with your system. For our example, we'll populate the elevator system into the repository.
Input 1: An empty metamodel repository
The empty metamodel repository (mmdb.ral) is supplied automatically by the
xuml-metamodel package, which popsystem depends on — so you do
not provide it yourself. That package is generated by the
makexumlrepo command and versioned independently; to populate
against a different metamodel version, install a different version of xuml-metamodel.
Input 2: Your modeled system
The modeled system is a structured hierarchy of folders containing text files representing your models. You can think of this as a system package. You just feed the name of the top level system folder as input to the command line.
Command usage
% popsystem -s elevator
The top level of the elevator system package named elevator is in the local directory for this example and we've specified the path with the -s option. The empty metamodel repository it populates comes from the installed xuml-metamodel package, so you do not supply it on the command line.
The above command will output a file named mmdb_elevator.ral. This optional naming convention can be read right to left as elevator populated into mmdb. Later, when you populate your system with scenario specific data, you can continue the convention with mmdb_elevator_threeshafts reading threeshafts populated into elevator system populated into the metamodel db.
If all goes well, your system is loaded into the repository. Often, all will not go well, and that is likely because there are errors in your models. If any Shlaer-Mellor Executable UML modeling rules are broken, the system models won't populate. The errors will tell you what's wrong so that you can make the necessary fixes before trying again. Rather than using complex checking algorithms, we rely on the power of the metamodel itself as a tightly constrained database to detect and report model errors.
When you finally succeed, you know that your models are syntatically correct. They still might not work when you try to run them, (just like syntatically correct code) but that's another set of problems that you can resolve with the appropriate tools downstream, such as the MDB (model debugger) and MX (model execution engine).
Command line options
| Option | Long form | Description |
|---|---|---|
-s |
--system |
Name of the system package to load. The package is a folder in the current working directory with the structure described below. |
-A |
--actions |
Suppress action language (Scrall) parsing. The model structure is still populated, but the actions within each activity are skipped. |
-v |
--verbose |
Print progress and the populated metamodel to the console. |
-L |
--log |
Keep the popsystem.log diagnostic log file. By default the log is deleted when the program exits. |
-D |
--debug |
Run in debug mode. |
-V |
--version |
Print the installed version and exit. |
By default, popsystem parses and populates the action language (Scrall) along with the model structure (classes,
relationships, states, and so on). If you don't want the action language parsed, suppress it with the -A option:
% popsystem -s elevator -A
You might do this when you just want to validate your class and state models without worrying about the action language yet. The models still populate; only the actions within each activity are skipped.
System structure
Each system is defined in a single package broken down into standard hierarchy of folders.
Here is a partial layout for The Elevator Case Study as an example:
elevator // system name
    elevator-management // domain name
        elevator // subsystem name (coincidentally matches system name)
            class-model  // must contain a single .xcm file for the subsystem
                elevator.xcm // must exist, and no more than one .xcm file
                elevator.pdf // any other files in this folder are not processed
                elevator.mls
            external // external entities, each a proxy for some class, this folder is optional
                external.yaml  // defines all external entities, synch and asynch services
                mark.yaml // implicit bridging, if any (implicit state entry events, for example)
            methods // methods for all classes in the subsystem
                cabin // methods defined on the 'cabin' class (must be a modeled class name)
                    count-stops-oneway.mtd
                    count-stops-roundtrip.mtd
                    estimate-delay.mtd
                    ping.mtd
                    ping-both-ways.mtd
                bank-level
                    choose-shaft.mtd
                // no other classes define methods in this subsystem
            state-machines // lifecycles and assigners for this subsystem
                aslev.xsm
                blev.xsm
                cabin.xsm // lifecycles named by class, assigners by association
                door.xsm
                floor-service.xsm
                R53.xsm
                transfer.xsm
                class-collaboration-diagram.pdf  // optional and not processed
                layouts  // optional subfolder with diagrams and layout sheets, not processed
        // no other subsystem folders in this example, but there can be, each structured like elevator above
        // this next types folder is optional for now, but you'll need it in the future
        // it defines model level data types for the entire domain
        types
            // content is not processed by popsystem, but it is processed downstream
    // more elevator system domain files will be added such as transport and sio (signal i/o)
    // for now, though, the elevator example only models a single domain
Here is a summary of the system skelton:
system
    domain
        subsystem1
            class-model
                classmodel.xcm
            types.yaml
            methods
                class1
                    m1.mtd
                    ...
                class2
                    m1.mtd
                    ...
                ...
            state-machines
                s1.xsm
                ...
            external
                external.yaml
                mark.yaml
        subsystem2
        ...
        types
            // content of this folder ignored by this command, but processed downstream
    domain2
    ...
Notes:
Additional files such as class model PDFs and other documentation can be present in the subfolders. Only the recognized files (xcm, mtd, etc) will be processed.
Each modeled domain has its own folder and each domain requires at least one subsystem folder.
Within a subsystem folder there is a class-model subfolder with one class model expressed as an .xcm (executable class model) file.
The following folders are necessary only if they contain model content:
- external – you can't wire this domain to any others, or stub it out in the debugger if you don't specify it
- methods – class methods each in a folder matching the class name with each method in a separate .mtd file
- state-machines – each state machine, assigner or lifecycle, in its own .xsm (executable state machine) file
The types folder resolves model level types and supported type operations like Distance, Speed, etc. to base types
and base type operations. We don't need to process these at this stage, so you can ignore this folder here.
Installation
This package is published on PyPI and requires Python 3.11 or later.
% pip install xuml-populate
Installing from within a virtual environment is recommended:
% python3 -m venv .venv
% source .venv/bin/activate
% pip install xuml-populate
The install pulls in all required Blueprint parser and database dependencies automatically
(xcm-parser, xsm-parser, mtd-parser, op-parser, scrall, mi-pyral, pyyaml). It also pulls in
xuml-metamodel, which provides the empty metamodel schema
that popsystem populates — so there is nothing extra to download or place in your working directory.
Once installed, the popsystem command is available on your path:
% popsystem -V
To upgrade to the latest release:
% pip install --upgrade xuml-populate
1 maintainer

Metadata
1 maintainer
Release files for xuml-populate 1.1.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| xuml_populate-1.1.0.tar.gz | 149.3 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| xuml_populate-1.1.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 349.5 kB
Release files / xuml_populate-1.1.0.tar.gz
| Download URL | xuml_populate-1.1.0.tar.gz |
|---|---|
| Size | 149.3 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
2ffcf381b5997ce6f81e7ebb770d7665495c230afce0462749a6e4bef864765e
|
|
BLAKE2b-256 checksum How to use checksums |
cd9e18c66b46b5195163bd51eb7181195bbba7db78c970593189b8cb5dc0d21e
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.2.0 CPython/3.13.3
|
Release files / xuml_populate-1.1.0-py3-none-any.whl
| Download URL | xuml_populate-1.1.0-py3-none-any.whl |
|---|---|
| Size | 200.3 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
633943385075343da3697b6811140b14a49955bf45f1f007ddba8234990174f0
|
|
BLAKE2b-256 checksum How to use checksums |
13cb53a72c9e8860ac0f4a61dbc9417b7ab3dbfb552d578b1b89b3f1cb720455
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.2.0 CPython/3.13.3
|














