
IKPy



Demo
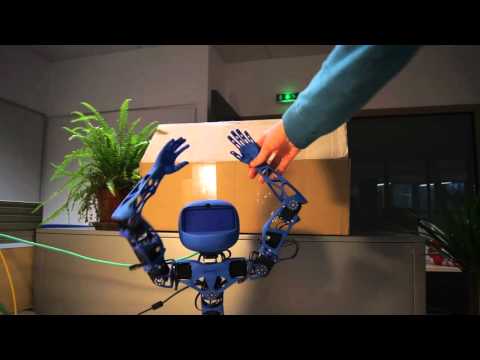
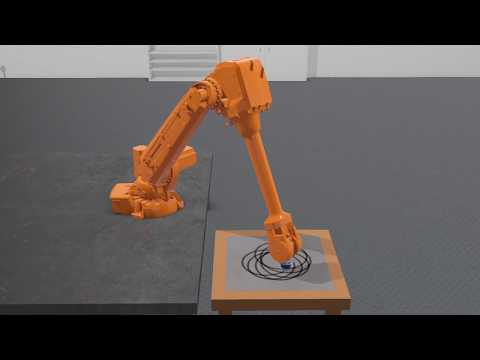
Live demos of what IKPy can do (click on the image below to see the video):
Also, a presentation of IKPy: Presentation.
Features
With IKPy, you can:
- Compute the Inverse Kinematics of every existing robot.
- Compute the Inverse Kinematics in position, orientation, or both
- Define your kinematic chain using arbitrary representations: DH (Denavit–Hartenberg), URDF, custom...
- Automatically import a kinematic chain from a URDF file, a MuJoCo MJCF file or a BVH motion capture file.
- Support for the URDF joint types
revolute,continuousandprismatic - Use pre-configured robots, such as baxter or the poppy-torso
- IKPy is precise (up to 7 digits): the only limitation being your underlying model's precision, and fast: from 7 ms to 50 ms (depending on your precision) for a complete IK computation.
- Plot your kinematic chain: no need to use a real robot (or a simulator) to test your algorithms!
- Define your own Inverse Kinematics methods.
- Utils to parse and analyze URDF files:

Moreover, IKPy is a pure-Python library: the install is a matter of seconds, and no compiling is required.
JAX Backend (Experimental)
IKPy now includes an optional JAX backend for accelerated inverse kinematics using automatic differentiation.
Benefits
| Scenario | Speedup vs NumPy |
|---|---|
| Single target (complex chains) | 1.5-4x faster |
| Trajectory tracking (warm start) | 2-3x faster |
| Cold start | More robust (fewer local minima) |
The JAX backend uses an analytical Jacobian computed via autodiff, which provides:
- Faster convergence on difficult targets
- Better robustness against local minima
- Significant speedup on robots with 5+ joints
Motion capture (BVH) Support
IKPy also reads BVH (Biovision Hierarchy) motion capture files: any path of the skeleton becomes a chain, and the motion of the file can be replayed on it, frame by frame:
from ikpy.chain import Chain
from ikpy.bvh import BVH

# From the hips to the left hand; the path in between is found automatically
chain = Chain.from_bvh_file("walk.bvh", base="Hips", tip="LeftHand", scale=0.01)

trajectory, frame_time = BVH.get_bvh_motion("walk.bvh", base="Hips", tip="LeftHand", scale=0.01)
hand_frames = [chain.forward_kinematics(joints) for joints in trajectory]
Each channel of a joint becomes one link (Hips_Zrotation, Hips_Xrotation...), so the chain follows the exact rotation order of the file. BVH files do not specify their unit: use scale to convert them to meters. ikpy.bvh.BVH.get_joint_names lists the joints of a file.
A better solution: multi-start
The optimizer is local: it converges to the solution closest to its starting point, initial_position. When that lands in a poor local minimum, give several starting points instead of one, and the best solution is returned:
joints = chain.inverse_kinematics(target_position, target_orientation, orientation_mode="all", initial_position=20)
initial_position stays a single configuration in the usual case. An int draws that many starting points anywhere in the joint limits. A dict combines given points and drawn ones: {"points": [current_joints, home_joints], "n": 8, "seed": 0, "around": current_joints, "radius": 0.5} starts from the two given configurations and 8 points drawn near the current one (n defaults to 0, so a dict with only points uses just those). An array of shape (n_starts, n_links) gives the starting points themselves.
To get every distinct solution of a target rather than the best one (elbow up and elbow down, wrist flipped...), chain._inverse_kinematics_solutions_frame(frame, initial_position=20, max_error=1e-3) returns them sorted by error; it is kept out of the main API but documented for that use.
Moving along a trajectory
A single IK call jumps to the solution closest to its starting point, which can be far from where the robot is. To move from one pose to another, interpolate the frames and solve them in sequence: each step starts from the previous solution, so the joint motion stays continuous:
from ikpy.utils import geometry

start = chain.forward_kinematics(current_joints)
end = geometry.to_transformation_matrix(target_position, target_orientation)
frames = geometry.interpolate_frames(start, end, n_steps=50)   # straight line, constant-speed rotation

trajectory = chain.inverse_kinematics_trajectory_frame(frames, initial_position=current_joints, orientation_mode="all")
for joints in trajectory:   # one row per frame
    robot.move_to(joints)
inverse_kinematics_trajectory takes arrays of positions and orientations instead of frames. Any list of frames works, so waypoints computed by a path planner (to go around an obstacle, for example) are solved the same way. regularization_parameter pulls each step towards the previous one for smoother joint motion, at the price of some accuracy. An int or a dict as initial_position runs the multi-start on the first step, which picks the branch of solutions the trajectory then follows. A frame out of reach gets the closest configuration; check each step with the residual the solver minimizes:
from ikpy.inverse_kinematics import target_error
errors = [np.linalg.norm(target_error(chain, joints, frame, "all")) for joints, frame in zip(trajectory, frames)]
Orientation conversions
IKPy works with homogeneous matrices. To exchange orientations with ROS, Unity or Blender, ikpy.utils.geometry converts the rotation part of a frame to and from quaternions, roll-pitch-yaw and arbitrary Euler sequences:
from ikpy.utils import geometry

frame = chain.forward_kinematics(joints)
quaternion = geometry.rotation_matrix_to_quaternion(frame)            # (x, y, z, w), as in ROS and Unity
quaternion = geometry.rotation_matrix_to_quaternion(frame, scalar_first=True)  # (w, x, y, z), as in Blender
roll, pitch, yaw = geometry.rotation_matrix_to_rpy(frame)             # URDF convention

# And back, as an orientation target for the IK
target_orientation = geometry.quaternion_to_rotation_matrix(quaternion)
joints = chain.inverse_kinematics(target_position, target_orientation, orientation_mode="all")
Installation
pip install 'ikpy[jax]'
Usage
from ikpy.chain import Chain

# Load your robot
chain = Chain.from_urdf_file("my_robot.urdf")

# Use JAX backend for IK
result = chain.inverse_kinematics(
    target_position=[0.5, 0.2, 0.3],
    backend="jax"  # Use JAX instead of NumPy
)

# Trajectory tracking with warm start (recommended)
current_joints = None
for target in trajectory:
    result = chain.inverse_kinematics(
        target_position=target,
        initial_position=current_joints,
        backend="jax"
    )
    current_joints = result  # Use solution as next initial guess
Configuration
Two arguments bound the work of the optimizer, and they mean the same thing whichever backend and whichever optimizer you use:
chain.inverse_kinematics(
    target_position=target,
    optimizer_budget=10,  # Approximate number of evaluations allowed
    tol=1e-4,             # Convergence tolerance
)
optimizer_budget is a budget rather than a hard cap: an optimizer finishing a gradient estimation
can overshoot it slightly. Use it to trade accuracy for speed in real-time loops.
Everything else goes through optimizer_kwargs, forwarded as-is to the SciPy optimizer in use
(scipy.optimize.least_squares by default, scipy.optimize.minimize for optimizer="scalar"):
chain.inverse_kinematics(target_position=target, optimizer_kwargs={"loss": "soft_l1"})
The bounds are derived from the limits of the links, so they cannot be set there, and neither can an
option that optimizer_budget or tol is already setting.
The JAX backend uses scipy.optimize.least_squares with an analytical Jacobian, and takes a few
options of its own on top:
chain.inverse_kinematics(
    target_position=target,
    backend="jax",
    optimizer_budget=10,           # Same argument as above
    scipy_method='trf',            # 'trf', 'dogbox', or 'lm'
    scipy_x_scale='jac',           # Auto-scaling (default, recommended)
    use_analytical_jacobian=True,  # Set False for finite differences
)
When to use JAX vs NumPy
| Use Case | Recommended Backend |
|---|---|
| Simple chains (≤4 joints), easy targets | NumPy |
| Complex chains (≥5 joints) | JAX |
| Trajectory tracking | JAX |
| Real-time control | JAX (after warmup) |
| One-off calculations | NumPy (no compilation overhead) |
Note: The first JAX call includes JIT compilation overhead (~1-5s). Subsequent calls are fast.
Selecting a chain
A robot description is a tree. A chain is the path from a base element to a tip element, and that path is unique, so the two names are all it takes, in every format:
chain = Chain.from_urdf_file("baxter.urdf", base="base", tip="left_gripper", tip_offset=[0, 0, 0.1])
chain = Chain.from_mjcf_file("ur5e.xml", base="base", tip="wrist_3_link")
chain = Chain.from_bvh_file("walk.bvh", base="Hips", tip="LeftHand")
base defaults to the root of the file and tip to the only leaf below base; when the tree branches, the error lists the leaves to choose from. In a URDF, base and tip can name a link or a joint; when a link and a joint share a name, the name means the link, and {"name": "left_hand", "type": "joint"} says otherwise. tip_offset adds a fixed translation at the end of the chain, in the frame of its last joint, typically the tool center point.
The former base_elements, base_element_type and last_link_vector arguments still work with a DeprecationWarning, and will be removed in IKPy 5.0.
MuJoCo (MJCF) Support
In addition to URDF, IKPy can import kinematic chains directly from MuJoCo MJCF XML files:
from ikpy.chain import Chain

chain = Chain.from_mjcf_file("ur5e.xml", base="base", tip="wrist_3_link")
The parser supports MuJoCo compiler settings, default classes (including childclass inheritance), and provides helpers to inspect models (ikpy.mjcf.get_body_names, ikpy.mjcf.get_joint_names).
Installation
You have three options:
-
From PyPI (recommended) - simply run:
pip install ikpy
If you intend to plot your robot, you can install the plotting dependencies (mainly
matplotlib):pip install 'ikpy[plot]'
If you want to use the JAX backend, install the JAX dependencies:
pip install 'ikpy[jax]'
-
From source - first download and extract the archive, then run:
pip install ./
NB: You must have the proper rights to execute this command
Quickstart
Follow this IPython notebook.
Guides and Tutorials
Go to the wiki. It should introduce you to the basic concepts of IKPy.
API Documentation
An extensive documentation of the API can be found here.
Dependencies and compatibility
Starting with IKPy v4, Python 3.10 or above is required. Starting with IKPy v3.1, only Python 3 is supported. For versions before v3.1, the library can work with both versions of Python (2.7 and 3.x).
In terms of dependencies, it requires numpy and scipy.
sympy is highly recommended, for fast hybrid computations, that's why it is installed by default.
matplotlib is optional: it is used to plot your models (in 3D).
Contributing
IKPy is designed to be easily customisable: you can add your own IK methods or robot representations (such as DH-Parameters) using a dedicated developer API.
Contributions are welcome: if you have an awesome patented (but also open-source!) IK method, don't hesitate to propose adding it to the library!
Links
- If performance is your main concern,
aversive++has an inverse kinematics module written in C++, which works the same way IKPy does.
Citation
If you use IKPy as part of a publication, please use the Bibtex below as a citation:
@software{Manceron_IKPy,
author = {Manceron, Pierre},
doi = {10.5281/zenodo.6551105},
license = {Apache-2.0},
title = {{IKPy}},
url = {https://github.com/Phylliade/ikpy}
}
2 maintainers


Metadata
2 maintainers
Release files for ikpy 4.3.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| ikpy-4.3.0.tar.gz | 86.5 kB | With provenance | Details for ikpy-4.3.0.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| ikpy-4.3.0-py3-none-any.whl | Python 3 | none | any | Details for ikpy-4.3.0-py3-none-any.whl |
Total release size: 149.2 kB
Release files / ikpy-4.3.0.tar.gz
| Download URL | ikpy-4.3.0.tar.gz |
|---|---|
| Size | 86.5 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
a0e295ffe53d17cfbde8d31dc4248488cde084c2d047cc7d53c6728f0c088623
|
|
BLAKE2b-256 checksum How to use checksums |
a7d358a3a68cca703bff1a5e150427f6a3ee6e65e99f69a68b7a12bbcab49657
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 27, 2026.
Transparency logRelease files / ikpy-4.3.0-py3-none-any.whl
| Download URL | ikpy-4.3.0-py3-none-any.whl |
|---|---|
| Size | 62.8 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
45c6268d83a29fb6910d323e30150c856ae8f33c76aa9b80e577f17812c4961b
|
|
BLAKE2b-256 checksum How to use checksums |
14f0c5ab71dcb148fe53003f2b7615abbb2e34b09991a798e7ce788d1368f578
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 27, 2026.
Transparency logSecurity for ikpy 4.3.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
Full provenance
All 2 files in this release have been uploaded with provenance metadata.
Attestation for ikpy-4.3.0.tar.gz
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 27, 2026.
Transparency logA note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














