


Tsipor Dynamics
Algorithms Engineering and Development
Tsipor (bird) Dynamics (c4dynamics) is the Python framework for state-space modeling and algorithm development.


Stop starting from scratch every time you change systems
Same workflow. Different systems.
Most engineers rebuild everything. c4dynamics keeps the structure fixed.
What is c4dynamics?
c4dynamics is a Python framework for building, simulating, estimating, and controlling physical systems — without resetting your workflow every time the system changes.
It gives you one consistent way to:
- define a system
- simulate its evolution
- estimate its state
- design control
Across:
robotics · aerospace · autonomous systems · navigation
🧪 Examples
Real implementations of modeling, estimation, and control
Not isolated demos. They all follow the same structure.
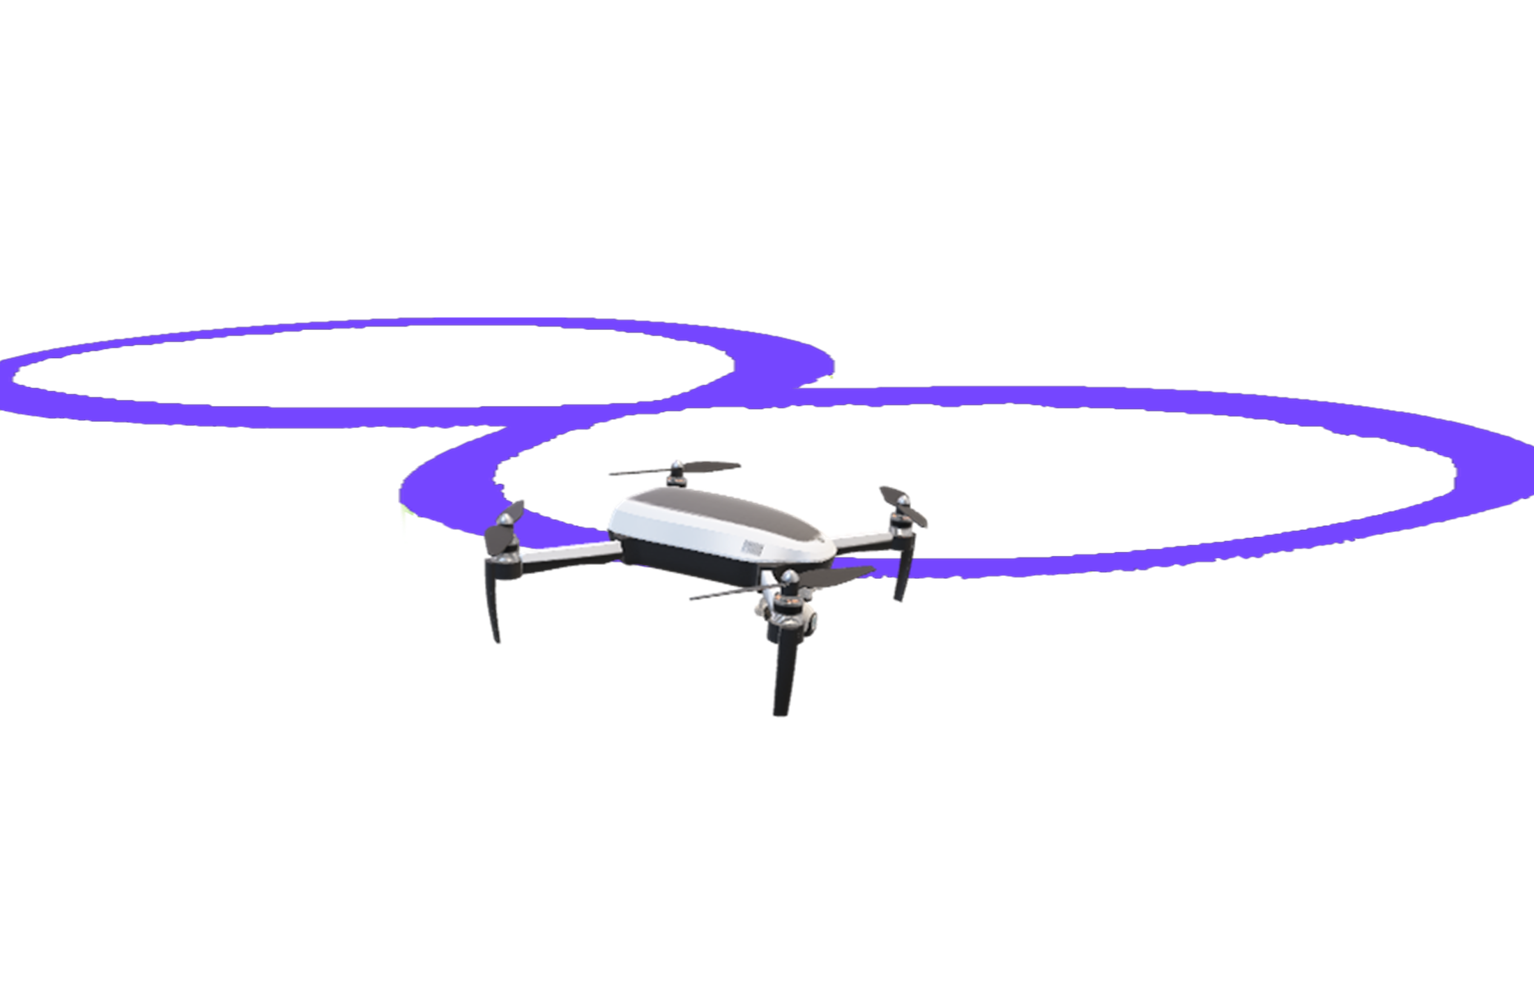
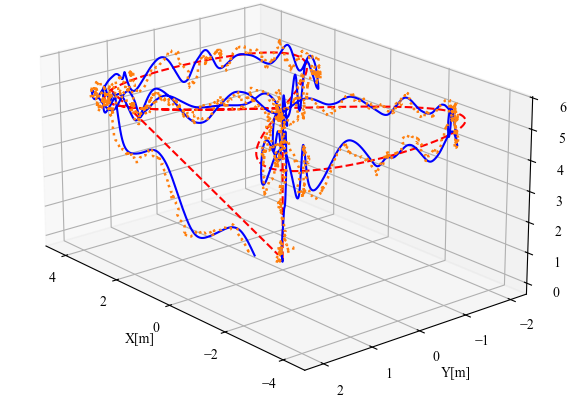
| Cascade PID | EKF State Estimation | ArduPilot Simulation |
 |
 |
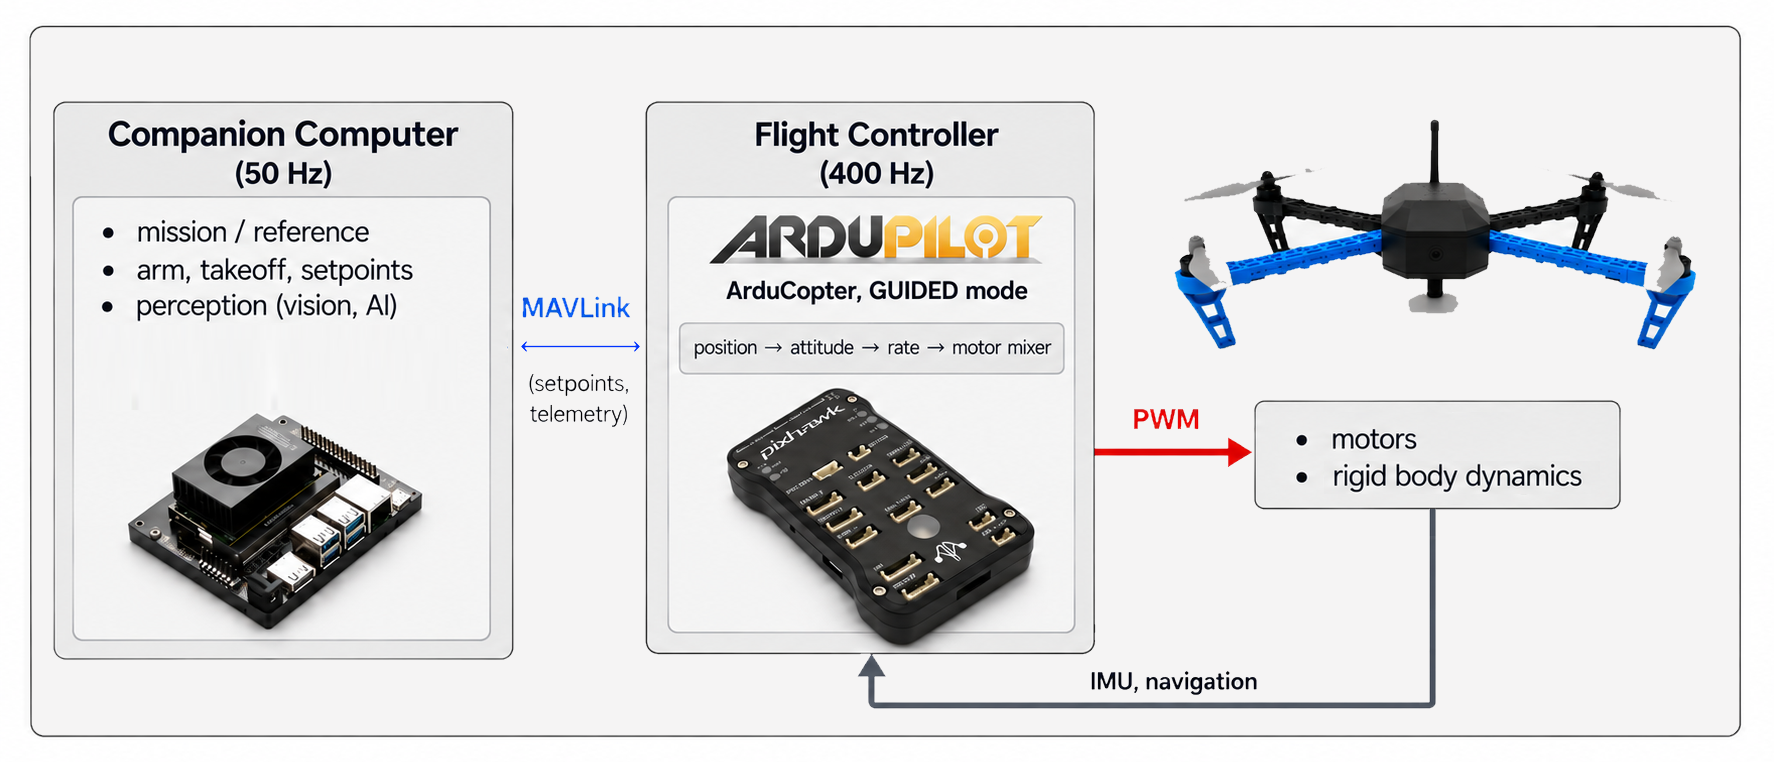 |
| Quadcopter figure-8 tracking | Quadcopter GPS/IMU/MAG sensor fusion | Quadcopter figure-8 under ArduCopter control |
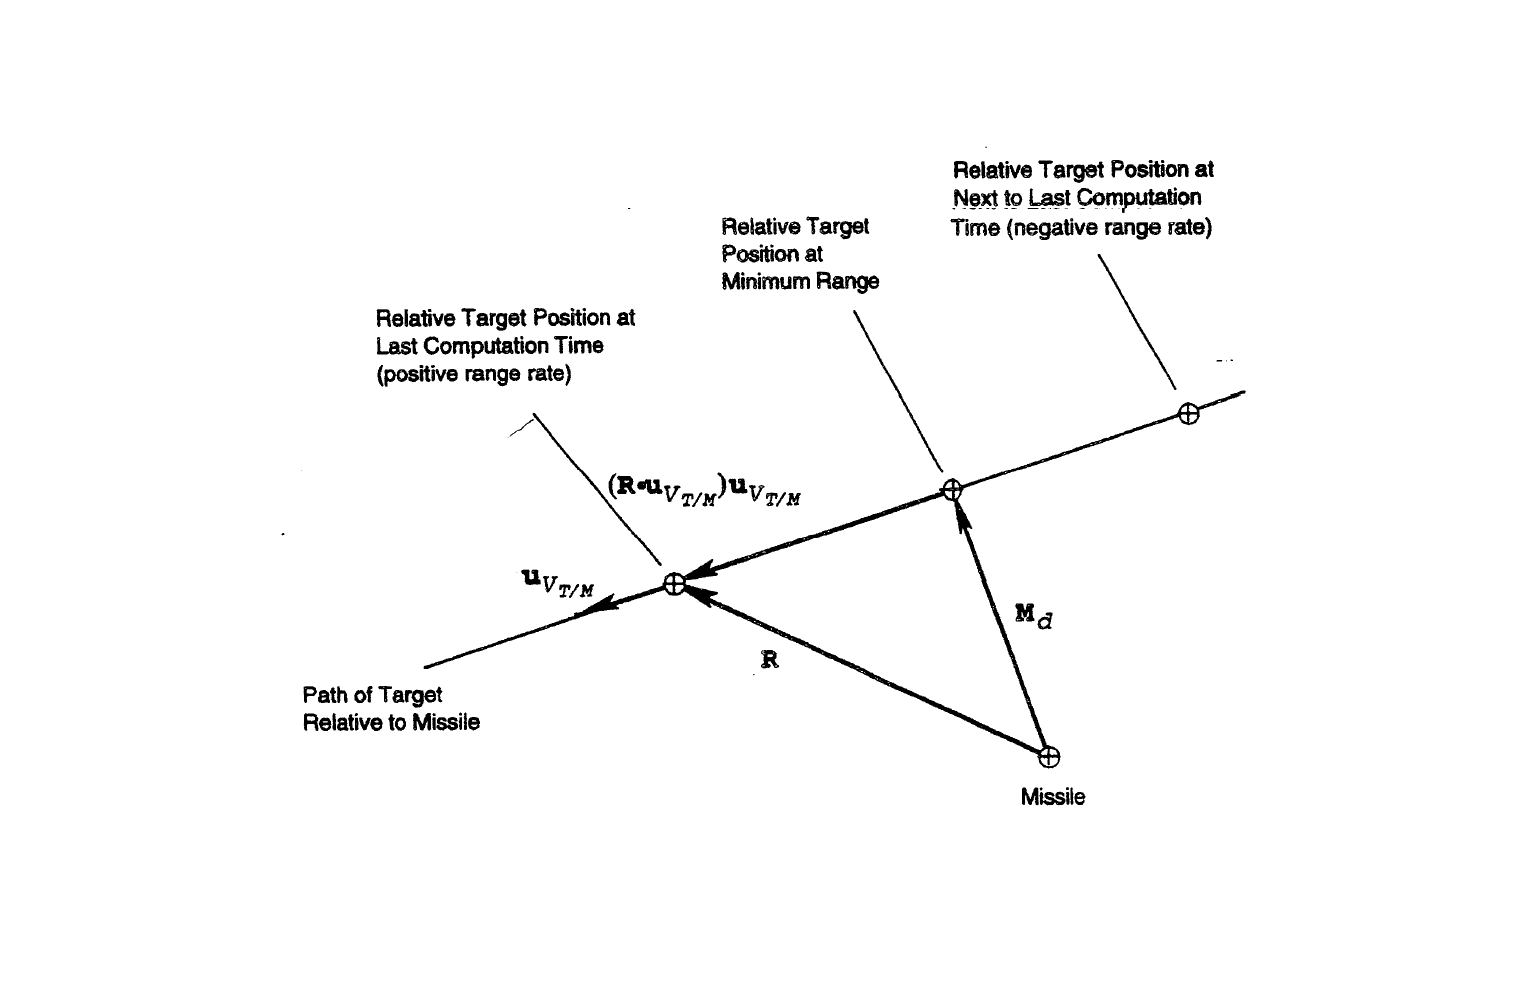
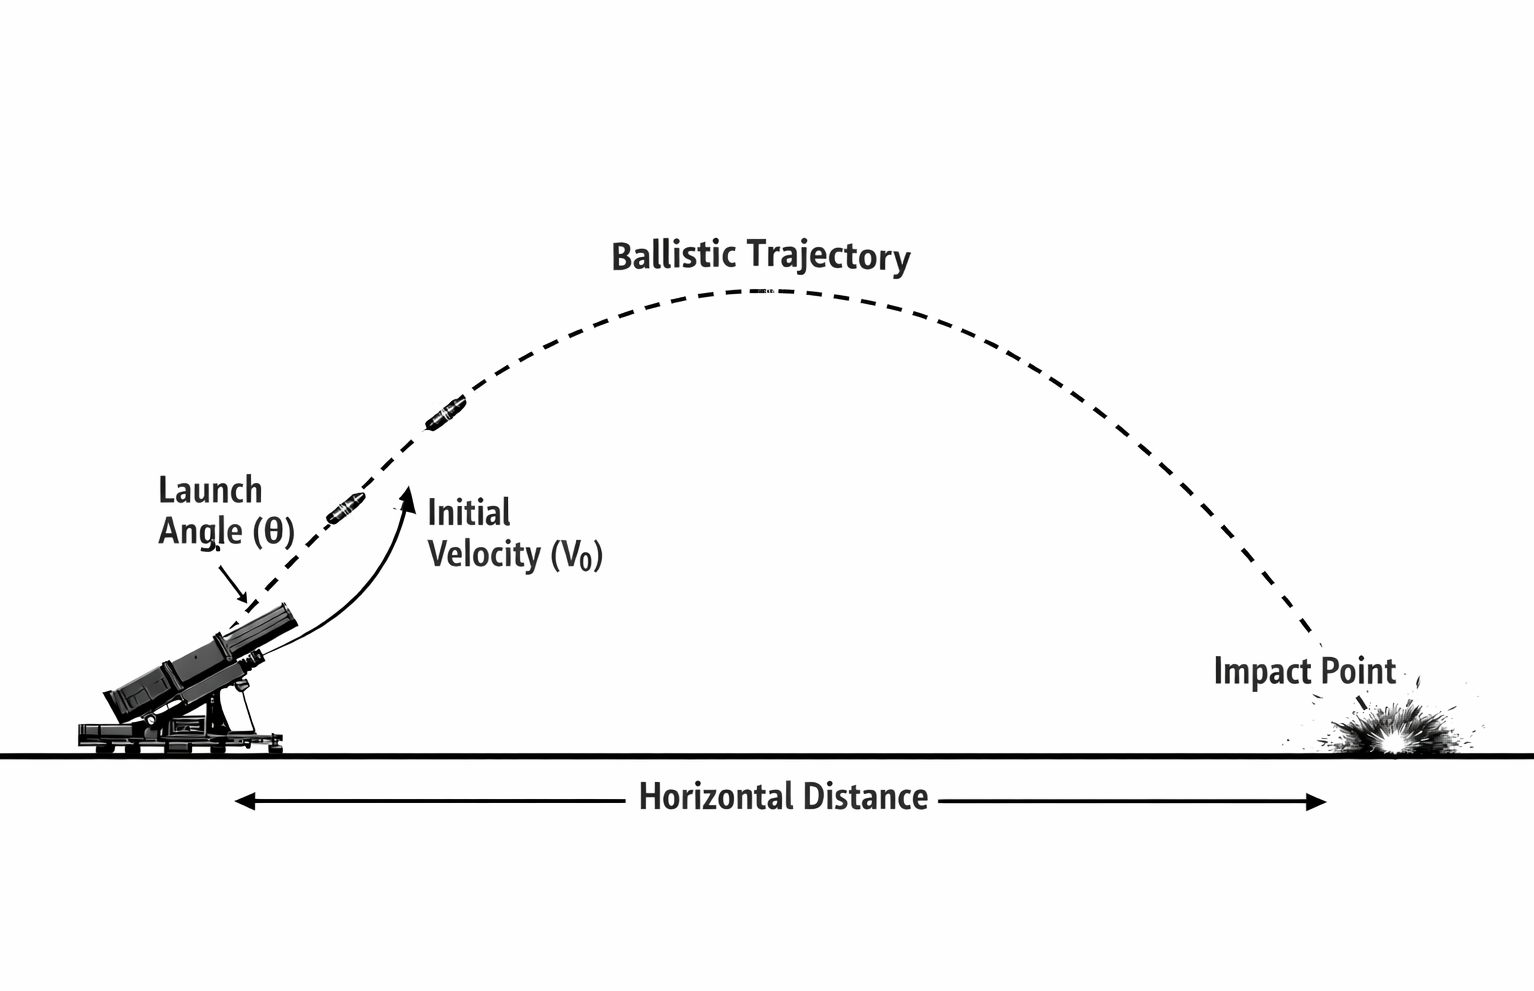
| 6-DOF Simulation | Extended Kalman Filter | Model Predictive Control |
 |
 |
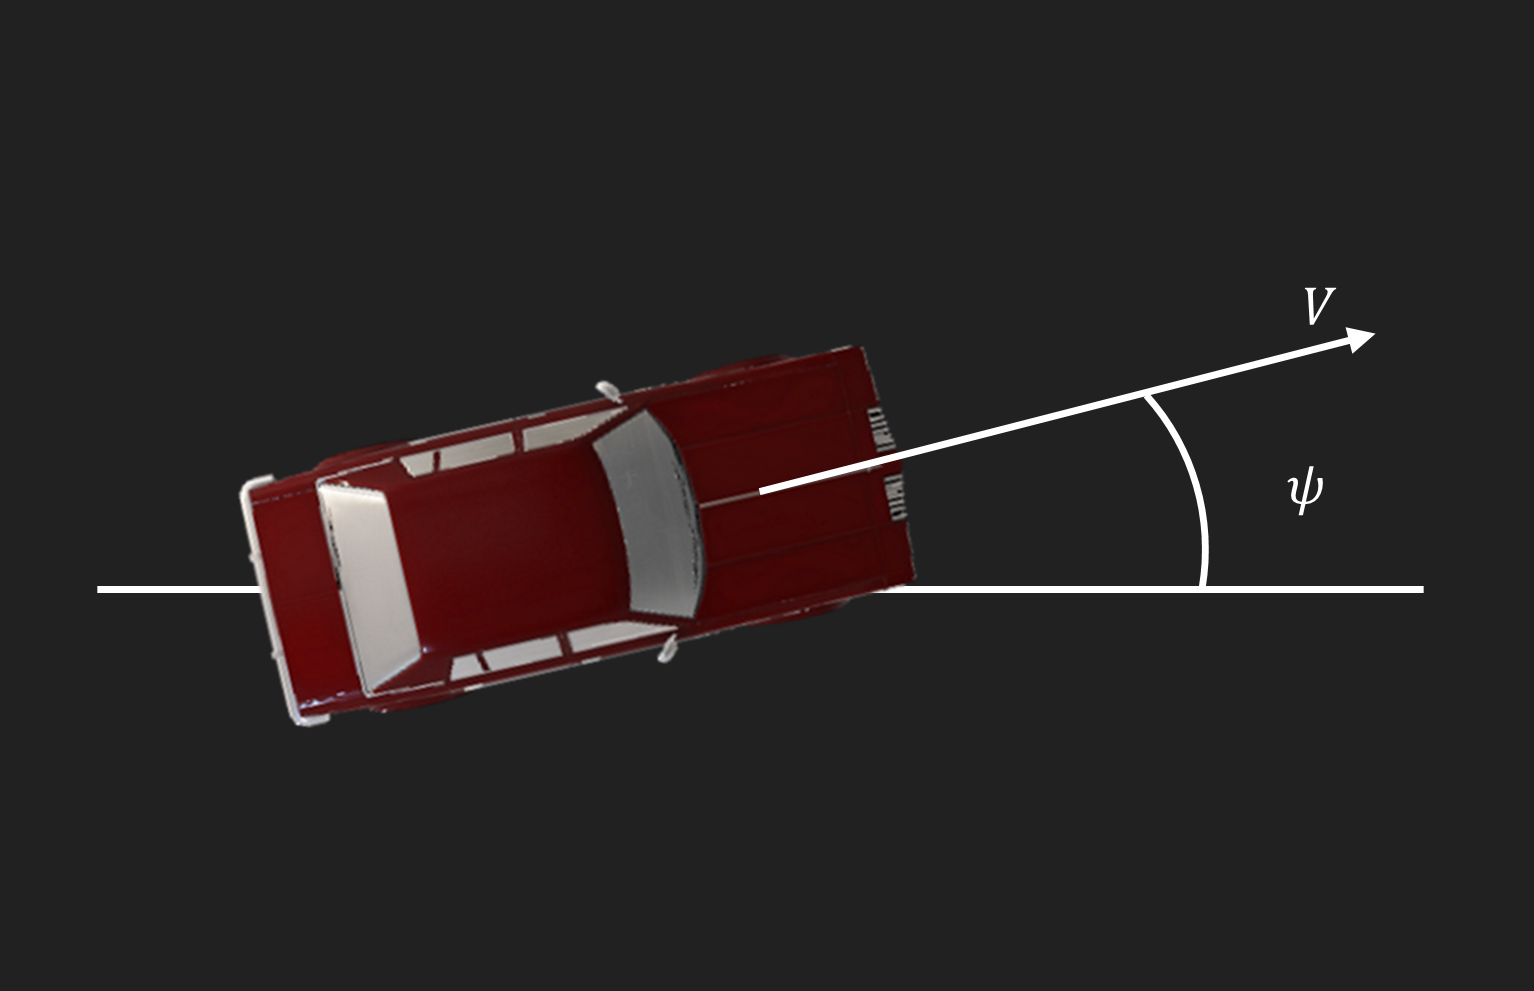 |
| Proportional navigation guidance | Ballistic coefficient estimation | Vehicle steering |
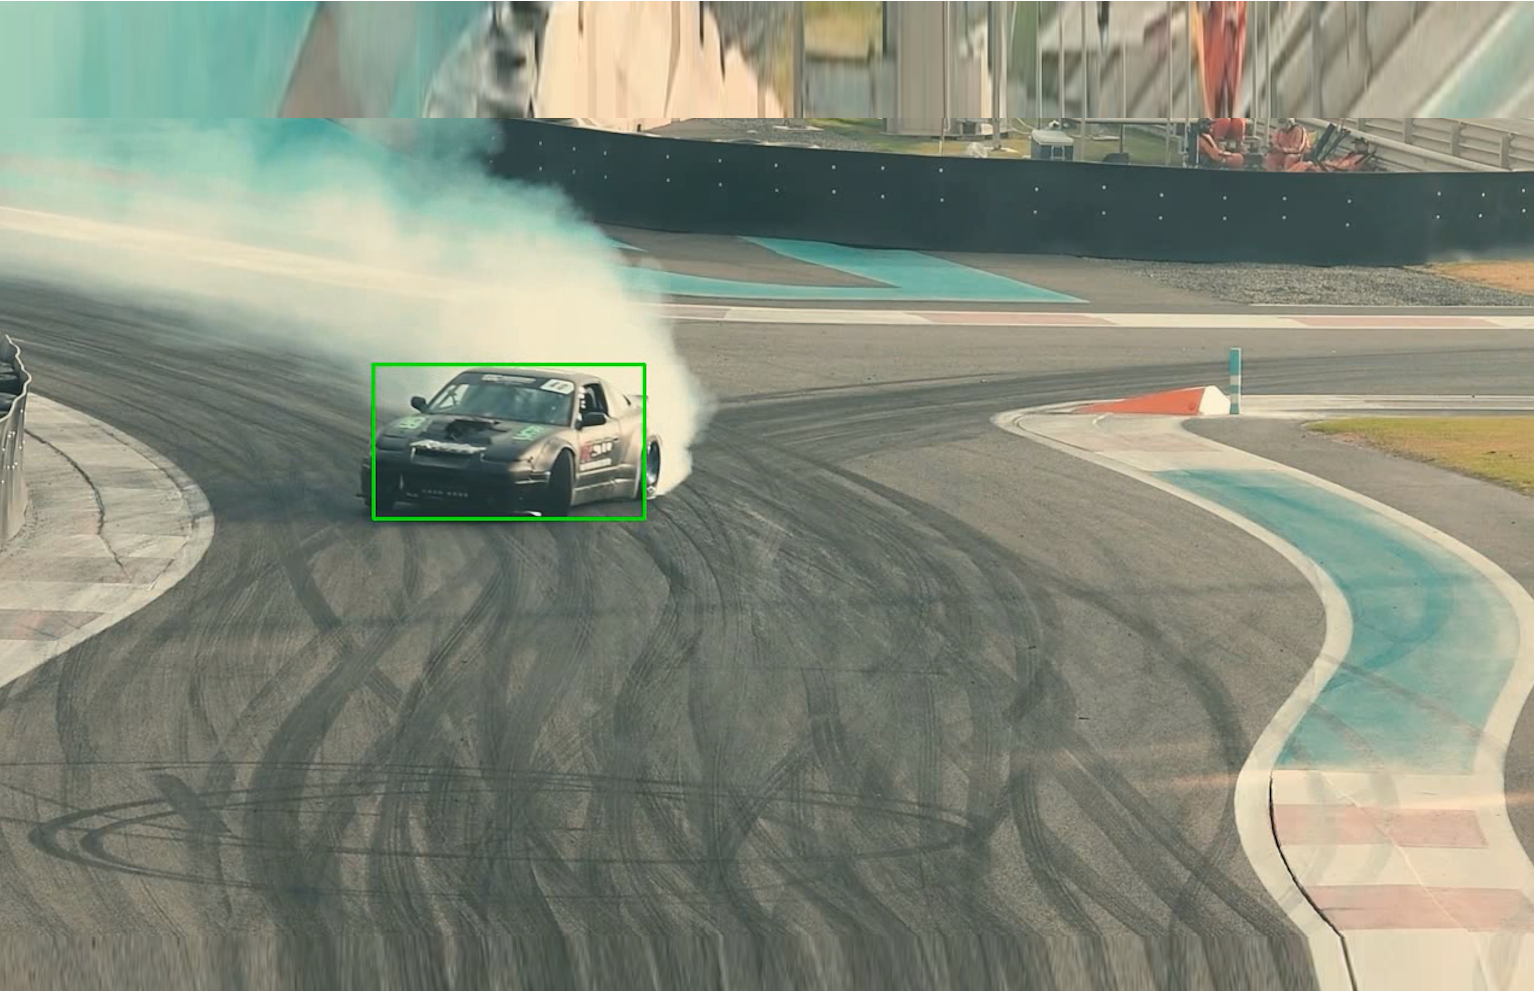
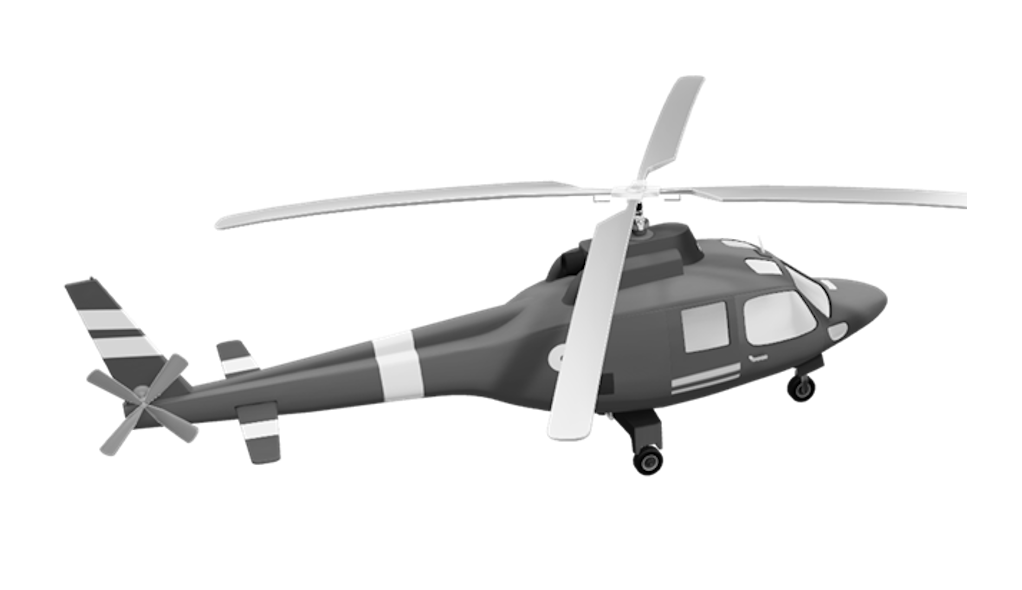
| YOLO3 + Kalman Filter | Neural Network based Controller | YOLO11 + Kalman Filter |
 |
 |
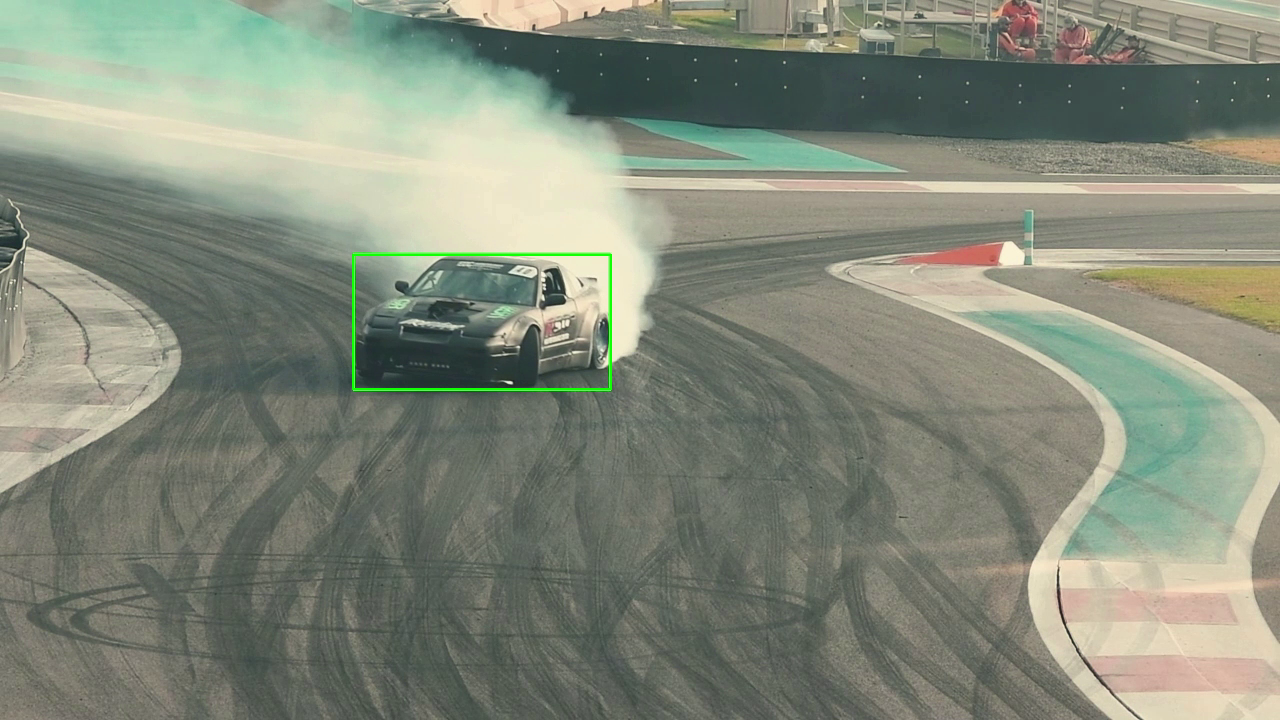 |
| Vehicle tracking | Helicopter Learning Controller | Vehicle tracking (newer detector) |
The switching problem
Switching systems shouldn’t feel like starting over.
But it does:
- new models
- new simulation structure
- new estimation logic
- new control pipeline
You don’t just learn new physics.
You rebuild everything.
The workflow
Keep the workflow. Change the physics.
c4dynamics enforces a consistent structure:
define → simulate → estimate → control
So when the system changes:
your thinking doesn’t.
Core principle
Physics first. Programming second.
- Code implements
- Models define reality
- Algorithms follow structure
What you get
- state-based modeling primitives
- simulation infrastructure
- Kalman / Extended Kalman filters
- sensor and detection modules
- reinforcement learning environments
- OpenCV / Open3D integration
- Monte Carlo simulation support
Who this is for
- control engineers
- robotics engineers
- aerospace engineers
- autonomy developers
Especially if you’ve felt:
“I know this stuff… but I don’t use it.”
Quickstart
>>> import c4dynamics as c4d
define system
s = c4d.state(y=1, vy=0.5)
simulate
F = [[1, 1],
     [0, 1]]

s.X += F @ s.X
s.store(t=1)
Requirements
- Python >= 3.8
- Required packages are listed in requirements.txt
Installation
For detailed instructions on installing c4dynamics, including setup for virtual environments, Python version requirements, and troubleshooting, refer to the c4dynamics setup guide.
>>> pip install c4dynamics
To run the latest GitHub version, download the repo and install required packages:
>>> pip install -r requirements.txt
Documentation
📘 https://c4dynamics.github.io/c4dynamics/
- concepts
- API
- examples
- tutorials
Contributing
This is not just a library.
It’s a shared way of building systems.
- build examples
- improve structure
- explore new systems
Support
If you encounter problems, have questions, or would like to suggest improvements, please open an Issue in this repository.
New system. Same workflow.
1 maintainer

Metadata
1 maintainer
Release files for c4dynamics 2.6.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| c4dynamics-2.6.0.tar.gz | 211.9 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| c4dynamics-2.6.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 422.6 kB
Release files / c4dynamics-2.6.0.tar.gz
| Download URL | c4dynamics-2.6.0.tar.gz |
|---|---|
| Size | 211.9 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
e240a7ca9a4baa210ee5cb5d64f054e6b30517afdf8d5fa51e3a7884ca3322b0
|
|
BLAKE2b-256 checksum How to use checksums |
10100dada908bd4911d264f5dfd7a0cbcfd83c90f3e4920f520cccfec606501a
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.13.15
|
Release files / c4dynamics-2.6.0-py3-none-any.whl
| Download URL | c4dynamics-2.6.0-py3-none-any.whl |
|---|---|
| Size | 210.7 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
009cad99e37ce4cb73ea8cee68a64aba767052301c5952931c921e5e26720c4c
|
|
BLAKE2b-256 checksum How to use checksums |
40441848c64ccafb85939c9fa4241b3086a75132306ed710469b0f50c97ac70a
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.13.15
|














