
diffct
English · 简体中文
Differentiable CUDA projectors for CT: arbitrary trajectories, multi-GPU, multi-node, geometry gradients.



Intro video (MP4) · Technical report · DOI
Install · Quickstart · Features · Performance · Examples · Citation
Install with the CUDA extra,
pip install "diffct[cu12]"orpip install "diffct[cu13]", after PyTorch. A plainpip install diffctneeds a system CUDA Toolkit.Version 2.0 replaces the circular-orbit API of 1.x with per-view trajectories. Code written for 1.x needs changes; see the migration notes. For Apple Silicon, use the MLX port by Linda-Sophie Schneider.
Why diffct
To our knowledge, diffct is the only open-source GPU CT library that combines arbitrary per-view trajectories, autograd through the volume, first-order gradients through the acquisition geometry, and built-in multi-GPU and multi-node execution. We compared it with LEAP, TIGRE, ASTRA/tomosipo, DiffDRR and others in October 2026.
- Arbitrary trajectories. Each view has its own source, detector centre and detector axes. Circular, helical, saddle, sinusoidal, random and calibrated scans use the same code. Trajectory tensors with
requires_grad=Truereceive geometry gradients for calibration. - Matched operators.
project()andbackproject()form an exact adjoint pair for the cell-constant Siddon model. Both support PyTorch autograd, with volume/sinogram gradients and Hessian-vector products. - Multi-GPU and multi-node. Use
devices=[0, 1, 2, 3]in one process, or one process per GPU with torchrun and NCCL. Views are partitioned and the volume is replicated. Speedup depends on workload and communication costs. - Analytical helpers.
diffct.analyticalprovides ramp filters (ram-lak, shepp-logan, cosine, hamming, hann), fan, cone and Parker weights, and FBP and FDK backprojection.
Capabilities, limits and isocenter rules: docs/REFERENCE.md.
Install
You need an NVIDIA GPU. Install PyTorch for your CUDA version first. Then install diffct with the extra for the same CUDA major version:
pip install "diffct[cu12]"    # PyTorch built for CUDA 12
pip install "diffct[cu13]"    # PyTorch built for CUDA 13
The extra installs the CUDA compiler libraries that Numba CUDA needs to compile the kernels. A plain pip install diffct does not install them. Use it only if a CUDA Toolkit is already installed on the system.
From source, with the examples:
git clone https://github.com/sypsyp97/diffct.git
cd diffct && pip install -e ".[cu12]"
python examples/quickstart.py               # smoke test: prints adjoint mismatch ~1e-8 for each beam
Notes on CUDA versions
- Numba CUDA imports
numpy.row_stack, which NumPy 2.5 removes. Keepnumpy<2.5. - Keep NVVM and NVJitLink compatible with the CUDA libraries that PyTorch loads. A newer NVVM with an older NVJitLink fails when the kernels compile.
- A tested CUDA 13 set:
pip install "numpy<2.5" "numba-cuda[cu13]" "cuda-toolkit[cccl,cudart,nvrtc,nvvm]==13.0.2" "nvidia-nvjitlink<13.1". - A tested CUDA 12 set: PyTorch 2.10 (cu126) with
numba-cuda[cu12]0.30.4 on NVIDIA driver 535.
Quickstart
Create the acquisition once. Then call project() and backproject().
import torch
from diffct import Projector, spiral_trajectory_3d

trajectory = spiral_trajectory_3d(360, sid=320.0, sdd=512.0, z_range=40.0, n_turns=1.0, device="cpu")
A = Projector(trajectory, volume_shape=(128, 128, 128), detector_shape=(384, 256), detector_spacing=0.8)

volume = torch.rand(A.volume_shape, device="cuda")
sinogram = A.project(volume)        # (360, 384, 256) line integrals
adjoint = A.backproject(sinogram)   # matched adjoint A^T

x = torch.zeros_like(volume, requires_grad=True)
loss = 0.5 * (A.project(x) - sinogram).square().sum()
loss.backward()                     # x.grad = A^T (A x - y)
Custom or calibrated trajectories. Pass calibrated tensors directly instead of a generator; no circular fit is needed. See REFERENCE.
Geometry gradients. Set requires_grad=True on trajectory tensors before you build Projector. See REFERENCE.
Several GPUs and nodes. Use devices=[0, 1, 2, 3] in one process, or one process per GPU with torchrun for one or more nodes. See REFERENCE and DISTRIBUTED.md.
A = Projector(trajectory, (128, 128, 128), (384, 256), detector_spacing=0.8, devices=[0, 1, 2, 3])
Performance
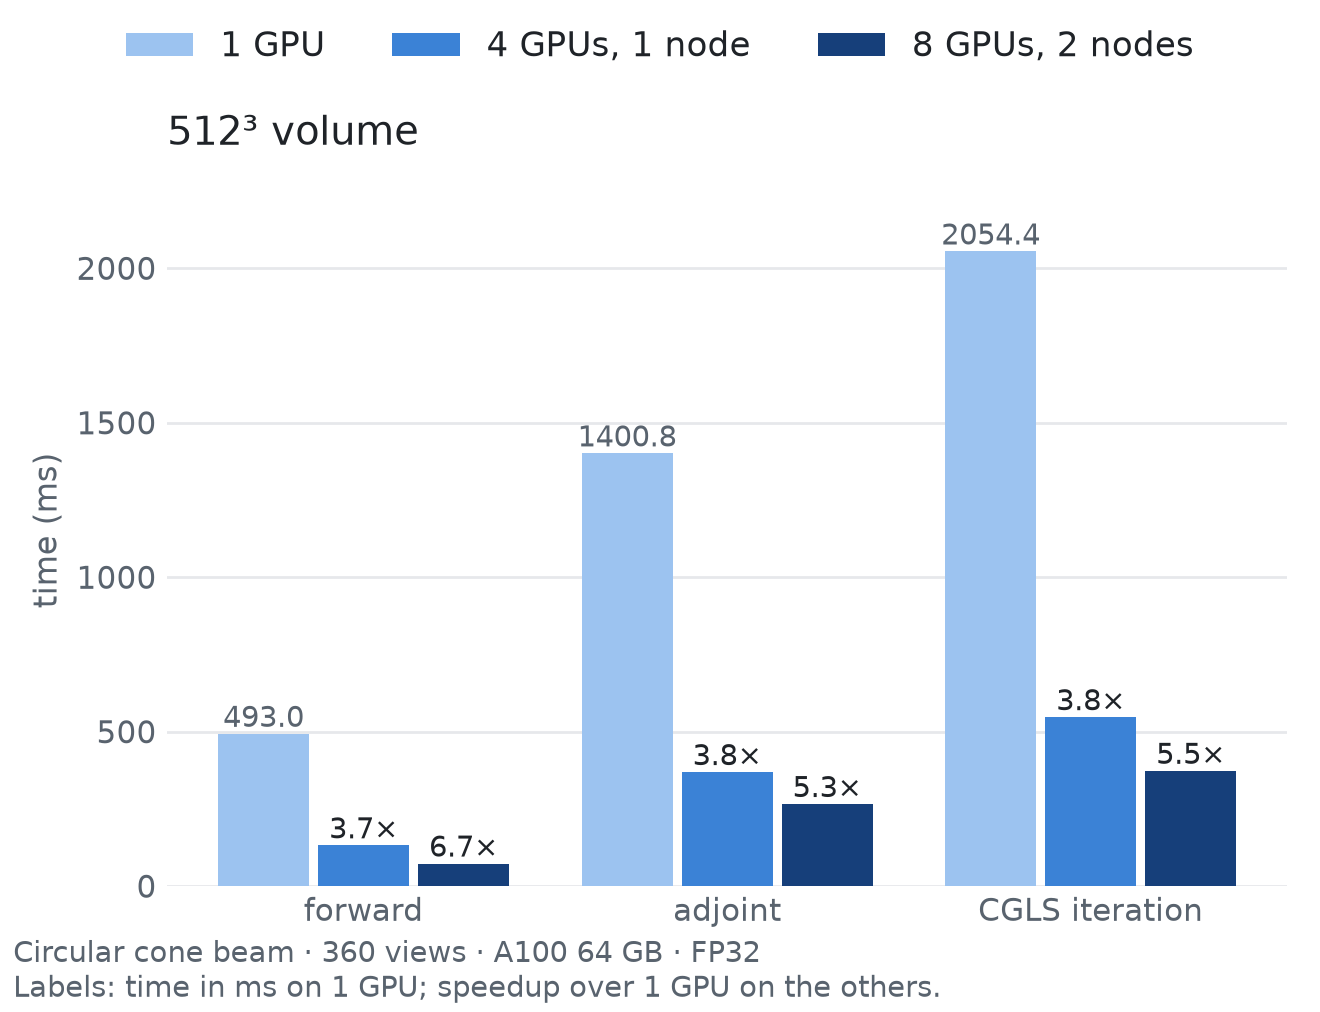
| 128³ volume | 1 GPU | 4 GPUs, 1 node | 8 GPUs, 2 nodes |
|---|---|---|---|
| Forward projection | 8.45 ms | 2.66 ms (3.2×) | 1.68 ms (5.0×) |
| Adjoint (backprojection) | 20.66 ms | 5.89 ms (3.5×) | 4.62 ms (4.5×) |
| CGLS iteration | 30.08 ms | 8.08 ms (3.7×) | 5.59 ms (5.4×) |
Circular trajectory, 360 views, detector (2n, 1.5n) cells at pitch 1.25, A100 64 GB GPUs. Small volumes scale less: at 64³, one CGLS iteration takes 4.63 ms on 1 GPU, 1.57 ms on 4 and 1.56 ms on 8. Raw data: docs/assets/scaling.json.
To measure one against several GPUs on your machine (default scan of the script, not the table setup):
python examples/benchmark_projector.py --devices 0 1
Gallery
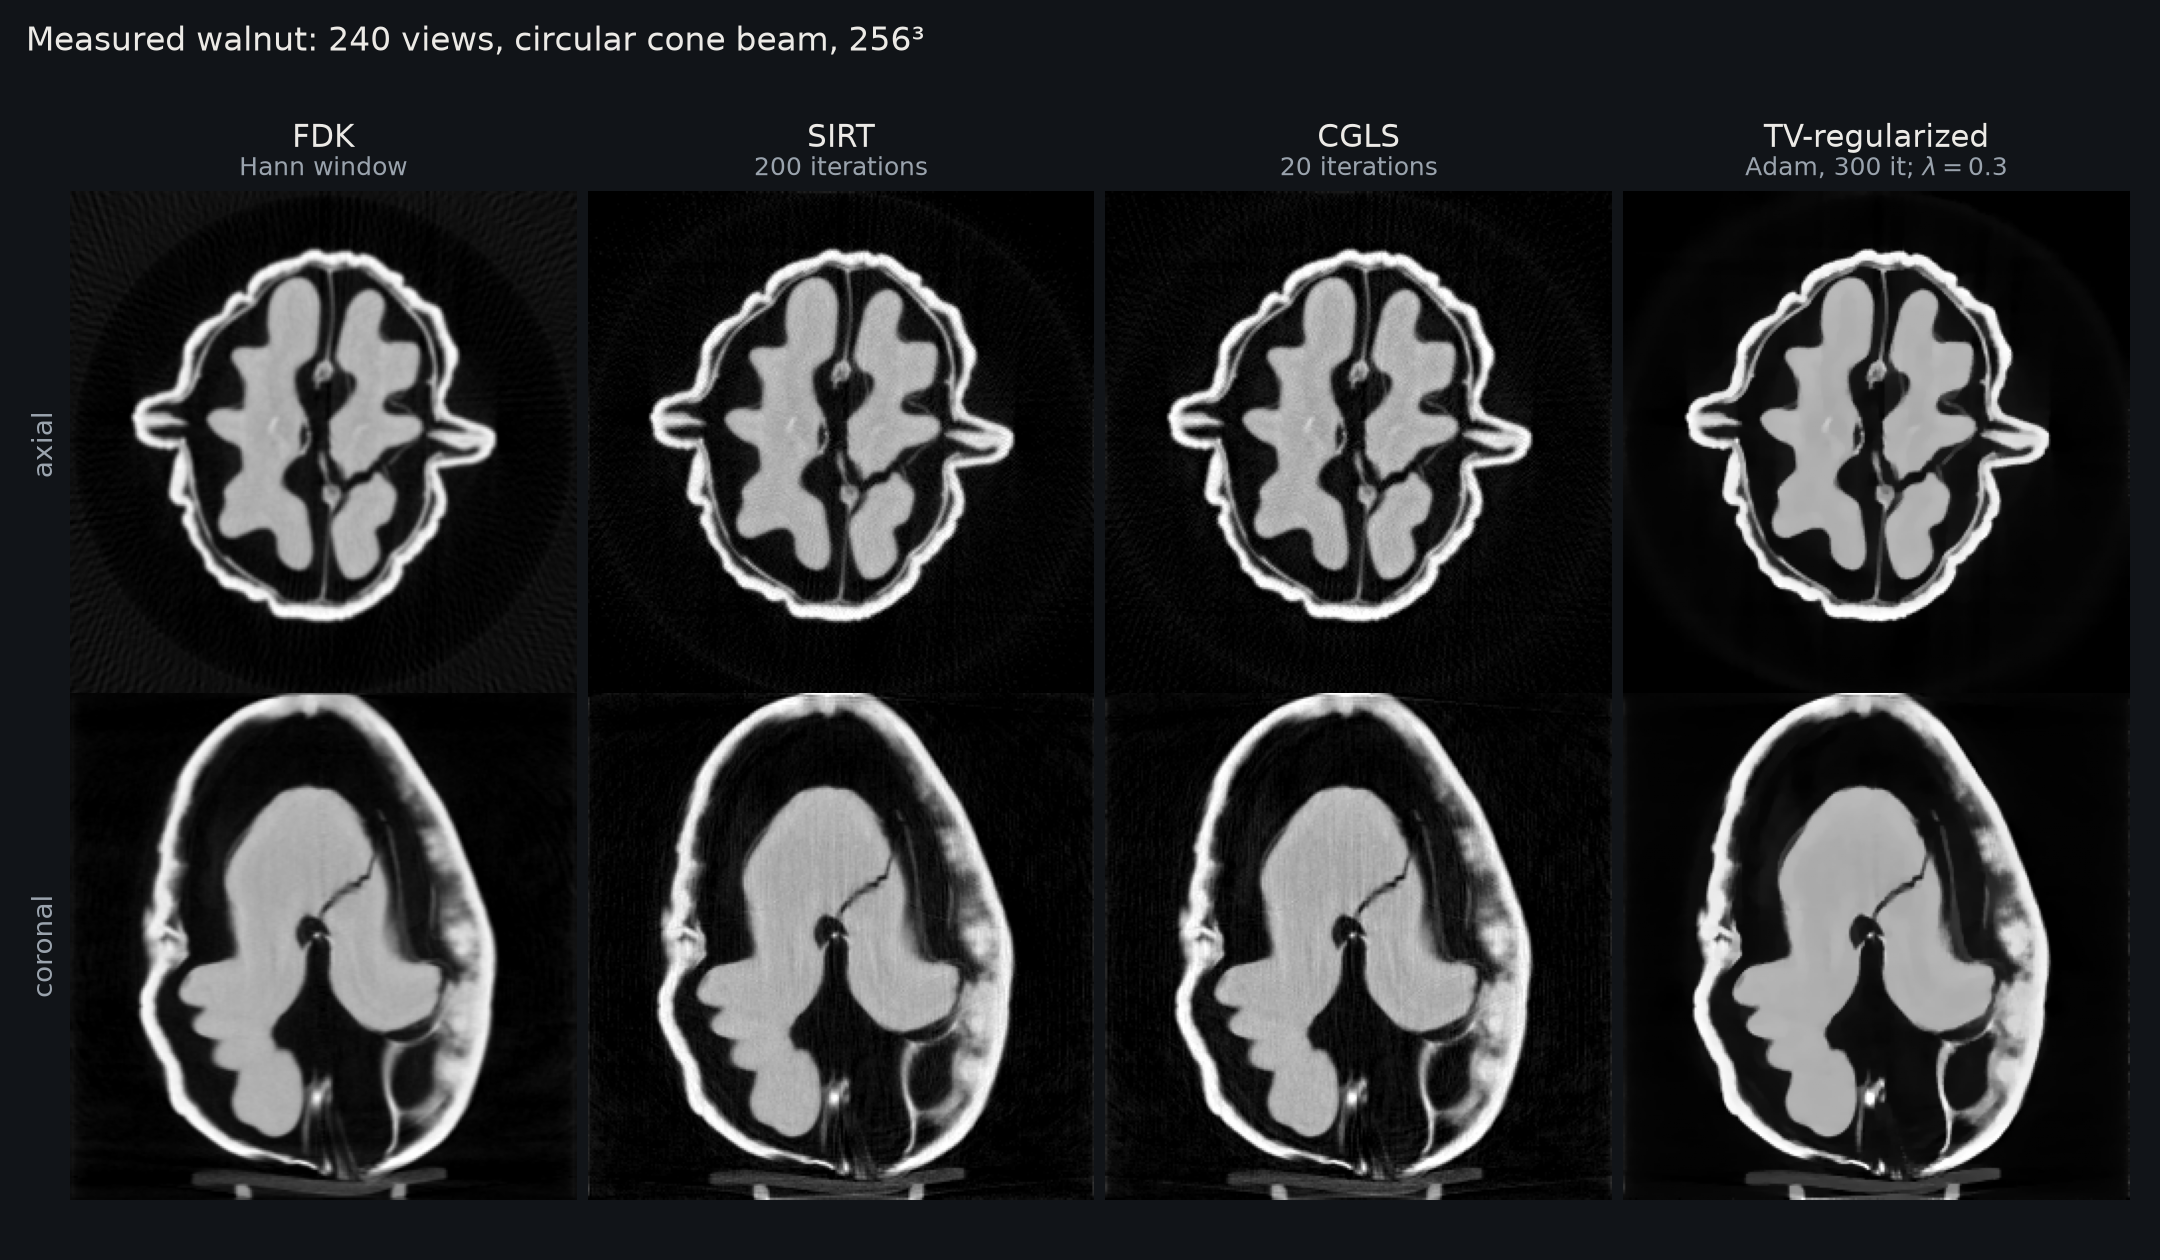
Measured walnut. 240 measured views, circular cone beam, 256³: FDK (Hann window), SIRT (200 iterations), CGLS (20), TV (300, weight 0.3); axial and coronal centre slices.
python examples/walnut_reconstruction.py --figure out.png
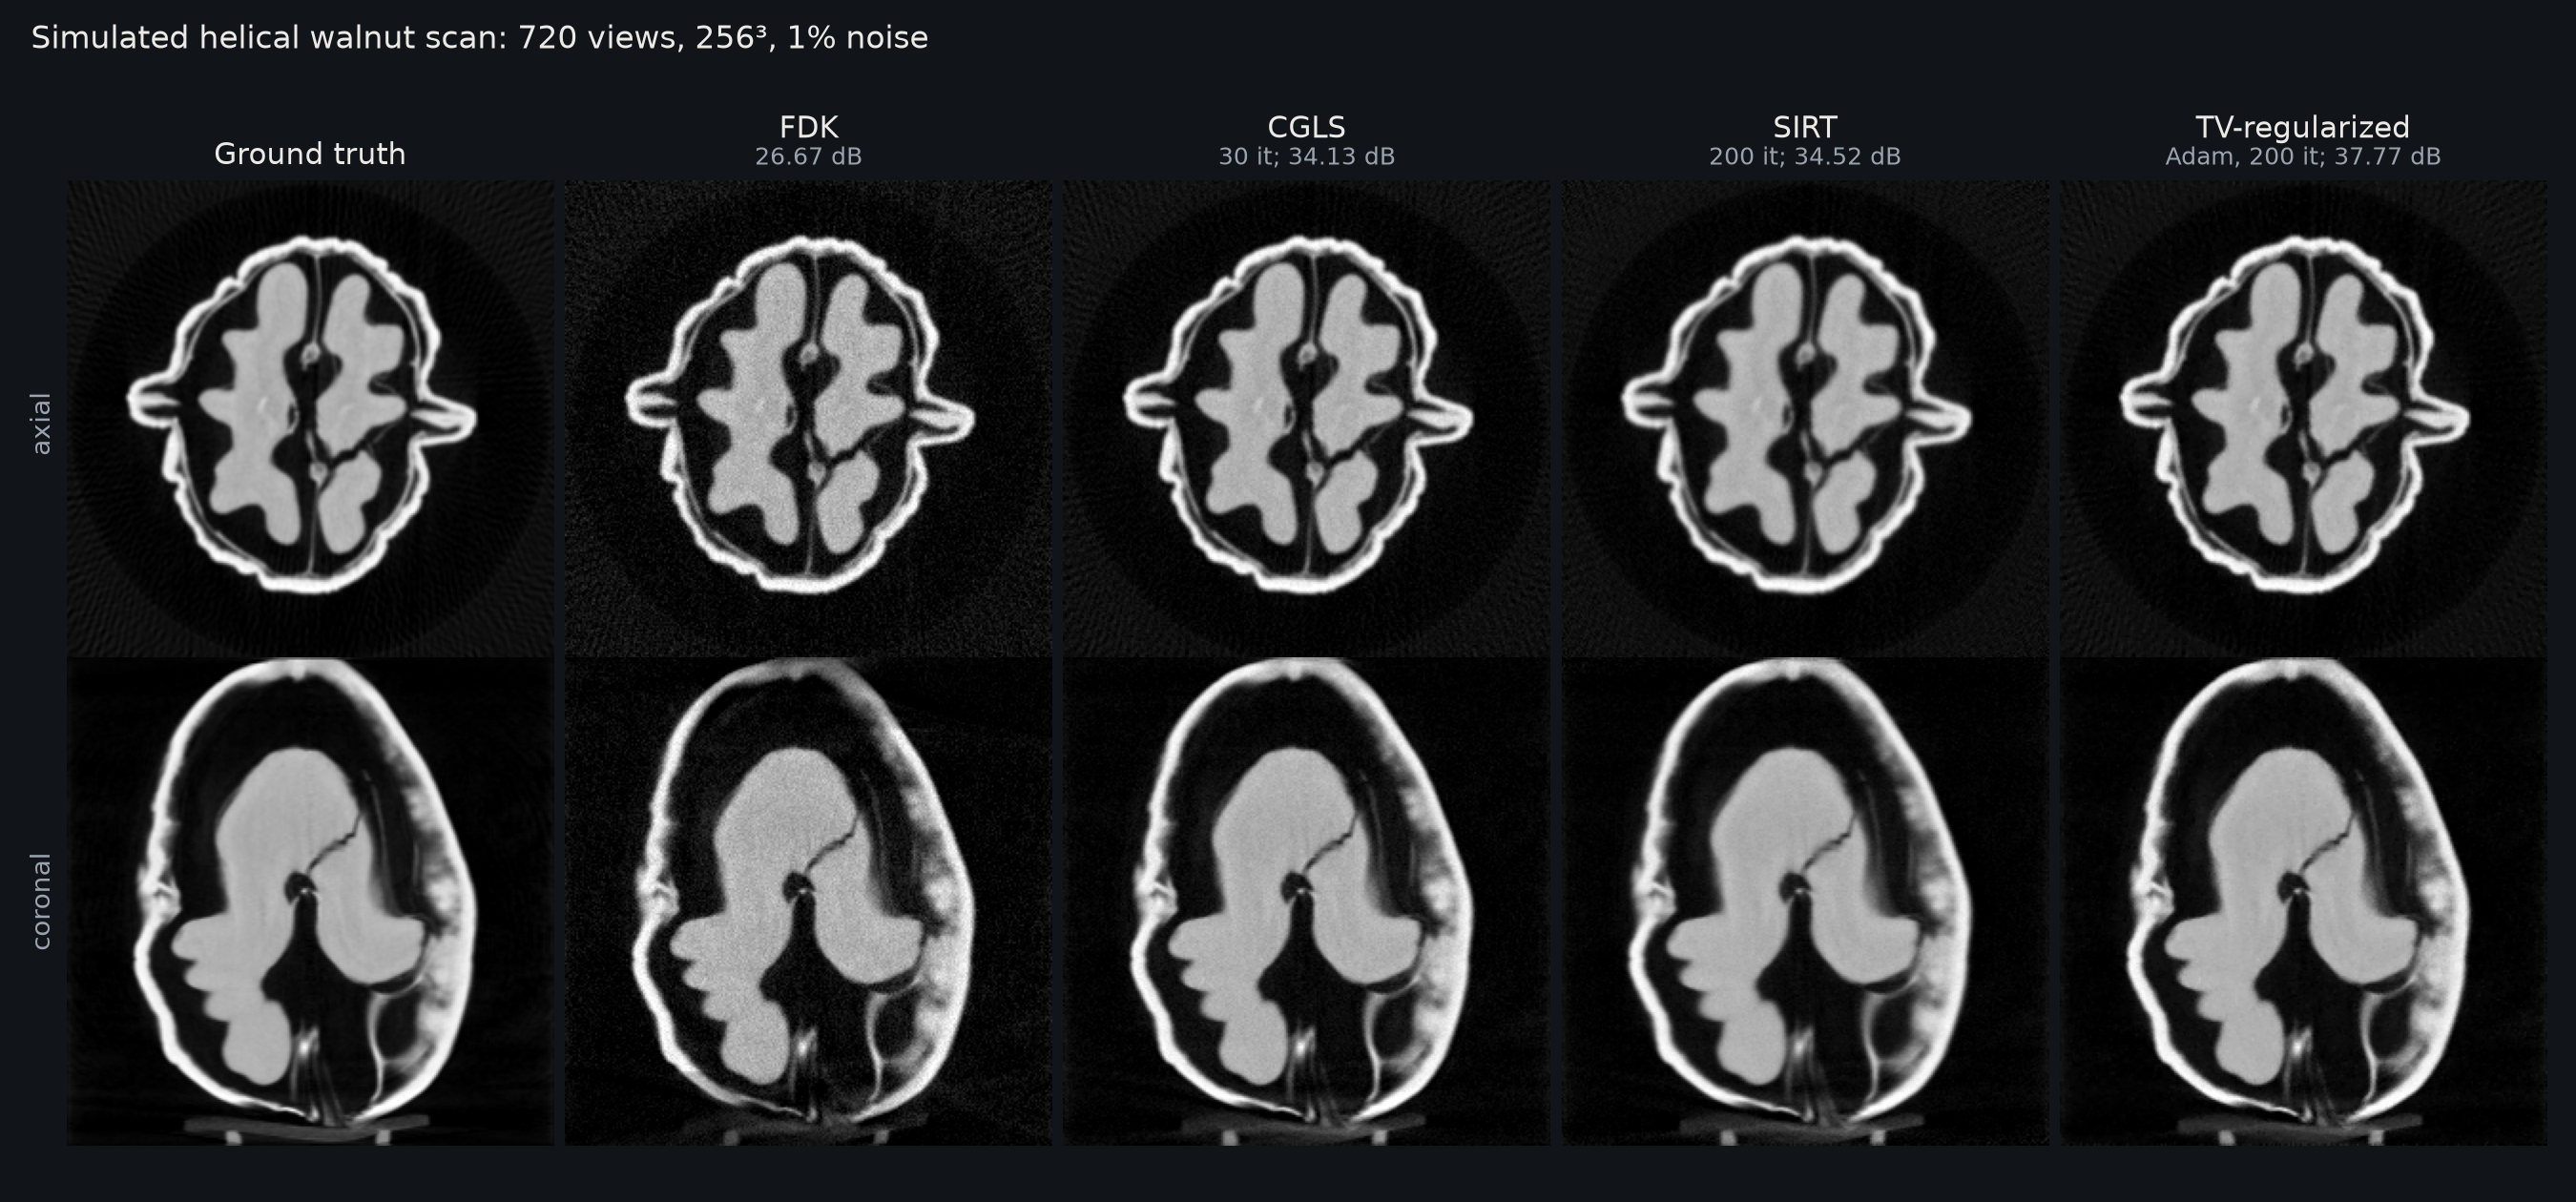
Simulated helical scan of the walnut. The FDK walnut volume as ground truth, 720 views, 1% noise, 256³. PSNR: FDK 26.67 dB, CGLS (30 iterations) 34.13 dB, SIRT (200) 34.52 dB, TV (200, weight 1.0) 37.77 dB.
python examples/walnut_reconstruction.py --algorithms --save-volume walnut256.npy
python examples/iterative_reconstruction.py --size 256 --views 720 --trajectory helical --noise 0.01 --phantom walnut256.npy --figure out.png
Walnut data: Meaney 2022, Zenodo 6986012, CC BY 4.0; see examples/data/NOTICE.
Examples
quickstart.py, analytical_reconstruction.py, iterative_reconstruction.py, walnut_reconstruction.py, geometry_calibration.py, benchmark_projector.py, plot_trajectory.py, and the Slurm template slurm/multi_node.sbatch. Launch modes and distributed-loss rules are in examples/README.md.
Documentation
| Document | Contents |
|---|---|
| Trajectory guide | Trajectory tuples and Projector usage |
| docs/REFERENCE.md | Capabilities and limits, custom trajectories, geometry gradients, multi-GPU details, geometry and units |
| docs/DISTRIBUTED.md | Execution/memory choices, distributed loss rules, Slurm and cross-node checks |
| docs/MIGRATION.md | Moving from the circular-only API |
| docs/video/README.md | How the intro video is rendered |
| CHANGELOG.md | Release history |
Run the test suite on a CUDA host with python -m pytest tests/ -q.
Citation
If you use this library in your research, please cite the software and the technical report:
@software{diffct2025,
  author    = {Yipeng Sun},
  title     = {diffct: Differentiable Computed Tomography Reconstruction with CUDA},
  year      = 2025,
  publisher = {Zenodo},
  doi       = {10.5281/zenodo.14999333},
  url       = {https://doi.org/10.5281/zenodo.14999333}
}

@article{202605.1446,
  doi       = {10.20944/preprints202605.1446.v1},
  url       = {https://doi.org/10.20944/preprints202605.1446.v1},
  year      = 2026,
  month     = {May},
  publisher = {Preprints},
  author    = {Yipeng Sun and Linda-Sophie Schneider and Chengze ye and Andreas Maier},
  title     = {diffct: Differentiable CT Operators from Circular Orbits to Arbitrary Trajectories},
  journal   = {Preprints}
}
License and acknowledgements
Apache 2.0, see LICENSE. The project draws on PYRO-NN and geometry_gradients_CT. Issues and pull requests are welcome. The walnut data are CC BY 4.0 (Meaney 2022); see NOTICE.
1 maintainer

Metadata
1 maintainer
Release files for diffct 2.0.2
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| diffct-2.0.2.tar.gz | 111.5 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| diffct-2.0.2-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 171.1 kB
Release files / diffct-2.0.2.tar.gz
| Download URL | diffct-2.0.2.tar.gz |
|---|---|
| Size | 111.5 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
671785ecff41e074fd0bd1f5eafca493c851a90151356c474fb4c9e2da1ae279
|
|
BLAKE2b-256 checksum How to use checksums |
dd9ea7e7df90f793a96b62af2f756e9b3cb21221eb9a425b23af5fdeb38db5cf
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 9, 2026.
Transparency logRelease files / diffct-2.0.2-py3-none-any.whl
| Download URL | diffct-2.0.2-py3-none-any.whl |
|---|---|
| Size | 59.6 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
bc078334875c753077c847f262fb3ec57812b673e0bacec96783de0e23c7cefc
|
|
BLAKE2b-256 checksum How to use checksums |
81a8880a2e04f0ac6cd4fd66963e009a59d2867d63c90edea9d7c64cc5e328e3
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 9, 2026.
Transparency log













