
This release is a pre-release and may not be stable for production use.
fieldtrial
Find out whether your robot policy actually got better.


fieldtrial is an open-source Python framework for statistically rigorous, real-world evaluation of robot policies. LeRobot trains the policy; fieldtrial tells you whether it actually got better.
Why
Real-world evaluation is slow, noisy and ad hoc. With 40 rollouts, the 95% confidence interval for a success rate is 12 to 15 percentage points wide on each side, so many apparent improvements from a fine-tuning run are just noise. fieldtrial helps at every stage:
- Before: how many rollouts do I need? What is the smallest difference this evaluation can detect?
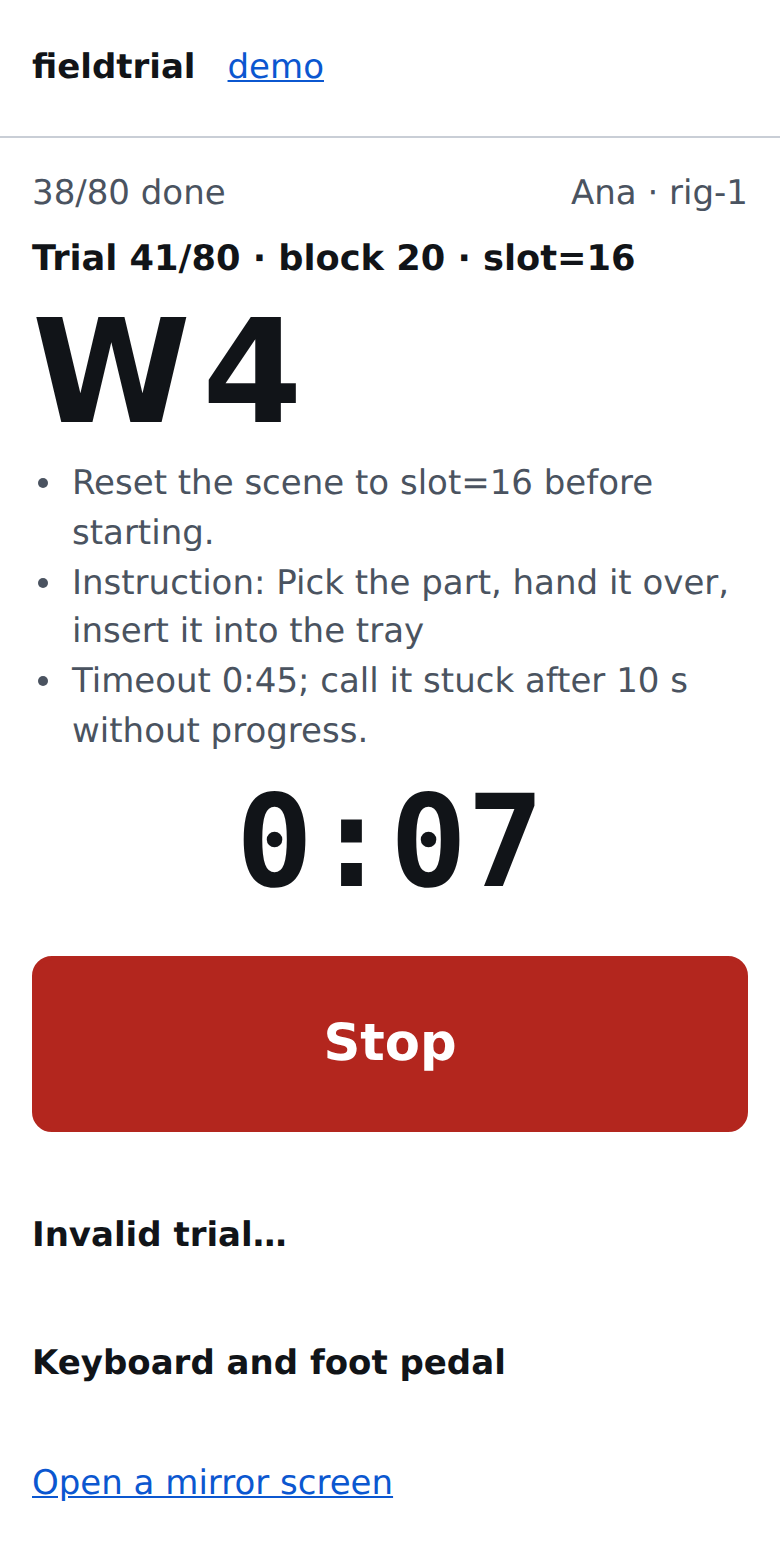
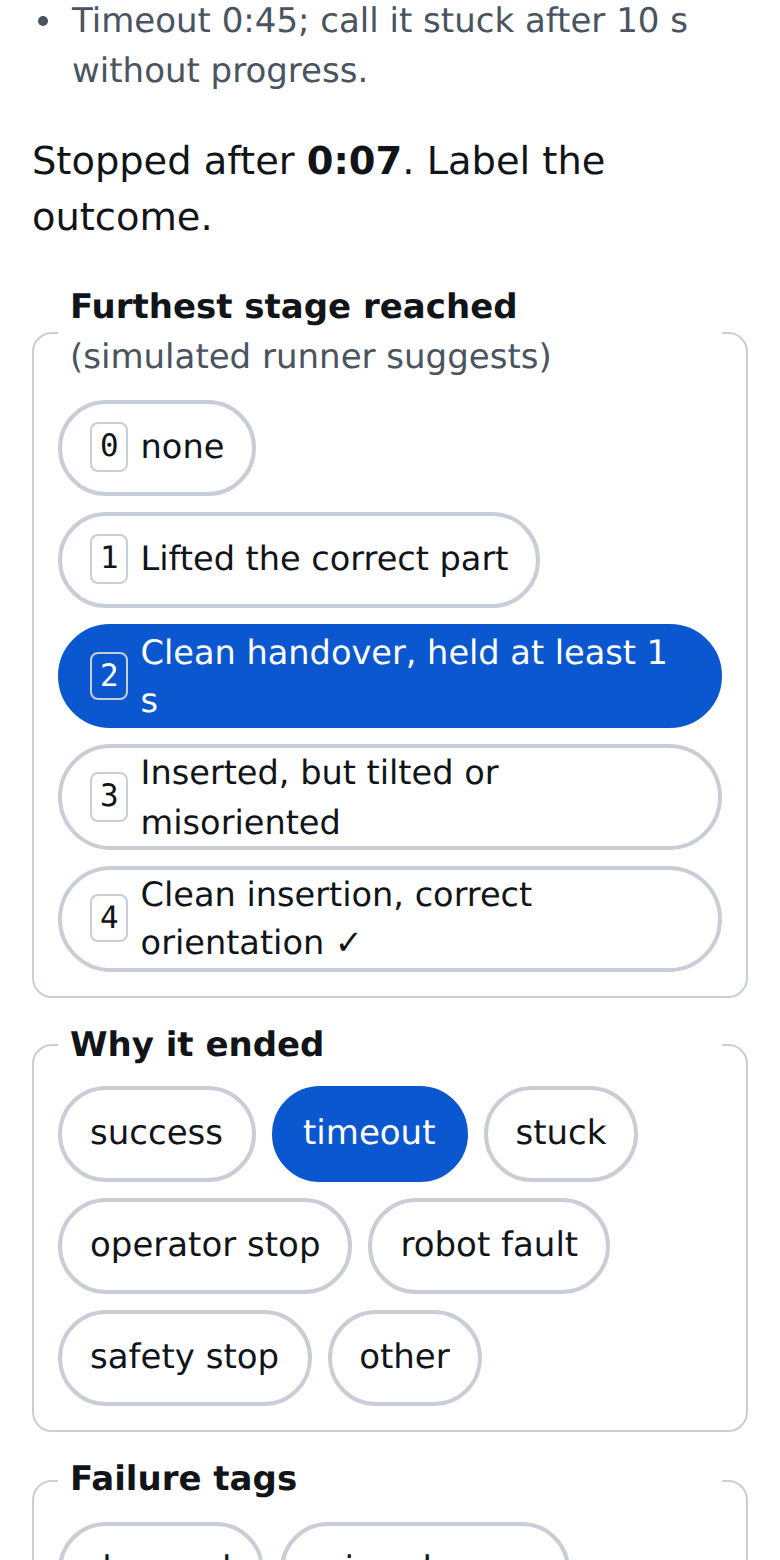
- During: a randomized, blinded schedule, and a phone-friendly operator console that records the outcome, the furthest stage reached and the failure mode of each rollout.
- After: the right statistics for the design (exact tests, paired analyses, multiplicity control), honest wording, and a self-contained report.
30-second demo
$ uvx fieldtrial compare 74/80 91/120
Arm 1: 74/80 = 92.5% (95% CI 84.6%–96.5%)
Arm 2: 91/120 = 75.8% (95% CI 67.4%–82.6%)
Difference +16.7 pp, Newcombe 95% CI [+6.2 pp, +26.0 pp]
Boschloo p = 0.0020 (two-sided); rejects H0 at α = 0.05
Fisher p = 0.0022

$ uvx fieldtrial power --p1 0.76 --p2 0.90      # rollouts needed to detect 76% → 90%
112 per arm (pooled-z)

$ uvx fieldtrial demo                           # a simulated study in the console
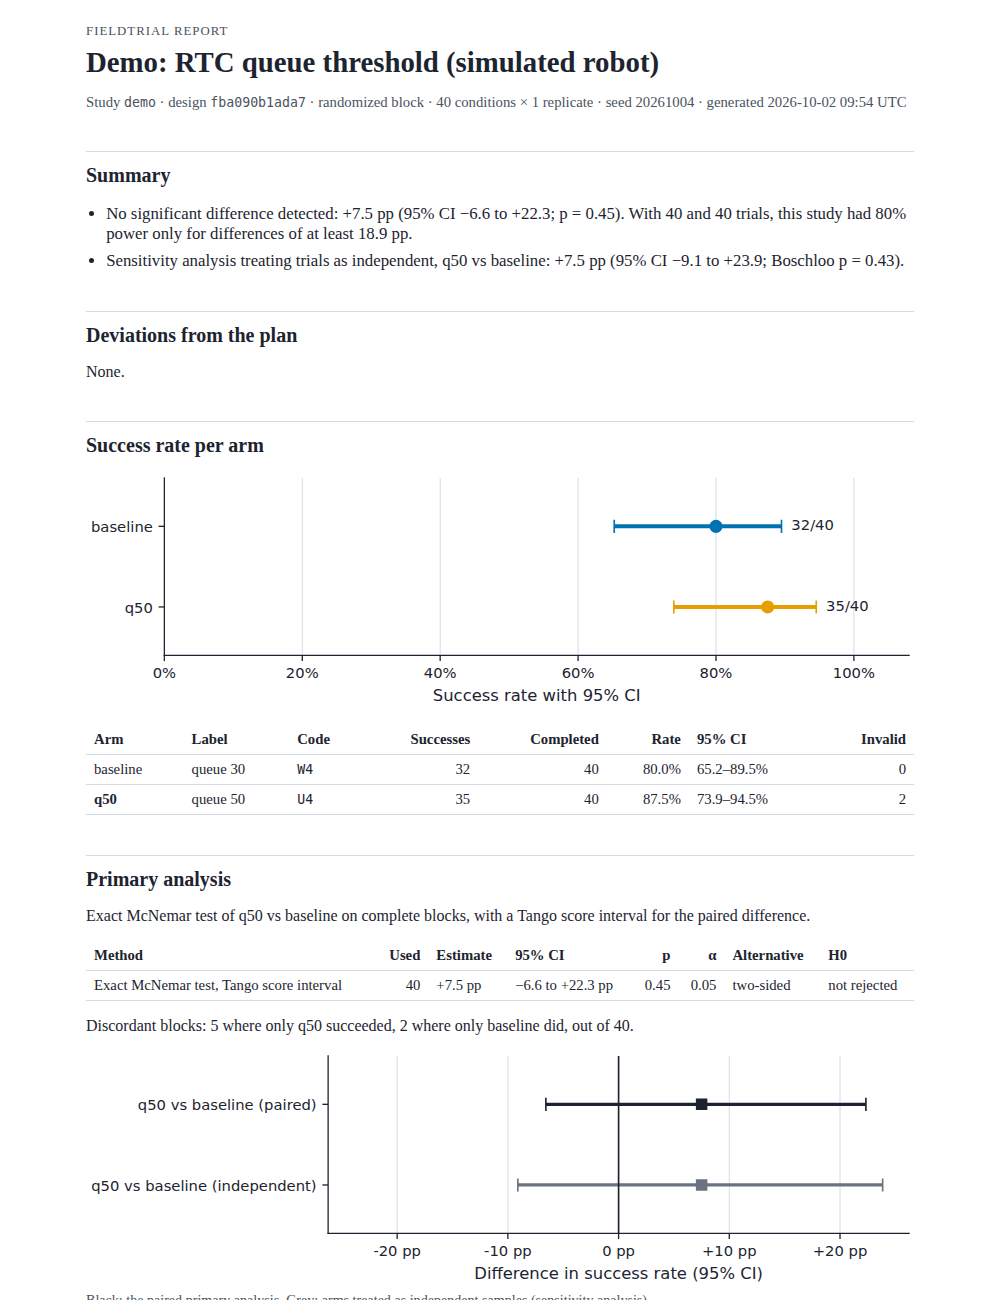
fieldtrial demo opens a half-run, blinded study with a simulated robot. Run the rest
from the keyboard (Space, Space, Enter), unblind, and read the report.
Quickstart
$ uv tool install fieldtrial              # or: pip install fieldtrial
$ fieldtrial init my-study                # writes my-study/study.yaml
$ fieldtrial plan my-study --baseline 0.75
$ fieldtrial lock my-study                # freezes the design and randomizes the schedule
$ fieldtrial serve my-study --lan         # scan the QR code with a phone at the robot
$ fieldtrial unblind my-study
$ fieldtrial report my-study              # my-study/reports/report.html
A study is one folder: study.yaml (the design) and a SQLite database. Everything is
local and works offline; fieldtrial sends no telemetry.
- Documentation: quickstart, concepts, guides and a statistics reference.
- Re-analysis of Dream Machines' published pi0.5 results: which of 30 published comparisons the data actually resolve.
What you get
-
Design:
- randomized complete blocks with balanced arm order
- crossover rounds for tasks whose scene carries over
- checkpoint ladders
- planned interim looks with early stopping
- blind codes, a design hash, locking and logged amendments
-
Real blinding: a command runner that launches your rollout command for each arm, and an openpi router that sends each trial's requests to that arm's policy server.
-
Console: sessions with a rig checklist, a timer, stage and failure-tag labels, 10-second undo, invalid trials with automatic rescheduling, a live mirror screen, keyboard and foot-pedal keys, LAN access with a QR code.
-
Evidence: an evaluation camera that records every trial, rig checks against a reference photo, and links from trials to LeRobot dataset episodes (with DAgger interventions).
-
Analysis: the primary test follows from the locked design:
- exact McNemar with a Tango interval, Cochran–Mantel–Haenszel, or Cochran's Q with Holm
- group-sequential boundaries
- the association of success with training step, and plateau detection
- a period-adjusted crossover test
Every analysis also gets an independent-samples sensitivity analysis, stage funnels, time to success, drift checks and a list of every deviation from the plan.
-
Reports: self-contained HTML with charts, Markdown for pull requests, and a versioned JSON results model.
-
Integration: a REST API with a dependency-free Python client for custom runtimes, CSV import and export, and
fieldtrial.statsas a library.
Every statistical function is tested against an independent reference implementation. Reports only describe a difference when the pre-registered test rejects; otherwise they say what the study could have detected.
How it fits with LeRobot and openpi
fieldtrial complements LeRobot and openpi and never forks them. It is not a training
framework, a simulation benchmark, a robot driver, a labeling platform or a cloud
service. In manual mode, fieldtrial schedules and records the trials and you run the
robot however you like. For real blinding, the command runner launches your rollout
command (for example lerobot-rollout) for each arm, and the openpi_router runner
routes an openpi client's traffic to each trial's policy server; see
Real blinding with runners.
How to cite
If fieldtrial helps your research, please cite it (see CITATION.cff):
@software{benko_fieldtrial,
  author  = {Benko, Rok},
  title   = {fieldtrial: statistically rigorous real-world evaluation for robot policies},
  url     = {https://github.com/rokbenko/fieldtrial},
  license = {Apache-2.0}
}
For evaluation practice in general, see Kress-Gazit et al. (2024), Robot Learning as an Empirical Science: Best Practices for Policy Evaluation, arXiv:2409.09491.
Development
See CONTRIBUTING.md.
1 maintainer

Metadata
1 maintainer
Release files for fieldtrial 0.2.0rc1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| fieldtrial-0.2.0rc1.tar.gz | 283.4 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| fieldtrial-0.2.0rc1-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 535.3 kB
Release files / fieldtrial-0.2.0rc1.tar.gz
| Download URL | fieldtrial-0.2.0rc1.tar.gz |
|---|---|
| Size | 283.4 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
c7abb414cbd362fdd2cfd3639e482259af48a7eeb55a029ff2b7636a389dd6c7
|
|
BLAKE2b-256 checksum How to use checksums |
60b9c61b3a191abf37b9e200223bb748a73590c00a17a6eb039b77235441b19b
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.12.12
|
Release files / fieldtrial-0.2.0rc1-py3-none-any.whl
| Download URL | fieldtrial-0.2.0rc1-py3-none-any.whl |
|---|---|
| Size | 251.9 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
a300398d4d8409732e8a2b5b037fd050424f946bc20a365589a00df1a6e47357
|
|
BLAKE2b-256 checksum How to use checksums |
9bc087ed3da7d87b39325a6b096ef361a8822c5b5f567612fbe3d82882f4d963
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.12.12
|














