
Grafito CANStepper
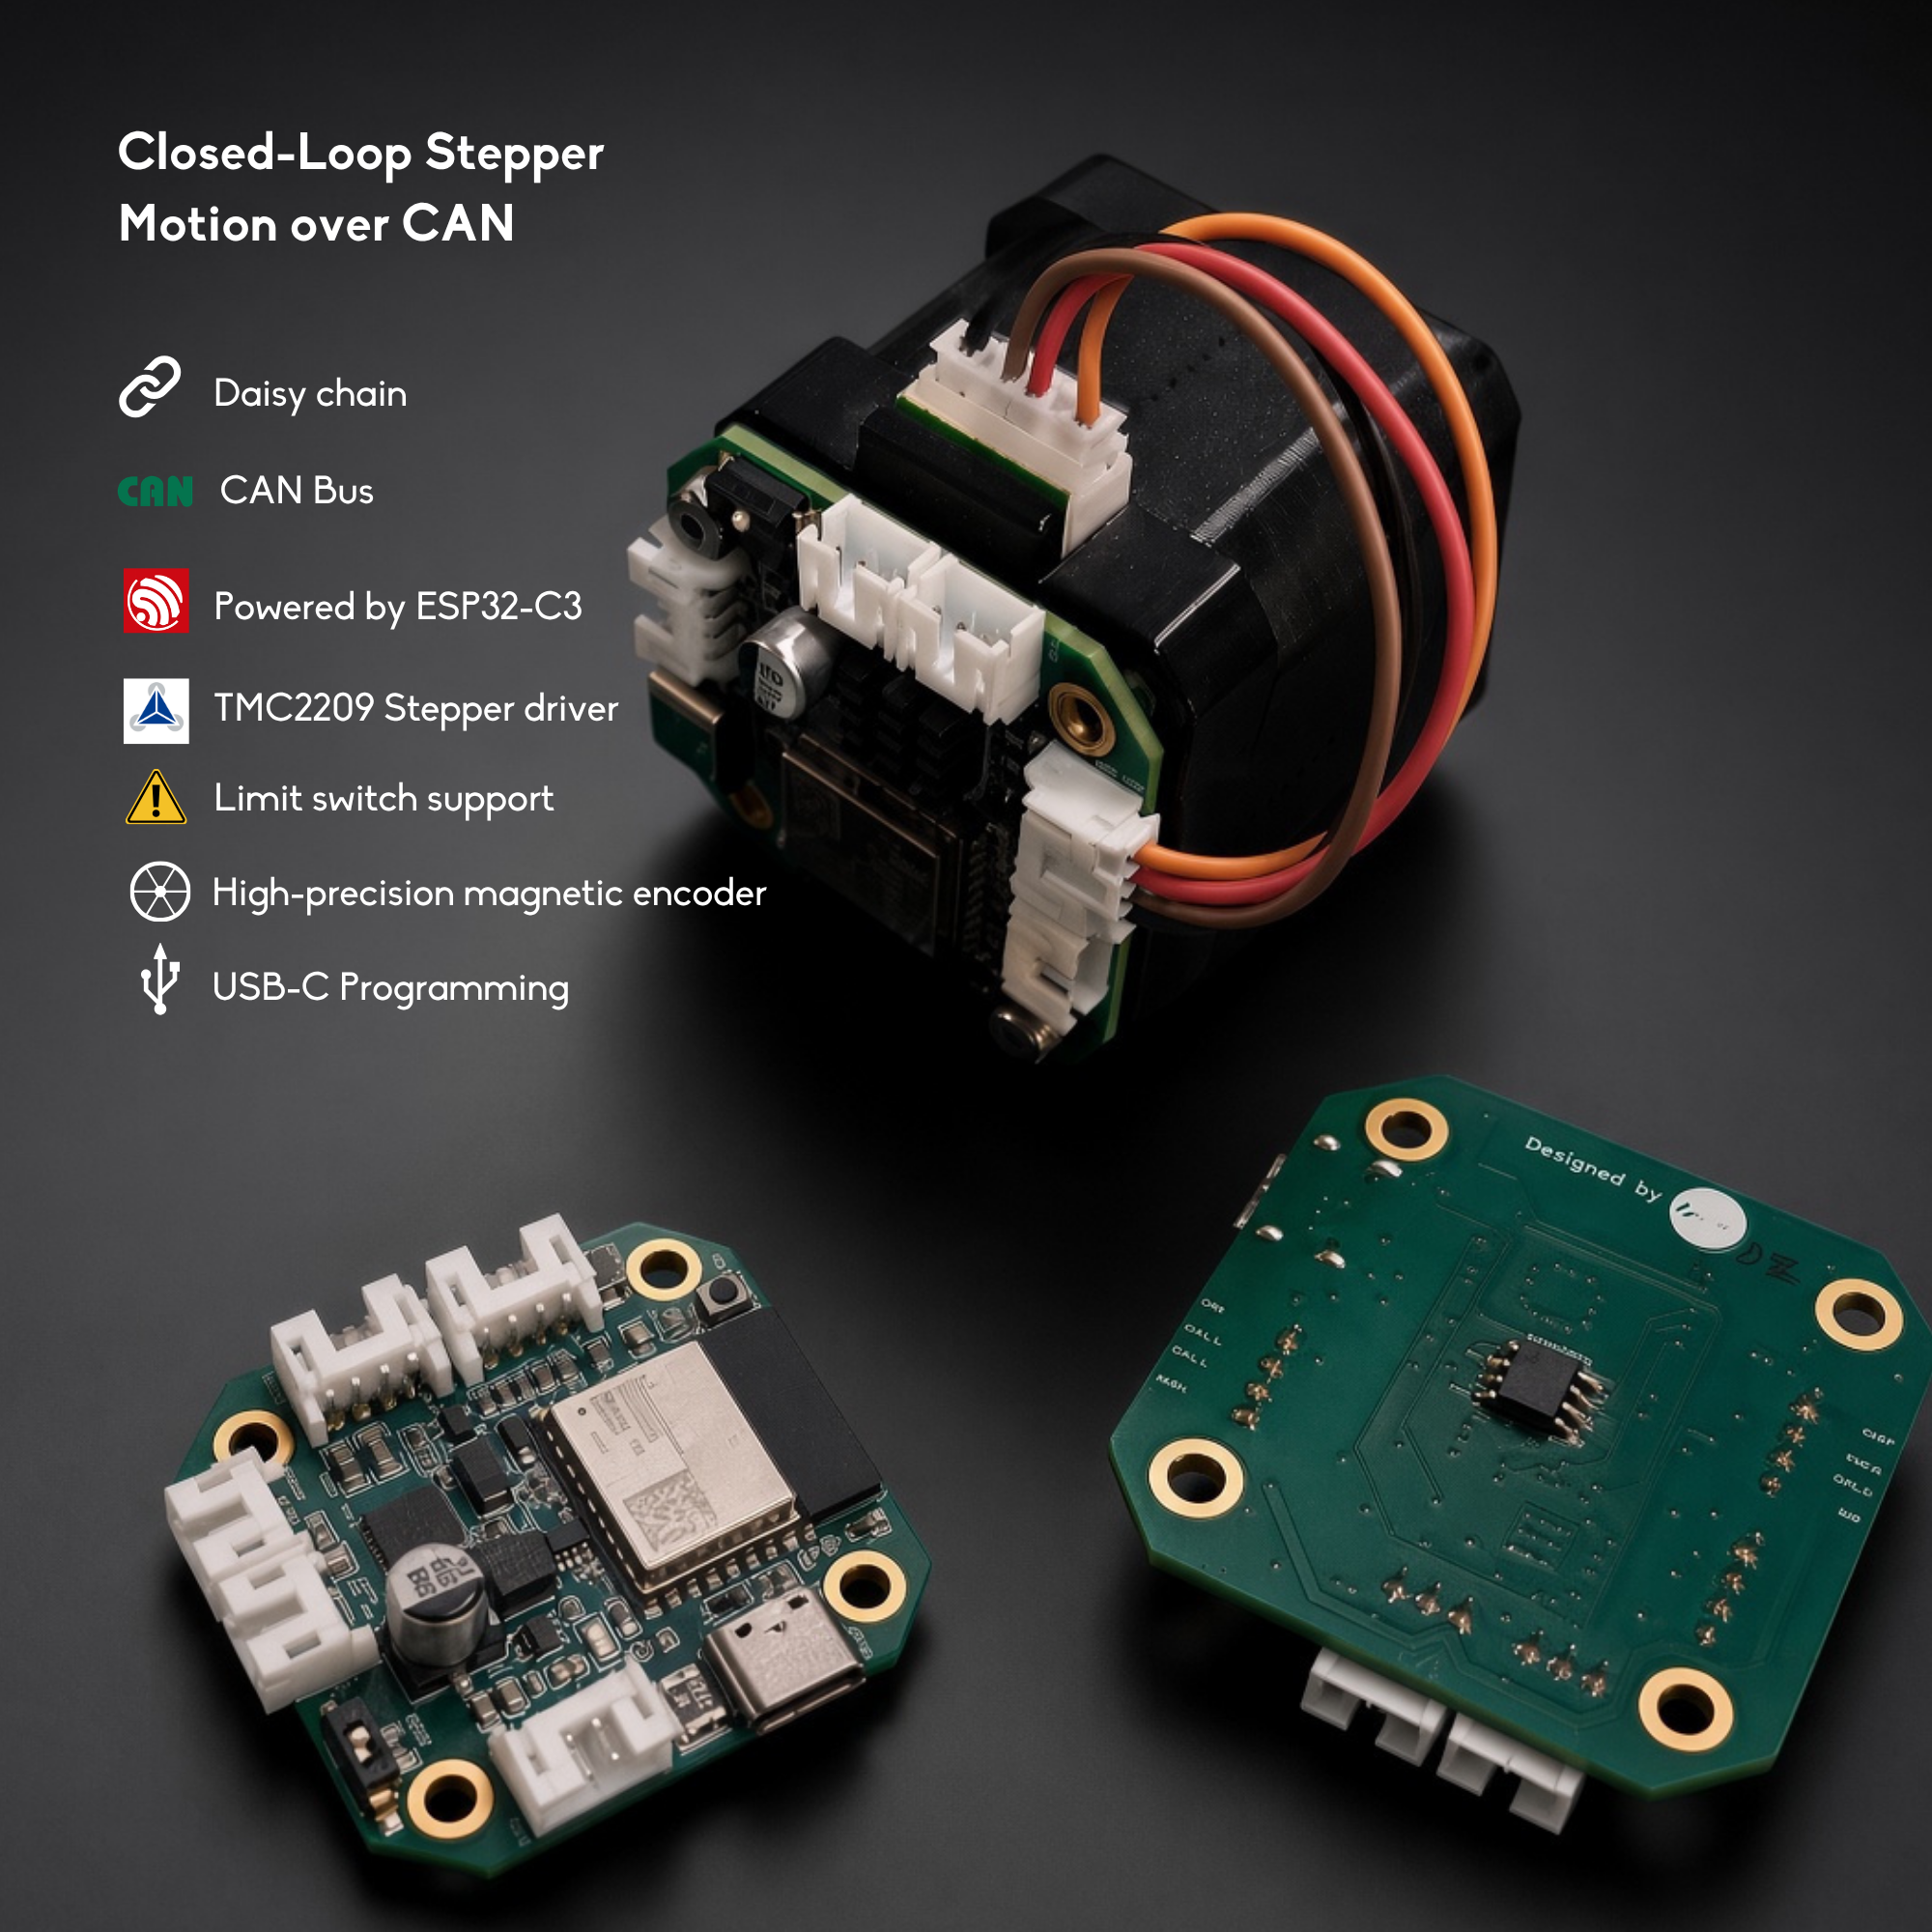
Closed-loop stepper motor control over CAN. Each board carries an ESP32-C3, a TMC2209 driver, an MT6701 14-bit magnetic encoder and a CAN transceiver; up to 31 boards daisy-chain on one 1 Mbps bus and are driven from Python through the USB port of any board on the chain.
├── canstepper/                              # Python package (grafito-canstepper)
├── firmware/GrafitoCANStepper_C3/           # node firmware (GCSP v1, fw 1.12)
├── firmware/GrafitoCANStepper_C3_CANopen/   # optional CiA 301/402 SKU (fw 2.1)
├── examples/                                # runnable examples + machine.toml
├── tests/                                   # pytest suite (runs on a software sim)
├── model_assets/                            # assembly render, PCB drawing, STEP CAD
└── docs/                                    # protocol, quickstart, CAD index
Product links
- Shop / brochure: CANStepper Adapter Board
- Amazon (India): https://www.amazon.in/dp/B0H8XZ6V99
- Docs: https://docs.grafito.in
- Board test station: https://docs.grafito.in/dashboard
- Mechanical CAD & drawings: https://docs.grafito.in/docs/mechanical-cad
- PyPI: grafito-canstepper
CAD and brochure files in this repo (model_assets/):
| File | Description |
|---|---|
CANStepper.png |
Product photo (also at repo root) |
CANStepper_pinout.png |
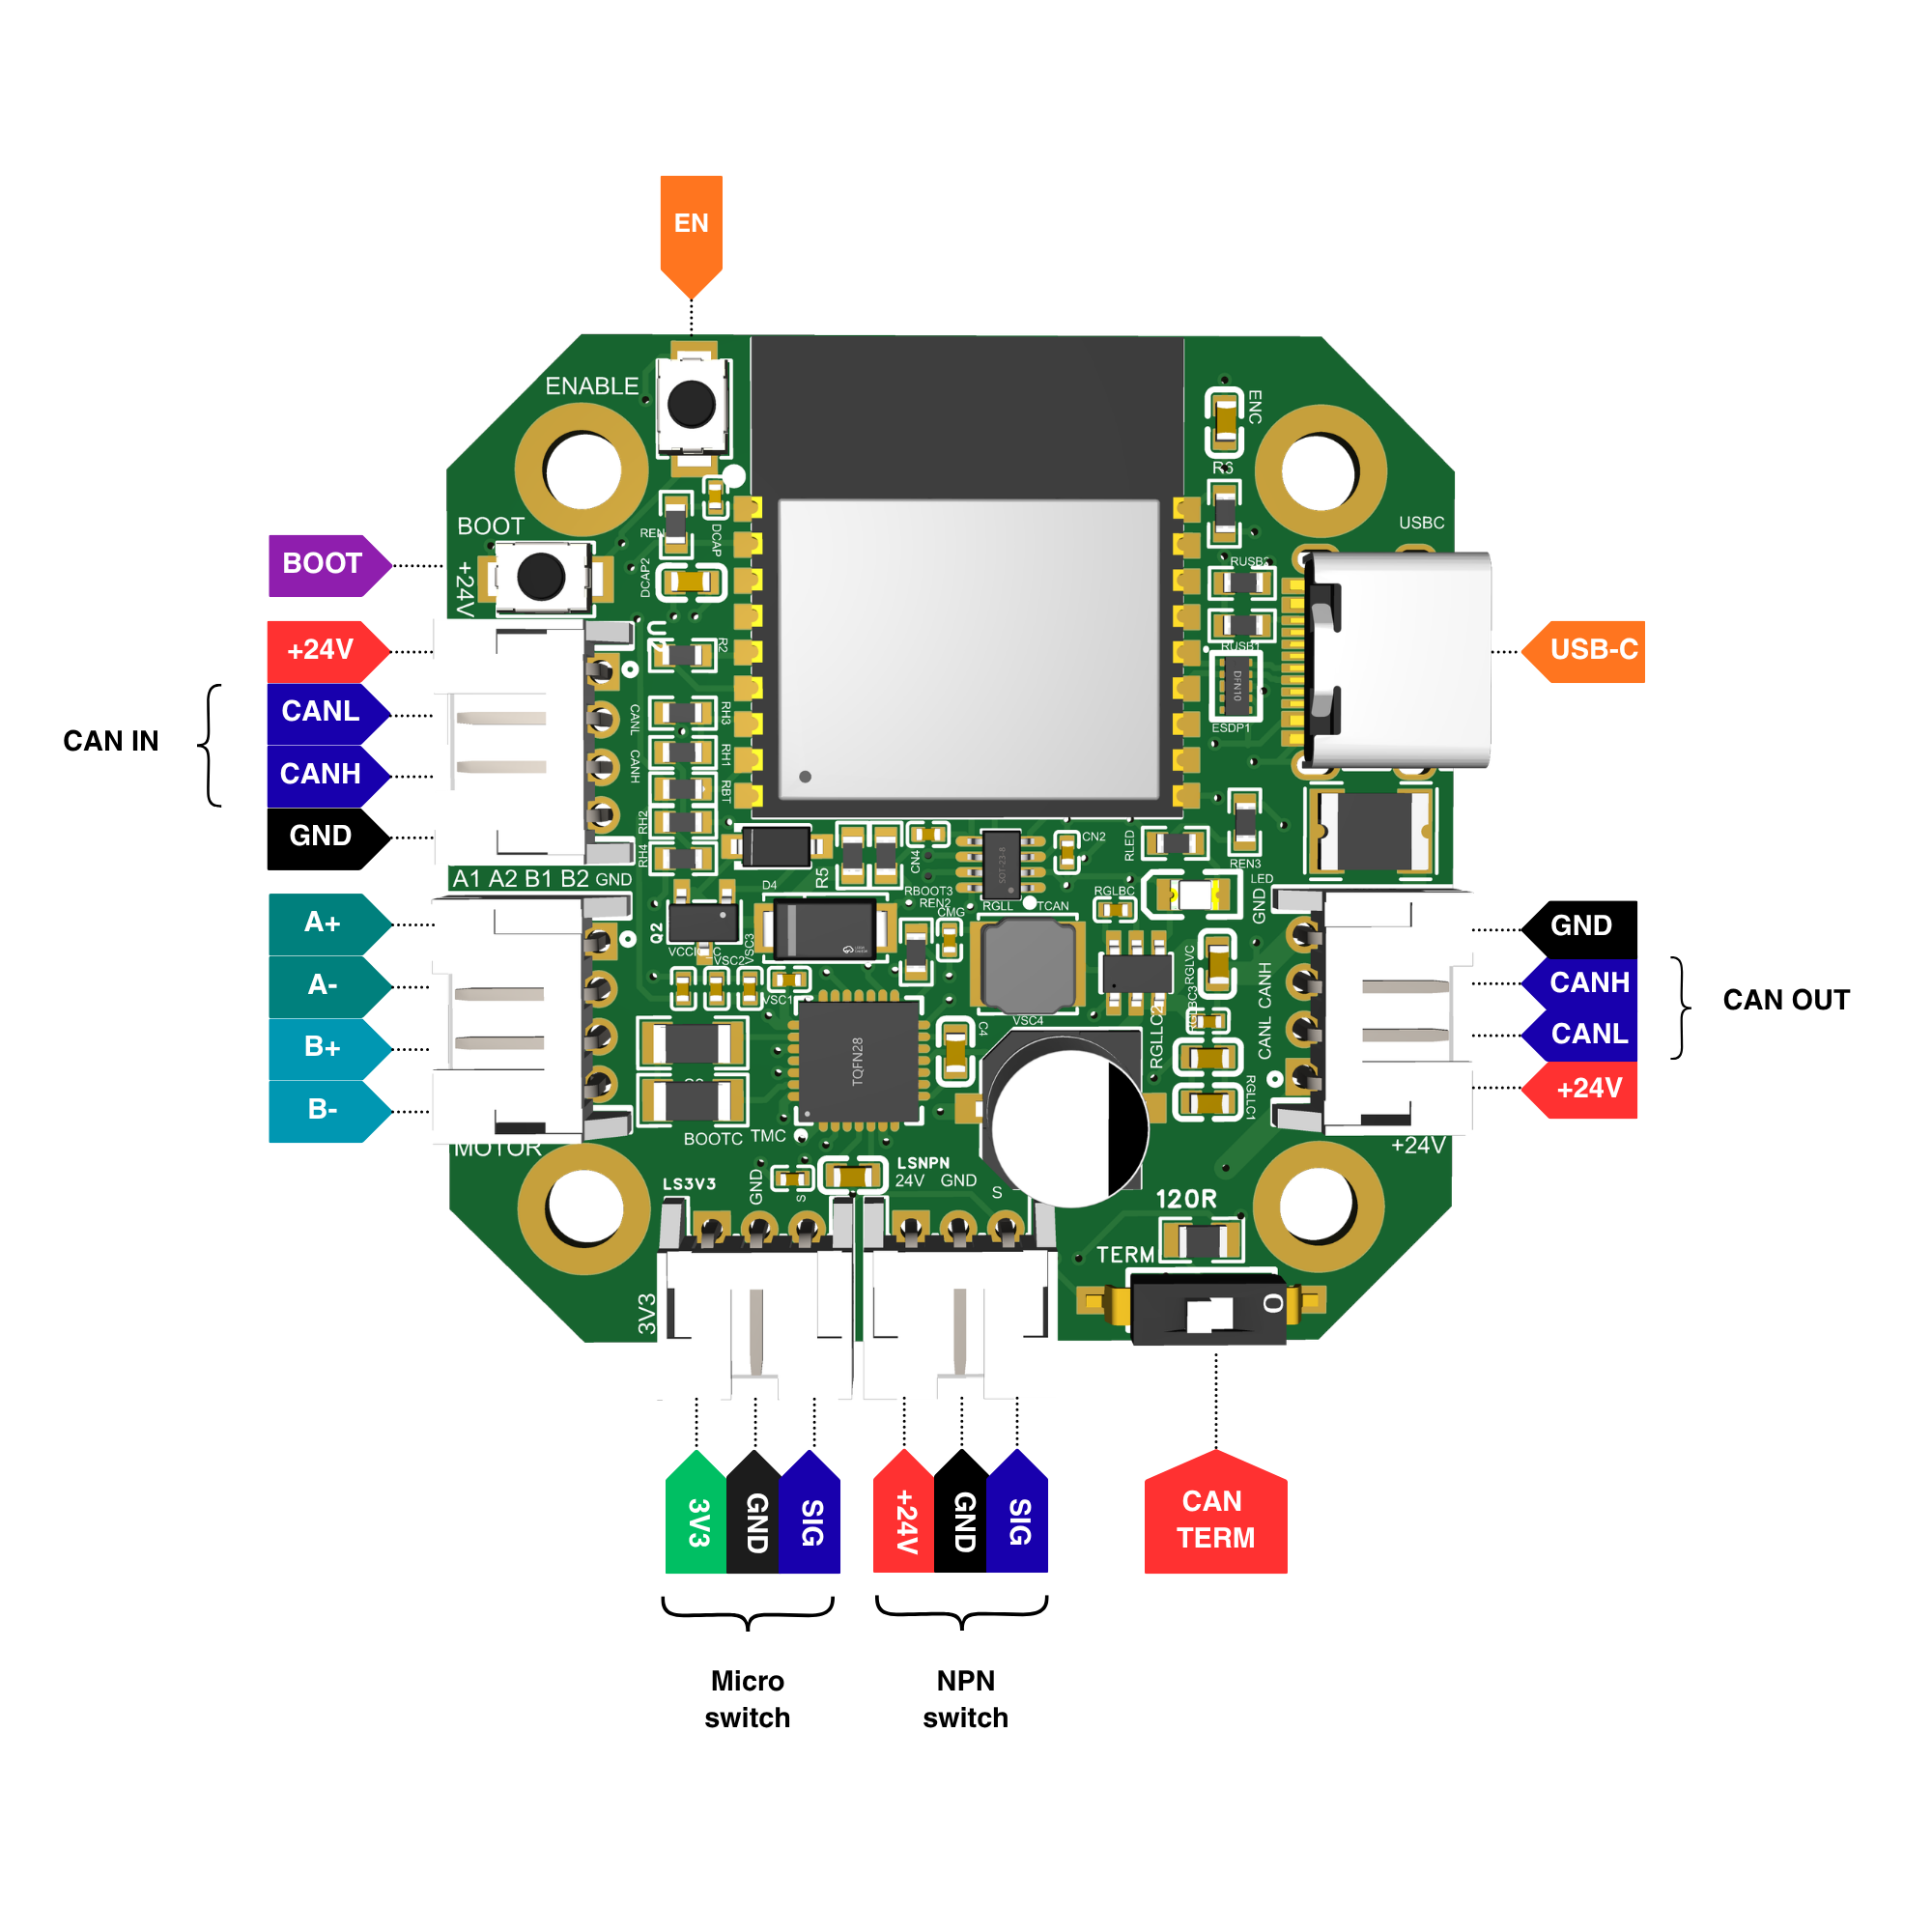
Connector / pinout diagram |
CANStepper_multiaxis_can.png |
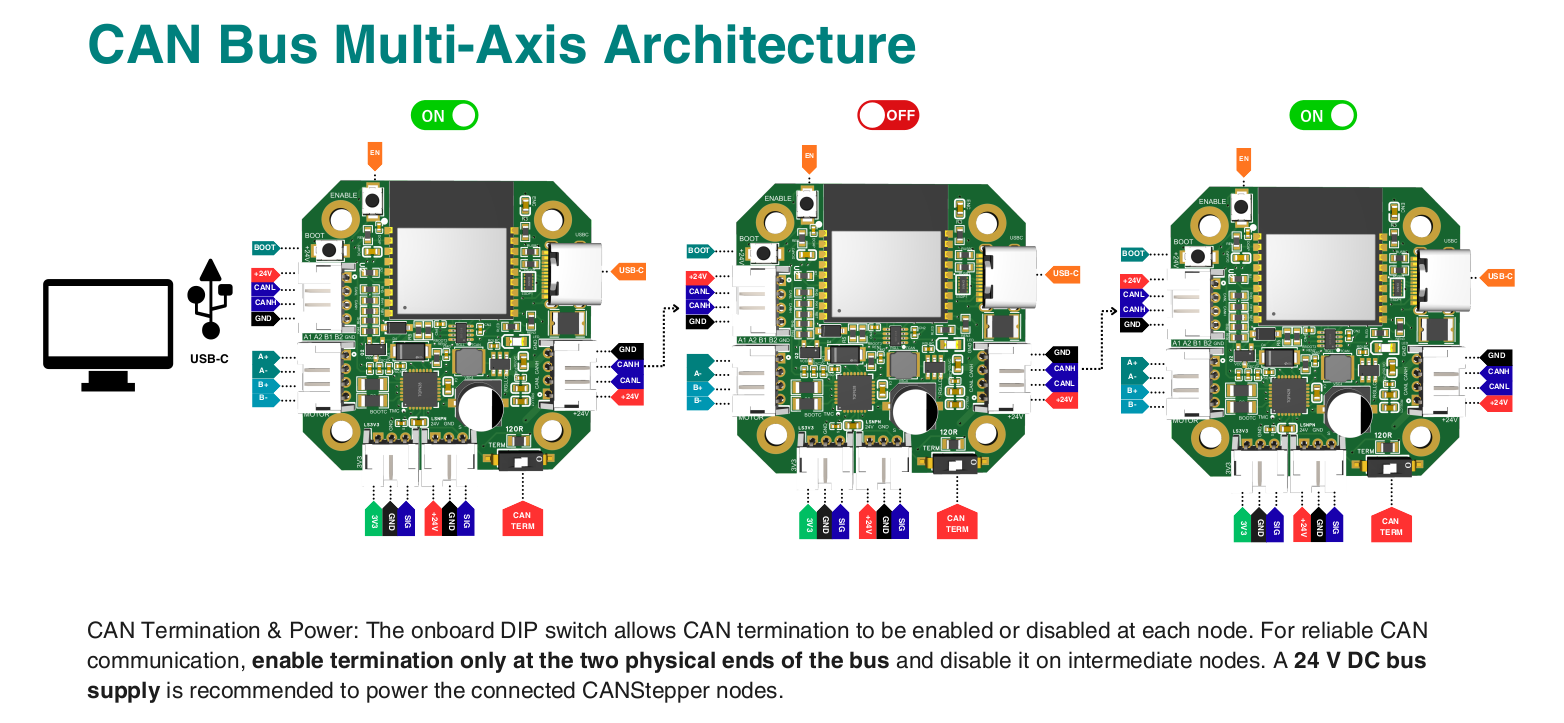
Multi-axis CAN bus demonstration |
CANStepper_V1_assembly.mp4 |
V1 board assembly video (historical) |
CANStepper_V1_assembly_preview.jpg |
Preview frame for the V1 video |
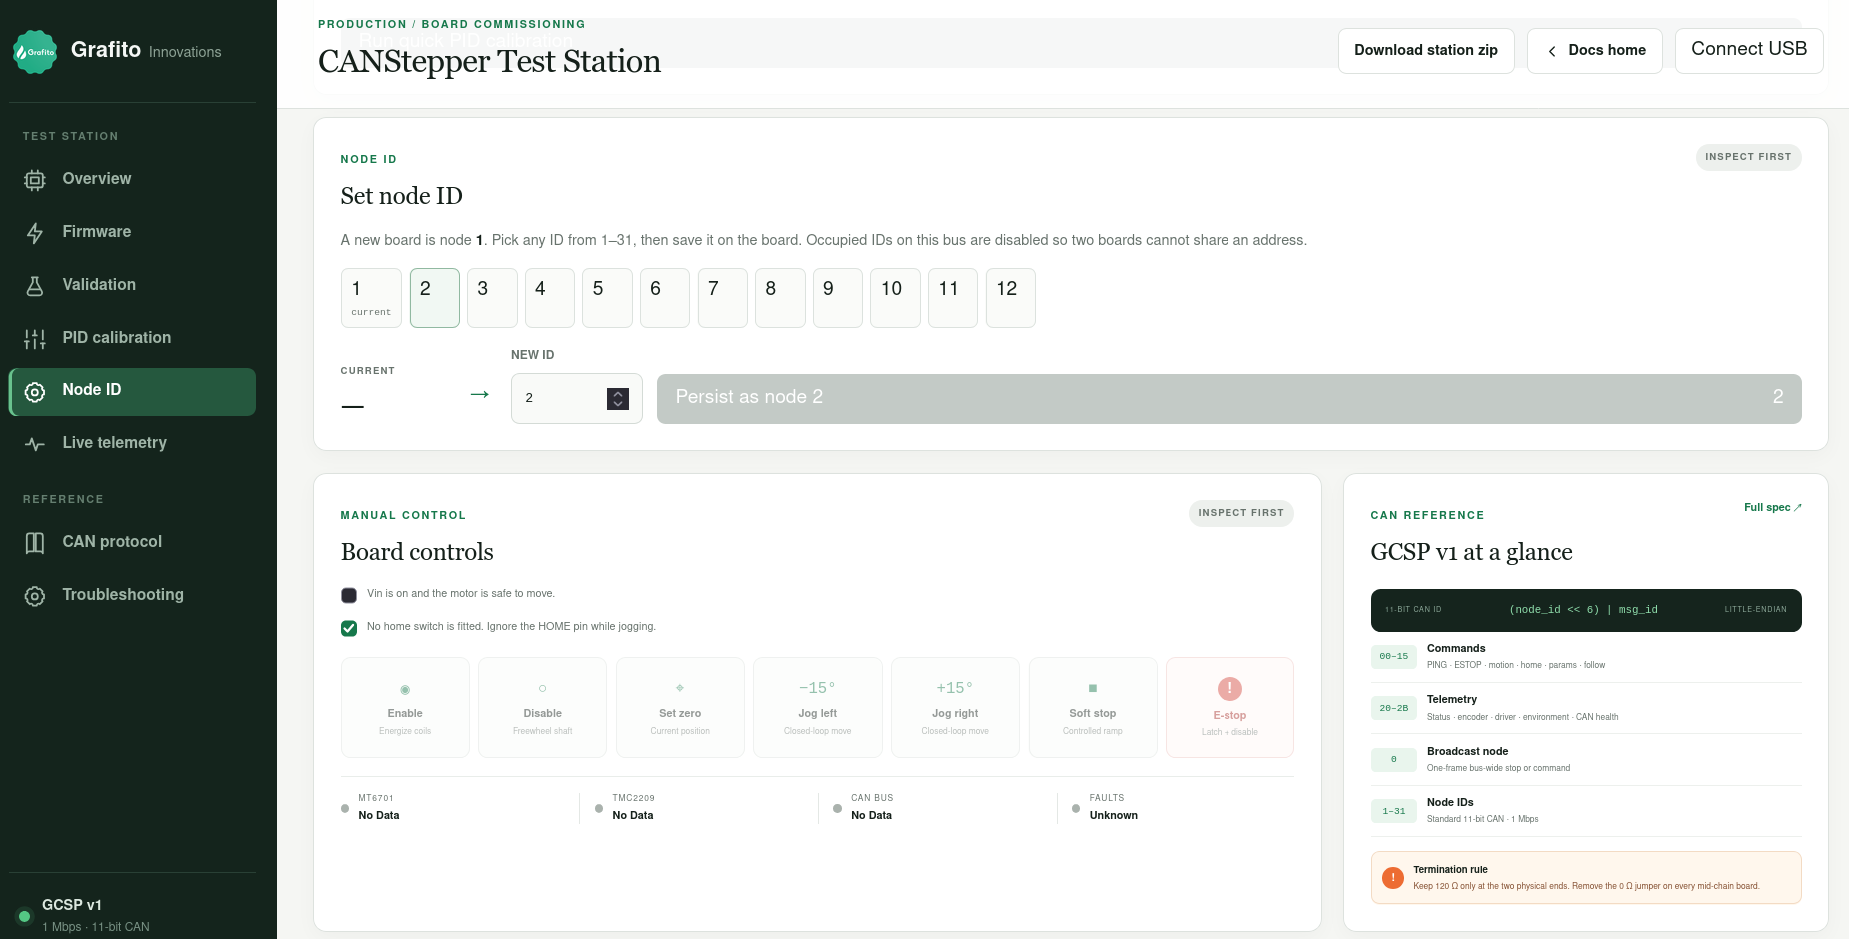
CANStepper_test_station.png |
Board Test Station (after USB connect) |
CANStepper_block_diagram.png |
System block diagram |
CANStepper_V2_Assembly.webp |
V2 assembly render |
Drawing_CANStepper_V2.pdf |
V2 PCB mechanical drawing |
CANStepperV2_3D_PCB.step |
V2 PCB STEP |
CASING_MOUNT.step |
Casing / mount STEP |
Heat_Spreader.step |
Heat spreader STEP |
TMC2209 UART Stepper Driver - Heat_Sink.step |
TMC2209 heatsink STEP |
canstepper-brochure-v2.pdf |
Product brochure |
V1 board assembly (click the preview to play the video):
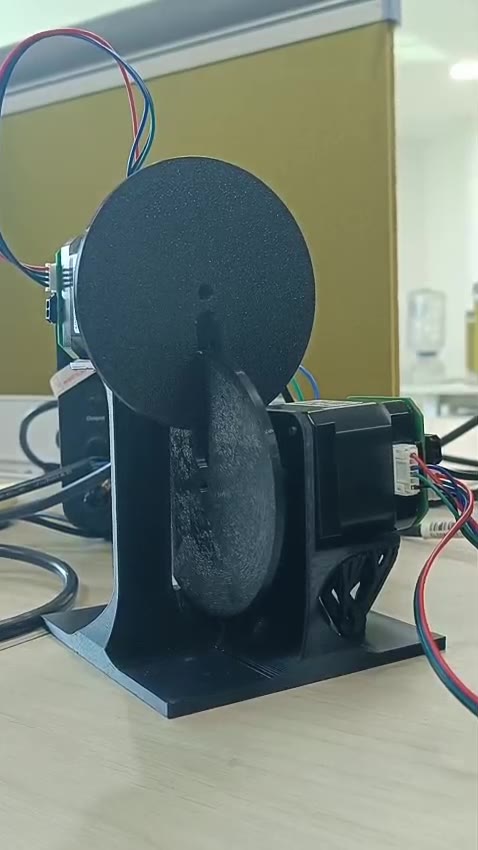
This clip is version 1 of the same board. V1 used three different connector types, which made cabling and crimping difficult. The current production board is V2, with JST 2.0 connectors throughout for easy crimping.
Important — encoder magnet: Fit a diametrical magnet on the motor shaft. The magnet polarity must be radial, not axial. An axial magnet will not produce a valid MT6701 angle and closed-loop control will fail.
After USB and Vin are connected, test the board in the CANStepper Test Station — set the node ID, enable the driver, jog, and check encoder / TMC / CAN telemetry.
Highlights
- Layered Python API — raw frames →
StepperNode→NodeGroup→Axis(mm units viarotation_distance) →DualMotorAxis/IndependentDualAxis/Cartesian/CoreXY/MotionGroup→ declarativemachine.toml. - Safety scopes —
node.estop(),group.estop(),bus.estop_all()(single broadcast frame); e-stop is latched until re-enabled. - Homing — physical endstop on IO8, sensorless (StallGuard), or set-zero; configurable current, backoff and timeout.
- Closed loop — firmware ≥1.12 plans a rest-to-rest S-curve trajectory with velocity + acceleration feedforward and a light tracking PID on the MT6701 encoder (optional encoder LUT). All motion limits are configurable defaults, never hard clamps.
- On-bus leader/follower — dual-motor gantries stay coupled with no
host in the loop (
DualMotorAxis). - Encoder-gated dual screws —
IndependentDualAxiscommands both motors independently and blocks the next pass until both encoders are within mm tolerance of the target. - Simulator included —
canstepper.sim.SimNetworkimplements the whole protocol in software; the test suite and the examples run without hardware.
Install & first spin
pip install grafito-canstepper

# Development (from this directory):
# pip install -U pip setuptools && pip install -e ".[dev]"
from canstepper import CANStepperBus

with CANStepperBus.serial("/dev/ttyACM0") as bus:
    print(bus.discover())
    node = bus.node(1)
    node.set_run_current(40).enable()
    node.move_to(360.0, blocking=True)
Continue with:
- docs/quickstart.md — first motion
- docs/closed_loop_tuning.md — trapezoid + v_ff
- docs/protocol.md — GCSP v1 wire protocol
- docs/mechanical_cad.md — CAD, drawings, assembly video
G-code examples (from this directory):
PYTHONPATH=. python3 examples/gcode_cartesian.py /dev/ttyACM0 1 2
PYTHONPATH=. python3 examples/gcode_corexy.py /dev/ttyACM0 1 2
PYTHONPATH=. python3 examples/gcode_from_file.py examples/gcode/square.gcode
Homing examples (IO8 endstop, StallGuard sensorless, set-zero):
PYTHONPATH=. python3 examples/home_endstop.py /dev/ttyACM0 1 -1
PYTHONPATH=. python3 examples/home_sensorless.py /dev/ttyACM0 1 -1 60
PYTHONPATH=. python3 examples/home_set_zero.py /dev/ttyACM0 1
Belt axis (mm):
PYTHONPATH=. python3 examples/belt_move_mm.py /dev/ttyACM0 1 50 77.2 150
Development
python3 -m pytest
Current GCSP firmware is 1.12 (S-curve + Ka + LUT; motors off at boot
until enable()). Optional CANopen 2.1 lives in
firmware/GrafitoCANStepper_C3_CANopen/ with GrafitoCANStepper.eds and
GrafitoCANStepper_Node1.dcf / GrafitoCANStepper_Node2.dcf
(FileRevision 2, identity 0x00020100). Discard any older 2.0 EDS — it
will not import this board. Node 2 must be flashed with
-DCO_FACTORY_NODE_ID=2. See https://docs.grafito.in/docs/canopen.
Do not mix GCSP and CANopen on one bus.
Firmware builds with Arduino IDE or arduino-cli (ESP32C3 Dev Module, USB
CDC On Boot = Enabled; libraries: FastAccelStepper, TMC2209 janelia-arduino).
Apply Vin (5–24 V, typically 24 V) before upload — USB-C is data only and
does not power the ESP32 for programming. CAN termination is on by default
(0 Ω jumper); remove that 0 Ω on mid-chain daisy-chain nodes.
arduino-cli compile --fqbn esp32:esp32:esp32c3:CDCOnBoot=cdc \
  firmware/GrafitoCANStepper_C3
arduino-cli upload -p /dev/ttyACM0 --fqbn esp32:esp32:esp32c3:CDCOnBoot=cdc \
  firmware/GrafitoCANStepper_C3
1 maintainer

Metadata
1 maintainer
Release files for grafito-canstepper 0.2.3
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| grafito_canstepper-0.2.3.tar.gz | 89.9 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| grafito_canstepper-0.2.3-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 171.0 kB
Release files / grafito_canstepper-0.2.3.tar.gz
| Download URL | grafito_canstepper-0.2.3.tar.gz |
|---|---|
| Size | 89.9 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
51355e7e230c9dfafce1b9e8bf203efb0d303f48e8cefdaa1238f2b2cccc0751
|
|
BLAKE2b-256 checksum How to use checksums |
8fb02eb527a8d19c22b7f39a5f338bef586e0a3023c970a63ee7a58616840f37
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.10.12
|
Release files / grafito_canstepper-0.2.3-py3-none-any.whl
| Download URL | grafito_canstepper-0.2.3-py3-none-any.whl |
|---|---|
| Size | 81.1 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
4401ca694da384fffa9f5238a06851b8a76a2f392efb2bb126a10f584391f7a0
|
|
BLAKE2b-256 checksum How to use checksums |
3d3c2f108ebf24eb2b976134dfaa594949c92cf0c87d1ef5afecbc5c8ef711d2
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.10.12
|














