
This release is a pre-release and may not be stable for production use.
Realistic granular assets generator for Physical AI.


Granulaire generates sand, gravel, pebbles, seeds, fruit, pellets, rubber mulch and packing peanuts with realistic, measured shapes, sizes, masses and moisture, and exports them to OpenUSD. It is built for Physical AI: robots trained and tested in simulation (reinforcement learning, virtual test campaigns, sim-to-real) need ground that looks and behaves like the real thing, not perfect spheres, and perception models need synthetic images with exact ground truth. Everything can run on CPU; see Physics limits by grain size for what current engines can simulate.
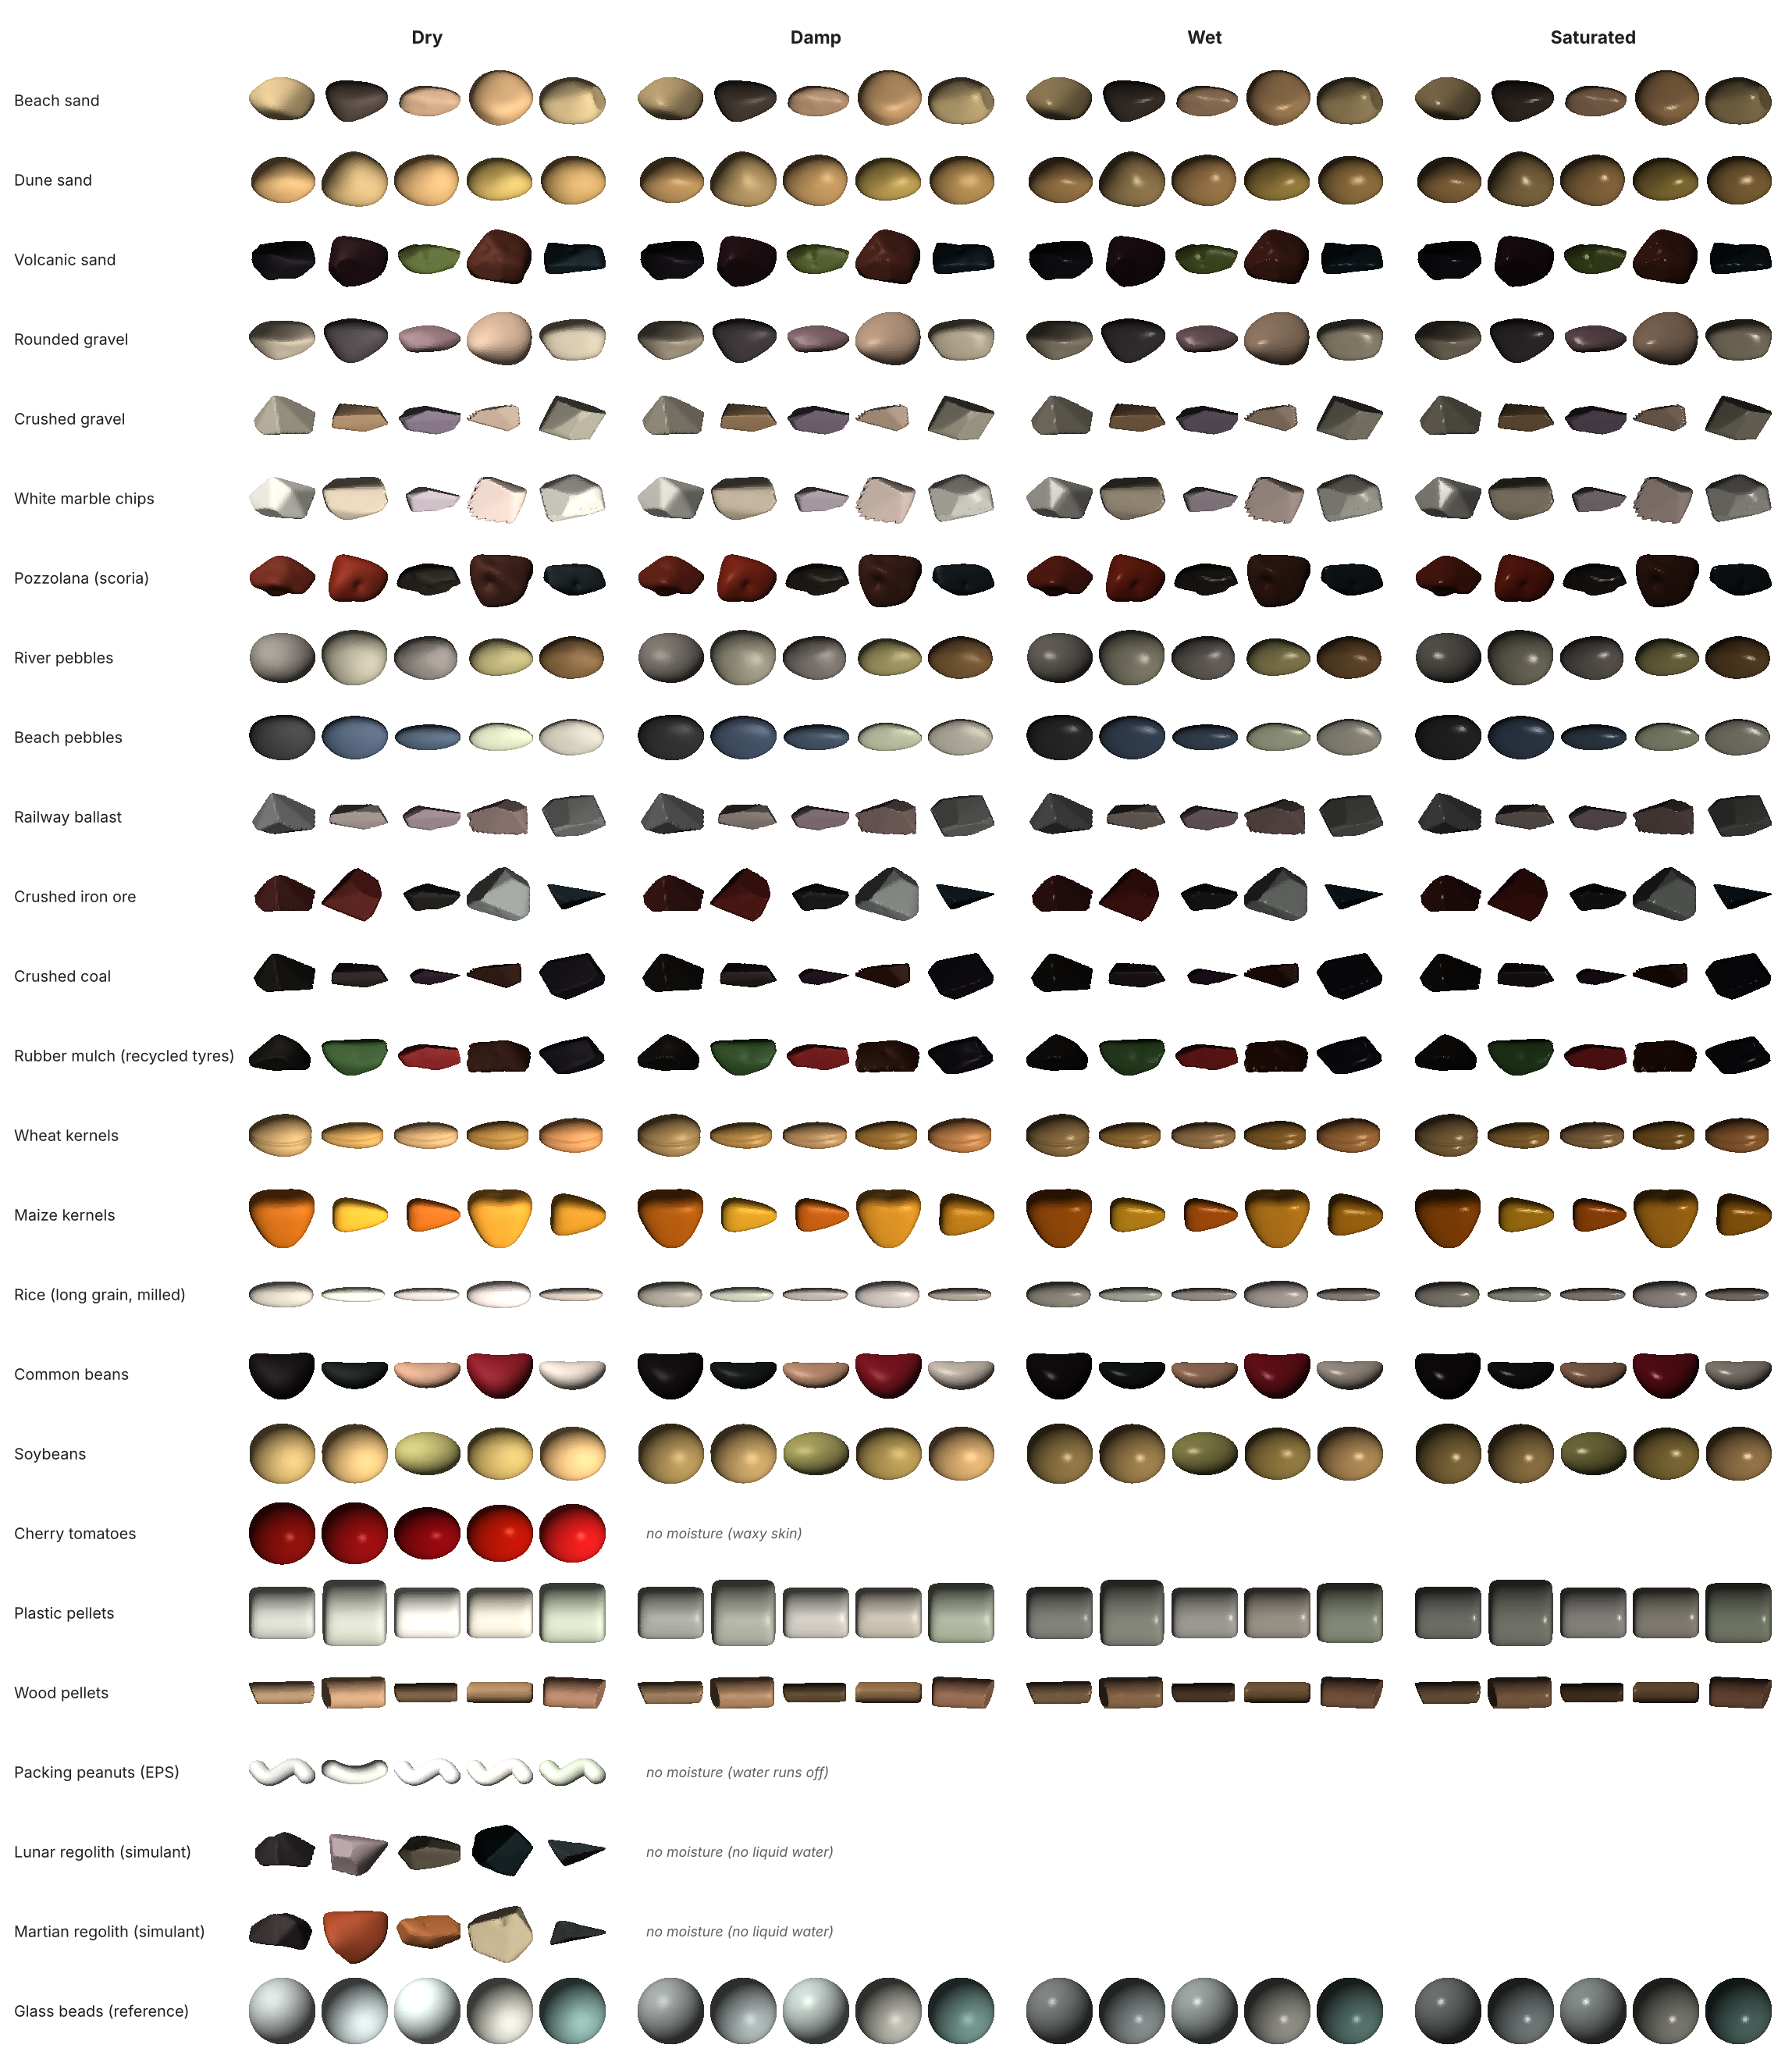
Five different grains of each of the 25 presets, dry, damp, wet and
saturated, rendered from the generated meshes. Each grain is drawn at its own
scale: sizes range from 0.07 mm (lunar regolith) to ~5 cm (river pebbles).
Regenerate with granulaire render-gallery (see Usage).
What it does
- Generates N distinct grain shapes (100 by default) from distributions borrowed from sedimentology: size on the phi scale (Wentworth), Zingg ratios (elongation I/L, flatness S/I), angularity, irregularity (fracture faces, lumps, pits) and mineralogy. Kernels, seeds and pellets use their own shape families (superellipsoids, cylinders).
- Places each shape several times in shuffled order with random orientations: by default 100 shapes × 5 copies = 500 grains per scene (see Scene size and mixing).
- Measures every generated grain (nominal diameter, Zingg ratios, Wadell sphericity, convexity, angularity proxy) instead of trusting the inputs.
- Exports an OpenUSD scene: prototypes, grains by reference, UsdPreviewSurface
materials,
UsdPhysicsrigid bodies (mass from volume and density, convex-hull collision, friction, restitution) and a collision ground. - Optionally gives every grain a moisture state through an OpenUSD variant set.
- Exports packing peanuts and cherry tomatoes as deformable bodies. Deformable simulation works only with NVIDIA OmniPhysics (Omniverse, Isaac Sim 5+) and is not tested yet; see Deformable grains.
Installation
From PyPI:
pip install "granulaire[render]"
From a clone, for development:
python -m venv .venv && source .venv/bin/activate
pip install -e ".[render]"        # add ",dev" for tests and linting
Requires Python 3.10+.
Usage
granulaire list
granulaire generate --preset beach_sand          # 100 shapes × 5 copies, shuffled
granulaire generate --preset beach_sand --shapes 20 --copies 10 --no-shuffle --seed 3
granulaire generate --preset beach_pebbles --moisture --moisture-weights 0,20,50,30
granulaire generate --preset rounded_gravel --no-size --no-orientation
granulaire render output/beach_sand output/crushed_gravel
granulaire render-moisture output/beach_pebbles output/crushed_gravel output/beach_sand
granulaire render-gallery output/beach_sand output/crushed_gravel --grains 5
The README gallery comes from generating every preset with --moisture, then
granulaire render-gallery on all 25 output folders in category order, with
--output docs/images/moisture_gallery.png.
python -m granulaire ... works too. From Python:
from granulaire import Variations, generate_scene, write_outputs

# defaults: 100 shapes × 5 copies, shuffled, seed 1; moisture turned on
sand = generate_scene("beach_sand", variations=Variations(moisture=True))
write_outputs(sand, "output")  # -> output/beach_sand/

# 20 shapes × 10 copies, copies side by side, another random draw
gravel = generate_scene("crushed_gravel", shapes=20, copies=10, shuffle=False, seed=3)
write_outputs(gravel, "output")  # -> output/crushed_gravel/
Scene size and mixing
| Option (CLI / Python) | Default | Effect |
|---|---|---|
--shapes N / shapes=N |
100 | number of distinct grain shapes |
--copies K / copies=K |
5 | how many times each shape is placed; the scene has N × K grains |
--no-shuffle / shuffle=False |
shuffled | place the copies of each shape side by side, shape after shape, instead of mixing them, e.g. to compare shapes |
--seed S / seed=S |
1 | random seed; the same options and seed give the same scene |
--shapes and --copies must be at least 1. Turning shuffling off changes
only which shape goes in which slot: shapes, positions and orientations stay
the same.
Presets
| Category | Presets |
|---|---|
| Sand | beach_sand, dune_sand, volcanic_sand |
| Gravel | rounded_gravel, crushed_gravel, marble_chips, pozzolana |
| Pebbles | river_pebbles (rounded, equant, earthy mixed minerals), beach_pebbles (flat discs and ovals, polished basalt and marble) |
| Industrial | railway_ballast, iron_ore, coal, rubber_mulch (shredded recycled tyres: torn, grippy, bouncy nuggets) |
| Agricultural | wheat (kernels with a ventral crease), maize (wedge-shaped dent kernels), rice (long grain, milled), beans (kidney-shaped, mixed varieties), soybean, cherry_tomatoes (glossy skin, stem scar): deformable, NVIDIA OmniPhysics only (rigid elsewhere with --no-deformable), no moisture (waxy skin) |
| Pellets | plastic_pellets (PE/PP, ~3.4 mm), wood_pellets (6 mm diameter, 10–30 mm long, broken ends) |
| Packaging | packing_peanuts (expanded polystyrene, S or C shaped): deformable, NVIDIA OmniPhysics only (rigid elsewhere with --no-deformable), and no moisture: EPS never gets wet, water runs off |
| Space | lunar_regolith, martian_regolith (no moisture) |
| Reference | glass_beads: exact spheres, the baseline to compare real grains against |
Values are realistic orders of magnitude, not measurements of a specific deposit.
Variations (checkboxes)
| Option | On | Off |
|---|---|---|
--size |
diameter drawn from the grading curve | all at d50 |
--shape |
elongation, flatness and irregularity drawn | mean values |
--roundness |
facets and edge rounding drawn | median values |
--mineralogy |
mineral and tint drawn | dominant mineral |
--orientation |
random orientation | all aligned |
--moisture (off by default) |
variant set + state drawn per grain | no moisture |
Turning one variation off does not change the other random draws: with the same seed you compare the same scene with a single difference.
Moisture (OpenUSD variant set)
Every prototype carries a moisture variant set (dry, damp, wet,
saturated) and every grain selects its own. A state changes:
- mass: a wetter grain is heavier. Each state stores its own mass
(dry mass + water) in
physics:mass, plus the water alone ingranulaire:waterMass; switching the variant switches the mass; - appearance: darker colour, lower roughness, clearcoat (UsdPreviewSurface);
- contact: friction and restitution (one UsdPhysics material per state),
plus capillary cohesion in the custom attribute
granulaire:capillaryCohesion, since UsdPhysics has no standard schema for it.
The water comes from two sources: a surface film, which weighs a lot on small grains (much surface for little mass) and little on pebbles, capped by the water the pores of a heap can hold; and absorbed water, which dominates for porous stone (pozzolana) and for anything that soaks (seeds, beans, wood). Median weight gain of one grain, % of its dry mass:
| Material | Damp | Wet | Saturated |
|---|---|---|---|
| Beach sand | +3.6 % | +14 % | +24 % |
| Pozzolana (porous) | +6.2 % | +17 % | +22 % |
| Crushed gravel | +0.5 % | +1.5 % | +2.2 % |
| River pebbles | +0.2 % | +0.6 % | +0.8 % |
| Beach pebbles (dense basalt, marble) | +0.1 % | +0.3 % | +0.5 % |
| Plastic pellets | +1.0 % | +4.0 % | +7.0 % |
| Wheat | +9.6 % | +26 % | +34 % |
| Soybeans | +12 % | +34 % | +43 % |
| Wood pellets | +15 % | +41 % | +52 % |
| Common beans | +27 % | +73 % | +92 % |
Every preset's values are in summary.json (median_water_content_pct) and
per grain in prototype_metrics.csv (mass_<state>_kg).
- No swelling. A wet grain gets heavier but keeps its shape and size. In reality beans, seeds and wood pellets swell when soaked, so their wet density is overstated.
- Indicative values. Water contents, contact and cohesion coefficients are model orders of magnitude, not measurements, and still need calibrating.
In usdview or Omniverse, change a grain's state by changing its variant selection. Blender's USD importer takes the state selected at import time.
Presets with no moisture states, even with --moisture: the regoliths (no
liquid water), the polystyrene packing peanuts (EPS never gets wet: water
runs off) and the cherry tomatoes (water beads on the waxy skin).
Deformable grains (packing peanuts, cherry tomatoes)
Works only with NVIDIA OmniPhysics, and not tested yet. Deformable simulation of
packing_peanutsandcherry_tomatoesrequires an engine that reads NVIDIA's OmniPhysics deformable schema: Omniverse Kit and Isaac Sim 5 or later, where PhysX runs it on the GPU. Other tools (Blender, usdview, MuJoCo, Bullet, engines reading only standard UsdPhysics) open the file but see these grains as static meshes with no physics. For those, export with--no-deformableto get ordinary rigid bodies.Granulaire is developed without an NVIDIA GPU: the files are checked to be valid OpenUSD with the documented schemas and attributes, but they have never been simulated in Isaac Sim. In some releases the schema is a beta feature that must be enabled. Feedback from anyone who runs them is very welcome.
Why: core OpenUSD has no deformable-body schema yet. UsdPhysics covers rigid
bodies only (UsdPhysics overview);
the AOUSD Physics Working Group lists deformable and soft bodies only as a
possible future extension
(charter).
Deformable presets therefore follow NVIDIA's OmniPhysics deformable
schema (reference),
built on the core UsdGeom.TetMesh:
/World/Prototypes/Grain_000   Xform  + OmniPhysicsDeformableBodyAPI (omniphysics:mass)
  geom                        Mesh   + OmniPhysicsDeformablePoseAPI:custom (bind pose)
  sim                         TetMesh + OmniPhysicsVolumeDeformableSimAPI
                                      + OmniPhysicsDeformablePoseAPI:custom
                                      + PhysicsCollisionAPI
/World/Looks/Phys             Material + OmniPhysicsBaseMaterialAPI (density, friction)
                                       + OmniPhysicsDeformableMaterialAPI
                                         (Young's modulus, Poisson's ratio)
                                       + PhysxDeformableMaterialAPI
                                         (elasticity damping)
-
The simulation mesh fills the grain's volume with tetrahedra (voxels split into 6 tetrahedra each, ~1,300–1,400 per grain); the render mesh follows it through the bind pose. The tetrahedral volume matches the surface within a few percent.
-
The schemas are applied by name, so the file stays valid OpenUSD in any tool, but only OmniPhysics acts on them.
usd-coredoes not list unregistered schemas inGetAppliedSchemas(), but they are in the file (apiSchemasmetadata). -
NVIDIA's schema is still evolving (it replaced an earlier PhysX deformable API); if a newer Omniverse release renames attributes, re-export with an updated Granulaire. If OpenUSD standardises deformables, the export will move to that schema.
-
--no-deformableexports the same presets as rigid bodies. -
Bounce. Deformable materials have no restitution: a grain bounces through its own elasticity, and
physxDeformableMaterial:elasticityDamping(1/s) sets how much energy each deformation loses. The values below are uncalibrated starting points, to tune in Isaac Sim. -
Material values are indicative:
Preset Young's modulus E Poisson's ratio ν Elasticity damping packing_peanuts(EPS foam)≈ 1 MPa ≈ 0.1 0.02 /s cherry_tomatoes(soft fruit, keeps its volume when squeezed)≈ 0.5 MPa ≈ 0.45 0.01 /s
Outputs (per preset, under output/<preset>/)
| File | Content |
|---|---|
granulaire_<preset>.usdc |
OpenUSD scene (Blender: File > Import > USD) |
prototype_metrics.csv |
measured descriptors, mass (per moisture state), parameters |
instances.csv |
grain → shape, position, moisture state |
summary.json |
global statistics (d50, mean sphericity, masses, water) |
prototypes.npz |
meshes, used by the renderer |
shape_sheet.png, mix_preview.png |
previews (granulaire render) |
In Blender
The .usdc scene opens directly in Blender (File > Import > USD).
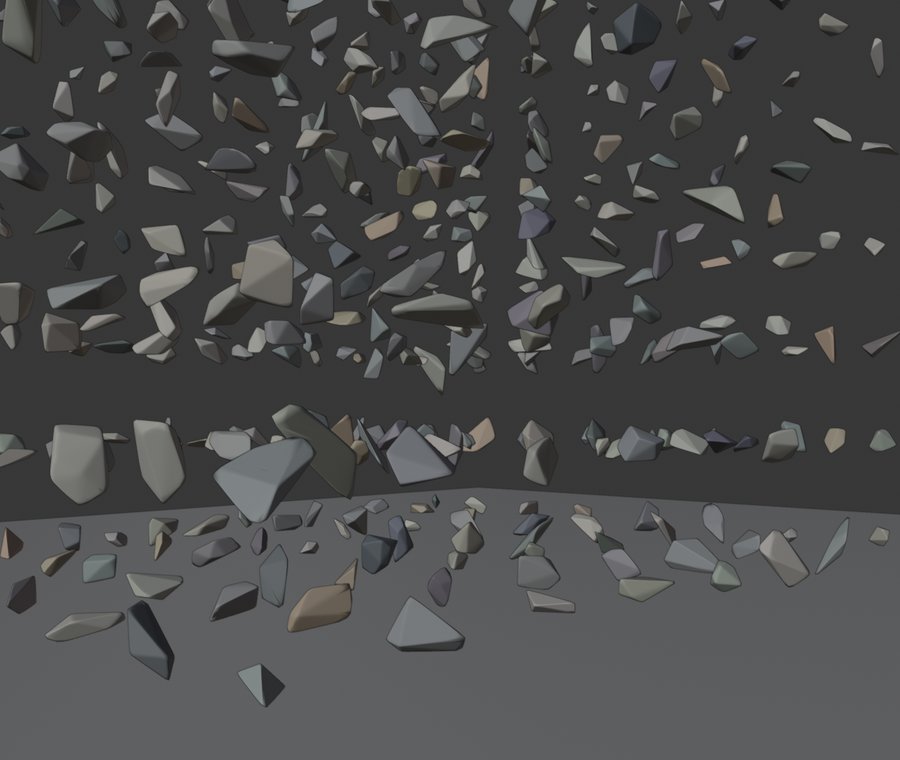 |
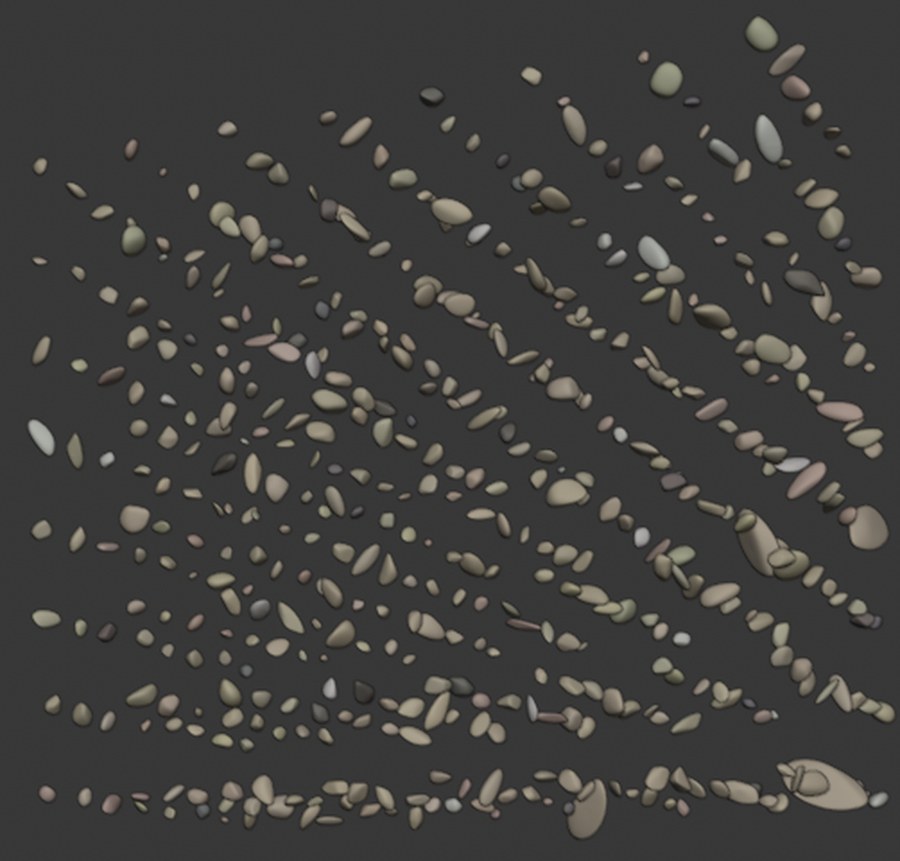 |
| Crushed gravel falling onto the floor (Blender rigid-body physics) | Beach sand, rounded grains in mineral colours |
Screenshots from the first version (0.1.0); grain shapes have become more varied since then.
Method in brief
Each grain is an implicit volume, meshed with marching cubes:
- Base body. Rocks: a random convex polyhedron (the hull of points drawn on an ellipsoid with Zingg proportions; few facets give an angular grain), with edges rounded by replacing the max in its gauge with a p-norm (low p gives a rounded grain, high p sharp edges). Kernels and seeds: a superellipsoid. Pellets: a cylinder with rounded end edges.
- Fracture chips. Random planes cut the body, leaving flat broken faces with sharp edges (crushed stone, broken pebbles, broken pellet ends).
- Taper and irregularity. An egg or wedge taper along the long axis, then low-frequency lumps, pits (scoria vesicles, flint dents), a crease (wheat), a crown dent (maize), a kidney bend with its hilum (beans) and light roughness.
- Mesh and scale. Marching cubes on the zero level set, recentring on the centre of mass, scaling to the target nominal diameter.
Friction and restitution
Every grain gets a standard OpenUSD physics material (UsdPhysicsMaterialAPI:
static friction, dynamic friction, restitution), bound to its collision mesh
with the physics purpose. With moisture enabled there is one material per
state, and each grain's moisture variant selects it. The ground has its own
material (static friction 0.60, restitution 0.10).
Values
Dynamic friction is 90 % of static friction. In wet states, friction is multiplied by 1.10 (damp: a little water makes grains grip), 1.00 (wet) and 0.80 (saturated: grains slide on the water); restitution by 0.60, 0.40 and 0.30. The values are realistic orders of magnitude, ranked sensibly (angular crushed rock grips more than round, polished or waxy grains), not measurements of a specific deposit.
| Preset | Static μ (dry) | Dynamic μ (dry) | Restitution (dry) | Static μ damp | Static μ wet | Static μ saturated |
|---|---|---|---|---|---|---|
beach_sand |
0.55 | 0.50 | 0.10 | 0.61 | 0.55 | 0.44 |
dune_sand |
0.50 | 0.45 | 0.10 | 0.55 | 0.50 | 0.40 |
volcanic_sand |
0.60 | 0.54 | 0.10 | 0.66 | 0.60 | 0.48 |
rounded_gravel |
0.55 | 0.50 | 0.15 | 0.61 | 0.55 | 0.44 |
crushed_gravel |
0.65 | 0.59 | 0.15 | 0.72 | 0.65 | 0.52 |
marble_chips |
0.60 | 0.54 | 0.15 | 0.66 | 0.60 | 0.48 |
pozzolana |
0.75 | 0.68 | 0.10 | 0.83 | 0.75 | 0.60 |
river_pebbles |
0.50 | 0.45 | 0.20 | 0.55 | 0.50 | 0.40 |
beach_pebbles |
0.40 | 0.36 | 0.25 | 0.44 | 0.40 | 0.32 |
railway_ballast |
0.70 | 0.63 | 0.15 | 0.77 | 0.70 | 0.56 |
iron_ore |
0.70 | 0.63 | 0.12 | 0.77 | 0.70 | 0.56 |
coal |
0.55 | 0.50 | 0.10 | 0.61 | 0.55 | 0.44 |
rubber_mulch |
0.85 | 0.77 | 0.55 | 0.94 | 0.85 | 0.68 |
wheat |
0.40 | 0.36 | 0.40 | 0.44 | 0.40 | 0.32 |
maize |
0.45 | 0.41 | 0.35 | 0.50 | 0.45 | 0.36 |
rice |
0.40 | 0.36 | 0.30 | 0.44 | 0.40 | 0.32 |
beans |
0.35 | 0.32 | 0.40 | 0.39 | 0.35 | 0.28 |
soybean |
0.35 | 0.32 | 0.45 | 0.39 | 0.35 | 0.28 |
cherry_tomatoes |
0.45 | 0.41 | 0.20 | — | — | — |
plastic_pellets |
0.30 | 0.27 | 0.50 | 0.33 | 0.30 | 0.24 |
wood_pellets |
0.50 | 0.45 | 0.20 | 0.55 | 0.50 | 0.40 |
packing_peanuts |
0.50 | 0.45 | 0.30 | — | — | — |
lunar_regolith |
0.75 | 0.68 | 0.05 | — | — | — |
martian_regolith |
0.70 | 0.63 | 0.05 | — | — | — |
glass_beads |
0.35 | 0.32 | 0.85 | 0.39 | 0.35 | 0.28 |
— : no moisture states for this preset. Packing peanuts and cherry tomatoes
are deformable: NVIDIA OmniPhysics ignores static friction for deformables, so
their single value is written as both static and dynamic friction, and
restitution does not apply (their bounce comes from elasticity and damping, see
Deformable grains); the
restitution shown is used when they are exported as rigid bodies
(--no-deformable).
Which engines use it
| Tool | Friction and restitution from the USD file |
|---|---|
| NVIDIA Isaac Sim / Omniverse (PhysX) | Used, including the material selected by each grain's moisture variant. PhysX averages the two materials in contact by default (physxMaterial:frictionCombineMode to change it). |
Other engines importing UsdPhysics (e.g. Newton) |
Should be read, as it is the standard schema; not tested here. |
| Blender | Not used: Blender's USD importer does not import physics data. Set friction in the rigid-body panel or with an import script. |
| MuJoCo, Gazebo, PyBullet | Not native; depends on the converter. MuJoCo combines friction differently (it takes the larger of the two). |
Limits
- Friction is per pair of surfaces. What a robot foot feels also depends on the foot's own material and the engine's combine mode.
- No capillary cohesion in simulation. Wet-grain cohesion is stored in
granulaire:capillaryCohesion, but OpenUSD has no standard schema for it and no rigid-body engine reads it: in simulation, wet grains differ only by friction, restitution and mass. - No rolling resistance. Neither
UsdPhysicsnor PhysX rigid bodies model it, which is why piles of spheres flow far too easily. Here the irregular shapes play that role: an angular grain cannot roll. - Calibrate for quantitative work. For training with domain randomisation, these values are a sensible centre to randomise around; for a quantitative study, calibrate them against the real material, for example with its angle of repose.
Physics limits by grain size
Grains are generated at their real size. That is right for rendering and perception, but many of them are too small or too light for today's rigid-body engines with default settings. Rules of thumb behind the table:
- Bullet (PyBullet, Blender) works best with objects larger than ~0.1 m, and Blender's default collision margin is 0.04 m.
- PhysX (Isaac Sim, Omniverse) uses a default
contactOffsetof 0.02 m per shape at metric scale, so two shapes are treated as touching from ~4 cm. - Tunnelling: at 60 Hz, a grain falling at 1–2 m/s travels 1.7–3.3 cm per step and can pass through surfaces smaller than that without CCD or substeps.
- Mass ratio: iterative solvers become unstable when very light grains touch a much heavier body, such as a robot foot weighing a few kilograms.
| Physics risk | Presets (median nominal size · mean grain mass) | What to do |
|---|---|---|
| Not usable as individual rigid bodies | lunar_regolith (0.07 mm · ~13 µg), martian_regolith (0.12 mm · ~0.1 mg), dune_sand (0.22 mm · ~18 µg), beach_sand (0.36 mm · ~0.1 mg), volcanic_sand (0.49 mm · ~0.4 mg), glass_beads (1 mm · ~1.4 mg) |
Use for rendering and perception; for physics, use a continuum model (MPM), a deformable heightfield, or scaled-up grains |
| Unstable without tuning | rice (2.8 mm, 1.6 mm thick · ~18 mg), plastic_pellets (3.4 mm · ~20 mg), wheat (4.1 mm · ~53 mg), rounded_gravel (5.8 mm · ~0.4 g), soybean (6.6 mm · ~0.19 g), beans (9.1 mm, 5.8 mm thick · ~0.53 g), maize (7.4 mm, 4.7 mm thick · ~0.29 g), crushed_gravel (8.2 mm · ~1 g) |
Reduce contact offsets / margins to ~1 mm, enable CCD, use substeps or a smaller time step |
| Workable with tuning | packing_peanuts (20 mm, ~9 mm thick · ~50 mg, extremely light), wood_pellets (9.8 mm, 6 mm thick · ~0.6 g), pozzolana (11 mm · ~1.5 g, very light), marble_chips (11.5 mm · ~2.5 g), iron_ore (16 mm · ~17 g), rubber_mulch (20 mm, 12 mm thick · ~6 g), cherry_tomatoes (25 mm · ~8 g, deformable) |
Same settings as above; check stability against the heaviest body in contact |
| Generally fine | coal (23 mm · ~15 g), beach_pebbles (38 mm, 18 mm thick · ~140 g), railway_ballast (40 mm · ~100 g), river_pebbles (46 mm · ~230 g) |
Keep CCD on for impacts; in Blender, lower the default 0.04 m margin |
For elongated or flat grains (rice, maize, beans, pellets), the thickness is what matters for tunnelling, not the nominal size. Packing peanuts are large but weigh almost nothing: the mass ratio with anything they touch is the main risk, and as deformable bodies they are simulated only by NVIDIA OmniPhysics (see above).
These are orders of magnitude, not hard limits: the actual threshold depends on the engine, time step, solver iterations, contact settings and the bodies in contact. Scaling grains up changes the physics (mass, inertia, contact forces scale differently), so treat it as an approximation of the material.
Perception is not affected. Cameras and renderers have no minimum size: every preset, including sand and regoliths, can be used at real scale for synthetic images, ground-truth masks, grading-from-image benchmarks or appearance studies (moisture darkening and gloss). Only dynamics need the precautions above. A thin layer of a few hundred grains on a hard surface (the "sand on the ramp" case) is also within reach of rigid-body engines for the gravel and pebble presets.
Known limits
- Real units. See Physics limits by grain size above.
- No grain-by-grain physics at large scale. CPU physics targets a few hundred grains; instancing is for rendering surfaces.
- Angularity is a proxy, not Wadell roundness, and is only comparable between grains of the same mesh resolution.
- Collision uses the convex hull for rigid grains. Pits, creases and dents are visible but not part of the collision shape; hollow shells (whole seashells) are not generated. Deformable grains collide with their tetrahedral mesh.
- Deformables work only with NVIDIA OmniPhysics, untested. Until OpenUSD
standardises deformable bodies, packing peanuts and cherry tomatoes are
simulated as deformables only in Omniverse / Isaac Sim (GPU); elsewhere they
are static meshes unless exported with
--no-deformable. They have not been run in Isaac Sim yet. - Mesh resolution. Marching cubes runs on a 48-cell grid along the longest axis; the sharpest edges can show slight stair-stepping.
Development
pip install -e ".[dev]"
pytest            # test suite
ruff check .      # lint
ruff format .     # format
Commits and versions
- Commit messages follow Conventional Commits
(
feat:,fix:,docs:,test:,refactor:,build:,chore:). - Versions follow Semantic Versioning. The version
lives in one place,
pyproject.toml;granulaire.__version__reads it from the installed package metadata. - To release: update
versioninpyproject.toml, move theUnreleasedentries ofCHANGELOG.mdunder the new version with its date, commit aschore(release): X.Y.Z, then tagvX.Y.Z(annotated). Pre-releases use PEP 440 suffixes (0.2.0b1for a beta, tagv0.2.0b1).
Branches (GitHub Flow)
The repository follows GitHub Flow:
mainis the only long-lived branch and is always releasable. Nobody pushes to it directly.- Every change starts on a short-lived branch from
main, named after its type:feat/<name>,fix/<name>,docs/<name>,ci/<name>, … - Push the branch and open a pull request into
main; CI runs on it. - Merge when CI is green, then delete the branch.
Releasing is a change like any other: on a chore/release-X.Y.Z branch, bump
version in pyproject.toml and move the Unreleased entries of
CHANGELOG.md under the new version; merge the pull request, then tag
vX.Y.Z on main (or create the release on the GitHub web page with that new
tag). The release workflow builds the packages and attaches them.
A versioned pre-push hook refuses direct pushes to main. Enable it once per
clone with git config core.hooksPath .githooks (emergency override:
ALLOW_MAIN_PUSH=1 git push).
On a private repository, GitHub enforces branch protection rules only with
GitHub Pro (or on a public repository). With either, add a rule on main:
require a pull request and the CI checks to pass, block force pushes and
deletion.
Continuous integration
GitHub Actions runs these workflows (.github/workflows/):
| Workflow | When | What |
|---|---|---|
ci.yml |
every push to main, every pull request |
ruff check and ruff format --check; pytest on Python 3.10–3.13 (Linux) and 3.12 (macOS, Windows); a command-line smoke test; build the wheel and sdist, twine check, install the wheel in a clean environment. The packages are kept as a run artifact for 14 days. |
release.yml |
a pushed tag v* |
checks the tag matches the version in pyproject.toml, tests, builds, then creates the GitHub release with the packages attached and the notes taken from CHANGELOG.md. Versions with a, b or rc are marked as pre-releases. If the release already exists (created on the web page), the packages are added to it. |
| Dependabot | monthly | pull requests to update the GitHub Actions and the Python dependencies. |
Ruff is pinned in CI so that a new ruff release cannot fail the build on
unchanged code; update the pin and run ruff format . together.
License
MIT © 2026 Daniel Régis Sarmento Caon
The logo is set in IBM Plex Sans (SIL Open Font License 1.1), outlined into paths, so it displays without the font installed.
Granulaire is part of Primvaria, physics-ready variability for Physical AI, in OpenUSD: pip install primvaria installs the whole suite.
1 maintainer

Metadata
1 maintainer
Release files for granulaire 0.2.0b3
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| granulaire-0.2.0b3.tar.gz | 61.3 kB | With provenance | Details for granulaire-0.2.0b3.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| granulaire-0.2.0b3-py3-none-any.whl | Python 3 | none | any | Details for granulaire-0.2.0b3-py3-none-any.whl |
Total release size: 108.7 kB
Release files / granulaire-0.2.0b3.tar.gz
| Download URL | granulaire-0.2.0b3.tar.gz |
|---|---|
| Size | 61.3 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
82ce97811faf40c3ce373685df33b7fd8a74ab6d9b8d3e46f76d130d54974d6c
|
|
BLAKE2b-256 checksum How to use checksums |
39bcabf639ca177594238a85a90e986df5904ac7e9a893654a141e215b200394
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 29, 2026.
Transparency logRelease files / granulaire-0.2.0b3-py3-none-any.whl
| Download URL | granulaire-0.2.0b3-py3-none-any.whl |
|---|---|
| Size | 47.4 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
8c35fa8c3659247ce06c63a164ec9ef68e0f83ffb7c92f2e474a52a6e350f556
|
|
BLAKE2b-256 checksum How to use checksums |
969c019bfc72573f89286def68d0579e54750a9f7db499e701676dc3e5e95c51
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.16
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 29, 2026.
Transparency logSecurity for granulaire 0.2.0b3
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
Full provenance
All 2 files in this release have been uploaded with provenance metadata.
Attestation for granulaire-0.2.0b3.tar.gz
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 29, 2026.
Transparency logA note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.













