


GraspKit is an end-to-end toolkit for manipulation across various robot embodiments, including grippers and dexterous hands. It synthesizes grasps, plans trajectories, trains policies, and deploys them in simulation or on real robots; it is built on top of RoboKit.
Quick links
Installation
Requires Python 3.10–3.14 (the full pipeline with ManiSkill and spconv: 3.10–3.12):
uv add graspkit # or: pip install graspkit
See Installation for source installs, PyTorch options, and asset access.
Features
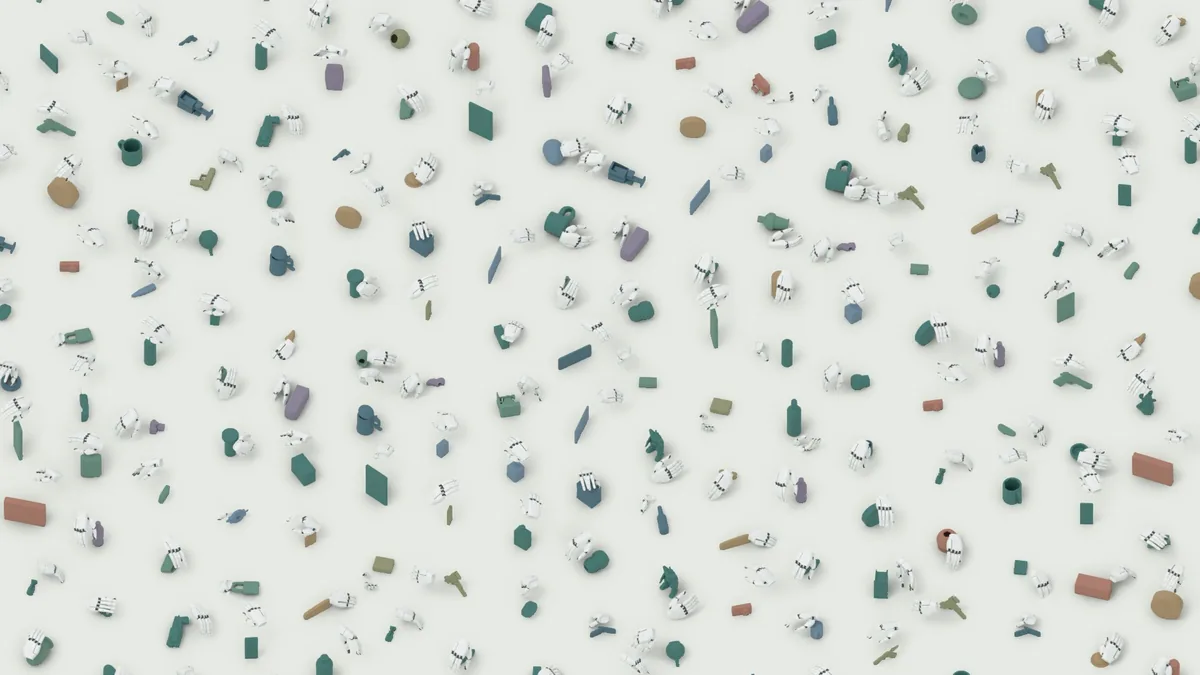 Fast grasp optimization |
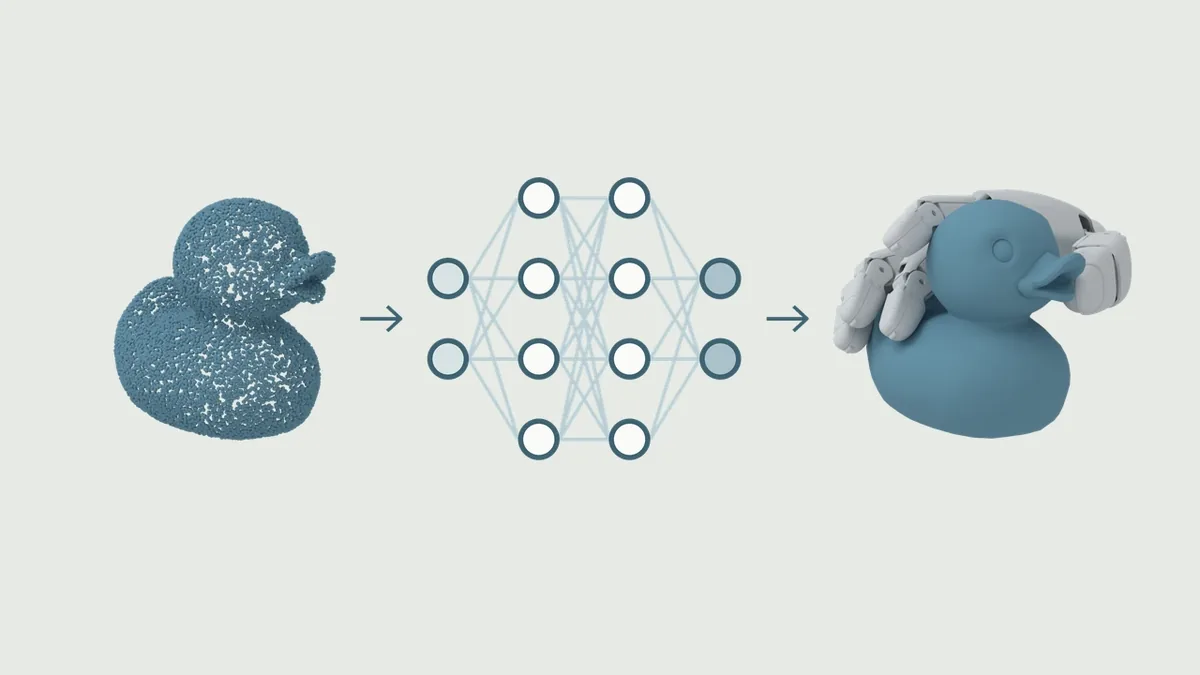 Policy learning |
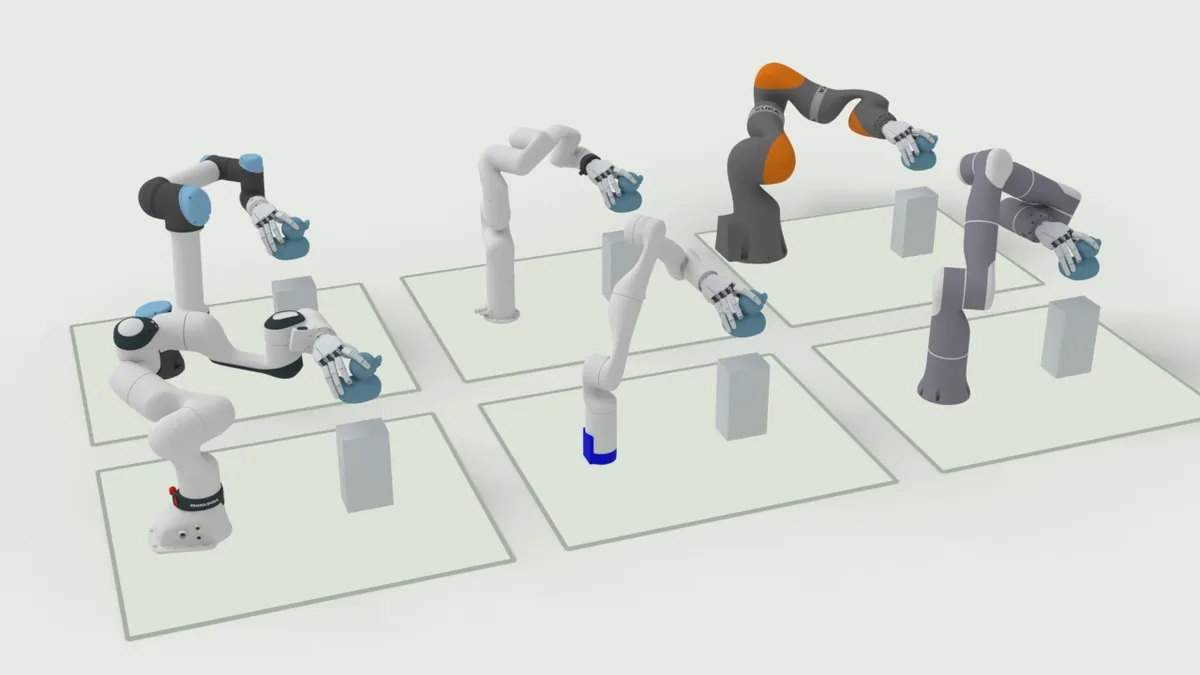 All arms, all hands |
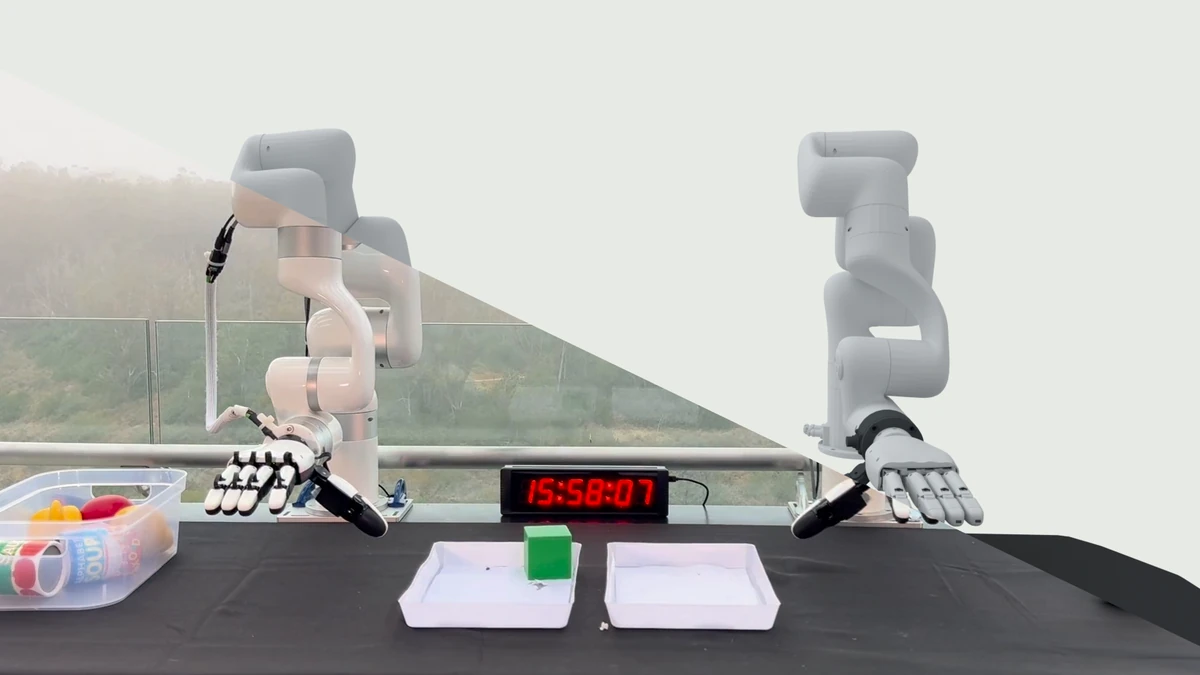 Real-world robustness |
Explore robot presets and optimized grasps in the interactive gallery.
How it works
For each scene, GraspKit optimizes and plans grasps on the GPU and renders the camera's point cloud. A policy trained on these pairs maps point clouds to grasp trajectories, in simulation or on real robots.
| Stage | Role | Read more |
|---|---|---|
| Grasp optimization | Generate grasps, plan motions, and optionally validate them in simulation. | Grasp optimization |
| Rendering | Render point-cloud observations for the same scenes. | Pipeline |
| Data processing | Join observations and grasps into policy training data. | Pipeline |
| Training | Train a grasp policy on the processed data. | Training |
| Deployment | Run a trained policy in simulation or on a real robot. | Sim, real |
See the core overview for the full stage graph and artifacts.
1 maintainer

Metadata
1 maintainer
Release files for graspkit 0.1.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| graspkit-0.1.0.tar.gz | 3.1 MB | Without provenance | Details for graspkit-0.1.0.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| graspkit-0.1.0-py3-none-any.whl | Python 3 | none | any | Details for graspkit-0.1.0-py3-none-any.whl |
Total release size: 3.5 MB
Release files / graspkit-0.1.0.tar.gz
| Download URL | graspkit-0.1.0.tar.gz |
|---|---|
| Size | 3.1 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
39e47899521bf896ecb67162edb3cdcddf276481bcc8b1a5efb83e50305d1ec1
|
|
BLAKE2b-256 checksum How to use checksums |
4d27d32aaf9fdce94637c6ba8a47e0d81d631eacaa961e8de709d911478c53af
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
uv/0.13.6 {"installer":{"name":"uv","version":"0.13.6","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":{"name":"Ubuntu","version":"26.04","id":"resolute","libc":null},"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":true}
|
Release files / graspkit-0.1.0-py3-none-any.whl
| Download URL | graspkit-0.1.0-py3-none-any.whl |
|---|---|
| Size | 337.3 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
503a642978ea45795f952f2f38b340e5217564b61b6d6048f16036aa64642eaa
|
|
BLAKE2b-256 checksum How to use checksums |
09fb2fb74d686abed74218cbebe1e8b92028f402f992580faeeac4ea641e40e6
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
uv/0.13.6 {"installer":{"name":"uv","version":"0.13.6","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":{"name":"Ubuntu","version":"26.04","id":"resolute","libc":null},"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":true}
|
Security for graspkit 0.1.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.













