
This release is a pre-release and may not be stable for production use.
gym-ignition-models


Robot models for gym-ignition
These models have been mainly tuned and tested to work in Ignition Gazebo.
Setup
This repository can be installed with the pip package manager as follows:
# From PyPI
pip3 install gym-ignition-models

# From the repository (always containing the most recent changes)
pip3 install git+https://github.com/dic-iit/gym-ignition-models.git
Only GNU/Linux distributions are currently supported.
Configuration
Standalone usage
If you use Ignition Gazebo, you need to specify where the models and their dependent resources are located in the filesystem.
The simulator reads the IGN_GAZEBO_RESOURCE_PATH environment variable.
Execute the following commands from outside the directory where you cloned this repository to temporarily configure your environment:
PKG_DIR=$(python -c "import gym_ignition_models, inspect, os; print(os.path.dirname(inspect.getfile(gym_ignition_models)))")
export IGN_GAZEBO_RESOURCE_PATH=$PKG_DIR:$IGN_GAZEBO_RESOURCE_PATH
If you want to make this change persistent, add the lines above to your ~/.bashrc.
Note: waiting an upstream fix, you also need to add
to IGN_GAZEBO_RESOURCE_PATH all the directories containing model's meshes.
Note: Alternatively, instead of using IGN_GAZEBO_RESOURCE_PATH, you can use SDF_PATH for the models and
IGN_FILE_PATH for the meshes.
Python usage
The environment variables are automatically exported when the package is imported.
If your application imports also the scenario package, make sure to import gym_ignition_models first.
Usage
You can use these models either with the standalone simulators, or find and import them in your Python code. Here below an Python example of the utility functions provided by the package:
import gym_ignition_models as m

print(f"Models have been installed in {m.get_models_path()}")
print(f"Available robots: {m.get_robot_names()}")
print("\nModel files:")

for robot_name in m.get_robot_names():
    print(f"{robot_name}: {m.get_model_file(robot_name)}")
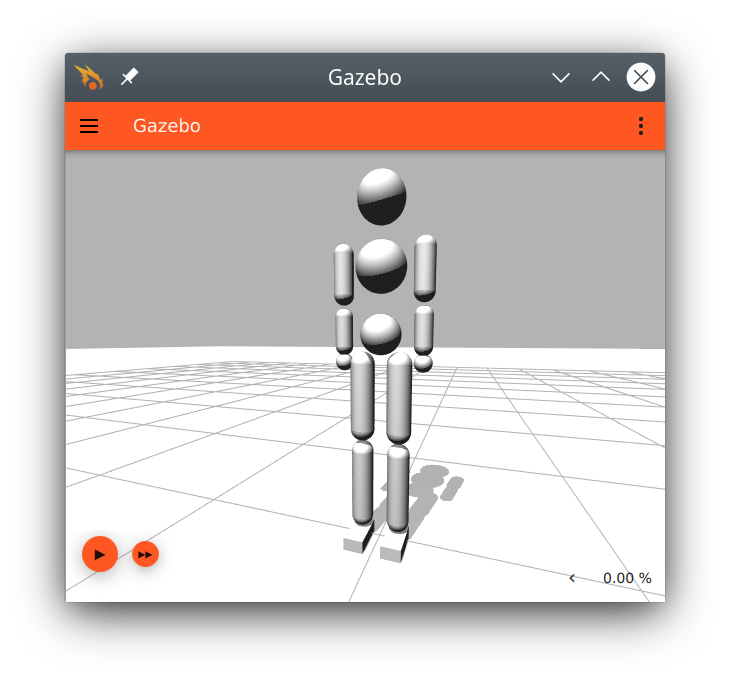
Supported models
| Robot Name | Screenshot |
|---|---|
ground_plane |
 |
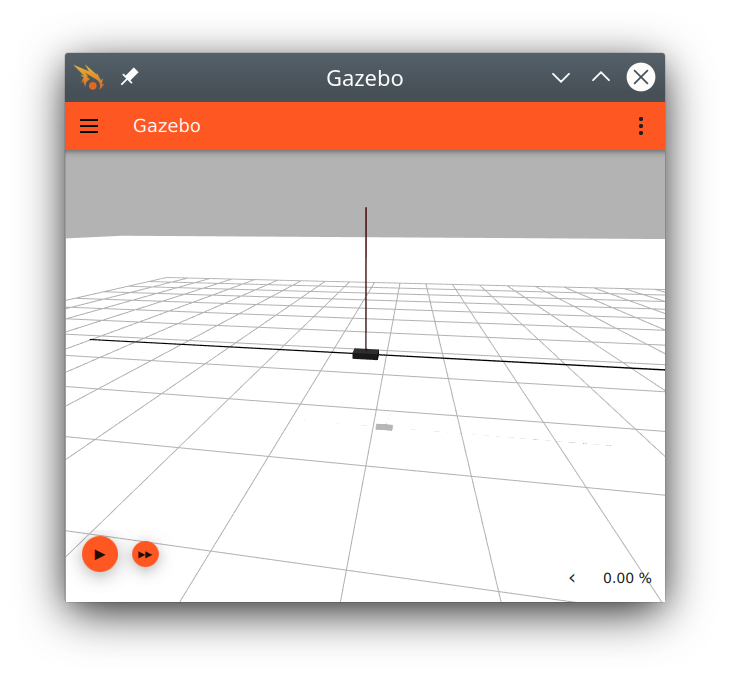
cartpole |
 |
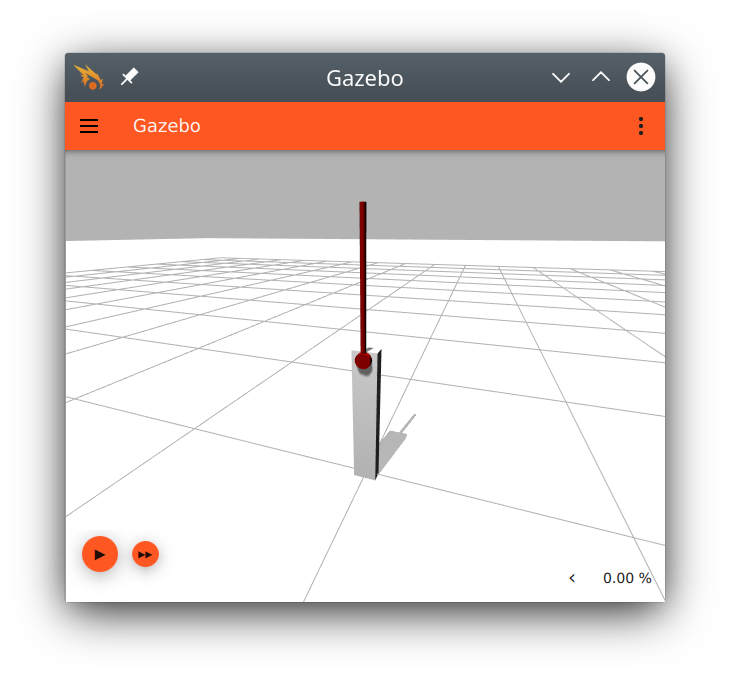
pendulum |
 |
iCubGazeboV2_5 iCubGazeboSimpleCollisionsV2_5 |
 |
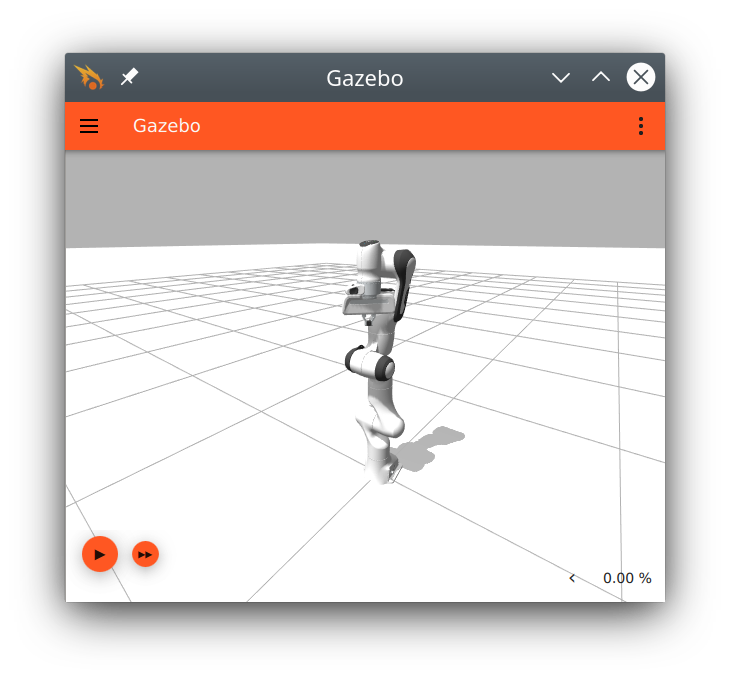
panda |
 |
character |
 |
1 maintainer

Metadata
1 maintainer
Release files for gym-ignition-models 0.1.dev100
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| gym-ignition-models-0.1.dev100.tar.gz | 9.5 MB | Without provenance | Details for gym-ignition-models-0.1.dev100.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| gym_ignition_models-0.1.dev100-py3-none-any.whl | Python 3 | none | any | Details for gym_ignition_models-0.1.dev100-py3-none-any.whl |
Total release size: 24.5 MB
Release files / gym-ignition-models-0.1.dev100.tar.gz
| Download URL | gym-ignition-models-0.1.dev100.tar.gz |
|---|---|
| Size | 9.5 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
1624124bf05719a39d49d429a4d3d4cd5d6541d4c7f58c10e45595e548a52bd6
|
|
BLAKE2b-256 checksum How to use checksums |
64ee23b72dcb65de8bf1b6f9b28391467de33ea89dc9c72c363b2a6ebb8ec274
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/3.2.0 pkginfo/1.6.0 requests/2.24.0 setuptools/50.3.2 requests-toolbelt/0.9.1 tqdm/4.50.2 CPython/3.8.6
|
Release files / gym_ignition_models-0.1.dev100-py3-none-any.whl
| Download URL | gym_ignition_models-0.1.dev100-py3-none-any.whl |
|---|---|
| Size | 15.1 MB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
2d29343a89c3a1de680a659e01b7ed965818a46d01fb3ee1bd2df99ad401d03c
|
|
BLAKE2b-256 checksum How to use checksums |
458b164e818ebf86f2bf9b20dd3fcccd41543225e63a859aabf3416f1dcb6961
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/3.2.0 pkginfo/1.6.0 requests/2.24.0 setuptools/50.3.2 requests-toolbelt/0.9.1 tqdm/4.50.2 CPython/3.8.6
|
Security for gym-ignition-models 0.1.dev100
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














