
Leuven.MapMatching


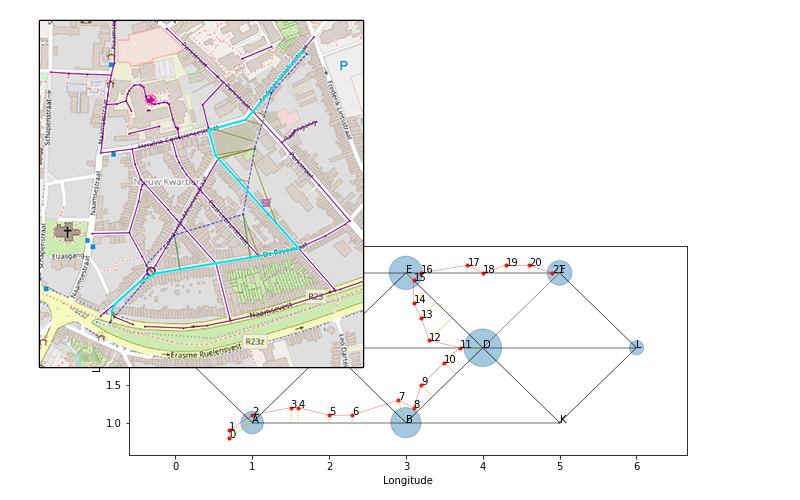
Align a trace of GPS measurements to a map or road segments.
The matching is based on a Hidden Markov Model (HMM) with non-emitting states. The model can deal with missing data and you can plug in custom transition and emission probability distributions.
Main reference:
Meert Wannes, Mathias Verbeke, "HMM with Non-Emitting States for Map Matching", European Conference on Data Analysis (ECDA), Paderborn, Germany, 2018.
Other references:
Devos Laurens, Vandebril Raf (supervisor), Meert Wannes (supervisor), "Traffic patterns revealed through matrix functions and map matching", Master thesis, Faculty of Engineering Science, KU Leuven, 2018
Installation and usage
$ pip install leuvenmapmatching
More information and examples:
leuvenmapmatching.readthedocs.io
Dependencies
Required:
Optional (only loaded when methods are called to rely on these packages):
- matplotlib: For visualisation
- smopy: For visualisation
- nvector: For latitude-longitude computations
- gpxpy: To import GPX files
- pykalman: So smooth paths using a Kalman filter
- pyproj: To project latitude-longitude coordinates to an XY-plane
- rtree: To quickly search locations
Contact
Wannes Meert, DTAI, KU Leuven
wannes.meert@cs.kuleuven.be
https://dtai.cs.kuleuven.be
Mathias Verbeke, Sirris
mathias.verbeke@sirris.be
http://www.sirris.be/expertise/data-innovation
Developed with the support of Elucidata.be.
License
Copyright 2015-2022, KU Leuven - DTAI Research Group, Sirris - Elucidata Group
Apache License, Version 2.0.
1 maintainer

Metadata
1 maintainer
Release files for leuvenmapmatching 1.1.4
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| leuvenmapmatching-1.1.4.tar.gz | 79.8 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| leuvenmapmatching-1.1.4-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 163.9 kB
Release files / leuvenmapmatching-1.1.4.tar.gz
| Download URL | leuvenmapmatching-1.1.4.tar.gz |
|---|---|
| Size | 79.8 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
78b558472a79305359e0894cc3b2ecb2d36dfb08ef25167314d372672935dfe4
|
|
BLAKE2b-256 checksum How to use checksums |
4a70e15b322d101e0aa2ee66cdd5a013c0316a6f6bccfa7c2ee6392456063355
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/4.0.2 CPython/3.10.8
|
Release files / leuvenmapmatching-1.1.4-py3-none-any.whl
| Download URL | leuvenmapmatching-1.1.4-py3-none-any.whl |
|---|---|
| Size | 84.1 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
3852a510b23a3a8dfdeaa77ca2034188dbc36f2ead76080ce051d08afcc9350a
|
|
BLAKE2b-256 checksum How to use checksums |
10dda45e17c9de5af710f9fd7039fb55c735452068b1d08b1957431de27811c5
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/4.0.2 CPython/3.10.8
|














