
medscope
Medical Intraoperative Real-time Visualization System.
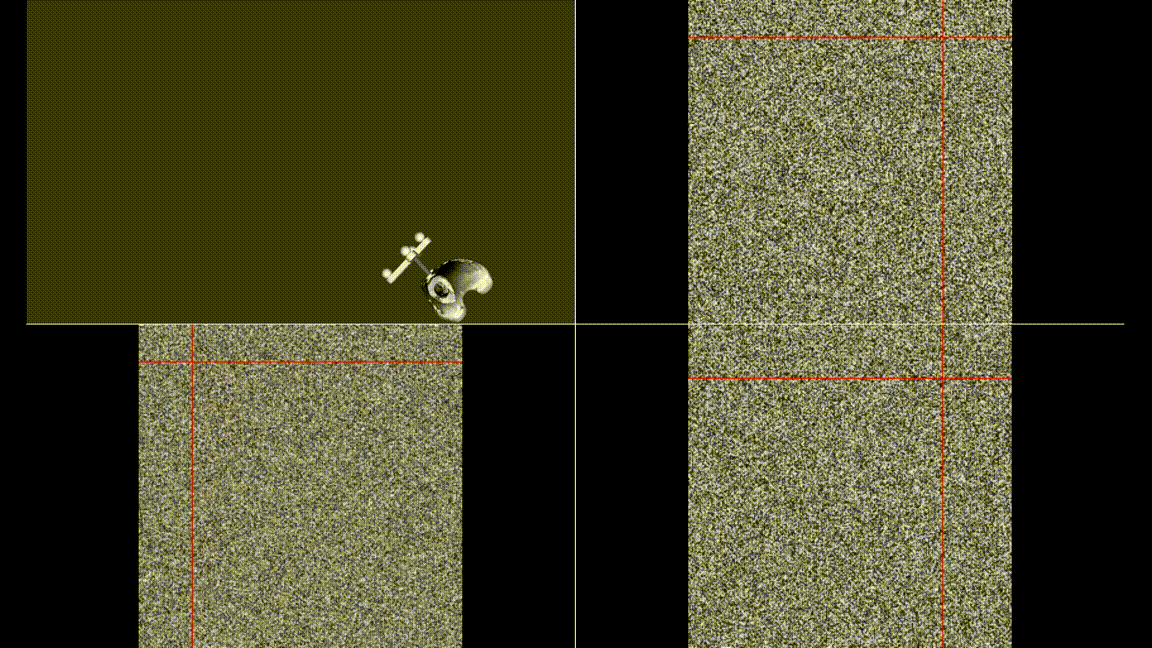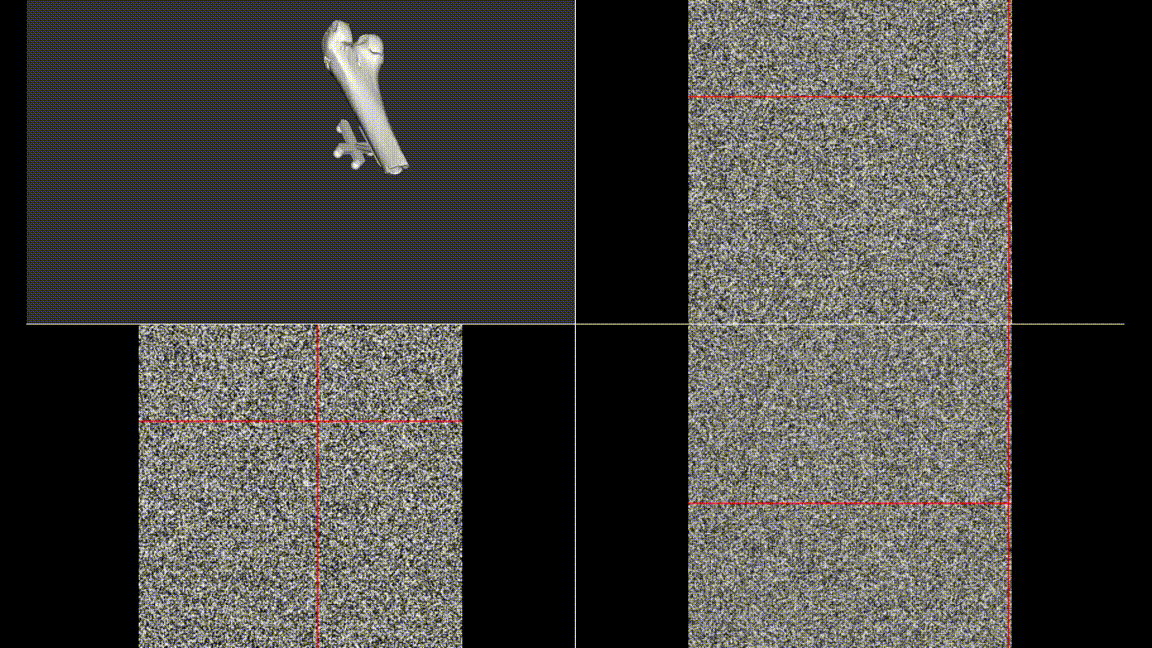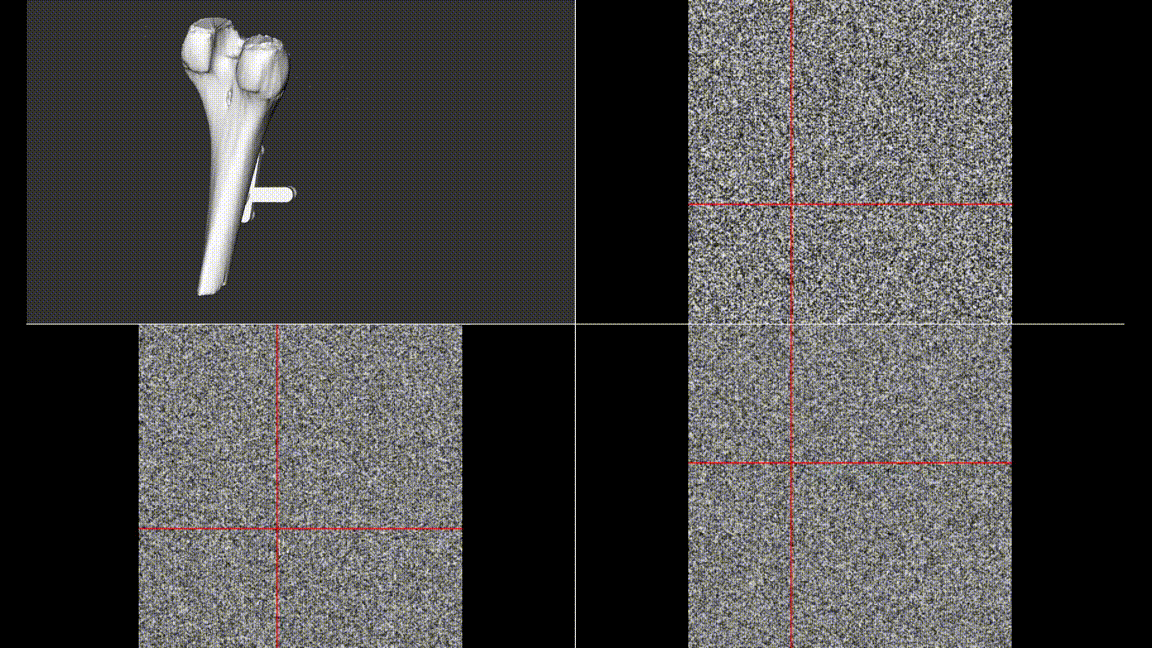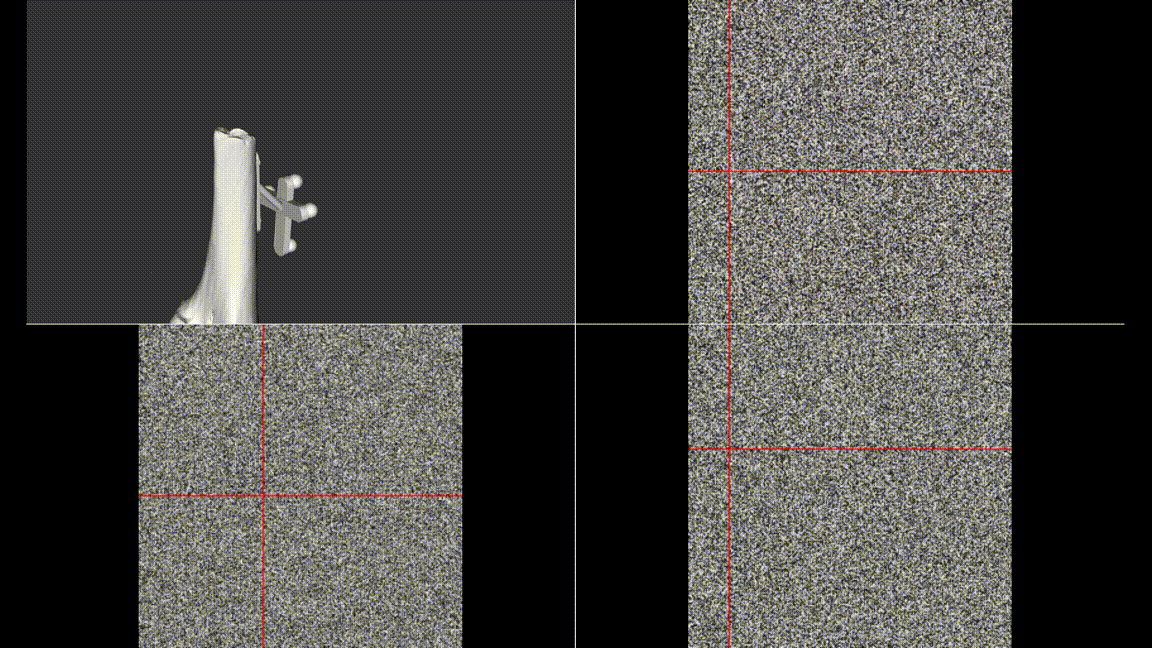
Demo
[!TIP] For another demo, see https://github.com/GGN-2015/medscope_demo_project
Installation
[!IMPORTANT] You should use
python >=3.10, <3.13
pip install medscope
Usage
[!WARNING] Do not use multithreading, use
MedScopeWindow.add_timer
from medscope import MedScopeWindow, MedScopeSystem
import numpy as np
import sys

# Generate a random 3x3 rotation matrix uniformly distributed over SO(3).
def random_rotation_matrix() -> np.ndarray:
    phi = np.random.uniform(0, 2 * np.pi)
    theta = np.random.uniform(0, np.pi)
    psi = np.random.uniform(0, 2 * np.pi)
    cos_phi, sin_phi = np.cos(phi), np.sin(phi)
    cos_theta, sin_theta = np.cos(theta), np.sin(theta)
    cos_psi, sin_psi = np.cos(psi), np.sin(psi)
    R = np.array([
        [cos_phi*cos_theta*cos_psi - sin_phi*sin_psi,
         -cos_phi*cos_theta*sin_psi - sin_phi*cos_psi,
         cos_phi*sin_theta],
        [sin_phi*cos_theta*cos_psi + cos_phi*sin_psi,
         -sin_phi*cos_theta*sin_psi + cos_phi*cos_psi,
         sin_phi*sin_theta],
        [-sin_theta*cos_psi,
         sin_theta*sin_psi,
         cos_theta]
    ])

    return R

# Initialize app and window
app = MedScopeSystem(sys.argv)
window = MedScopeWindow()

# Add a 3D model
window.add_model_from_file(
    "bone_model",
    "BONE-1.real.stl",
    (1.0, 1.0, 1.0))  # white, random if not given

# Set model color
window.set_model_color("bone_model", (1.0, 0.0, 0.0))

# Check intersection (True)
print(window.check_model_intersect("bone_model", "bone_model"))

# Set the pose of camera
#   you can change camera pos in callback function with add_timer
window.set_camera_pose(
    (0, 0, -500),
    (0, 0, 0),
    (0, 1, 0)
)

# Volume data should be given in 3D np.ndarray
#   and dtype should be np.uint8
#   RGB channel image 3 * N * M * L
# window.set_volume(np.random.randint(0, 255, (3, 256, 256, 256)).astype(np.uint8))

# use N * M * L to achieve grey image
window.set_volume(np.random.randint(0, 255, (256, 256, 256)).astype(np.uint8))

# calculate every 1.0s
import time
lp = time.time()
pp = 1.0

# Create a callback function to move your model
def move_model():
    import random
    global lp
    if time.time() - lp >= pp:
        lp = time.time()
        x = random.random() * 256
        y = random.random() * 256
        z = random.random() * 256
        window.set_slice_positions(x, y, z)
        window.set_model_pose(
            "bone_model",
            (x  - 128, y - 128, z - 128),
            random_rotation_matrix()
        )

# Call move_model every 1ms (as quickly as the processor can)
window.add_timer("move_model", 1, move_model)
sys.exit(app.exec_())
1 maintainer

Metadata
1 maintainer
Release files for medscope 0.1.25
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| medscope-0.1.25.tar.gz | 9.2 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| medscope-0.1.25-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 19.4 kB
Release files / medscope-0.1.25.tar.gz
| Download URL | medscope-0.1.25.tar.gz |
|---|---|
| Size | 9.2 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
2577bdf2f2c96c3bd0927c5c5b36b72c02459b4f4ce11aaca917089746d329b6
|
|
BLAKE2b-256 checksum How to use checksums |
0b9be065c629e3204d58ff2944253db91e07744db662498cac40d192f3bf0772
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
poetry/2.4.1 CPython/3.13.12 Windows/11
|
Release files / medscope-0.1.25-py3-none-any.whl
| Download URL | medscope-0.1.25-py3-none-any.whl |
|---|---|
| Size | 10.1 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
78116837f69502b7d1f5901bb253585bafe1b1612abbcf3742e5ab8dd39cceb7
|
|
BLAKE2b-256 checksum How to use checksums |
b92b9e178fded5a8a793bccfe98f6eb68e330a26ce3a13b40dc0ba1f8bd34a10
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
poetry/2.4.1 CPython/3.13.12 Windows/11
|














