

Naga
Naga is a simulation engine for Python, built on SimPy, for people who have a question about how a system behaves and want an answer they can show their work for. You describe the system once, as a data file of blocks, resources and expressions (by hand, from Python code or through an agent), and Naga runs it as a discrete-event, system-dynamics or agent-based model, or as all three on one clock. Around each run it puts what turns a single run into evidence: independent replications with confidence intervals, scenarios compared on the same random numbers, designed experiments, optimisation and calibration. The same model can also be connected to a plant, so that it starts from what is happening now, forecasts what comes next, checks those forecasts against what then happened, and proposes what to change. Because the model stays a file that can be read, compared and shared, whichever way you drive it, the answer it gives is one a team can inspect and repeat rather than take on trust.
pip install nagasim
naga run single_server --replications 5 --report report.html
Documentation: https://thematthub.github.io/naga/
How it fits together
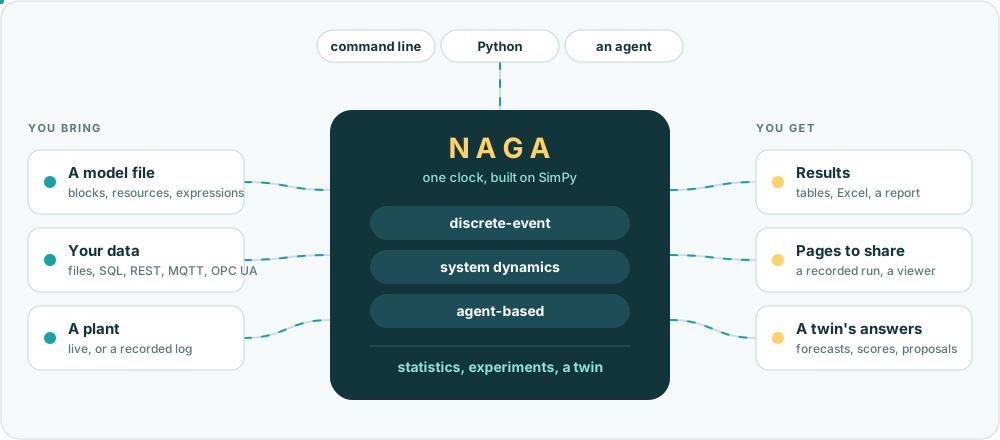
The picture reads from left to right. On the left is what you bring: a model file, the data it draws on and, if you have one, a plant to follow. In the middle the engine runs the model on a single clock, whichever of the three ways of modelling it uses, and wraps the run in statistics, experiments or a twin. On the right is what comes back: results and a report, pages you can send to someone else, and a twin's forecasts and proposals. Along the top are the three ways in, the command line, Python and an agent, and because a model is a data file and not a program, the same file gives the same answer through each of them.
What it does
- Discrete-event models from blocks (create, process, seize/release, batch, match, decide, route, transport, ...) with resources, sets, schedules, failures, costs, expressions and submodels.
- Material handling: path networks, vehicle fleets with batteries and chargers, conveyors, motion cycles, machine tending.
- System dynamics (stocks, flows, auxiliaries, delays, subscripts, units, XMILE and Vensim import) and agent-based models (statecharts, messages, space, networks), in the same model and on the same clock as the discrete-event part.
- Statistics you can defend: independent replications, Student-t intervals, warm-up handling, reproducible random streams, validated against queueing theory.
- Experiments: named scenarios with paired comparisons, design of experiments, ranking-and-selection, optimisation, calibration, forecasting, an investment case.
- A twin of a plant (
naga twin): live readers for files, SQL, REST, MQTT and OPC UA, a run that starts from the observed state, forecasts scored against what happened, and candidate actions compared on the forecast. It reads a plant and never writes to one. - Model files as data: a versioned JSON schema published for editor completion, a short
canonical form (
naga fmt), validation with stable problem codes, semantic diff and three-way merge, assertions (naga check) with a CI template. - A Python builder (
nagasim.build, provisional until 1.0) that writes the same file, andnaga export --pythonto turn any model into that code. - Outputs: pandas frames, Excel, CSV, JSON, a self-contained HTML report, a recorded run to replay, and a viewer in which the engine itself runs in a browser.
- Agent tools: 96 tools over MCP to build, validate, run, debug and analyse a model.
Quick start
From the command line, with the bundled example models (naga examples lists them; a command
that takes a model file also takes one of their names):
naga examples
naga run single_server --replications 5 --report report.html
naga scenarios automation_cell
naga validate single_server
naga --help
From Python:
from nagasim import api, examples

results = api.run_model(examples.path("single_server"), replications=5, seed=0)
print(results["system"])
results is a dictionary of pandas frames (system, resources, queues, entities, costs and more).
Write a model
A model is a JSON file, and you can write it in Python. nagasim.build has one method per block
and one constructor per distribution, and the package ships type hints, so your editor completes
every parameter and flags a misspelt one before the model runs. The code below is a single
server with random arrivals, run for five replications:
from nagasim import build as nb

m = nb.Model(time_limit=1000, warmup=100, replications=5)
m.add_resource(name="Server")
arrive = m.create(distribution=nb.Exponential(rate=1.0))
serve = m.process(resource_name="Server", distribution=nb.Exponential(rate=1.25))
arrive >> serve >> m.dispose()
print(m.run().kpis().head())
m.save("mm1.json") writes the same model as the short file below, which you can also write by
hand; the $schema line gives completion in an editor that reads JSON Schema:
{
  "$schema": "https://thematthub.github.io/naga/schema/model-v29.json",
  "schema_version": 29,
  "blocks": [
    {
      "name": "create_1",
      "type": "CREATE",
      "params": {"distribution": "Exponential", "dist_params": {"rate": 1.0}}
    },
    {
      "name": "process_1",
      "type": "PROCESS",
      "params": {
        "distribution": "Exponential",
        "dist_params": {"rate": 1.25},
        "resource_name": "Server"
      }
    },
    {"name": "dispose_1", "type": "DISPOSE"}
  ],
  "links": [
    {"source": "create_1", "target": "process_1"},
    {"source": "process_1", "target": "dispose_1"}
  ],
  "resources": [{"name": "Server"}],
  "simulation": {"time_limit": 1000, "warmup": 100, "replications": 5}
}
To start from one of the bundled models instead, naga export --python warehouse_forklifts
writes the code that builds it, and naga fmt FILE rewrites any model file in this short form.
The JSON file stays the one model that the command line, Python, an agent and a twin all share.
What you can see
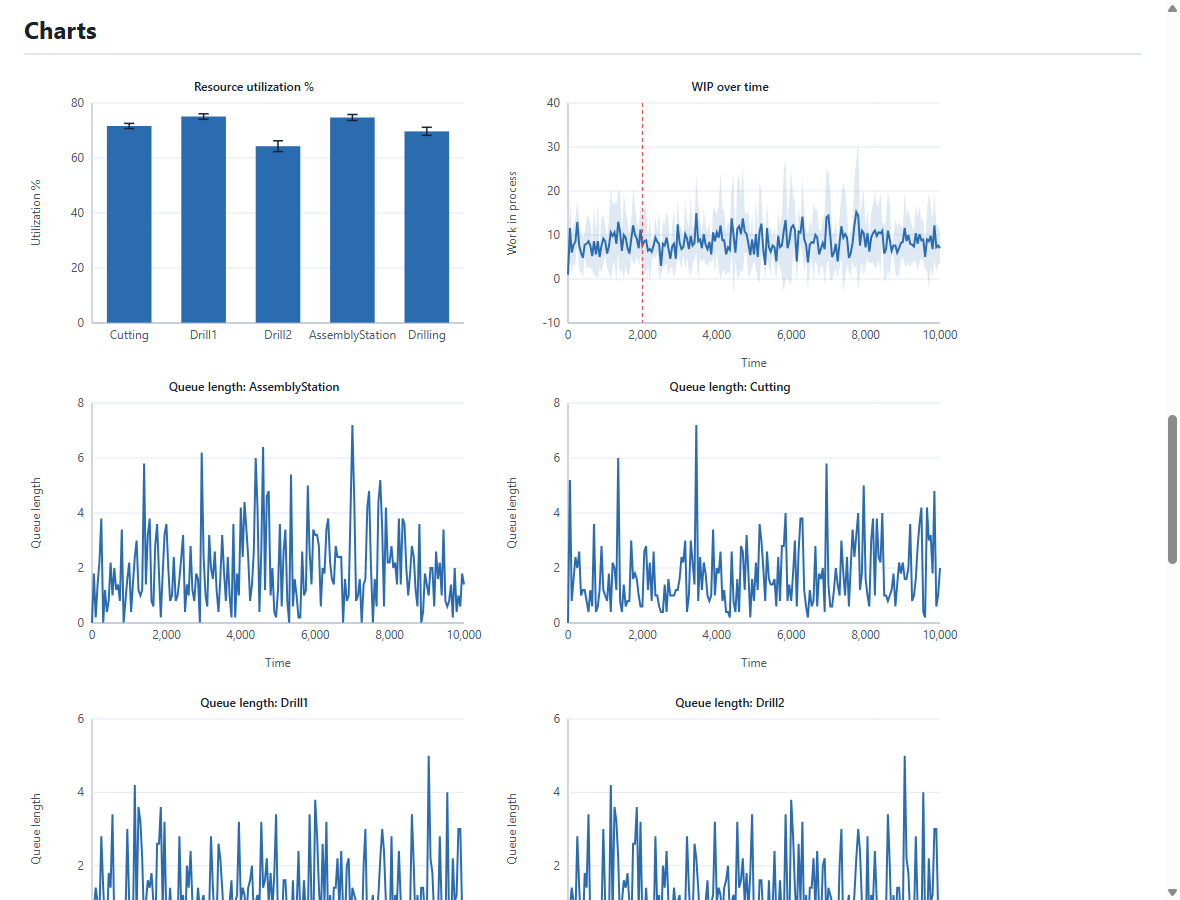
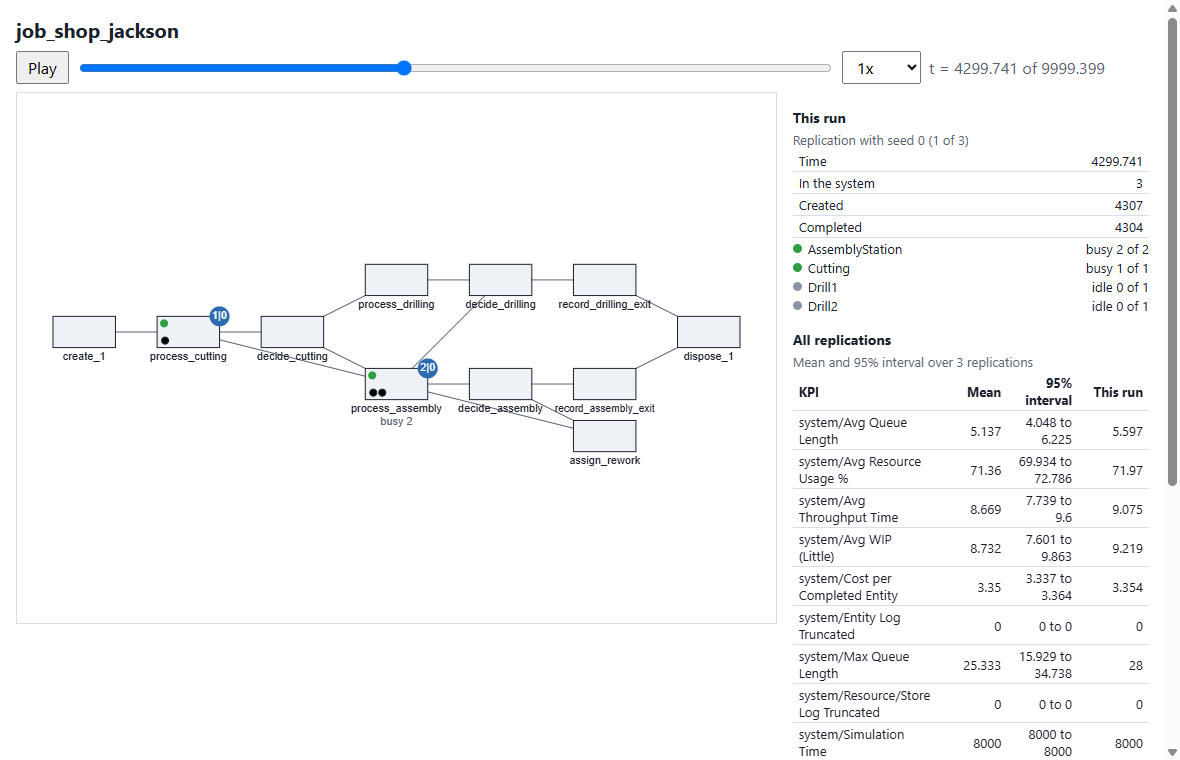
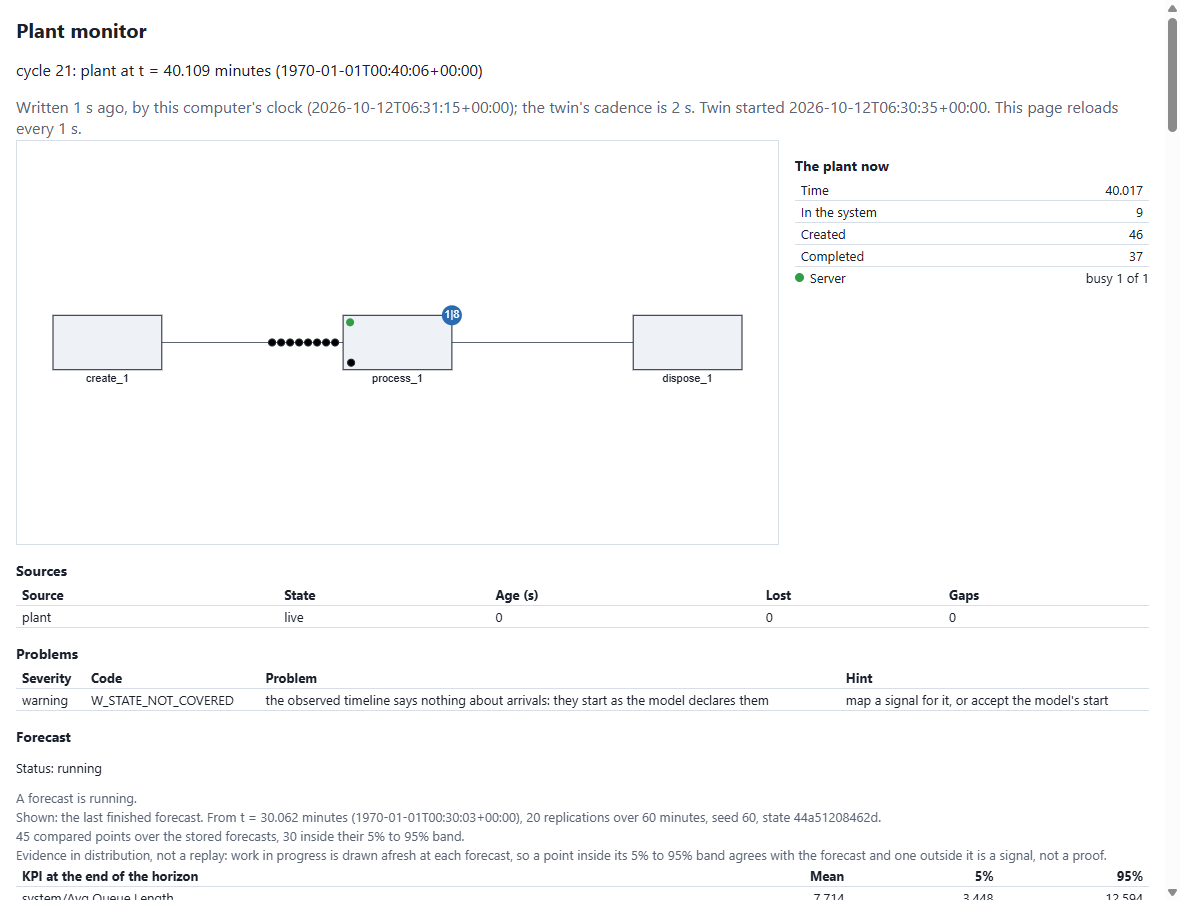
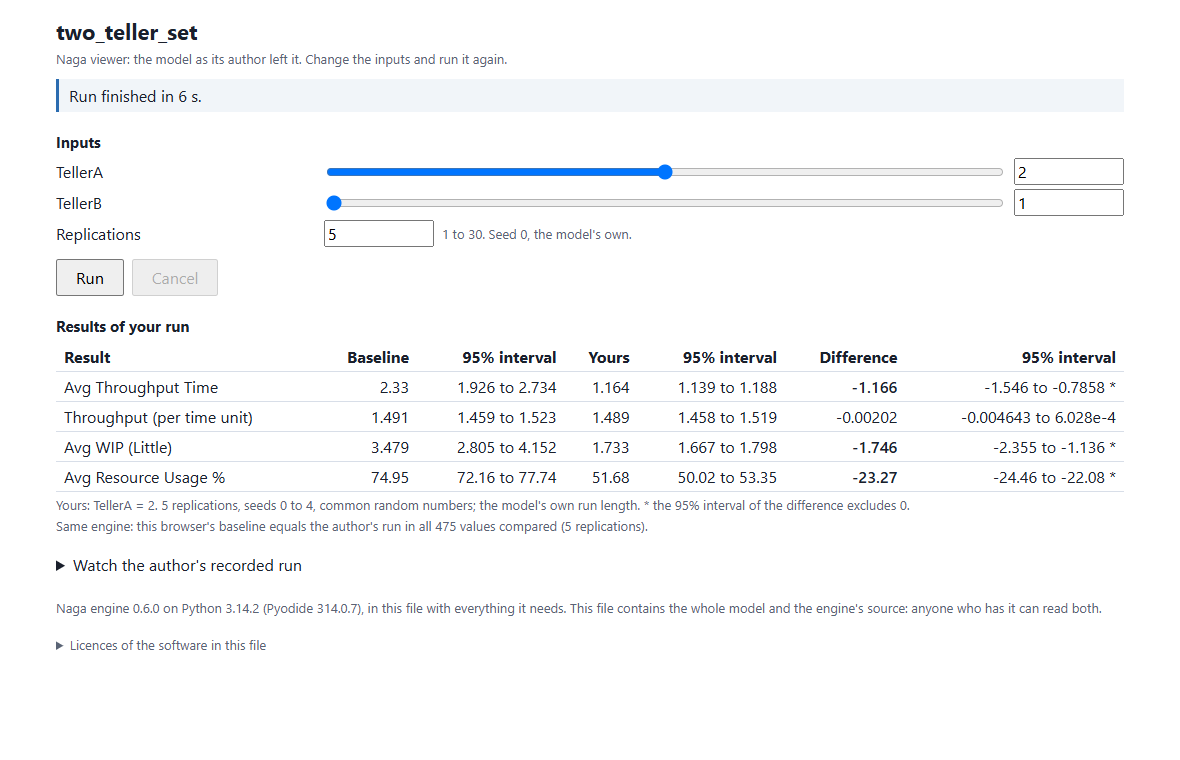
A run is easier to trust when you can look at it, so the engine writes what it finds as pages as well as tables. Each of the four below is a single file, made by one command, that opens in a browser with no server behind it: a report to read, a recorded run to replay, a monitor that follows a plant, and a viewer in which someone else can change the inputs and run the model again. They are what you hand to the people who asked the question.
 |
 |
A report. naga run MODEL --report report.html: KPIs with intervals, resources, costs and charts. |
A recorded run. naga run MODEL --player run.html: the run replayed on the model's layout, with its KPIs. |
 |
 |
A twin's monitor. naga twin run ... --monitor: the plant now, the forecast against what happened, problems with their hints. The page reloads itself. |
A viewer. naga viewer MODEL -o viewer.html: the engine runs in the reader's browser; they change the inputs you exposed and run it again. |
Example models
The package holds about sixty models: queues with a known analytical answer, job shops, warehouses with forklifts, an energy site, a biogas plant, a supply chain, system-dynamics classics, agent-based classics. Each runs as it is, and the documentation has a gallery of them with numbers from a run:
naga run warehouse_forklifts --replications 2
Some of them use submodels that came from asset libraries of a separate product; the engine runs the submodels, the product's artwork is not included here.
Use with an agent
The engine ships 96 tools an agent can call to build, validate, run, debug and analyse a model, and two ways to offer them:
pip install "nagasim[mcp]"
naga mcp --root path/to/models                 # an MCP server over stdio (Claude Code, Claude Desktop)

pip install "nagasim[assistant]"               # only for Claude
naga assist model.json "add a second server"   # one assistant turn on a model file
A local model needs no extra.
naga assist talks to a local model by default (an OpenAI-compatible server such as Ollama at
http://localhost:11434/v1; pass its model name with --model-id) or to Claude when
ANTHROPIC_API_KEY is set. Where a request goes is the caller's choice and nothing else's:
command-line flags, then the environment (NAGASIM_LLM_PROVIDER, NAGASIM_LLM_BASE_URL,
NAGASIM_LLM_MODEL; also NAGASIM_LLM_API_KEY and NAGASIM_LLM_REASONING), then the defaults.
naga mcp keeps every file inside --root and has the network off unless you allow it;
naga assist works on the one model file you give it and reaches only the endpoint you
configured. A model's own Python behaviour never runs through either.
Optional: System-1 tool picker
A small re-ranking model can help an assistant pick the right tool. pip install "nagasim[picker]"
and naga mcp --tool-picker gte re-rank find_tool's answers with gte-reranker-modernbert-base
(the right tool first for 163 of 274 blind agent queries, against 136 without it), and the answer tells the
assistant to try the first three in order. It is off unless you pass the flag, and its first use
downloads the weights from Hugging Face. --tool-picker haiku uses hosted Claude Haiku instead
(the assistant extra and your ANTHROPIC_API_KEY): it chooses among all the tools, 190 of 274 first,
and sends each query and the tool catalogue to Anthropic. Both pickers are optional suggestions, off by
default. To use another model, see the
System-1 AI Gateway and its study of the options;
the tool picker page has the comparison.
Limits to know
- The readers, the MQTT outbox and the twin have run against Mosquitto 2.1.2, an asyncua 2.1.0 OPC UA server and a Sparkplug B edge node built on the official schema, all on one machine (docs: Live data, "Tested against"). Nothing has run against a real plant, an MES, a plant counter, another broker or OPC UA server, or a commercial edge node.
- A twin starts from the plant's state for lines with finite buffers, accumulating conveyors, batches whose members the plant names, transfers, robot and cobot cycles, the plant's orders, and fleets whose vehicles each report where they are and what they carry. It cannot yet start from agent populations, a non-accumulating conveyor with parts on it, tours, gantries, segment capacities or worker fleets: such a model is monitored and its forecast is refused by name.
- Recommendations compare a resource's capacity, a DECIDE's route and, with an order signal, the order actions (hold, release, expedite, resequence), refused by name where the model cannot answer them. They are written to a file or an MQTT topic of yours. Nothing acts on a plant.
- The viewer needs Chrome, Edge or Firefox on a desktop.
- There is no editor and no animation here beyond the recorded player: Naga is an engine.
Building a product on top
Naga is the engine only. It is written so that a product package (an editor, asset libraries,
an assistant, connectors) sits beside it and imports it, never the other way round: nothing in
nagasim imports such a package, and a test keeps it that way. Where the code or a comment says
product or "the product", that is the place such a package takes; none is part of this
repository.
What a product builds on:
nagasim.api(run_modeland friends) andnagasim.core.document.ModelDocument, the model as an editable, undoable document;- the model schema (
naga schema) and structured validation problems with stable codes; - the event bus and
nagasim.core.trace.TraceRecorder, withnagasim.core.playback.Timelineto turn a recorded or live run into the state at any instant (what an animation draws); - plugin entry points for blocks, distributions and exporters (
nagasim.plugins); nagasim.netguard, the one place file and network access is decided.
Development
git clone https://github.com/TheMattHub/naga
cd naga
pip install -e ".[plan,ml,sql,plot]" -r requirements-dev.txt
python -m pytest -q -n auto
Python 3.11 or later. The engine depends on SimPy, NumPy, pandas, SciPy and openpyxl; everything
else is optional and imported only where it is used. The documentation's sources are in docs/
(pip install -r requirements-docs.txt, then python -m mkdocs serve).
Versions
Before 1.0:
- Model files always migrate forward: a file saved by an older version opens in a newer one.
- Agent tool names and problem codes are permanent.
- The Python API may change between minor versions; every such change has a changelog line.
See the changelog.
Licence and citation
Apache License 2.0, see LICENSE and NOTICE. If you use Naga in published work, please cite it: see CITATION.cff.
1 maintainer

Metadata
1 maintainer
Release files for nagasim 0.16.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | |
|---|---|---|---|---|
| nagasim-0.16.0.tar.gz | 2.7 MB | With provenance | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| nagasim-0.16.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 4.6 MB
Release files / nagasim-0.16.0.tar.gz
| Download URL | nagasim-0.16.0.tar.gz |
|---|---|
| Size | 2.7 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
114763b4dbdf08bb95170d941dc1884928eb856983d0cb3bd068ee28f88ca6b7
|
|
BLAKE2b-256 checksum How to use checksums |
89328c330d9032bc8f1189cbee75e93b984af76290b99b41839662cb0a3a4c29
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 23, 2026.
Transparency logRelease files / nagasim-0.16.0-py3-none-any.whl
| Download URL | nagasim-0.16.0-py3-none-any.whl |
|---|---|
| Size | 1.9 MB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
b3847375e1c161a2bc0ade67437610bb526bff5556d956c144a7d935bbaf46f2
|
|
BLAKE2b-256 checksum How to use checksums |
2f617d9e23959cecb0d61487ea94aadea54ecb9d8a9b0fa029e41204275a89c3
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 23, 2026.
Transparency logSecurity for nagasim 0.16.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
Full provenance
All 2 files in this release have been uploaded with provenance metadata.
Attestation for nagasim-0.16.0.tar.gz
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 23, 2026.
Transparency logA note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.














