
qpmpc



Model predictive control (MPC) in Python for optimal-control problems that are quadratic programs (QP). This includes linear time-invariant (LTI) and time-variant (LTV) systems with linear constraints. The corresponding QP has the form:
\begin{array}{rl}
\underset{x_k, u_k}{\min} \quad & w_{t} \|x_N - x_{\mathit{goal}}\|_2^2 + w_x \sum_{k=0}^{N-1} \| x_k - x^{\mathrm{ref}}_k \|_2^2  + w_u \sum_{k=0}^{N-1} \| u_k - u^{\mathrm{ref}}_k \|^2_2 \\
\mathrm{s.t.} \quad & x_{k+1} = A_k x_k + B_k u_k \\
& C_k x_k + D_k u_k \leq e_k \\
& x_0 = x_{\mathit{init}}
\end{array}
This module is designed for prototyping. If you need performance, check out the alternatives below.
Installation
pip install qpmpc
Usage
This module defines a one-stop shop function:
solve_mpc(problem: MPCProblem, solver: str) -> Plan
The MPCProblem defines the model predictive control problem (LTV system, LTV constraints, initial state and cost function to optimize) while the returned Plan holds the state and input trajectories that result from optimizing the problem (if a solution exists). The solver string is used to select the backend quadratic programming solver.
Example
Let us define a triple integrator:
    import numpy as np

    horizon_duration = 1.0  # [s]
    N = 16  # number of discretization steps
    T = horizon_duration / N
    A = np.array([[1.0, T, T ** 2 / 2.0], [0.0, 1.0, T], [0.0, 0.0, 1.0]])
    B = np.array([T ** 3 / 6.0, T ** 2 / 2.0, T]).reshape((3, 1))
Suppose for the sake of example that acceleration is the main constraint acting on our system. We thus define an acceleration constraint |acceleration| <= max_accel:
    max_accel = 3.0  # [m] / [s] / [s]
    accel_from_state = np.array([0.0, 0.0, 1.0])
    C = np.vstack([+accel_from_state, -accel_from_state])
    e = np.array([+max_accel, +max_accel])
This leads us to the following linear MPC problem:
    from qpmpc import MPCProblem

    x_init = np.array([0.0, 0.0, 0.0])
    x_goal = np.array([1.0, 0.0, 0.0])
    problem = MPCProblem(
        transition_state_matrix=A,
        transition_input_matrix=B,
        ineq_state_matrix=C,
        ineq_input_matrix=None,
        ineq_vector=e,
        initial_state=x_init,
        goal_state=x_goal,
        nb_timesteps=N,
        terminal_cost_weight=1.0,
        stage_state_cost_weight=None,
        stage_input_cost_weight=1e-6,
    )
We can solve it with:
    from qpmpc import solve_mpc

    solution = solve_mpc(problem, solver="proxqp")
The solution holds complete state and input trajectories as stacked vectors. For instance, we can plot positions, velocities and accelerations as follows:
    import matplotlib.pyplot as plt

    t = np.linspace(0.0, horizon_duration, N + 1)
    X = solution.states
    positions, velocities, accelerations = X[:, 0], X[:, 1], X[:, 2]
    plt.ion()
    plt.plot(t, positions)
    plt.plot(t, velocities)
    plt.plot(t, accelerations)
    plt.grid(True)
    plt.legend(("position", "velocity", "acceleration"))
This example produces the following trajectory:
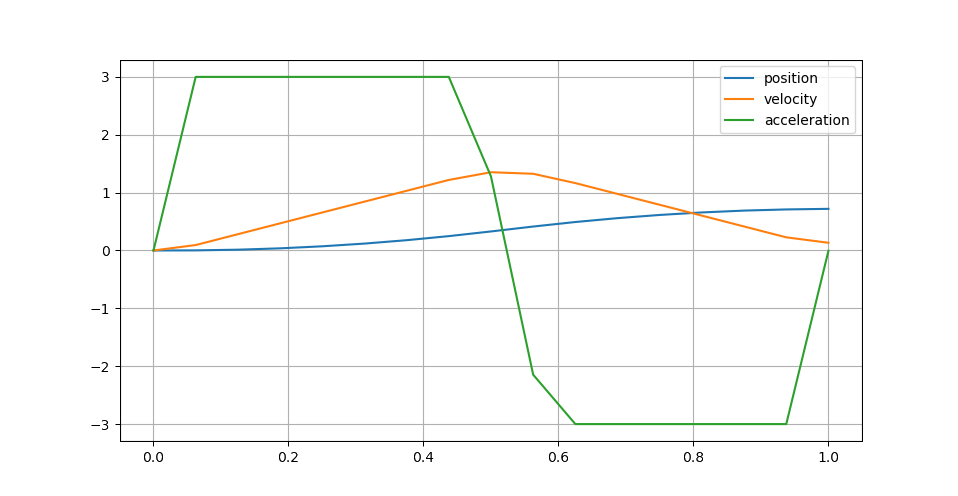
The behavior is a weighted compromise between reaching the goal state (weight 1.0) and keeping reasonable finite jerk inputs (weight 1e-6). The latter mitigate bang-bang accelerations but prevent fully reaching the goal within the horizon. See the examples folder for more examples.
Areas of improvement
This module is incomplete with regards to the following points:
- Cost functions: can be extended to general linear stage cost functions
- Documentation: there are some undocumented functions
- Test coverage: only one end-to-end test
Check out the contribution guidelines if you are interested in lending a hand.
Alternatives
You can also check out the following open-source libraries:
Linear model predictive control
| Name | Systems | Languages | License |
|---|---|---|---|
| Copra (LTV fork) | Linear time-variant | C++, Python | BSD-2-Clause |
| Copra (original) | Linear time-invariant | C++, Python | BSD-2-Clause |
| mpc-interface | Linear time-variant | C++, Python | BSD-2-Clause |
| pyMPC | Linear time-variant | Python | MIT |
Nonlinear model predictive control
| Name | Systems | Languages | License |
|---|---|---|---|
| acados | Nonlinear | C++, Matlab, Python | BSD-2-Clause |
| Aligator | Nonlinear | C++, Python | BSD-2-Clause |
| Crocoddyl | Nonlinear | C++, Python | BSD-3-Clause |
1 maintainer

Metadata
1 maintainer
Release files for qpmpc 3.3.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| qpmpc-3.3.0.tar.gz | 195.2 kB | Without provenance | Details for qpmpc-3.3.0.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| qpmpc-3.3.0-py3-none-any.whl | Python 3 | none | any | Details for qpmpc-3.3.0-py3-none-any.whl |
Total release size: 215.8 kB
Release files / qpmpc-3.3.0.tar.gz
| Download URL | qpmpc-3.3.0.tar.gz |
|---|---|
| Size | 195.2 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
c39db2adcaa5d1d84bf8ad7c9beb46fbfbcfb6bd985f2fedfac46a6144c33b2b
|
|
BLAKE2b-256 checksum How to use checksums |
c65902ceb4a033d4409df6109c23c7047b2e130d896e0681342ae1c46e275c36
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
python-requests/2.32.4
|
Release files / qpmpc-3.3.0-py3-none-any.whl
| Download URL | qpmpc-3.3.0-py3-none-any.whl |
|---|---|
| Size | 20.5 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
ff7cdfec73a9e5acf12ae2a3b5b5a6172886a17b236f083902059106c83bd553
|
|
BLAKE2b-256 checksum How to use checksums |
20c81fc4ef45fdc02165615abca396a957d87a398884317e9fb49620180b0530
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
python-requests/2.32.4
|
Security for qpmpc 3.3.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














