
This release is a pre-release and may not be stable for production use.


RoboKit is a high-performance, general-purpose toolkit for versatile robotic tasks. It scales from one problem to thousands in parallel. It provides a library of cost terms and optimizers that compose freely. Built-in tasks such as IK, motion planning, and retargeting are validated on real robots.
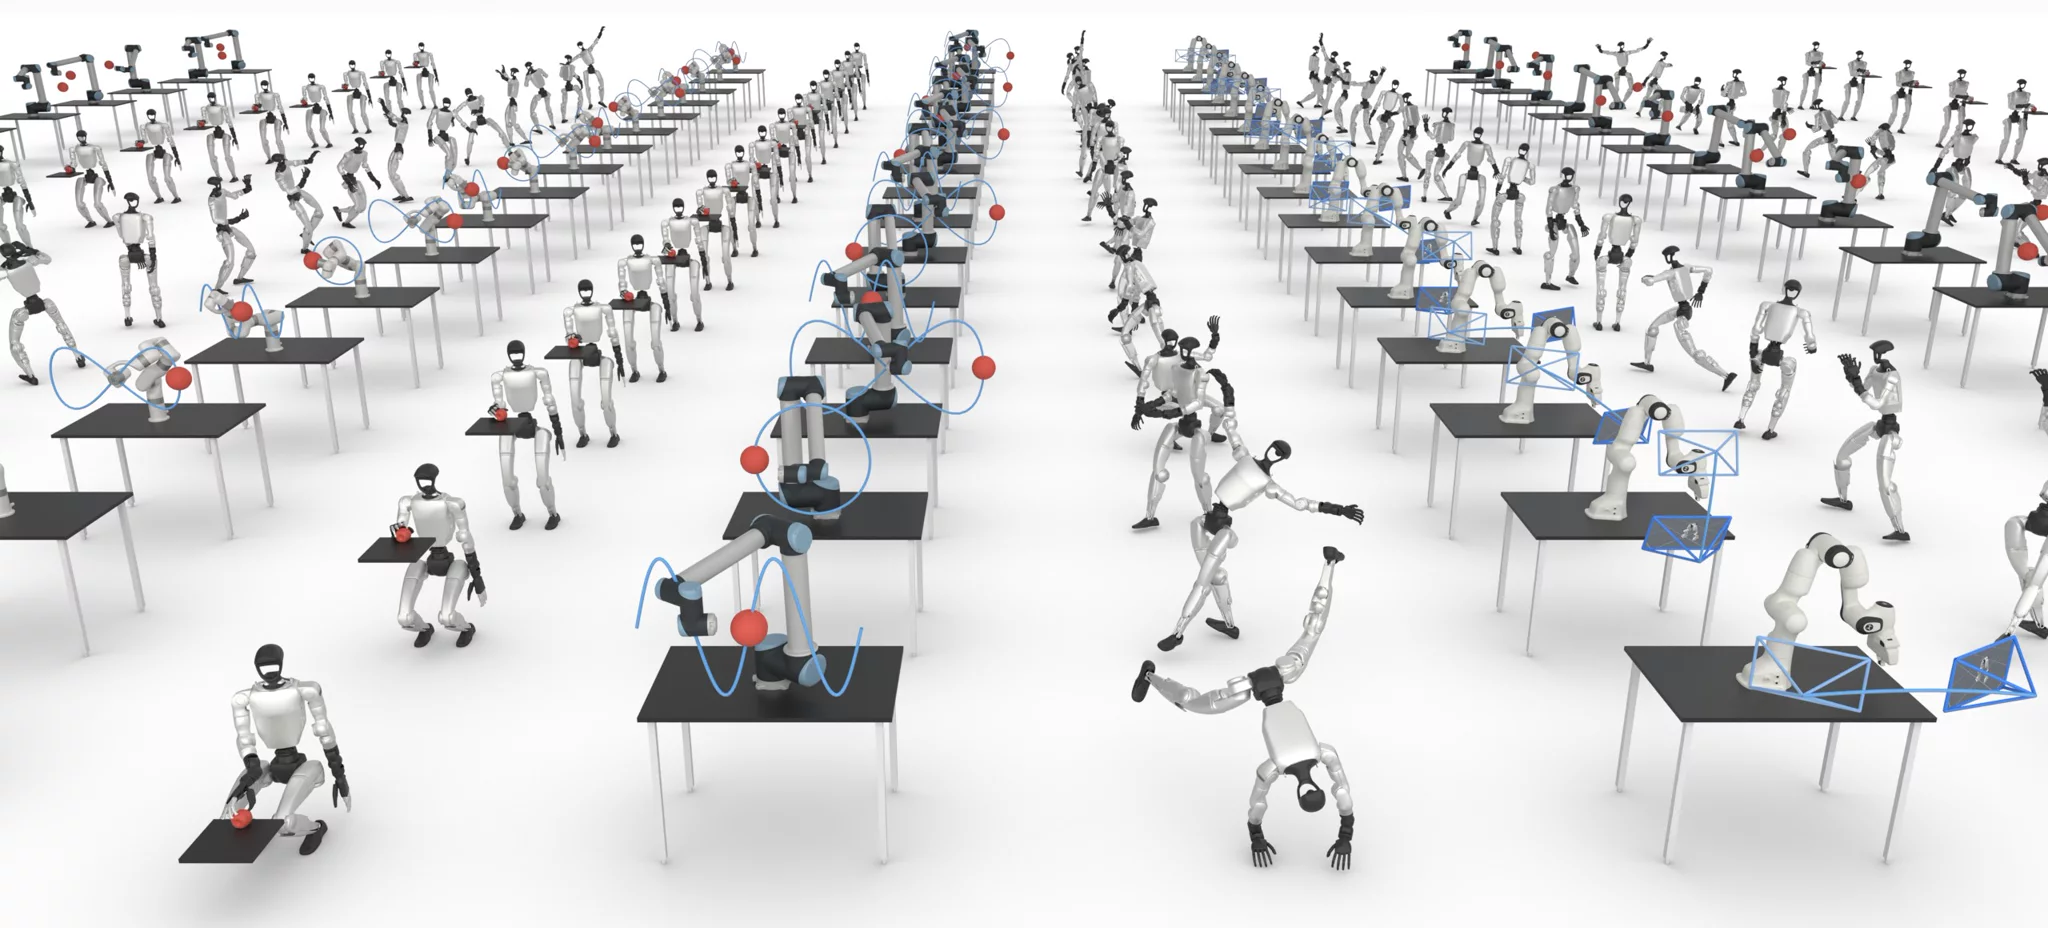
Thousands of robots solving in parallel.
Benchmarks
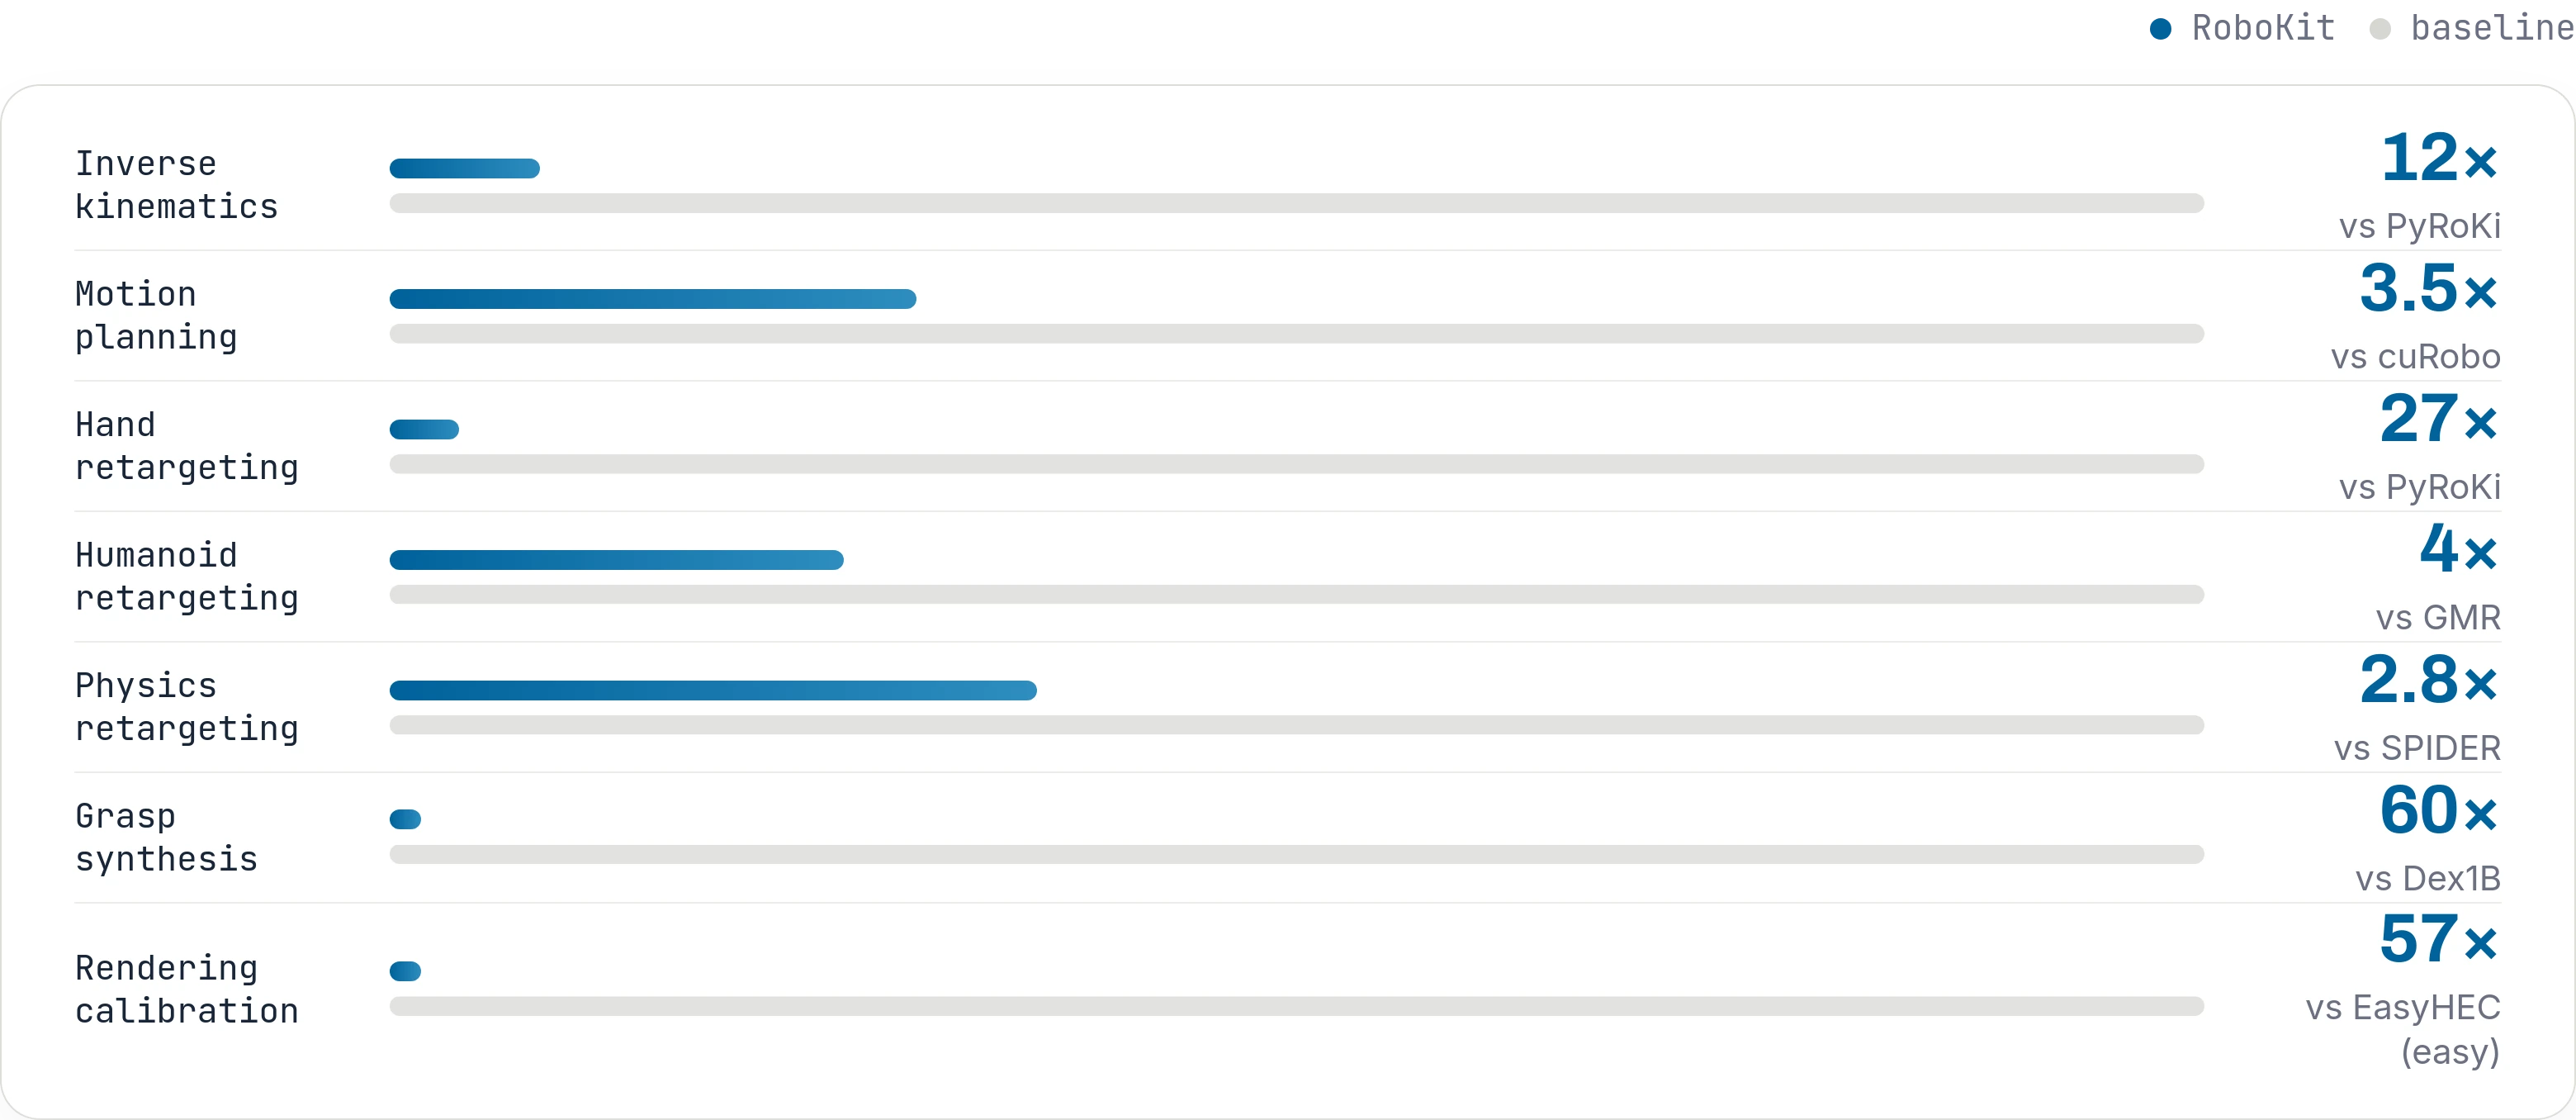
Bars are wall-clock time on the same task, baseline normalized to full width. Check the paper for benchmark details.
Optimization with Simulation
 Pen Spinning A Sharpa hand spins a pen in its fingers. |
 Cube Rotation A LEAP hand turns a cube to random goals. |
 Notebook Opening Two XHands open a hinged ARCTIC notebook. |
 Box Carrying A G1 lifts and carries a box. |
 Climbing A G1 climbs a box on hands and knees. |
 Jumping A Go2 lands four 40 cm jumps on target footholds. |
Optimization with Analytic Objectives
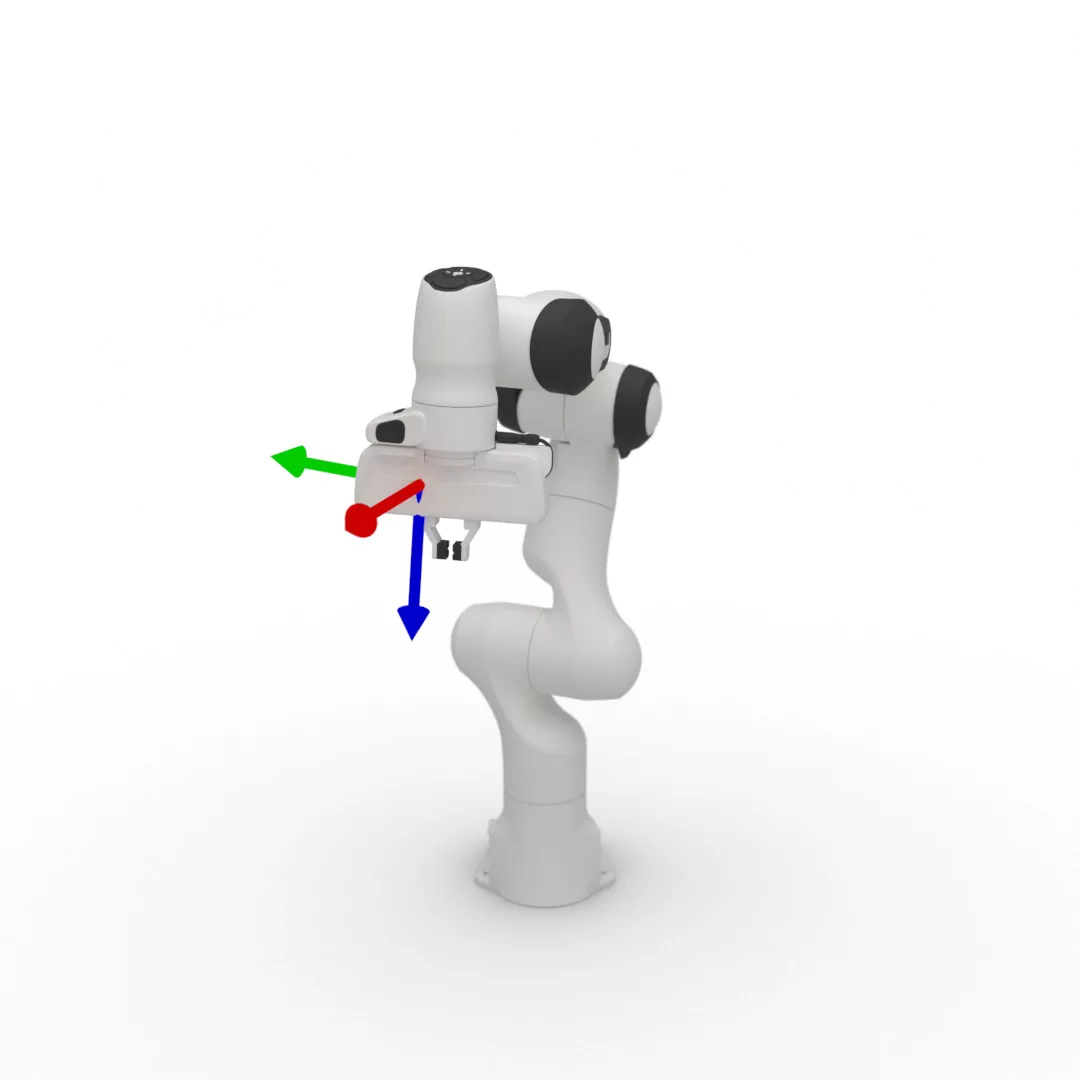 IK Multi-link targets, fixed or floating base. |
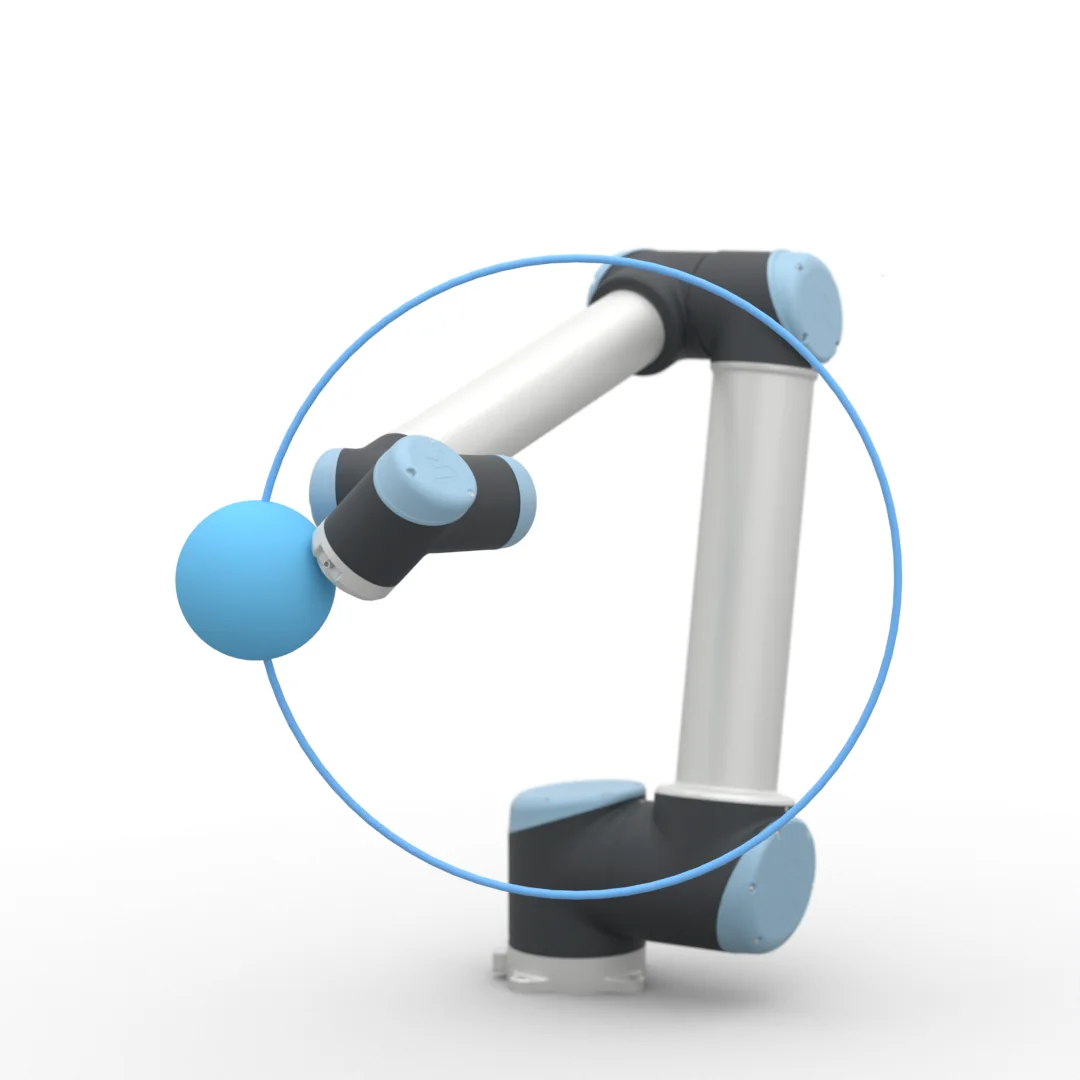 Motion Planning Collision-free trajectories, offline or online. |
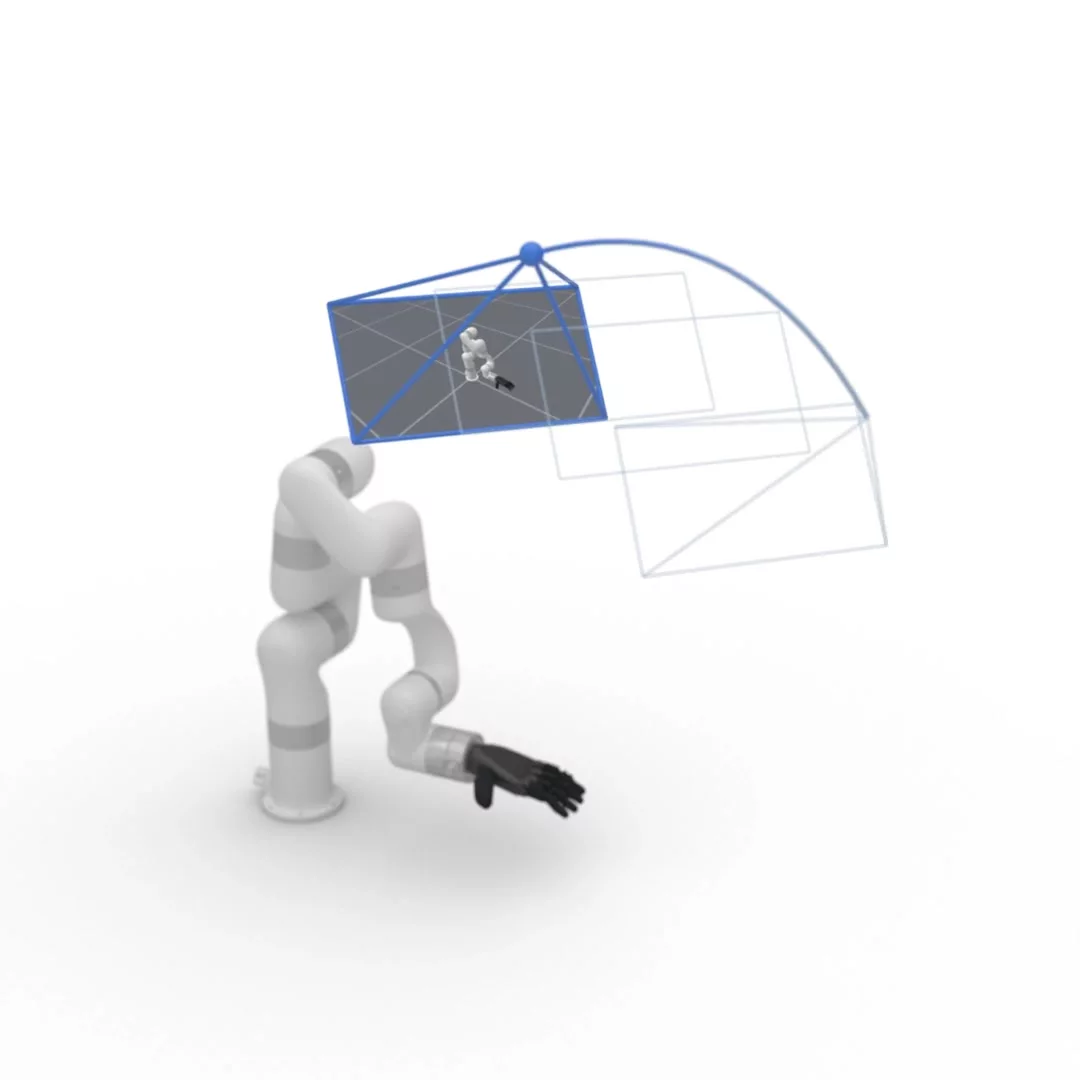 Hand-Eye Calibration Camera pose from rendered robot masks. |
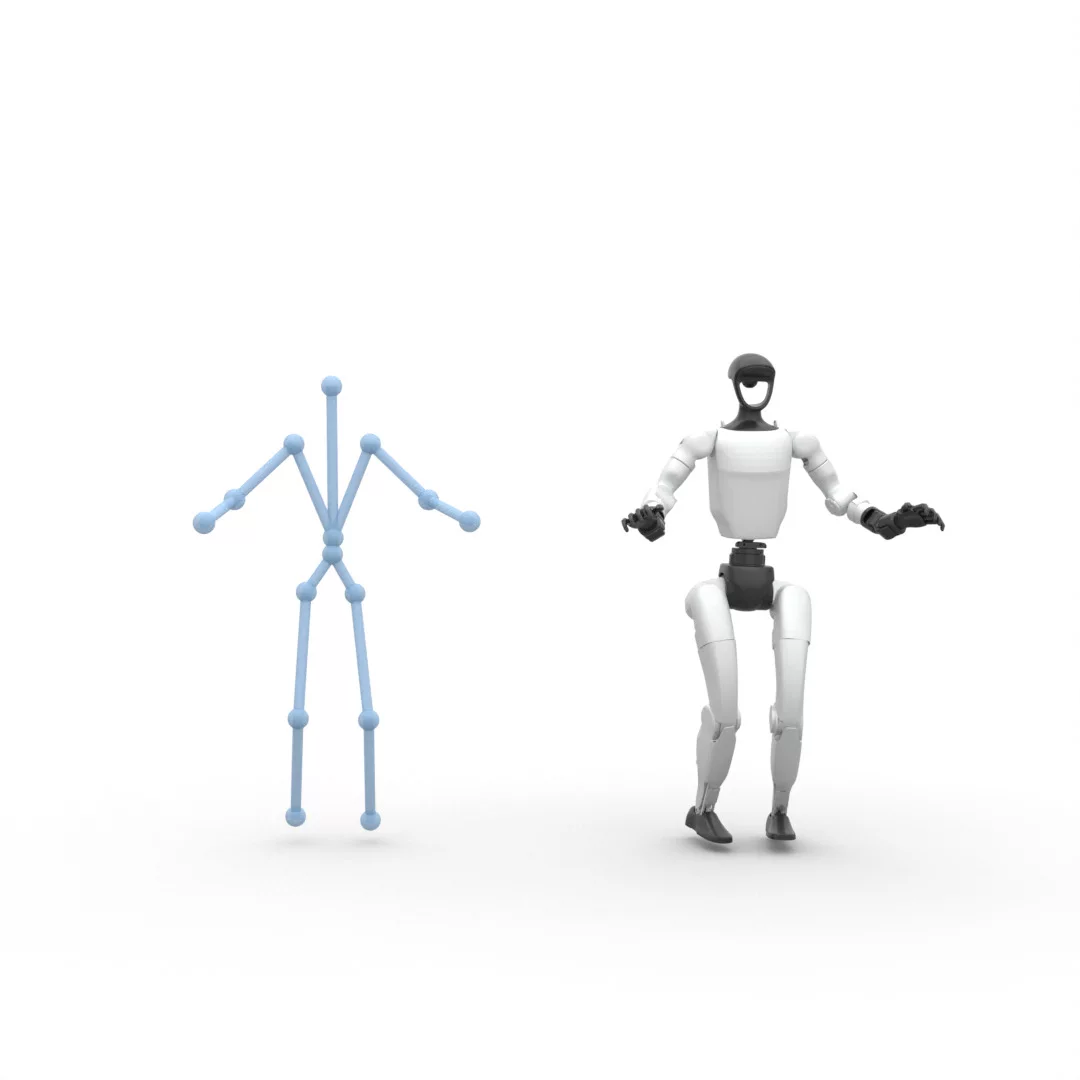 Humanoid Retargeting Human motion capture to a humanoid. |
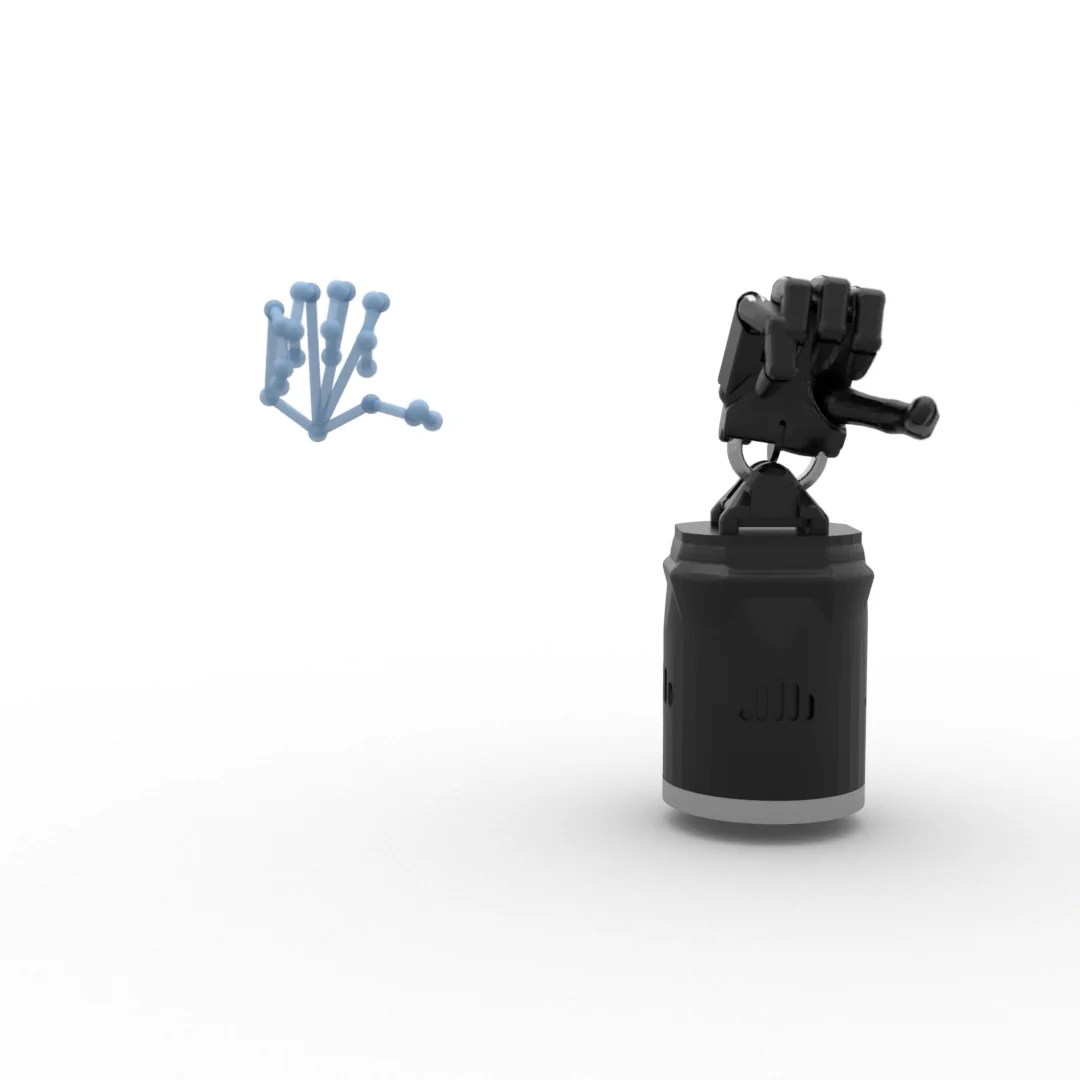 Hand Retargeting Human hand motion to a robot hand. |
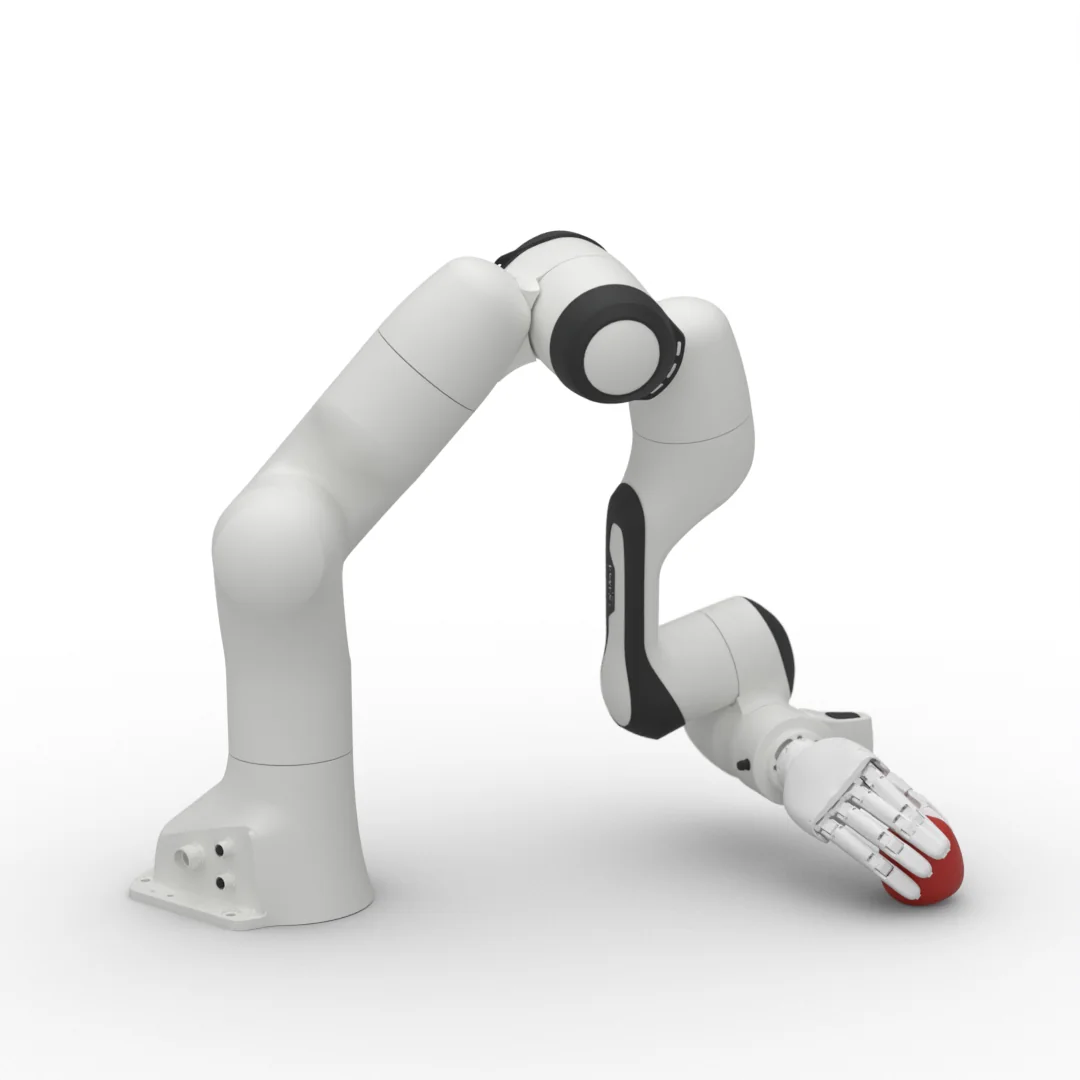 Grasp Optimization Force-closure grasps for any hand or body. |
How it works

| Component | Role | Read more |
|---|---|---|
| Robot | Load URDF or MJCF models and compute batched, differentiable kinematics. | Robot |
| Objectives | Cost terms that define a task: pose matching, collision, limits, contacts. | Terms |
| Optimizers | Sampling and gradient methods that minimize the objectives in parallel. | Optimization |
| Acceleration | Fast geometry and rendering for contact-rich and calibration tasks. | Geometry |
| Distillation | Train policies on solver outputs for even faster inference. |
Installation
Requires Python 3.8 or newer:
uv add robokit # or: pip install robokit
PyTorch is optional. See Installation for source installs and extras.
Quick links
Citation
@inproceedings{ye2026robokit,
  title     = {RoboKit: Accelerating Parallel Differentiable Optimization for Robot Learning},
  author    = {Ye, Jianglong and Peng, Xuanbin and Mc Gartoll, Conor and Jing, Changwei and Wei, Lai and Chen, Jiali and Zou, Xueyan and Wang, Xiaolong},
  booktitle = {Conference on Robot Learning (CoRL)},
  year      = {2026}
}
1 maintainer

Metadata
1 maintainer
Release files for robokit 1.0.0rc1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| robokit-1.0.0rc1.tar.gz | 721.5 kB | Without provenance | Details for robokit-1.0.0rc1.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| robokit-1.0.0rc1-py3-none-any.whl | Python 3 | none | any | Details for robokit-1.0.0rc1-py3-none-any.whl |
Total release size: 1.7 MB
Release files / robokit-1.0.0rc1.tar.gz
| Download URL | robokit-1.0.0rc1.tar.gz |
|---|---|
| Size | 721.5 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
486ddafb34db746b9cfdbf7eb7b0e839d5787f6cee0dca6e76f6a837aa49c96e
|
|
BLAKE2b-256 checksum How to use checksums |
a312199ad0fc67a69e710c7544e75b5a53a51fa711cc1b25470ab88788e42550
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
uv/0.13.6 {"installer":{"name":"uv","version":"0.13.6","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":{"name":"Ubuntu","version":"26.04","id":"resolute","libc":null},"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":true}
|
Release files / robokit-1.0.0rc1-py3-none-any.whl
| Download URL | robokit-1.0.0rc1-py3-none-any.whl |
|---|---|
| Size | 977.2 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
9872f91fc17f1dd2b37f38410c34d8683f330f64067463c91a654cb87f75cf86
|
|
BLAKE2b-256 checksum How to use checksums |
f262e4519fe68e156a9576b5f1d7a4ec41a1c12cf9b99143024e94d229cf04ab
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
uv/0.13.6 {"installer":{"name":"uv","version":"0.13.6","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":{"name":"Ubuntu","version":"26.04","id":"resolute","libc":null},"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":true}
|
Security for robokit 1.0.0rc1
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.













