



RoboSkills is a low-cost, minimal set of agent workflows and tools for robotics.
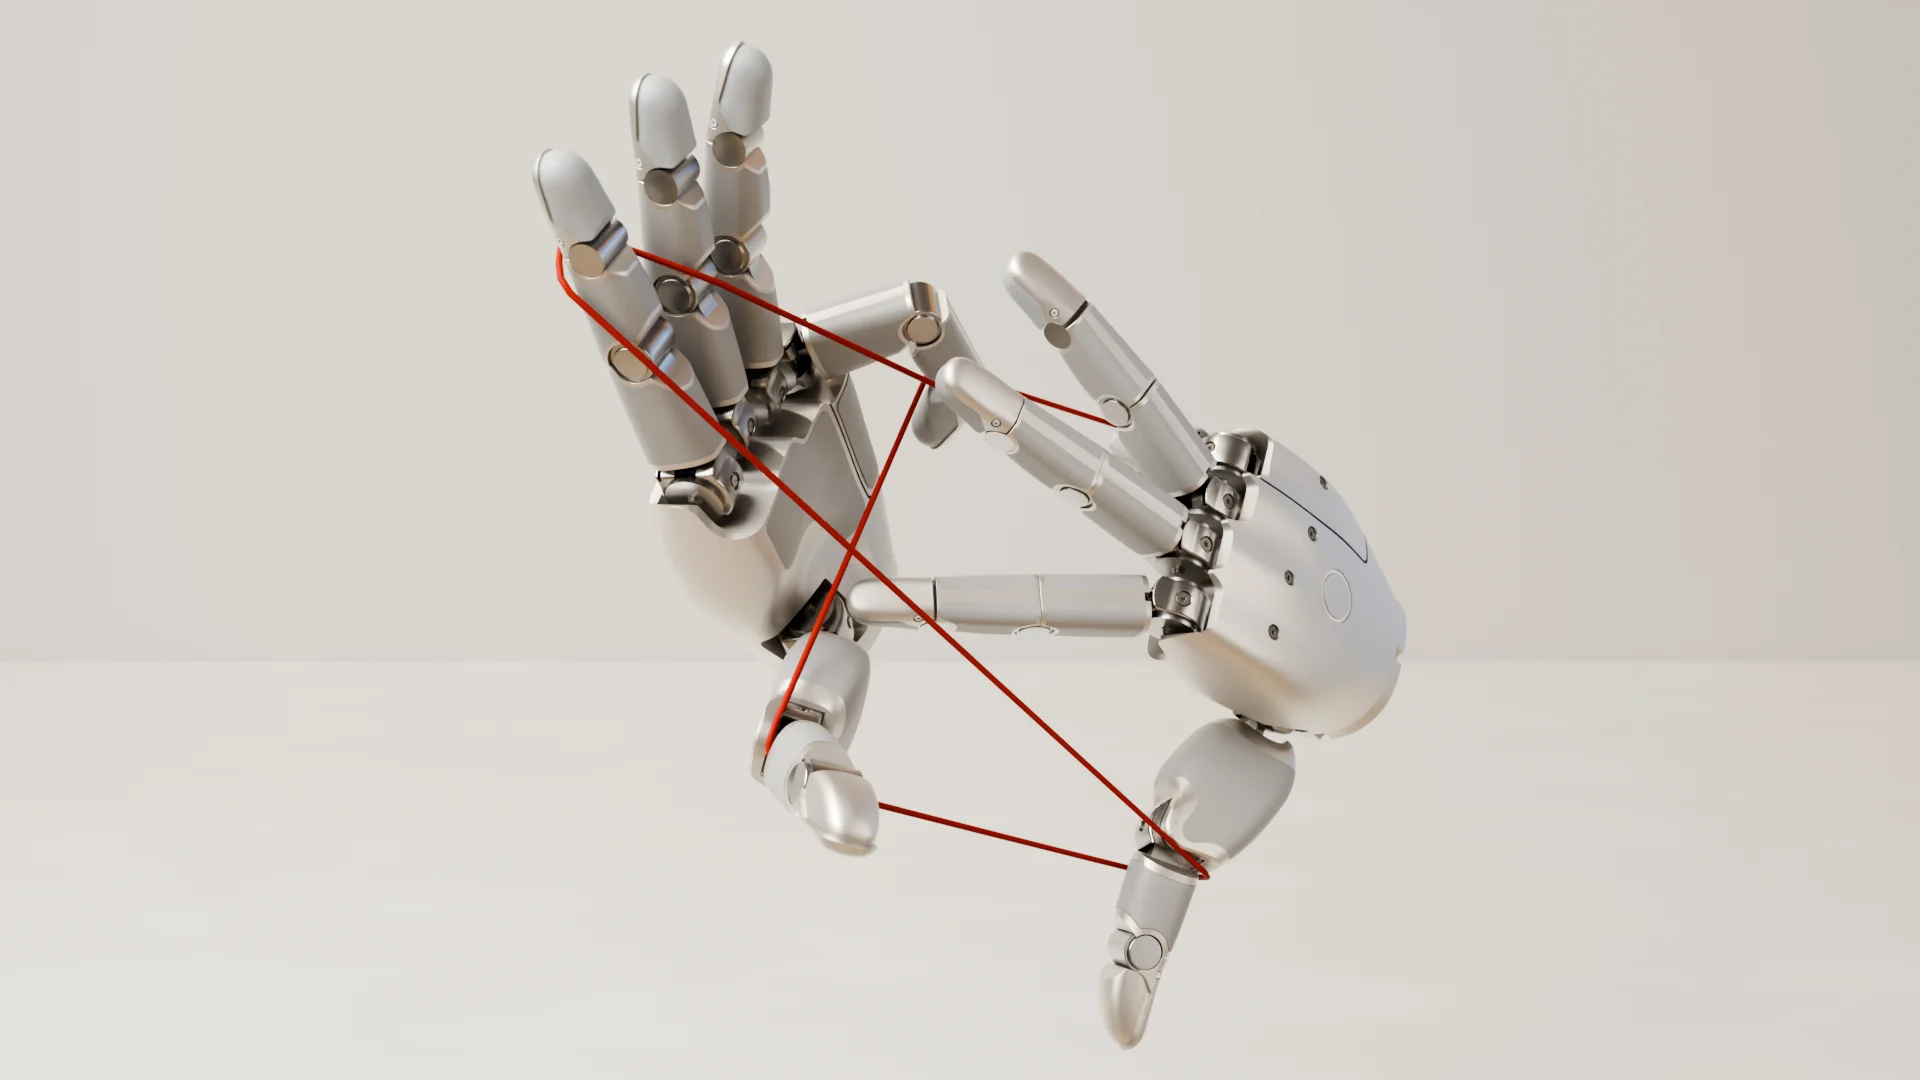
Sharpa hands playing cat's cradle, reconstructed from a human video.
Workflows
 Auto Research Improve policies and reusable skills through repeated simulation experiments. Setting: Auto-research; no direct privileged simulator state in the policy API. |
 Agent as Policy An LLM observes an episode and chooses actions turn by turn. Setting: Zero/one-shot demonstrations; no auto-research. |
 Agentic Simulation Solve simulation tasks from natural-language instructions. Setting: Privileged simulator information available. |
 Real2Sim Build interactive simulations from demonstrations. Setting: Physics simulation included. |
 Motion Generation One agent turns a text, image or video request into a motion video. Setting: Kinematic motion and rendering; no physics. |
Features
Low cost
With suitable tools, agents reach comparable performance on fewer, cheaper tokens.
| Real2Sim · DexYCB potted meat can | Motion Generation · Tennis serve |
|---|---|
| Cost $0.09. 11% of Codex. | Cost $0.00. 0% of Claude Code. |
 |
 |
| Agent as Policy · RoboDojo stack blocks | Auto Research · RoboDojo press by number |
| Cost $0.16 with DeepSeek. 7% of Claude Code. Both 5/5 on 5 seeds. | Cost $0.14 with DeepSeek. 13% of Claude Code. Both 3/3 on 3 seeds. |
 |
 |
Minimal
We commit to keeping each workflow under 1,000 lines of code.
Tools
| Tool | Does | Reference |
|---|---|---|
 RoboKit |
kinematics, motion planning, robot hands | Code |
| GraspKit |
learned grasps | Code |
 SAM 3 |
text → masks | Paper · Code |
| SAM 3D |
image → object mesh | Paper · Code |
 MoGe |
image → depth | Paper · Code |
 GeoCalib |
image → gravity | Paper · Code |
 HaWoR |
video → hand motion | Paper · Code |
| WiLoR |
image → hands (MANO) | Paper · Code |
 GVHMR |
video → human motion | Paper · Code |
 Kimodo |
text → G1 or human motion | Paper · Code |
 Blender |
rendering | Site · Code |
 CoACD |
mesh → convex collision parts | Paper · Code |
 MuJoCo |
physics, IK, contact feedback, rendering | Paper · Code |
Installation
Requires Python 3.10 or newer:
uv add roboskills # or: pip install roboskills
Quick links
1 maintainer

Metadata
1 maintainer
Release files for roboskills 0.1.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | Actions |
|---|---|---|---|---|
| roboskills-0.1.0.tar.gz | 2.0 MB | Without provenance | Details for roboskills-0.1.0.tar.gz |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Actions Reset |
|---|---|---|---|---|
| roboskills-0.1.0-py3-none-any.whl | Python 3 | none | any | Details for roboskills-0.1.0-py3-none-any.whl |
Total release size: 4.0 MB
Release files / roboskills-0.1.0.tar.gz
| Download URL | roboskills-0.1.0.tar.gz |
|---|---|
| Size | 2.0 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
5405efb02622a0facc0cc54bf4c5779d4f5673986bb2264bca88e22dcb1e9b21
|
|
BLAKE2b-256 checksum How to use checksums |
a6ce74273285f5c63c7f38e9e4ac662a59e2d040c08707837ce00d5473a8f33b
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
uv/0.13.6 {"installer":{"name":"uv","version":"0.13.6","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":{"name":"Ubuntu","version":"26.04","id":"resolute","libc":null},"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":true}
|
Release files / roboskills-0.1.0-py3-none-any.whl
| Download URL | roboskills-0.1.0-py3-none-any.whl |
|---|---|
| Size | 2.1 MB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
db9d24e44fd1f0e90fd5070880642c172ba73192aa101c31b4aae35dc300fe88
|
|
BLAKE2b-256 checksum How to use checksums |
36698ae157df6209f5c0ea3da021b28c2701fc51aaed483f46b962355c6984f8
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
uv/0.13.6 {"installer":{"name":"uv","version":"0.13.6","subcommand":["publish"]},"python":null,"implementation":{"name":null,"version":null},"distro":{"name":"Ubuntu","version":"26.04","id":"resolute","libc":null},"system":{"name":null,"release":null},"cpu":null,"openssl_version":null,"setuptools_version":null,"rustc_version":null,"ci":true}
|
Security for roboskills 0.1.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
No provenance found
None of the files in this release were uploaded with provenance metadata.
A note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














