
Robotics Toolbox for Python
Robotics without the cruft
A high-productivity framework for robotics research and education.


GitHub • Wiki • Changelog • Installation
Status & Project Health



Ecosystem & Dependencies

Contents
- Synopsis
- Getting going
- Tutorials
- Code Examples
- Toolbox Research Applications
- References
- Using the Toolbox in your Open Source Code?
- Common Issues and Solutions
- Build a JupyterLite/Pyodide Wasm wheel
Synopsis
This toolbox brings robotics-specific functionality to Python, and leverages Python's advantages of portability, ubiquity and support, and the capability of the open-source ecosystem for linear algebra (numpy, scipy), graphics (matplotlib, three.js, WebGL), interactive development (Jupyter, JupyterLab, mybinder.org), and documentation (sphinx).
The Toolbox provides tools for representing the kinematics and dynamics of serial-link manipulators - you can easily create your own in Denavit-Hartenberg form, import a URDF file, or use over 50 supplied models for well-known contemporary robots from Franka-Emika, Kinova, Universal Robotics, Rethink as well as classical robots such as the Puma 560 and the Stanford arm.
The Toolbox contains fast implementations of kinematic operations. The forward kinematics and the manipulator Jacobian can be computed in less than 1 microsecond while numerical inverse kinematics can be solved in as little as 4 microseconds.
The toolbox also supports mobile robots with functions for robot motion models (unicycle, bicycle), path planning algorithms (bug, distance transform, D*, PRM), kinodynamic planning (lattice, RRT), localization (EKF, particle filter), map building (EKF) and simultaneous localization and mapping (EKF).
The Toolbox provides:
- code that is mature and provides a point of comparison for other implementations of the same algorithms;
- routines which are generally written in a straightforward manner which allows for easy understanding, perhaps at the expense of computational efficiency;
- source code which can be read for learning and teaching;
- backward compatability with the Robotics Toolbox for MATLAB
The Toolbox leverages the Spatial Maths Toolbox for Python to provide support for data types such as SO(n) and SE(n) matrices, quaternions, twists and spatial vectors.
Getting going
You will need Python >= 3.10
Using pip
Install a snapshot from PyPI
pip install roboticstoolbox-python
Available options are:
swiftinstall Swift, a web-based visualizerqpinstall quadratic-programming IK dependencies (qpsolvers,quadprog)collisioninstall collision checking with coal andtrimeshtoolinstallIPythonandpygments, needed to run thertbtoolinteractive shellallinstallswift,qp,collision, andtool
Windows note:
coaldoes not publish Windows wheels on PyPI, so thecollision/allextras skip it there and collision checking is unavailable viapipon Windows. It's available viaconda install -c conda-forge coal-pythonif needed. Everything else in the Toolbox works normally.
Put the options in a comma separated list like
pip install roboticstoolbox-python[optionlist]
If you want the Swift visualizer, install the swift extra.
Install matrix:
- Core only
pip install roboticstoolbox-python
- Swift visualizer only
pip install roboticstoolbox-python[swift]
- QP solver dependencies only
pip install roboticstoolbox-python[qp]
- Collision checking dependencies only
pip install roboticstoolbox-python[collision]
rtbtoolinteractive shell dependencies only
pip install roboticstoolbox-python[tool]
- Everything (swift + qp + collision + tool)
pip install roboticstoolbox-python[all]
- Multiple extras explicitly
pip install roboticstoolbox-python[swift,qp,collision]
From GitHub
To install the bleeding-edge version from GitHub
git clone https://github.com/petercorke/robotics-toolbox-python.git
cd robotics-toolbox-python
pip install -e .
To generate a Wasm wheel that will run in the browser see the instructions here.
Tutorials
 |
 |
Do you want to learn about manipulator kinematics, differential kinematics, inverse-kinematics and motion control? Have a look at our tutorial. This tutorial comes with two articles to cover the theory and 12 Jupyter Notebooks providing full code implementations and examples. Most of the Notebooks are also Google Colab compatible allowing them to run online. |
Code Examples
We will load a model of the Franka-Emika Panda robot defined by a URDF file
import roboticstoolbox as rtb
robot = rtb.models.Panda()
print(robot)

	ERobot: panda (by Franka Emika), 7 joints (RRRRRRR), 1 gripper, geometry, collision
	┌─────┬──────────────┬───────┬─────────────┬────────────────────────────────────────────────┐
	│link │     link     │ joint │   parent    │              ETS: parent to link               │
	├─────┼──────────────┼───────┼─────────────┼────────────────────────────────────────────────┤
	│   0 │ panda_link0  │       │ BASE        │                                                │
	│   1 │ panda_link1  │     0 │ panda_link0 │ SE3(0, 0, 0.333) ⊕ Rz(q0)                      │
	│   2 │ panda_link2  │     1 │ panda_link1 │ SE3(-90°, -0°, 0°) ⊕ Rz(q1)                    │
	│   3 │ panda_link3  │     2 │ panda_link2 │ SE3(0, -0.316, 0; 90°, -0°, 0°) ⊕ Rz(q2)       │
	│   4 │ panda_link4  │     3 │ panda_link3 │ SE3(0.0825, 0, 0; 90°, -0°, 0°) ⊕ Rz(q3)       │
	│   5 │ panda_link5  │     4 │ panda_link4 │ SE3(-0.0825, 0.384, 0; -90°, -0°, 0°) ⊕ Rz(q4) │
	│   6 │ panda_link6  │     5 │ panda_link5 │ SE3(90°, -0°, 0°) ⊕ Rz(q5)                     │
	│   7 │ panda_link7  │     6 │ panda_link6 │ SE3(0.088, 0, 0; 90°, -0°, 0°) ⊕ Rz(q6)        │
	│   8 │ @panda_link8 │       │ panda_link7 │ SE3(0, 0, 0.107)                               │
	└─────┴──────────────┴───────┴─────────────┴────────────────────────────────────────────────┘

	┌─────┬─────┬────────┬─────┬───────┬─────┬───────┬──────┐
	│name │ q0  │ q1     │ q2  │ q3    │ q4  │ q5    │ q6   │
	├─────┼─────┼────────┼─────┼───────┼─────┼───────┼──────┤
	│  qr │  0° │ -17.2° │  0° │ -126° │  0° │  115° │  45° │
	│  qz │  0° │  0°    │  0° │  0°   │  0° │  0°   │  0°  │
	└─────┴─────┴────────┴─────┴───────┴─────┴───────┴──────┘
The symbol @ indicates the link as an end-effector, a leaf node in the rigid-body
tree (Python prompts are not shown to make it easy to copy+paste the code, console output is indented).
We will compute the forward kinematics next
Te = robot.fkine(robot.qr)  # forward kinematics
print(Te)

	0.995     0         0.09983   0.484
	0        -1         0         0
	0.09983   0        -0.995     0.4126
	0         0         0         1
We can solve inverse kinematics very easily. We first choose an SE(3) pose defined in terms of position and orientation (end-effector z-axis down (A=-Z) and finger orientation parallel to y-axis (O=+Y)).
from spatialmath import SE3

Tep = SE3.Trans(0.6, -0.3, 0.1) * SE3.OA([0, 1, 0], [0, 0, -1])
sol = robot.ik_LM(Tep)         # solve IK
print(sol)

	(array([ 0.20592815,  0.86609481, -0.79473206, -1.68254794,  0.74872915,
			2.21764746, -0.10255606]), 1, 114, 7, 2.890164057230228e-07)

q_pickup = sol[0]
print(robot.fkine(q_pickup))    # FK shows that desired end-effector pose was achieved

	 1         -8.913e-05  -0.0003334  0.5996
	-8.929e-05 -1          -0.0004912 -0.2998
	-0.0003334  0.0004912  -1          0.1001
	 0          0           0          1
We can animate a path from the ready pose qr configuration to this pickup configuration
qt = rtb.jtraj(robot.qr, q_pickup, 50)
robot.plot(qt.q, backend='pyplot', movie='panda1.gif')

where we have specified the matplotlib pyplot backend. Blue arrows show the joint axes and the coloured frame shows the end-effector pose.
We can also plot the trajectory in the Swift simulator (a browser-based 3d-simulation environment built to work with the Toolbox)
robot.plot(qt.q)

We can also experiment with velocity controllers in Swift. Here is a resolved-rate motion control example
import swift
import roboticstoolbox as rtb
import spatialmath as sm
import numpy as np

env = swift.Swift()
env.launch(realtime=True)

panda = rtb.models.Panda()
handle = env.add(panda)
handle.q = panda.qr

Tep = panda.fkine(handle.q) * sm.SE3.Trans(0.2, 0.2, 0.45)

arrived = False

dt = 0.05

while not arrived:

    v, arrived = rtb.p_servo(panda.fkine(handle.q), Tep, 1)
    handle.qd = np.linalg.pinv(panda.jacobe(handle.q)) @ v
    env.step(dt)

# Uncomment to stop the browser tab from closing
# env.hold()
env.add(panda) returns a handle owning this instance's live joint state --
drive the simulation via handle.q/handle.qd, not panda.q/panda.qd
directly. panda itself stays a plain, shareable kinematic model, so the
same panda object can back several independent handles/instances at once.

Loading models from robot_descriptions
The Panda example above uses one of the ~50 models shipped with the Toolbox, but many more
robots are available on demand via the robot_descriptions
package, which is installed automatically as a dependency. Passing a bare name (no file suffix)
to URDFRobot fetches and loads it from there:
from roboticstoolbox.models.URDF.URDFRobot import URDFRobot
ur5 = URDFRobot("ur5")
rtb.models.catalog() lists everything available — the models built into the Toolbox as well
as those it can load from robot_descriptions — with filtering by keyword/DoF/model type and
column sorting:
rtb.models.catalog(mtype="URDF", sorton="name")
Run some examples
The notebooks folder contains some tutorial Jupyter notebooks which you can browse on GitHub. Additionally, have a look in the examples folder for many ready to run examples.
References
Key papers
- P. Corke, "A computer tool for simulation and analysis: the Robotics Toolbox for MATLAB," Proc. National Conf. Australian Robot Association, pp. 319–330, Melbourne, July 1995. [PDF]
- P. Corke, "A robotics toolbox for MATLAB," IEEE Robotics and Automation Magazine, 3(1):24–32, Sept. 1996. [IEEE Xplore]
- P. Corke, "A simple and systematic approach to assigning Denavit-Hartenberg parameters," IEEE Transactions on Robotics, 23(3):590–594, 2007. [IEEE Xplore] — introduces the Elementary Transform Sequence (ETS) notation used throughout the Toolbox.
- J. Haviland and P. Corke, "A systematic approach to computing the manipulator Jacobian and Hessian using the elementary transform sequence," arXiv preprint, 2020. [arXiv]
- P. Corke and J. Haviland, "Not your grandmother's toolbox – the Robotics Toolbox reinvented for Python," Proc. ICRA 2021. [IEEE Xplore] [PDF]
Talks
- Peter Corke – The Robotics Toolbox: 30 Years Old and Still Going Strong — a retrospective on the Toolbox's history and motivation, a good starting point before diving into the API.
Related book
The Toolbox is a companion to Peter Corke's textbook Robotics, Vision & Control (Springer) — many docstrings and examples reference specific figures/sections from the book.
Citing the Toolbox
If the toolbox helped you in your research, please cite
@inproceedings{rtb,
  title={Not your grandmother’s toolbox--the Robotics Toolbox reinvented for Python},
  author={Corke, Peter and Haviland, Jesse},
  booktitle={2021 IEEE International Conference on Robotics and Automation (ICRA)},
  pages={11357--11363},
  year={2021},
  organization={IEEE}
}
Using the Toolbox in your Open Source Code?
If you are using the Toolbox in your open source code, feel free to add our badge to your readme!
For the powered by robotics toolbox badge

copy the following
[](https://github.com/petercorke/robotics-toolbox-python)
For the powered by python robotics badge

copy the following
[](https://github.com/petercorke/robotics-toolbox-python)
Common Issues and Solutions
See the common issues with fixes here.
Using the Toolbox with Windows?
Graphical visualisation via Swift is currently not supported under Windows. However there is a hotfix, by changing in SwiftRoute.py
self.path[9:] to self.path[10:]
Toolbox Research Applications
The toolbox is incredibly useful for developing and prototyping algorithms for research, thanks to the exhaustive set of well documented and mature robotic functions exposed through clean and painless APIs. Additionally, the ease at which a user can visualize their algorithm supports a rapid prototyping paradigm.
Publication List
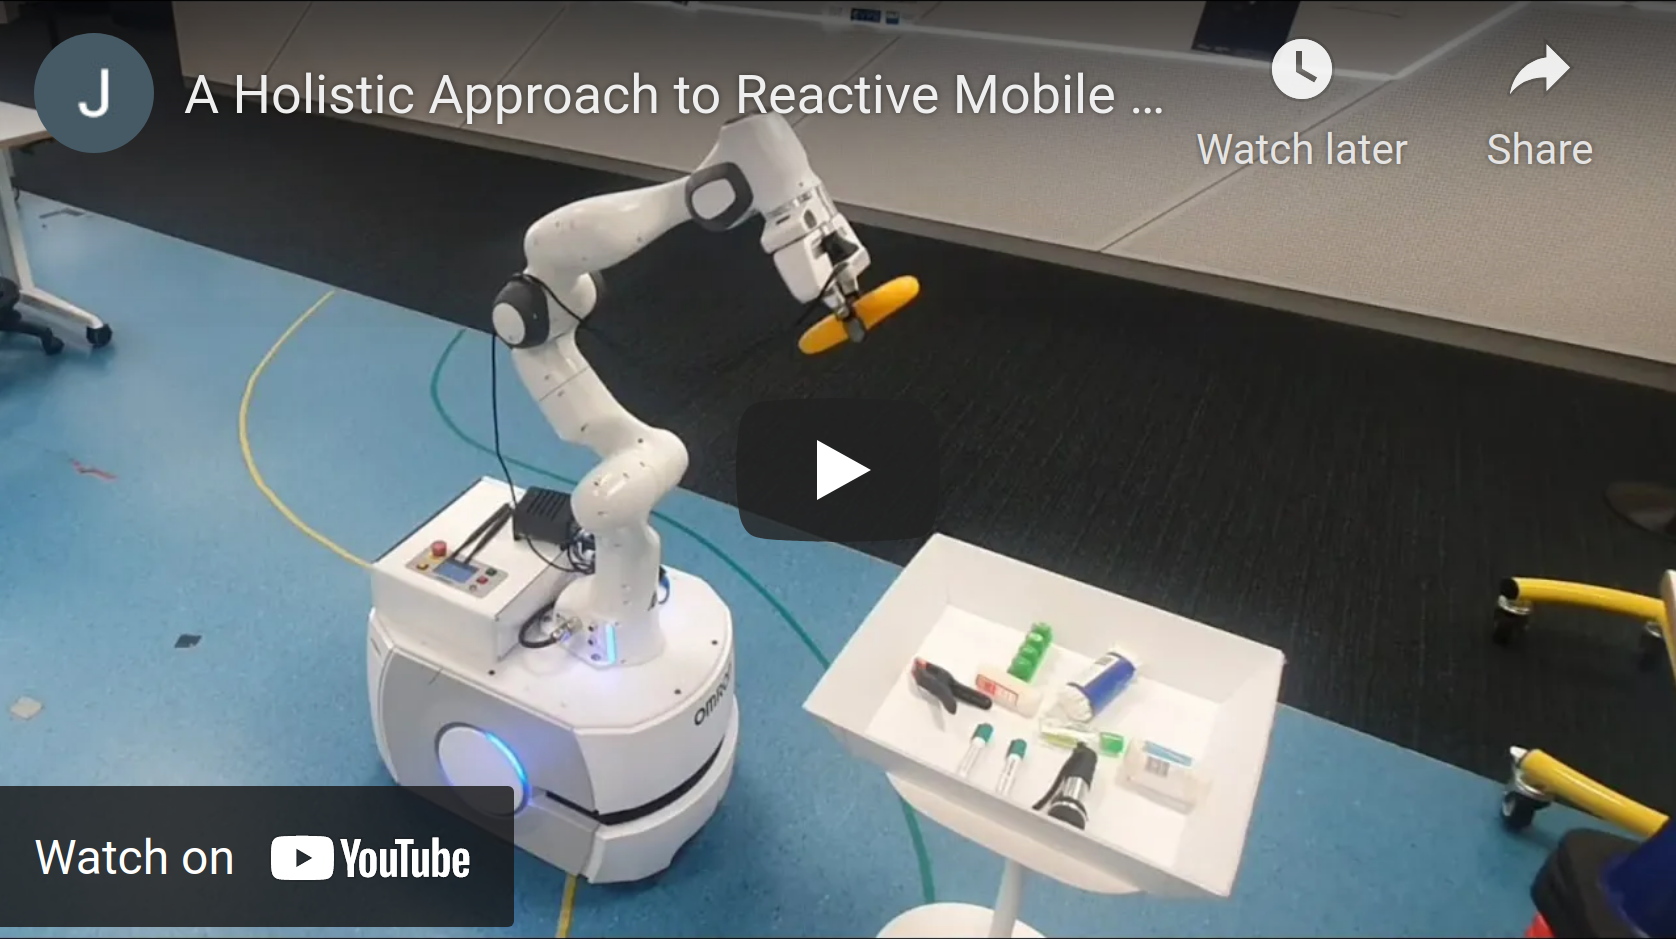
J. Haviland, N. Sünderhauf and P. Corke, "A Holistic Approach to Reactive Mobile Manipulation," in IEEE Robotics and Automation Letters, doi: 10.1109/LRA.2022.3146554. In the video, the robot is controlled using the Robotics toolbox for Python and features a recording from the Swift Simulator.
[Arxiv Paper] [IEEE Xplore] [Project Website] [Video] [Code Example]
J. Haviland and P. Corke, "NEO: A Novel Expeditious Optimisation Algorithm for Reactive Motion Control of Manipulators," in IEEE Robotics and Automation Letters, doi: 10.1109/LRA.2021.3056060. In the video, the robot is controlled using the Robotics toolbox for Python and features a recording from the Swift Simulator.
[Arxiv Paper] [IEEE Xplore] [Project Website] [Video] [Code Example]
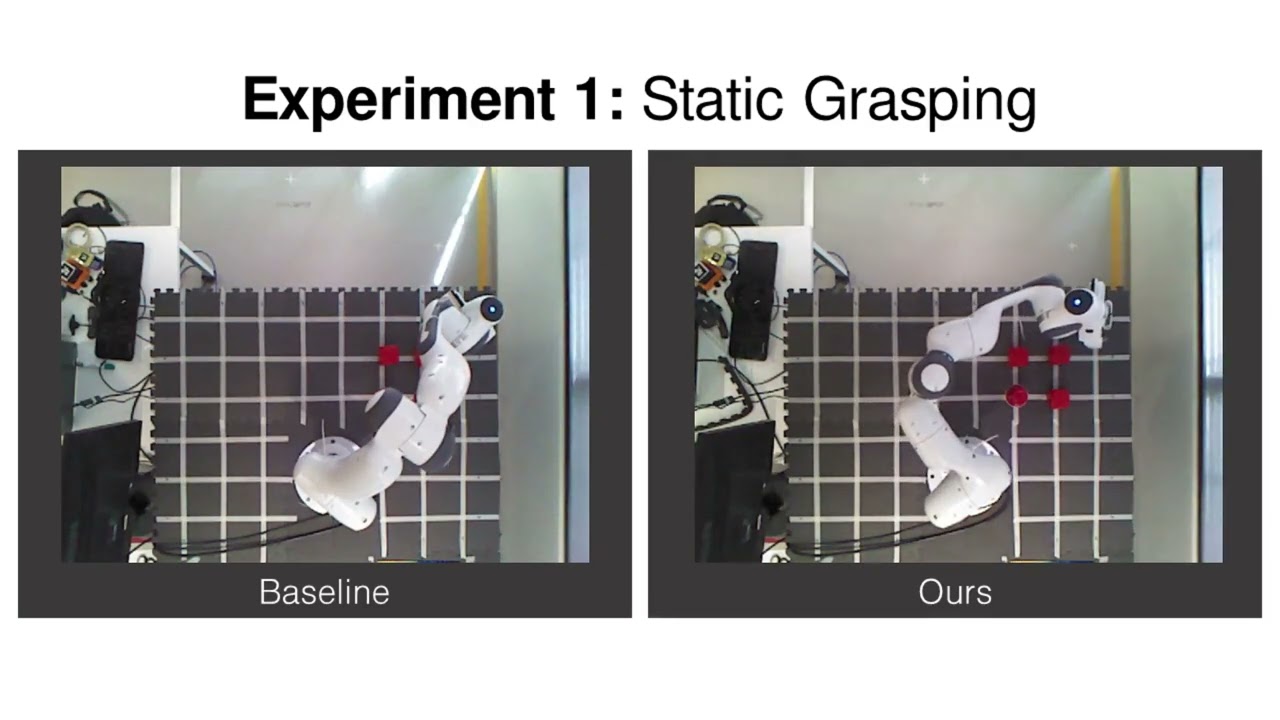
K. He, R. Newbury, T. Tran, J. Haviland, B. Burgess-Limerick, D. Kulić, P. Corke, A. Cosgun, "Visibility Maximization Controller for Robotic Manipulation", in IEEE Robotics and Automation Letters, doi: 10.1109/LRA.2022.3188430. In the video, the robot is controlled using the Robotics toolbox for Python and features a recording from the Swift Simulator.
[Arxiv Paper] [IEEE Xplore] [Project Website] [Video] [Code Example]
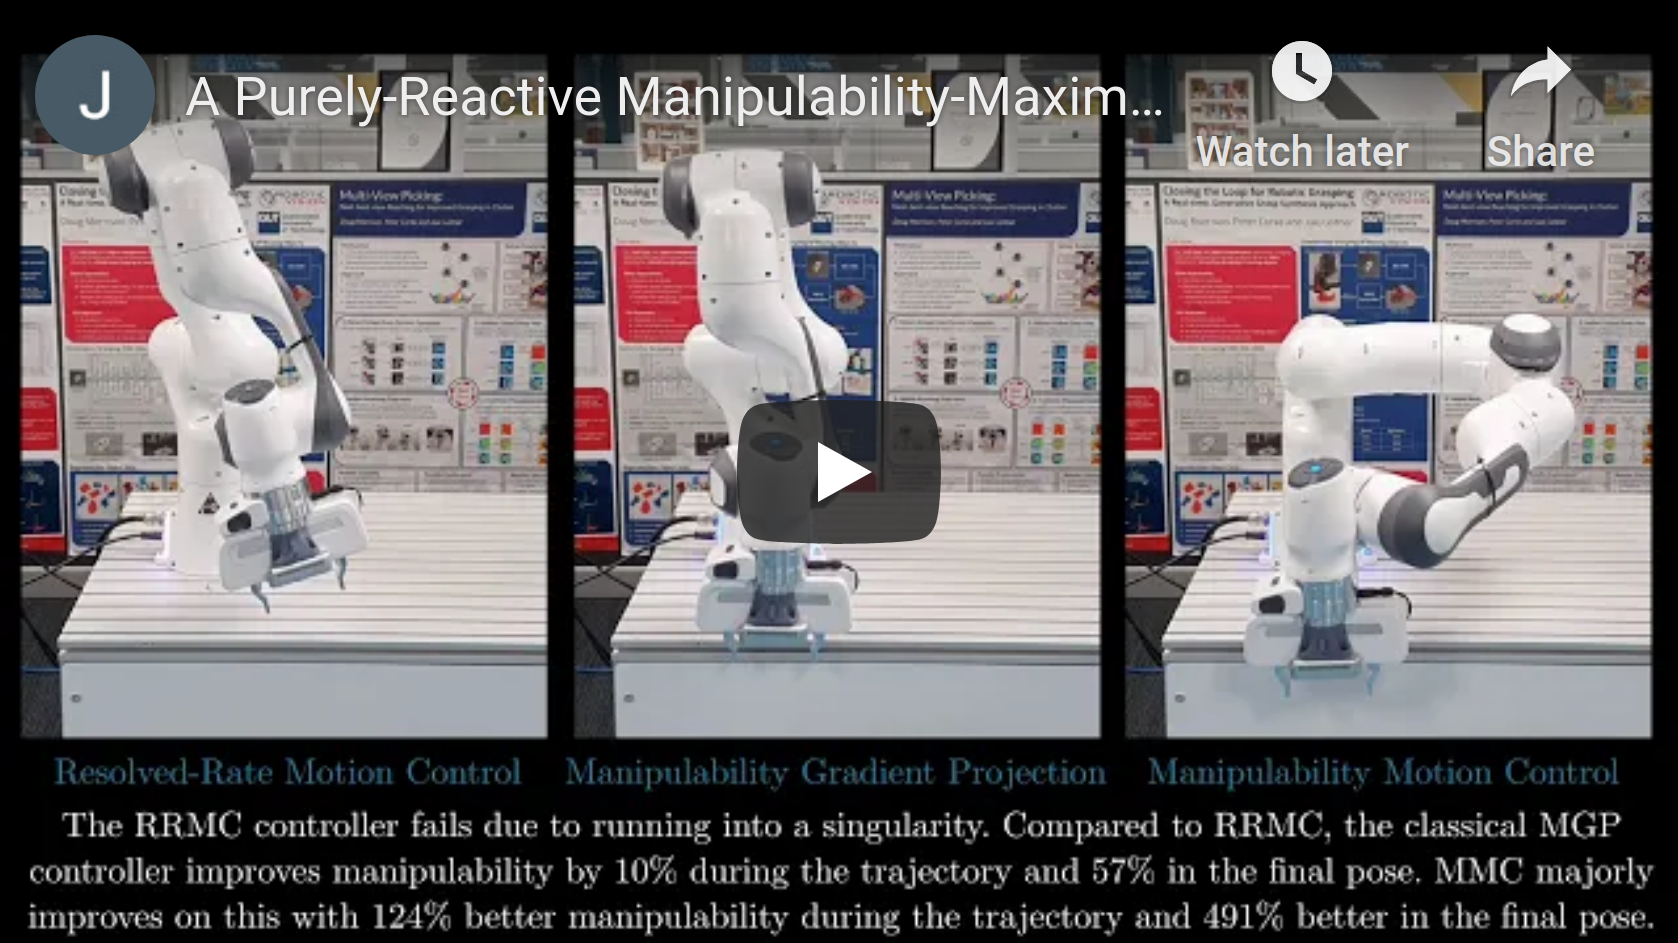
A Purely-Reactive Manipulability-Maximising Motion Controller, J. Haviland and P. Corke. In the video, the robot is controlled using the Robotics toolbox for Python.
[Paper] [Project Website] [Video] [Code Example]
2 maintainers


Metadata
2 maintainers
Release files for roboticstoolbox-python 1.4.3
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| roboticstoolbox_python-1.4.3.tar.gz | 15.5 MB | Details |
Built distributions (wheels)
Total release size: 64.4 MB
Release files / roboticstoolbox_python-1.4.3.tar.gz
| Download URL | roboticstoolbox_python-1.4.3.tar.gz |
|---|---|
| Size | 15.5 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
e8b29eee8eac006677007d8f0040af776f321e67784068e9a8314c0a748c6550
|
|
BLAKE2b-256 checksum How to use checksums |
5afa00af153158a17ee7f0d750ddf006ca474520c49a699e056c4cc521ca0075
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-py3-none-any.whl
| Download URL | roboticstoolbox_python-1.4.3-py3-none-any.whl |
|---|---|
| Size | 2.0 MB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
c70d5e0bd30589761f3e7e8c3061519f8d51f074dfccb8840dfed13fcb56514a
|
|
BLAKE2b-256 checksum How to use checksums |
114e0e19079e2b70c81fd1d2bbfacd2c358f4a8d90dc105a73b3564ed9b8fe32
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp314-cp314-win_amd64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp314-cp314-win_amd64.whl |
|---|---|
| Size | 2.5 MB |
| Tags | CPython 3.14 Windows x86-64 |
|
SHA-256 checksum How to use checksums |
a0f6eccbfaa0bd5929dbaf174d5c6898e1abc72c50845ac592b3d53bc5577515
|
|
BLAKE2b-256 checksum How to use checksums |
8a4df468beee2101b2db3f3be80f7dc9f1ec88a58857484bdea9cf9c559412db
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp314-cp314-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp314-cp314-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl |
|---|---|
| Size | 2.3 MB |
| Tags | CPython 3.14 Linux glibc 2.27+ x86-64 Linux glibc 2.28+ x86-64 |
|
SHA-256 checksum How to use checksums |
abc975e4a7fa861de6d1a641e365ca9cae2ba452514e13a346d89192e4d1bc2c
|
|
BLAKE2b-256 checksum How to use checksums |
ebf1fe6008034e56f282e656528952d86769307d52712b80ae47322d25003719
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp314-cp314-manylinux_2_26_aarch64.manylinux_2_28_aarch64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp314-cp314-manylinux_2_26_aarch64.manylinux_2_28_aarch64.whl |
|---|---|
| Size | 2.3 MB |
| Tags | CPython 3.14 Linux glibc 2.26+ ARM64 Linux glibc 2.28+ ARM64 |
|
SHA-256 checksum How to use checksums |
c2c7ba5c49beedfcb5b9bbaee46ee17d4e7ec849c1685eec07dc836cac2b2746
|
|
BLAKE2b-256 checksum How to use checksums |
5557f9e12ef160b435b94fb8f392c6a7dff69424dfb78723e5d58238981326c2
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp314-cp314-macosx_11_0_arm64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp314-cp314-macosx_11_0_arm64.whl |
|---|---|
| Size | 2.3 MB |
| Tags | CPython 3.14 macOS 11.0+ ARM64 |
|
SHA-256 checksum How to use checksums |
822353d4db0df6f7934f089e47ad43d2526bae87dd2137da2c4bf0d65bb83c5e
|
|
BLAKE2b-256 checksum How to use checksums |
8c159dd4fb293d65ad182af5ced3de3b1cb11f0b7473b82b68b01c0b5f14887a
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp313-cp313-win_amd64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp313-cp313-win_amd64.whl |
|---|---|
| Size | 2.5 MB |
| Tags | CPython 3.13 Windows x86-64 |
|
SHA-256 checksum How to use checksums |
486369c105f6425e07eacf25b202a1c22eb5068d5320f1f68a5f76788bcd5371
|
|
BLAKE2b-256 checksum How to use checksums |
e1c6c98bf64310b6e39f44dde97d0234d37201f3432a297aa88bc6eb146f53a6
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp313-cp313-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp313-cp313-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl |
|---|---|
| Size | 2.3 MB |
| Tags | CPython 3.13 Linux glibc 2.27+ x86-64 Linux glibc 2.28+ x86-64 |
|
SHA-256 checksum How to use checksums |
9825548e2689e2b5dcba8eecefc7cf8c90492facdc5b7799fe19c36ba64930aa
|
|
BLAKE2b-256 checksum How to use checksums |
6e5f381bd0020b065ec30c8cb7a6ee3b074013ba9930896e0183af657738b174
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp313-cp313-manylinux_2_26_aarch64.manylinux_2_28_aarch64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp313-cp313-manylinux_2_26_aarch64.manylinux_2_28_aarch64.whl |
|---|---|
| Size | 2.3 MB |
| Tags | CPython 3.13 Linux glibc 2.26+ ARM64 Linux glibc 2.28+ ARM64 |
|
SHA-256 checksum How to use checksums |
653e06bd11745e10e542c4d5a529150f7fe41bf6645f9a38558f5ef64b900ee3
|
|
BLAKE2b-256 checksum How to use checksums |
5c980c4dc404288e9682bdf9046c99a2266dd05dd51f2feacbe4c75aa82b88d0
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp313-cp313-macosx_11_0_arm64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp313-cp313-macosx_11_0_arm64.whl |
|---|---|
| Size | 2.3 MB |
| Tags | CPython 3.13 macOS 11.0+ ARM64 |
|
SHA-256 checksum How to use checksums |
de2af4342259a27f1bc745cad70b6121767dfcc21bbb31250ae7b6f47b79cf6f
|
|
BLAKE2b-256 checksum How to use checksums |
f05de584ad0383a2d7beb68bc2f48b90c9dcbd644685612c6dccfd14acbf3de2
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp312-cp312-win_amd64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp312-cp312-win_amd64.whl |
|---|---|
| Size | 2.5 MB |
| Tags | CPython 3.12 Windows x86-64 |
|
SHA-256 checksum How to use checksums |
6ced778dacca94ae7c7c14f043ca07945c035506b8c967bef84f19f902ef16a9
|
|
BLAKE2b-256 checksum How to use checksums |
d8a96ed2754743a6c02319d8d56e3c525e5287c1ec628b83a9387a5c8812d695
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp312-cp312-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp312-cp312-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl |
|---|---|
| Size | 2.3 MB |
| Tags | CPython 3.12 Linux glibc 2.27+ x86-64 Linux glibc 2.28+ x86-64 |
|
SHA-256 checksum How to use checksums |
e73eea520b4768fc9e378553f3763ca8aa9015554781055342d0e1573fab50d7
|
|
BLAKE2b-256 checksum How to use checksums |
24405767d964710e5af01864c6d9d6db45250811eda713b0878d9abda04191f4
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp312-cp312-manylinux_2_26_aarch64.manylinux_2_28_aarch64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp312-cp312-manylinux_2_26_aarch64.manylinux_2_28_aarch64.whl |
|---|---|
| Size | 2.3 MB |
| Tags | CPython 3.12 Linux glibc 2.26+ ARM64 Linux glibc 2.28+ ARM64 |
|
SHA-256 checksum How to use checksums |
6ec8de98bc64ce97f7cca01530a005db224cfca35be665dbbddcbdb773adbf2f
|
|
BLAKE2b-256 checksum How to use checksums |
faf527f06224a469707efb77b8db51c70f35993aa2d3788fa8ee4f917ba0fca2
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp312-cp312-macosx_11_0_arm64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp312-cp312-macosx_11_0_arm64.whl |
|---|---|
| Size | 2.3 MB |
| Tags | CPython 3.12 macOS 11.0+ ARM64 |
|
SHA-256 checksum How to use checksums |
acce956bc9d6a6ce33b533531c4f4dead88b075fba77c1a7b684828db36dc7b6
|
|
BLAKE2b-256 checksum How to use checksums |
318f0a992e840beeef7eceb45d78e930a95f596b4cbdacad1318f0c6e3729bc2
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp311-cp311-win_amd64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp311-cp311-win_amd64.whl |
|---|---|
| Size | 2.5 MB |
| Tags | CPython 3.11 Windows x86-64 |
|
SHA-256 checksum How to use checksums |
b368e78eff89beef6cd79f7601c6aab0c2b8c0c82109308acd9da5626e19d6fc
|
|
BLAKE2b-256 checksum How to use checksums |
59083c446426653585c78ecca5e2c1737521469fdcc90db32787936db38c6df5
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp311-cp311-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp311-cp311-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl |
|---|---|
| Size | 2.3 MB |
| Tags | CPython 3.11 Linux glibc 2.27+ x86-64 Linux glibc 2.28+ x86-64 |
|
SHA-256 checksum How to use checksums |
dbfb14e139c394feddef8a6d712eb2db49aba1f84d5eda0aeaac662eff9e8260
|
|
BLAKE2b-256 checksum How to use checksums |
ecfc9466bbb27118bd824ffb2e8bd1a1b85325edf29a727687700a02ec9552ae
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp311-cp311-manylinux_2_26_aarch64.manylinux_2_28_aarch64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp311-cp311-manylinux_2_26_aarch64.manylinux_2_28_aarch64.whl |
|---|---|
| Size | 2.3 MB |
| Tags | CPython 3.11 Linux glibc 2.26+ ARM64 Linux glibc 2.28+ ARM64 |
|
SHA-256 checksum How to use checksums |
b83c80bb9a25b0b3a1f2ef5c5e1c90bdc0d6875ab95beb04cb3220a38cfe605e
|
|
BLAKE2b-256 checksum How to use checksums |
434de9d709f2995a7acf35688240f03a36036b42913d0b916888c2f31de418e3
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp311-cp311-macosx_11_0_arm64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp311-cp311-macosx_11_0_arm64.whl |
|---|---|
| Size | 2.3 MB |
| Tags | CPython 3.11 macOS 11.0+ ARM64 |
|
SHA-256 checksum How to use checksums |
a1ab9a23d306afc6b79ede55c64c349837b6b73d39e96a0b26aa8dc805377609
|
|
BLAKE2b-256 checksum How to use checksums |
7fec4bc2bbc18fe984dde0e4578ccf332883538cbe67b54f6013f26f1d25d6ef
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp310-cp310-win_amd64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp310-cp310-win_amd64.whl |
|---|---|
| Size | 2.5 MB |
| Tags | CPython 3.10 Windows x86-64 |
|
SHA-256 checksum How to use checksums |
c62116b0e563d104c0ae5f974eea86eb1e10083dd54015fd10ad1fe7c5ee4f3b
|
|
BLAKE2b-256 checksum How to use checksums |
e31bb509cd958845761a69e608cc5f1c663aa1a3e5d078f5c0b5ea95895965af
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp310-cp310-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp310-cp310-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl |
|---|---|
| Size | 2.3 MB |
| Tags | CPython 3.10 Linux glibc 2.27+ x86-64 Linux glibc 2.28+ x86-64 |
|
SHA-256 checksum How to use checksums |
8413d9e7dd6f2780c977d8a58df3f396631342cbf27b8f21118f9e73e067a098
|
|
BLAKE2b-256 checksum How to use checksums |
023fbe866cf3e03529384c719bf7067588a80c83327f288fff1295663534043e
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp310-cp310-manylinux_2_26_aarch64.manylinux_2_28_aarch64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp310-cp310-manylinux_2_26_aarch64.manylinux_2_28_aarch64.whl |
|---|---|
| Size | 2.3 MB |
| Tags | CPython 3.10 Linux glibc 2.26+ ARM64 Linux glibc 2.28+ ARM64 |
|
SHA-256 checksum How to use checksums |
28808cf124b4438d754095cbbf89125a2a21871f23886008df070be2df36d63f
|
|
BLAKE2b-256 checksum How to use checksums |
ceef46f5282b474836a385793d1c5eb8feb9155d2c22ca7202760c2994c88534
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency logRelease files / roboticstoolbox_python-1.4.3-cp310-cp310-macosx_11_0_arm64.whl
| Download URL | roboticstoolbox_python-1.4.3-cp310-cp310-macosx_11_0_arm64.whl |
|---|---|
| Size | 2.3 MB |
| Tags | CPython 3.10 macOS 11.0+ ARM64 |
|
SHA-256 checksum How to use checksums |
1df14cd6fb7709ecc0979273e5f0bc7a8a9b07bdde4a1813524fc48759564dfd
|
|
BLAKE2b-256 checksum How to use checksums |
8a745721cabab56aab3443058785fe8224b96dfc089469fc50e536d5fab001a6
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Sep 12, 2026.
Transparency log













