




gsplat renders your Gaussians; splatreg registers them. Two 3DGS scans of the same scene go in, one SE(3) or Sim(3) transform comes out, and (optionally) one fused, deduped splat. Pure PyTorch, no meshing, no CUDA extension, no point-cloud detour; works with anything that speaks the standard 3DGS PLY (gsplat, Nerfstudio, INRIA, SuperSplat) or hands over tensors.
What you get that no other splat registrar ships (each claim traced in
Results and RESULTS.md):
- Provably correct SH rotation. When a recovered transform is baked in, the higher-order
spherical-harmonic bands (
f_rest) are mixed by the real-basis Wigner-D matrix, so glossy highlights turn with the splat instead of staying stuck in the old capture frame. Test-locked against an independent basis evaluator to ~2.4e-15 in float64 (tests/test_sh_rotation.py). - Align WITHOUT merging.
apply_transform()(andsplatreg align) bakes the recovered pose into the source and writes it as its own PLY: both scans stay separate files, now in one frame, ready for any viewer or editor. - Photometric refinement with per-pair exposure compensation and a coarse-to-fine render ladder, for the poses geometry cannot see (symmetry, texture-only DoF): 5°/7 mm down to 0.36°/0.5 mm on the real rasterizer.
- Pose covariance on every builtin-LM solve (
info["information"]/info["covariance"]), so the result plugs straight into a pose graph with an honest weight,Nonewhen singular, never faked. - Zero-shot and outlier-robust seeds. A pretrained BUFFER-X seed (
init="bufferx", ICCV 2025) registers across sensors and scales with no per-dataset training; a MAC maximal-clique seed (init="mac", Zhang et al. CVPR 2023) handles contaminated correspondence sets — each reported with its honest measured verdict below. - Sim(3) scale recovery, which none of the competing splat tools attempt at all.
- Ambiguity-aware fusion evidence.
cluster_hypotheses()preserves distinct pose modes, whiledecide_fusion()evaluates source→target geometry on an alternating held-out anchor set and returns an auditable fuse/no-fuse decision. It abstains when multiple pose clusters fit equally well or the held-out tail exceeds the caller's calibrated policy threshold; it never turns optimizer covariance into a false rendering guarantee.
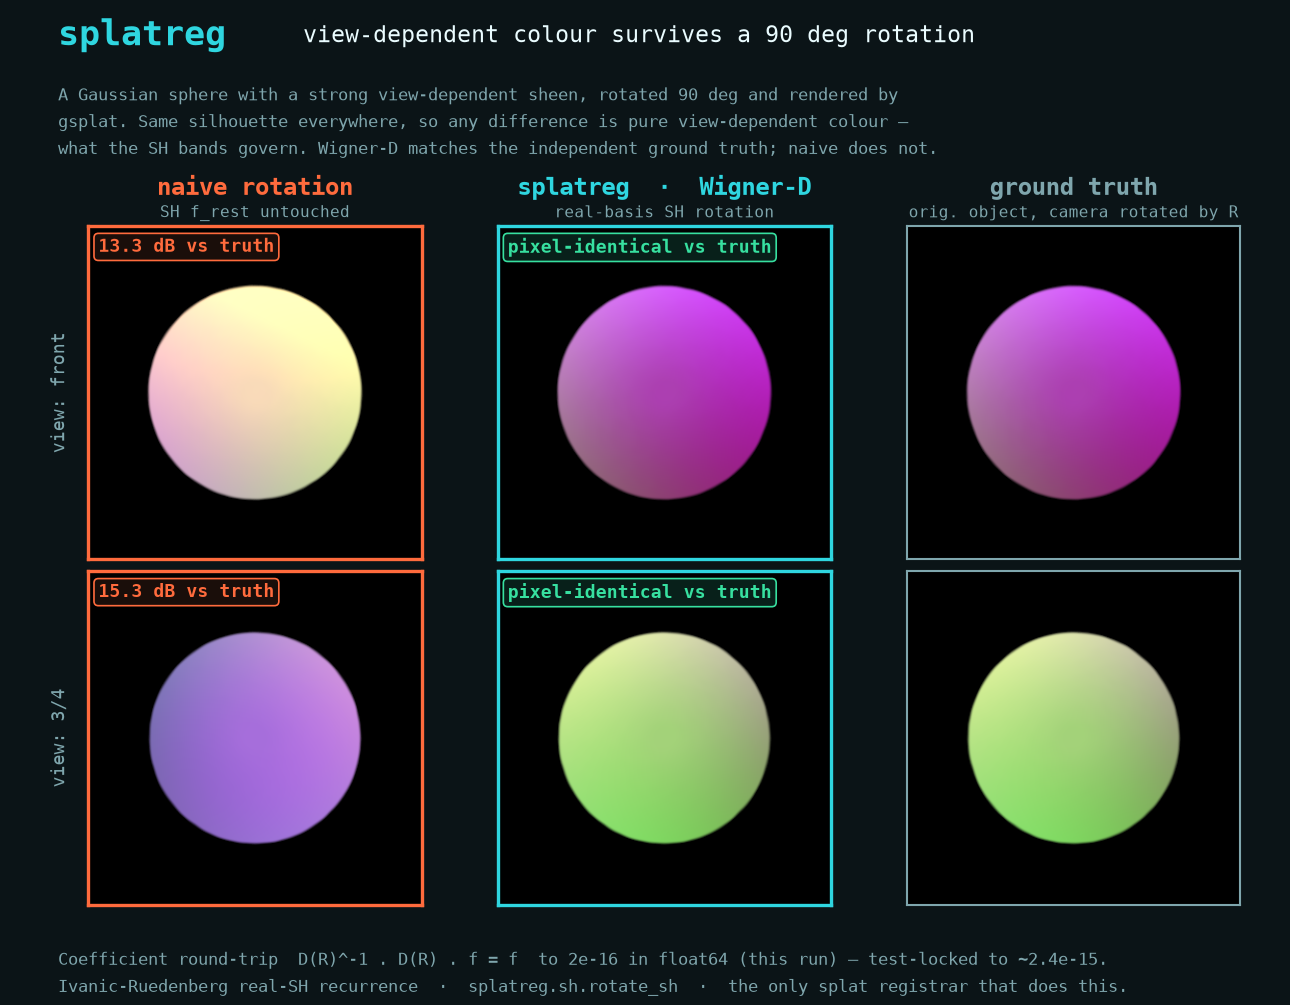
Provably correct SH rotation, rendered through gsplat. A view-dependent-coloured splat is
rotated 90°: the naive rotation (higher-order SH left in place) paints the sheen in the wrong,
world-fixed direction — 13–15 dB vs an independent ground truth — while splatreg's Wigner-D
render is pixel-identical to it. Coefficient round-trip D(R)⁻¹·D(R)·f = f to ~2e-16 in
float64. Regenerate: examples/make_sh_rotation_figure.py.
Install
pip install splatreg
# editable / dev
git clone https://github.com/Archerkattri/splatreg.git
cd splatreg
pip install -e ".[test]"
30-second quickstart
The 3-line merge (Python):
from splatreg.api import merge
from splatreg.io import load_ply, save_ply

fused = merge([load_ply("a.ply"), load_ply("b.ply")])   # register + fuse + dedupe
save_ply(fused, "fused.ply")                            # opens in SuperSplat / any viewer
load_ply() and the CLI prefer CUDA whenever it is available and fall back to CPU only
when it is not. Pass device="cpu" or --device cpu only when you intentionally want CPU.
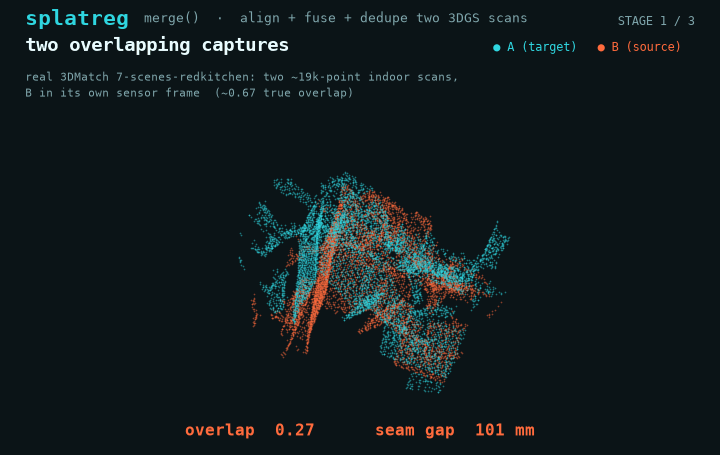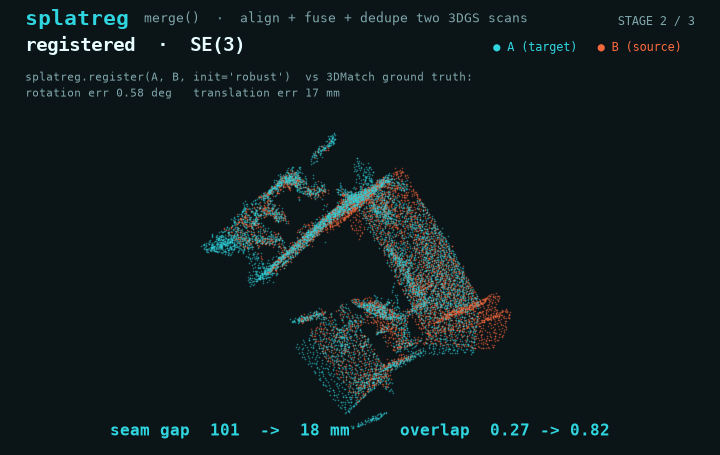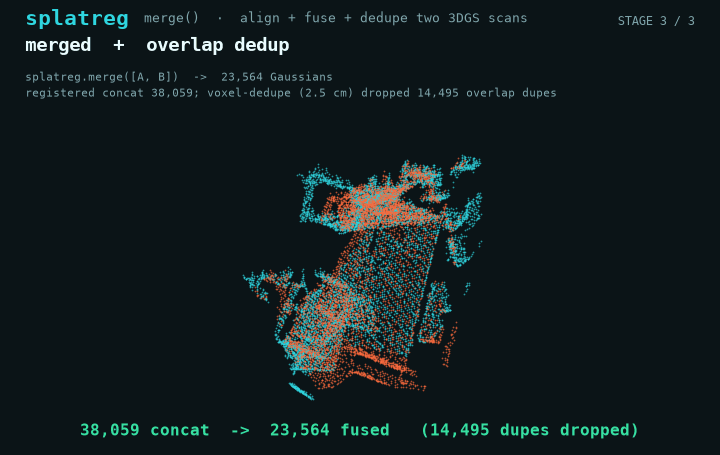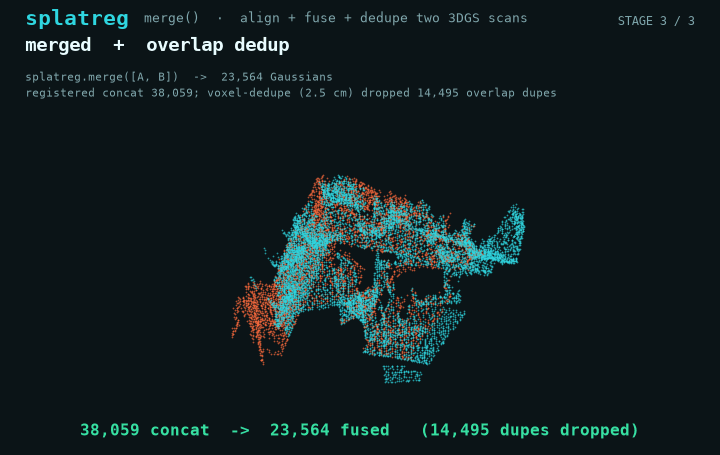
That 3-line merge on two real overlapping 3DMatch scans (7-scenes-redkitchen,
~19k points each): register (SE(3), recovered to 0.58° / 17 mm against the 3DMatch ground
truth — the seam gap closes 101 → 18 mm, overlap 0.27 → 0.82), then fuse + voxel-dedupe the
double-covered seam (38,059 → 23,564 Gaussians, 14,495 overlap duplicates dropped). Every number
is measured on this run; regenerate: examples/make_merge_fusion_gif.py.
Align without merging (both scans stay separate files, registered into one frame):
from splatreg.api import register, apply_transform
from splatreg.io import load_ply, save_ply

target, source = load_ply("a.ply"), load_ply("b.ply")
result = register(target, source, transform="sim3")     # init="fast" by default (~17 ms)
save_ply(apply_transform(source, result.T, result.scale), "b_aligned.ply")
# a.ply untouched; a.ply + b_aligned.ply now line up in any viewer.

result.T          # recovered 4x4 similarity [[s*R, t], [0, 1]], maps source -> target
result.scale      # recovered scale s (1.0 for transform="se3")
result.converged  # solver convergence flag
result.info       # diagnostics incl. pose information/covariance, ambiguity flag
Or entirely from the shell (standard 3DGS PLY in/out, composes with SuperSplat / gsplat / Nerfstudio exports; see the CLI guide):
splatreg align target.ply source.ply -o aligned.ply    # register + write the aligned source
splatreg merge a.ply b.ply -o fused.ply                # register + fuse + dedupe N splats
splatreg info x.ply                                    # count / bounds / SH degree / stats
Object pose and camera localization ride on the same core:
from splatreg import estimate_object_pose, localize_camera, coarse_localize_camera

result = estimate_object_pose(model_splat, observation_splat)    # ADD / ADD-S / AUC built in
result = localize_camera(scene_splat, frame, init_T_WC=T_init)   # needs splatreg[render]
T_coarse = coarse_localize_camera(scene_splat, frame)            # prior-free CPU seed
For an independently reconstructed pair, keep the registration alternatives instead of forcing a single covariance-shaped answer:
from splatreg import decide_fusion

decision = decide_fusion(
    source.means, target.means, candidate_transforms,
    max_heldout_p95=0.02,       # calibrated on separate scenes
)
if decision.fuse:
    chosen = candidate_transforms[decision.selected]
else:
    print("keep assets separate:", decision.reason)
The score is geometric held-out evidence, not a formal probability guarantee; calibrate the threshold by scene and keep complete scenes independent between development, calibration and test.
Capability matrix
Honest comparison against the tools people actually use for this job. The accuracy row is
measured head-to-head on a real splat with known ground truth
(RESULTS.md §5c); editor columns reflect their design (manual transforms,
not registration).
| splatreg | splatalign | GaussianSplattingRegistration | SuperSplat / SplatTransform | |
|---|---|---|---|---|
| Automatic splat-to-splat registration | yes (6 init modes) | ICP from identity | Open3D RANSAC+ICP | no (manual gizmo / user-given transform) |
| Measured rotation error, real splat + GT | 5.2° | 15.3° | 36.3° | n/a |
| Sim(3) scale recovery | yes, native | no (SE(3) only) | no (SE(3) only) | manual |
SH (f_rest) rotated with the splat |
yes, test-locked | no | no | not in any splat registrar we know of |
| Merge + overlap dedupe | yes | no | no dedupe | concat only |
| Photometric refine (exposure comp + ladder) | yes | no | no | no |
| Zero-shot learned seed (BUFFER-X) | yes | no | no | no |
| Pose covariance for pose graphs | yes | no | no | n/a |
| Honest ambiguity flag (never silent-wrong) | yes | no | no | n/a |
| Pure PyTorch library + CLI | yes | script | GUI | editor / CLI |
How it works
splatreg takes two splats and finds the rigid (SE(3)) or similarity (Sim(3), +scale) transform that aligns them, then optionally merges and dedupes them into one. It is the missing registration half of the Gaussian-splatting toolchain (the splat-to-splat alignment SuperSplat / INRIA / geospatial users keep asking for, where today's tooling punts to a manual gizmo).
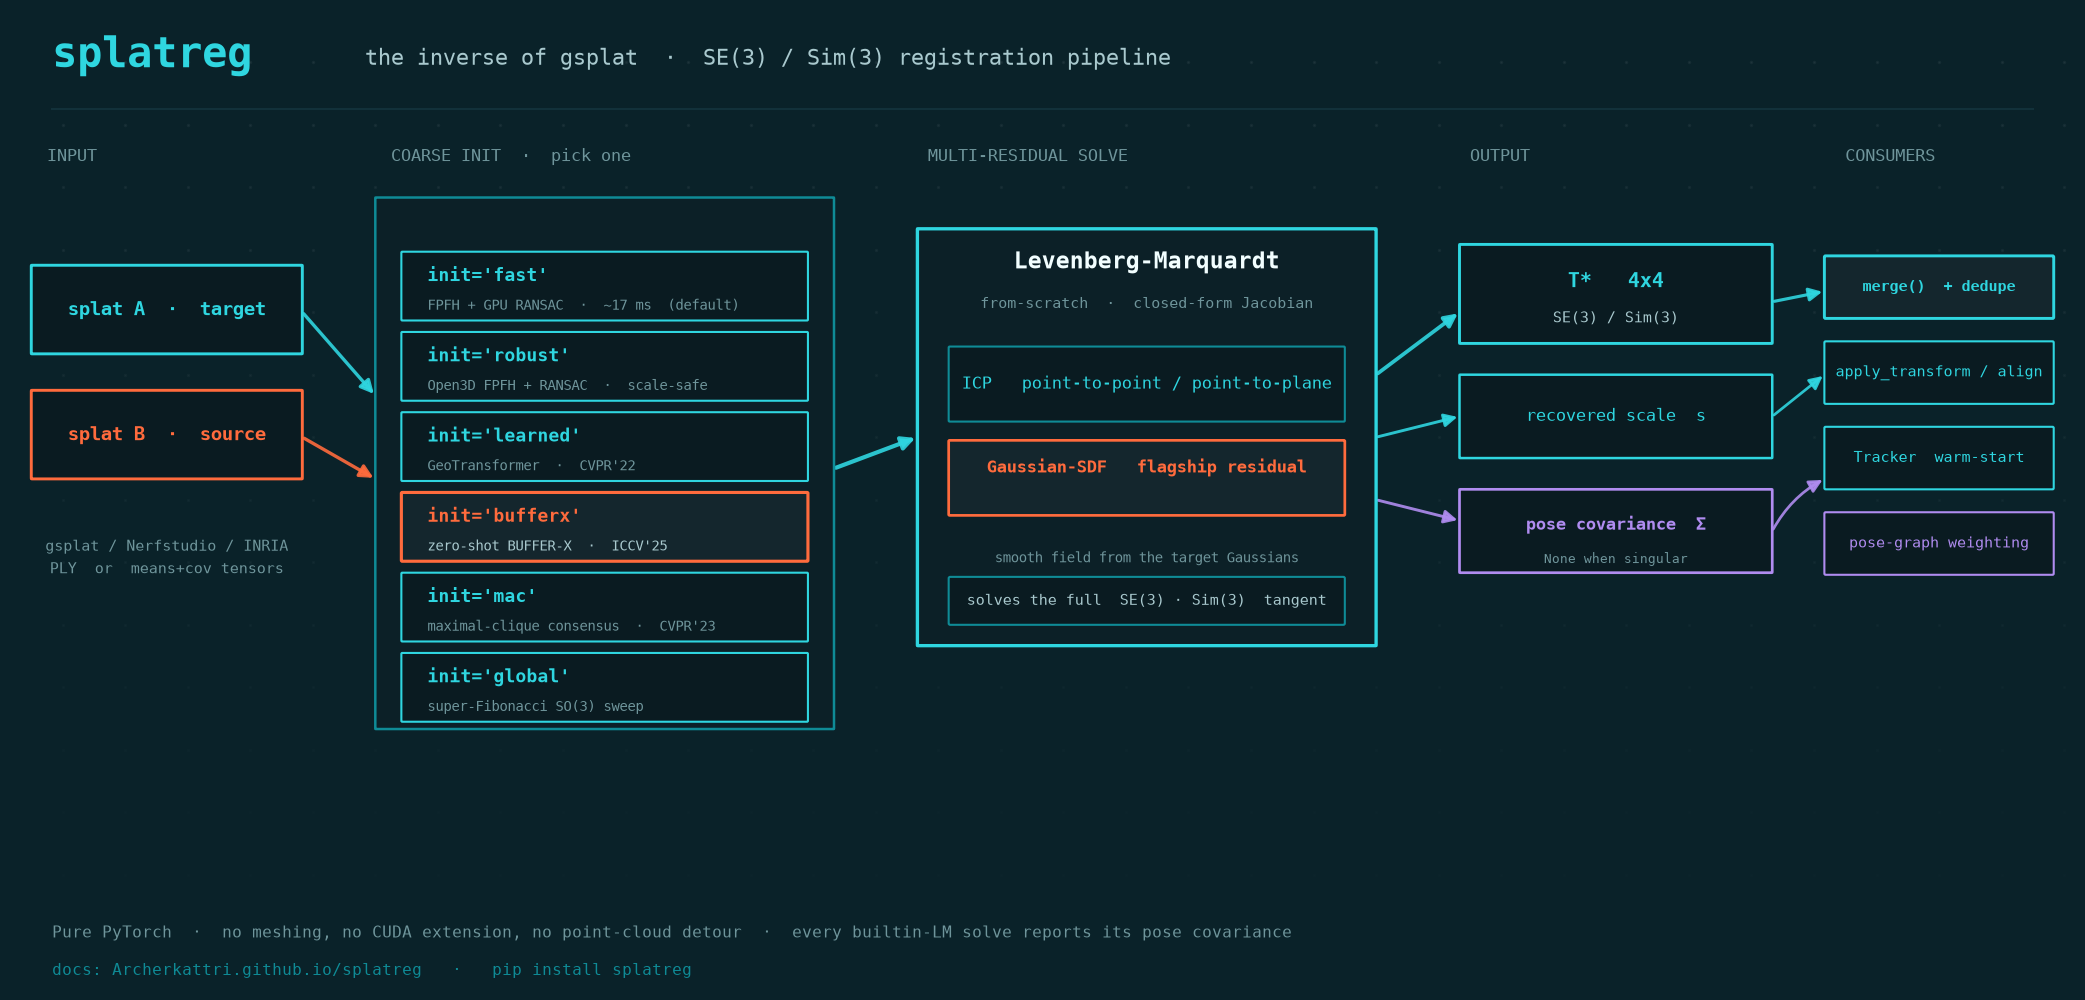
- Global init: a coarse pose from a dense super-Fibonacci rotation sweep + batched trimmed ICP (no local-minimum trap), with FPFH+RANSAC, learned (GeoTransformer), zero-shot BUFFER-X, and MAC maximal-clique seeds for harder real scans.
- Refinement: a from-scratch Levenberg-Marquardt core over ICP (point-to-point / point-to-plane) and splatreg's flagship Gaussian-SDF residual, solving the full SE(3) or Sim(3) tangent, with the pose information/covariance exposed at the optimum.
The Gaussian-SDF residual
No competitor packages this. splatreg derives a smooth signed-distance field directly from the target Gaussians (no mesh, no marching cubes) and drives registration by it:
w_i(p) = exp(−‖p − q_i‖² / 2σ²)              # Gaussian kernel weight per anchor
q̃(p)   = Σ w_i q_i / Σ w_i                    # kernel-weighted centroid
ñ(p)   = Σ w_i n_i / ‖Σ w_i n_i‖              # kernel-weighted surface normal
d(p)   = (p − q̃(p)) · ñ(p)                    # signed distance, the residual
d(p) vanishes exactly when source points land on the target surface. It has a
closed-form, audited Jacobian and is a reusable primitive:
from splatreg.geometry.gaussian_sdf import gaussian_sdf, gaussian_sdf_grad
sdf, normal = gaussian_sdf(target, query_points, sigma=0.02)       # signed distance + normal
sdf, grad   = gaussian_sdf_grad(target, query_points, sigma=0.02)  # + exact ∇_p d
Init modes: trade speed for robustness
Every mode is a different way to seed the same LM core, so you pick one per capture and the refine, scale recovery, SH rotation, and covariance are identical downstream.
init= |
what | when |
|---|---|---|
"fast" (default) |
FPFH + GPU-batched RANSAC seed → closed-form LM | objects / full-overlap, ~17 ms |
"robust" |
Open3D FPFH+RANSAC seed → splatreg refine + scale | real metre-scale scans |
"learned" |
pretrained GeoTransformer seed → splatreg refine + scale | best accuracy on real scans |
"bufferx" |
pretrained BUFFER-X zero-shot seed (ICCV 2025) → splatreg refine + scale | cross-sensor / cross-scale scans with no per-dataset training |
"mac" |
MAC maximal-clique consensus (Zhang et al. CVPR 2023) → weighted SVD → refine | outlier-heavy / multi-consensus correspondence sets |
"global" |
blind super-Fibonacci SO(3) sweep | robust fallback, any rotation |
Two options refine the seed rather than the pose. init="learned" accepts seed_gate=True
(off by default), a Decision-PCR-style confidence check (arXiv 2507.14965) that scores the learned
seed (mutual-NN inlier ratio + SC² spatial consistency) and reseeds a low-confidence hypothesis from
the classical "robust" path before LM refinement, instead of blindly refining a bad seed. And
init="bufferx" swaps GeoTransformer for BUFFER-X ("Towards Zero-Shot Point Cloud Registration
in Diverse Scenes", ICCV 2025) — a single generalist model that registers across sensors and scales
with no per-dataset training. Both learned backends are optional and lazily loaded; when their
weights / CUDA extensions are absent they fall back to "robust" with a logged note. BUFFER-X
weights come from Hugging Face Hyungtae-Lim/BUFFER-X; a native build on a modern stack
(CUDA 12.8 / sm_120 / torch 2.11 / numpy 2.x) is nontrivial; the full sudo-free recipe
(clone location, weights, and build) is in
docs/BUFFERX_BUILD_MODERN_CUDA.md.
Per-dataset-trained backbones like PSReg and DiffusionPCR now top the 3DMatch leaderboard (95%+ registration recall), above the ~91.5% GeoTransformer seed splatreg wraps. splatreg deliberately keeps a zero-shot learned option (BUFFER-X) rather than chasing that number: a splat registrar should not require training a per-scene/per-sensor model to align two captures, so the value is a generalist seed plus splatreg's provable SH rotation, honest pose covariance, Sim(3) scale, and overlap-aware refine on top — not the last recall point on one benchmark. Drop in a higher-recall correspondence model as the seed the day it ships a permissive, zero-shot checkpoint.
Results
Every number is measured and reproducible; the provenance column points at the full record.
| Benchmark | splatreg | reference | provenance |
|---|---|---|---|
| Real-splat merge (103k Gaussians) | Chamfer 10.3 → 2.0 mm (5.1×), overlap 0.03 → 0.67 (22×) | naive concat | RESULTS.md §5d, examples/merge_demo.py |
| Photometric refine (real rasterizer) | 5°/7 mm → 0.36°/0.5 mm (~1.1 s) | geometric stage alone worsens the symmetric case 6.0°→11.2° | benchmarks/photometric_refine_results.md |
| Official 3DMatch recall (1279 pairs, Choi/Zeng protocol) | 91.5% mean, 93.5% pooled | GeoTransformer ~92%, Open3D ~77% | RESULTS.md §5b |
| Official 3DLoMatch (hard, 10-30% overlap) | 72.5% mean, 74.4% pooled | GeoTransformer ~74%, Open3D ~20% | RESULTS.md §5b |
| vs splat competitors (real splat, known GT Sim3) | 5.2° (SE3), recovers scale (Sim3) | splatalign 15.3°, GS-Registration 36.3° | RESULTS.md §5c |
| Object pose (canonical YCB CAD, 14 models × 4 poses) | ADD-S AUC 0.995, 100% < 2 cm | n/a | RESULTS.md §5f-ycb |
| Camera localization (real splat, known perturbation) | median 5°/10 mm → 0.11°/1.35 mm | n/a | RESULTS.md §5g |
| Known-transform recovery | 36/36 = 100% (GPU full grid); 6/6 CPU smoke in 41 s | n/a | RESULTS.md §1, §5j |
| Registration speed | ~17 ms (fast init), 104 ms (learned) | GeoTransformer ~50 ms, Open3D 142 ms | RESULTS.md §5e |
| SH rotation correctness | rotated-coeff evaluation error ~2.4e-15 (float64) | n/a | tests/test_sh_rotation.py, RESULTS.md §5j |
| Exposure compensation | tinted-pair scale error 3.99% → 0.47% (clean: 0.01%, harmless) | no-compensation baseline | RESULTS.md §5j |
| Pose covariance | SPD when well-constrained, scales with noise, None when singular |
n/a | tests/test_pose_covariance.py |
Zero-shot registration on real 3DMatch
The init="bufferx" seed is run on real 3DMatch, with both seeds pushed through the
identical splatreg refine so the comparison isolates the seed rather than the pipeline. On
the complete official gt.log pair sets (a pair counts as recalled at RRE < 15° and
RTE < 0.3 m): on 3DMatch (8/8 scenes, n=1619) the BUFFER-X seed reaches 0.962 recall
(median RRE 1.46°) against 0.630 (2.12°) for the classical robust FPFH seed; on
official 3DLoMatch (n=1781) it holds 0.777 (2.77°) against 0.122 (103.4°) —
6.4× the recall where the classical seed's median error is effectively random. BUFFER-X
wins every scene on both splits.
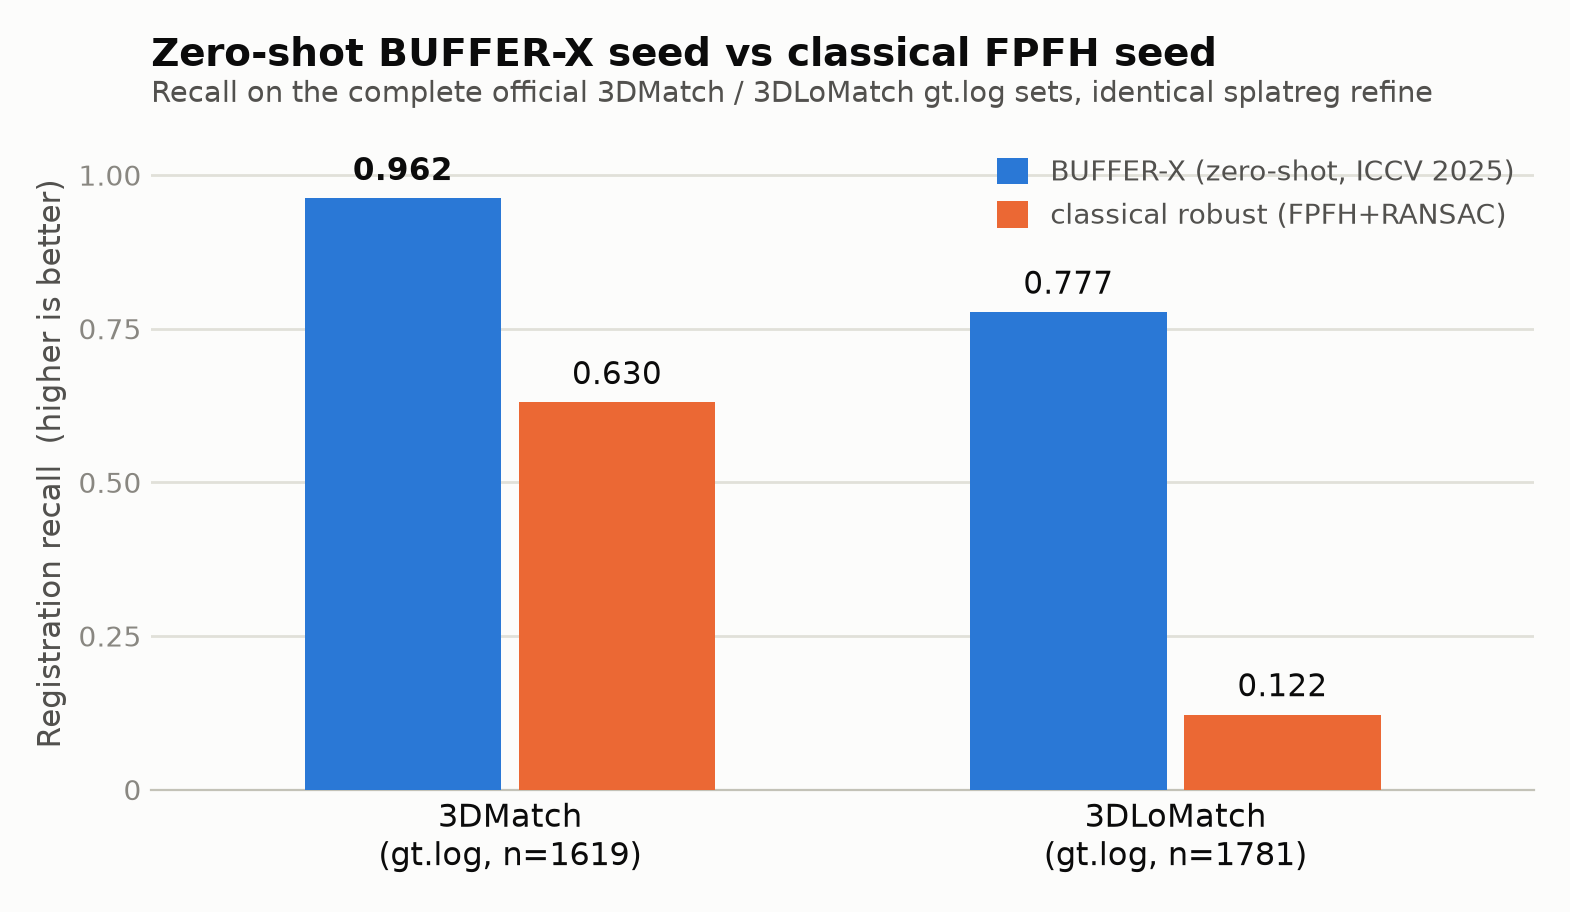
Registration recall on the complete official gt.log pair sets — 3DMatch 8/8 scenes (n=1619):
0.962 vs 0.630; official 3DLoMatch (n=1781): 0.777 vs 0.122. Both seeds share the identical lighter
feature_align refine, so these bars isolate the seed rather than report full-pipeline absolute
numbers. Regenerate: examples/make_bufferx_figure.py.
One real low-overlap pair, watched end to end: the source fragment starts unaligned, the classical FPFH+RANSAC seed slews it into the wrong basin (151.5° off), then the BUFFER-X seed + splatreg refine rotates it onto the target and locks on at 2.0°.
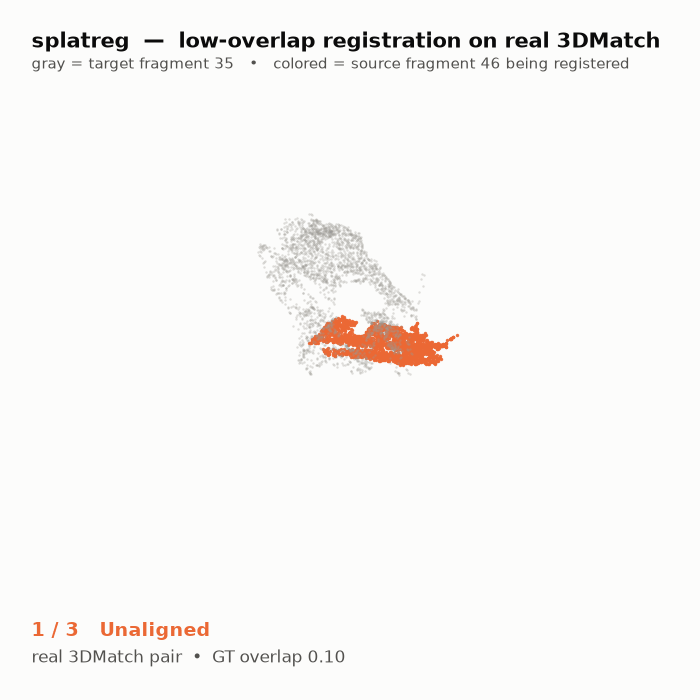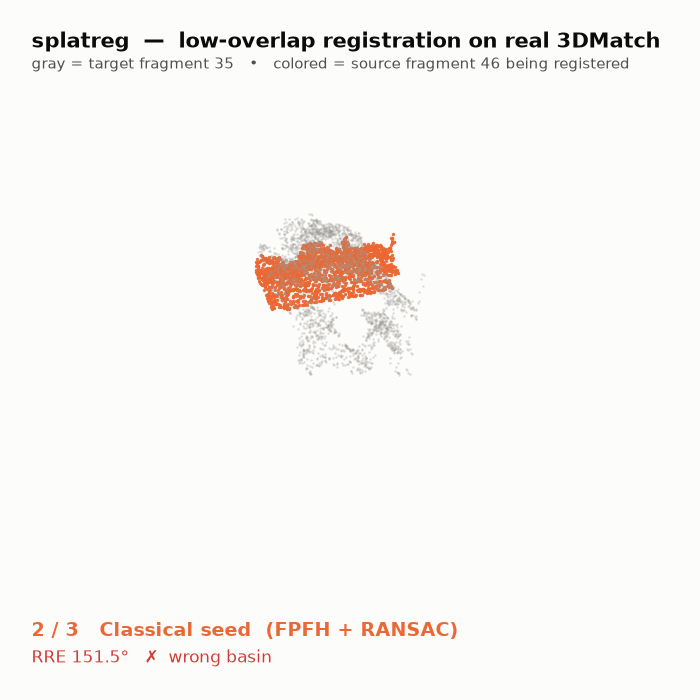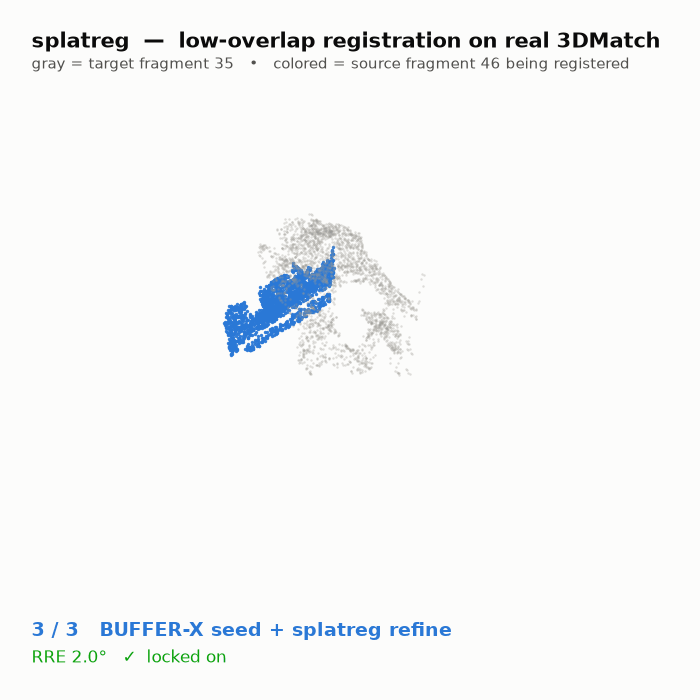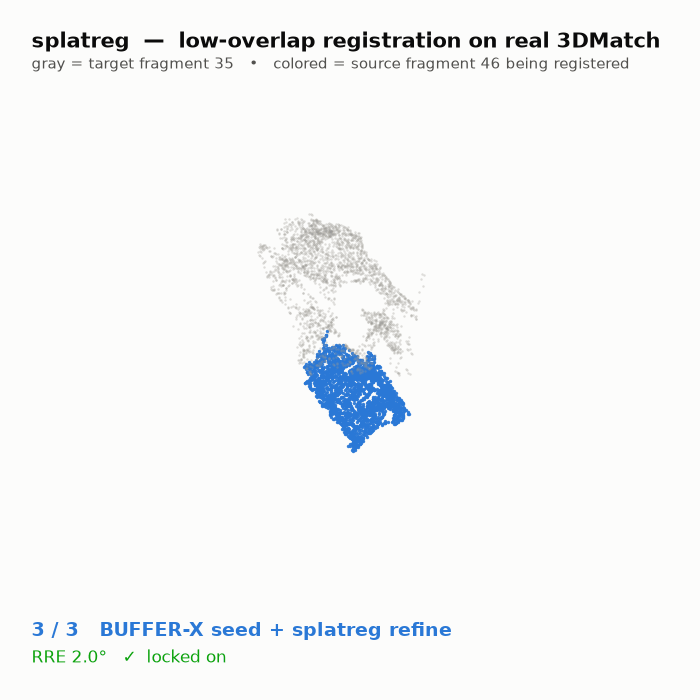
Real 3DMatch pair 7-scenes-redkitchen 35→46, GT overlap 0.10. Both transforms are the
actual robust_feature_align (classical, RRE 151.5° ✗) and bufferx_feature_align (BUFFER-X,
RRE 2.0° ✓) library outputs — the animation interpolates between the real estimates, nothing is
hand-posed. At 10 % overlap the source only shares a corner with the target, so a correct lock
overlaps just that corner. Regenerate: examples/make_lowoverlap_gif.py.
Photometric refinement, for the pose geometry can't see
When geometry alone is ambiguous — a rotation-symmetric object, a texture-only degree of freedom —
the opt-in photometric stage (refine="photometric") renders source vs target through gsplat
and closes the pose the geometric solve cannot, with per-pair exposure compensation and a
coarse-to-fine render ladder. No real images needed.
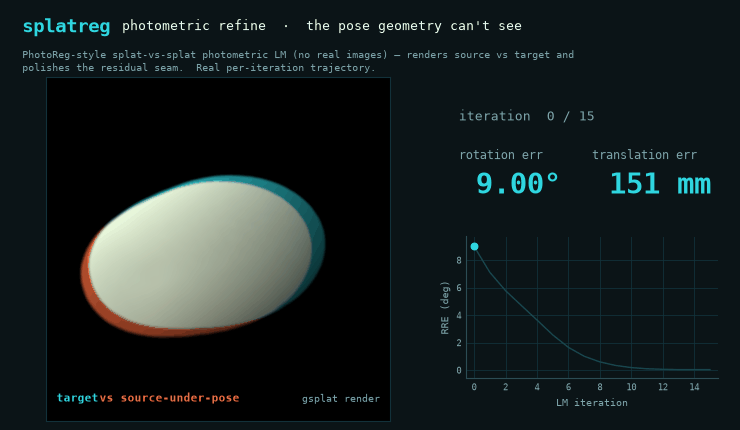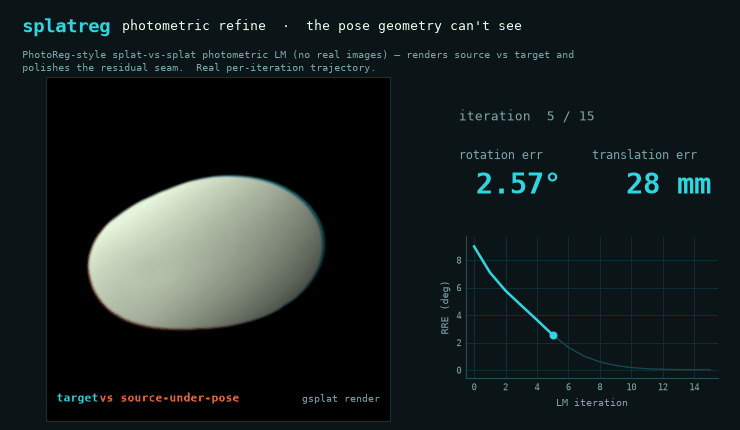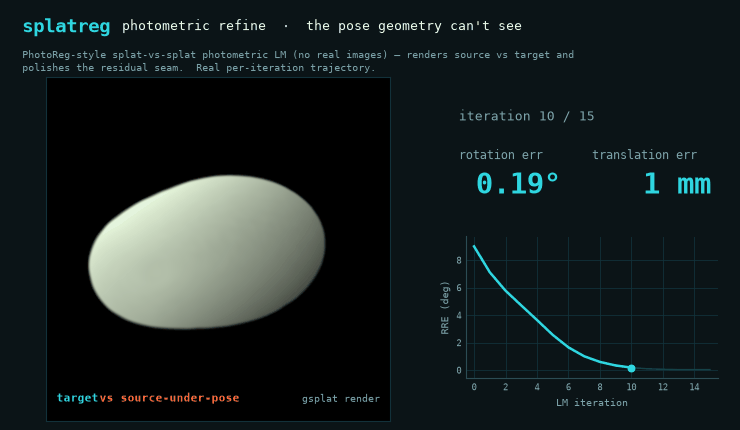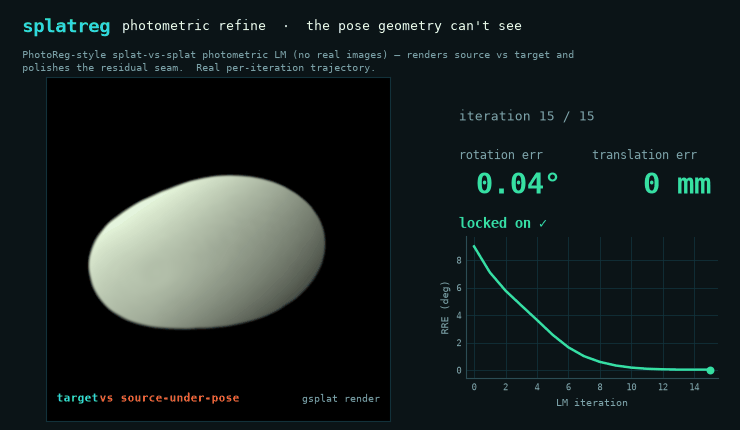
A colour splat knocked 9° / 151 mm out of alignment, polished by the PhotoReg-style
splat-vs-splat photometric LM (renders through gsplat, no real images) down to
0.04° / 0.04 mm — a real per-iteration trajectory. On the benchmark rasterizer the stage takes
5°/7 mm → 0.36°/0.5 mm in ~1.1 s and is neutral on dense-overlap pairs, hence opt-in. Regenerate:
examples/make_photometric_refine_gif.py.
The MAC verdict, stated honestly
init="mac" reimplements the MAC hypothesis generator (SC²-weighted rigidity graph → maximal
cliques → weighted SVD per clique, with explicit caps) in pure torch + networkx
(pip install "splatreg[mac]"). On synthetic contaminated sets
(tests/test_mac.py) it matches the RANSAC engine at 30/60/90% random
outliers and decisively wins the structured-decoy regime (RANSAC fails at ~78°, MAC stays <0.2°).
Measured on the full official splits (same forward/voxel/refine, only the hypothesis stage
differs) it is a wash, not a lift: 3DLoMatch 72.1/74.6 vs LGR's 72.5/74.4, 3DMatch 91.7/93.8
vs 91.5/93.5, every delta within ±4 pairs, at ~+50% runtime. GeoTransformer's native-voxel
correspondences are already consensus-dominated, so the default stays seed_selector="lgr";
"mac" is the tool for genuinely contaminated correspondence sets
(RESULTS.md §5k).
Validation
Every number is reproducible; full record in RESULTS.md.
python -m pytest tests/ -q                        # 166 passing, 8 skipped
python tests/test_jacobians.py                    # analytic vs numerical Jacobian audit
python examples/validate_recovery.py --fast       # CUDA-first smoke; CPU fallback
python examples/validate_recovery.py              # CUDA-first 36/36 recovery
SPLATREG_DEVICE=cuda python benchmarks/robustness_bench.py --device cuda
python examples/merge_demo.py                     # real-splat merge demo
Limitations
splatreg is honest about its edges (full detail in RESULTS.md):
- Heavy overlap loss (keep ≤ 40%) is genuinely ambiguous. The rotation-disambiguating
geometry is physically absent; even the true pose does not seat cleanly. The aligner flags
these honestly (
result.info['ambiguous']/['confidence']) and never silently wrong-poses.mergeandtrackare designed for high-overlap captures. - Scale is unobservable under thin overlap. Under ~20% shared geometry the Sim(3) scale residual valley is flat; the line-search tightens scale on its own objective but cannot recover what the geometry does not carry.
- Cost on rigid SE(3). Plain ICP reaches the same SE(3) success and is far faster; the
SDF residual buys scale + implicit-field robustness at a real compute cost. Use
track()(~17 ms/frame) for the warm-start real-time path.
Documentation
Full docs at https://archerkattri.github.io/splatreg/: quickstart, CLI guide, init modes (incl. the MAC verdict), photometric refinement (when and why, with the measured three-case table), PLY interop (splatfacto/INRIA/SuperSplat round-trip + the SH-under-rotation detail), benchmarks, and the API reference. Or run the Colab quickstart (CPU-only, no assets needed).
Citation
If splatreg is useful in your research, please cite it (see CITATION.cff;
GitHub's "Cite this repository" button gives BibTeX/APA). The DOI is the Zenodo concept DOI
and always resolves to the latest archived release:
@software{attri_splatreg,
  author  = {Attri, Krishi},
  title   = {splatreg: composable SE(3)/Sim(3) registration for 3D Gaussian Splatting},
  url     = {https://github.com/Archerkattri/splatreg},
  doi     = {10.5281/zenodo.20618389},
  version = {1.4.0},
  year    = {2026}
}
Paper (preprint). engrXiv, doi:10.31224/7313:
@article{attri2026splatreg,
  author  = {Attri, Krishi},
  title   = {Registering Gaussian Splats Without the Point-Cloud Detour: Accuracy,
             Representation Semantics, and a Negative Result on Hypothesis-Stage Transfer},
  journal = {engrXiv},
  doi     = {10.31224/7313},
  year    = {2026}
}
License & layout
BSD 3-Clause: permissive, composes with the gsplat / Theseus / GTSAM ecosystem.
splatreg/ is the library (api, align, align_features, mac, sh, bundle,
spatial_index, core/lie, geometry/gaussian_sdf, residuals/, solvers/lm, cli),
plus tests/, benchmarks/, examples/, docs_site/. Full validation record:
RESULTS.md.
Current release status
The current checkout includes ambiguity-aware hypothesis fusion, held-out
evidence scoring and the official flat-archive 3DMatch benchmark path. The full
suite passes 166 tests with 8 skips. A corrected one-scene CPU recovery audit
freezes the robust configuration on three development pairs, then obtains 5/7
held-out recall (71.4%, 95% Wilson 35.9–91.8%) for both splatreg and the matched
Open3D control; splatreg reduces median pose error at a small latency cost. This
bounded audit is not a new full-leaderboard or learned-SOTA result; see
benchmarks/3dmatch_redkitchen_cpu_2026-09-15.md.
1 maintainer

Metadata
1 maintainer
Release files for splatreg 1.5.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| splatreg-1.5.0.tar.gz | 246.3 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| splatreg-1.5.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 446.1 kB
Release files / splatreg-1.5.0.tar.gz
| Download URL | splatreg-1.5.0.tar.gz |
|---|---|
| Size | 246.3 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
371c0464c753e8b615c77f672859c8062fd68cc7eac2b5a6a0b70f5bf7a7ced7
|
|
BLAKE2b-256 checksum How to use checksums |
7f1e0a54f3d7a2ab41cece3d69a2b0e20d2c1d8e25dd03a3a9b0d3b4cb83bece
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.12.3
|
Release files / splatreg-1.5.0-py3-none-any.whl
| Download URL | splatreg-1.5.0-py3-none-any.whl |
|---|---|
| Size | 199.8 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
eed7d401b6373a8f1d15cce7e31a5a2cf0bafb29a6b79d9ba53496b41eecfe04
|
|
BLAKE2b-256 checksum How to use checksums |
dcd55378b5eb06e5cb9ca33c0eced5732e84773d2605c8aa71e199f22426727d
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.12.3
|














