
sscbirrt



A motion planner over sets of configurations that also times its paths for execution. One call plans a path and, given the joints' velocity and acceleration limits, returns a timed trajectory along it, ready for a robot to follow.
- Planning. A planning problem names a start set, a goal set, a set the
whole path must stay inside, and a validity predicate. A solution is a path
that begins in the start set, ends in the goal set, and stays inside the
path set with every configuration valid. A set is anything that answers
contains(q). The algorithm is CBiRRT (Berenson et al., 2009), a bidirectional RRT that grows trees from many roots and projects onto constraints. Task Space Regions are one representation of a set; the planner does not depend on it, and sets you define yourself take the same roles. - Trajectory smoothing. The path's corners become motion: the trajectory carries velocity through them and cuts them short, under the limits. Every cut is checked against the same problem, so the trajectory keeps the path's guarantees: collision-free, inside the path set, at the planner's resolution. On the pick and transport demos the median trajectory takes about 60% of the time of stopping at every corner (Timed trajectories).
 | 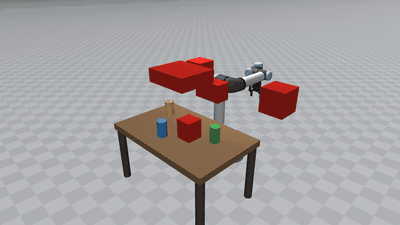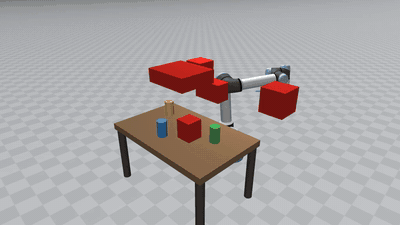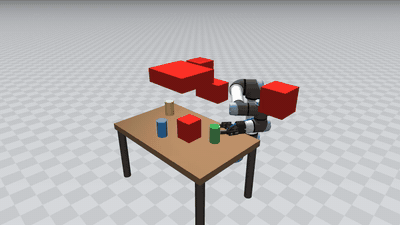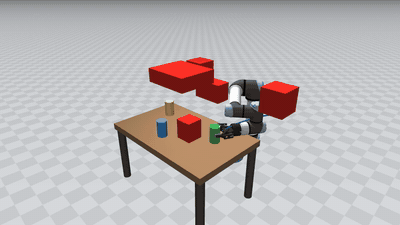 | 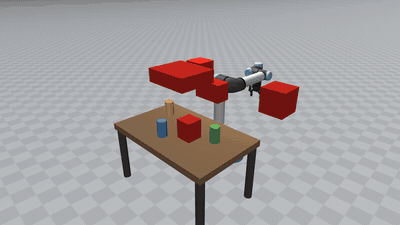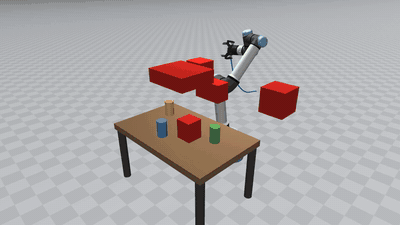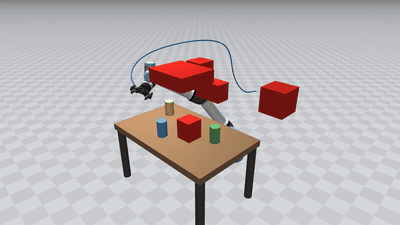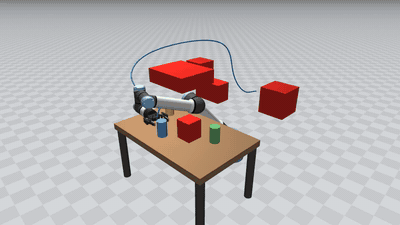 |
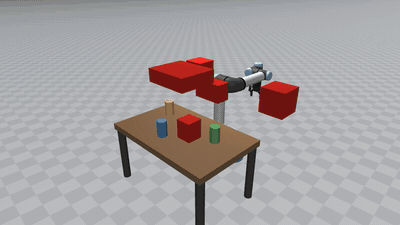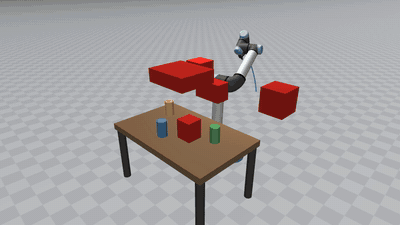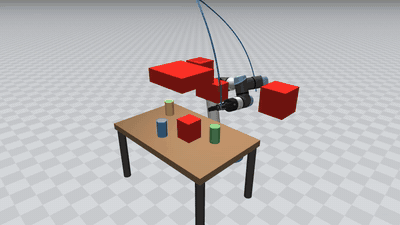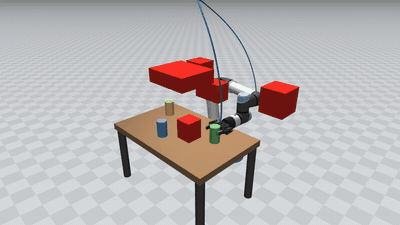
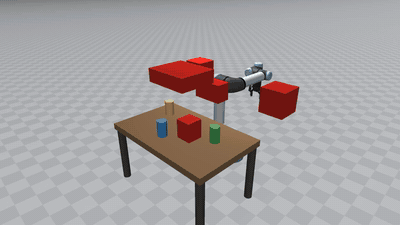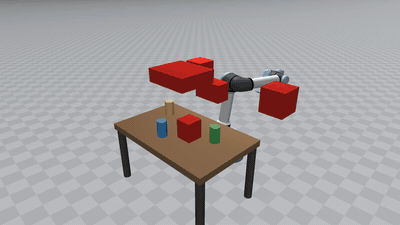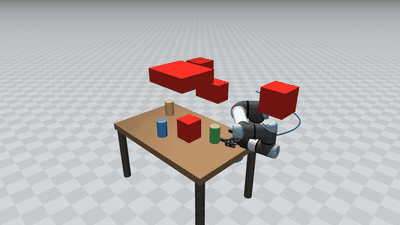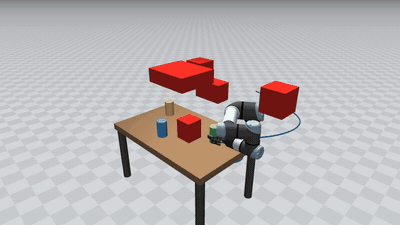
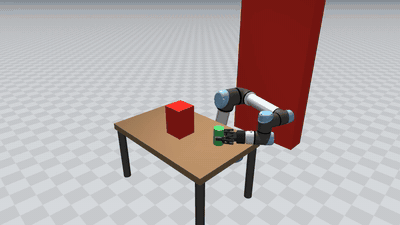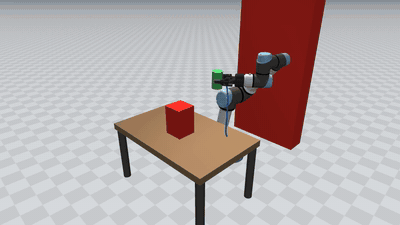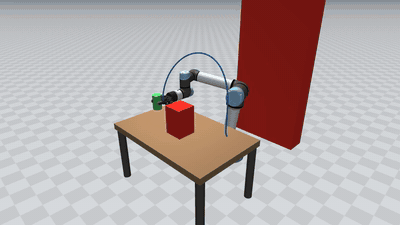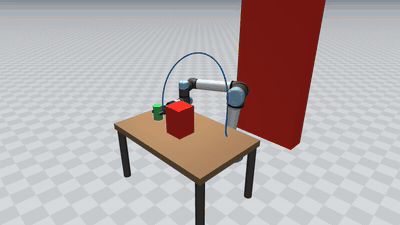
| yellow can, a wide arc | green can, straight in | blue can, over the boxes |
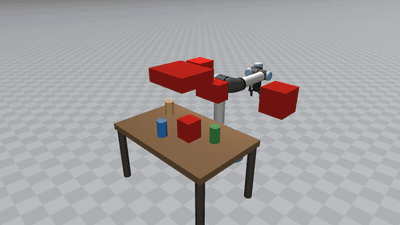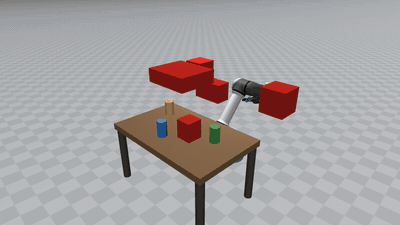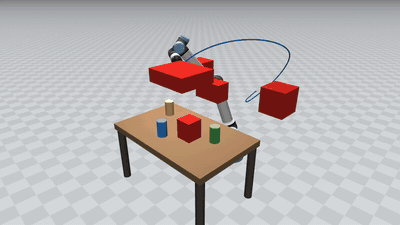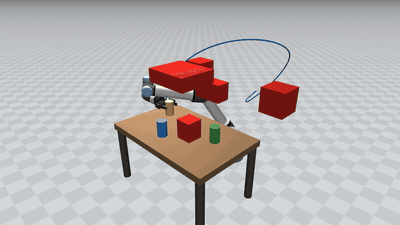 |  |  |
| yellow can, from the far side | green can, from above | green can, elbow down |
Six runs of one call, plan(model, data, arm, goal=grasps), where grasps is
every side grasp of every can: 18 regions. Each run lets the planner choose a
different can, grasp, and route around the red boxes. Over 100 seeds every
run succeeds, with a median of 0.05 s including root collection
(tools/planning_benchmark.py). Every video plays in real time: the arm
follows the planned path's timed trajectory
at 1.57 rad/s and 4 rad/s². sscbirrt-demo pick --seed N renders a run.
 | 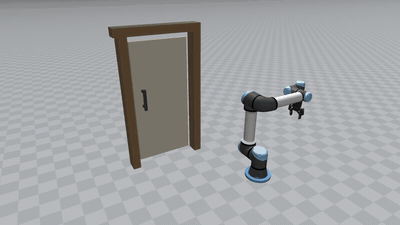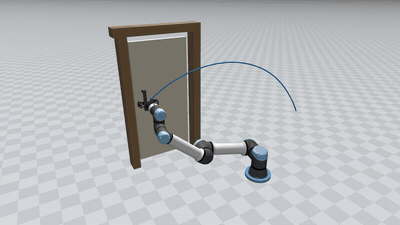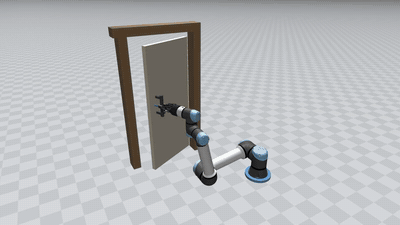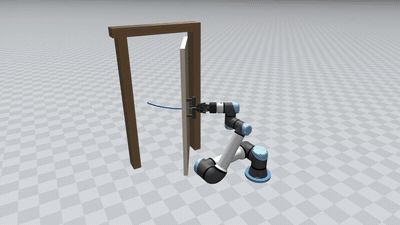 |
| carrying a can upright: a path constraint | opening a door: a TSR chain |
A path constraint holds at every point of the path: the can is lifted over
the box and set down without tipping. The door's constraint is a TSR chain,
the hinge and then the grasp on the handle, so the gripper follows the
handle's arc as the door swings open. sscbirrt-demo transport door
renders both.
Install
pip install sscbirrt                                  # the planner and trajectory smoother, their C++ core, and TSRs
pip install "sscbirrt[mujoco,ssik]" sscbirrt-assets   # plus MuJoCo, analytical IK, and the UR5e model below
pip install "sscbirrt[demo]" && sscbirrt-demo         # everything above, and the rendered demos (MP4s in ./sscbirrt-demo)
Wheels for Linux x86_64 and macOS arm64, Python 3.10 through 3.14, include the
native core with the SSIK and MuJoCo adapters. numpy and sstsr (Task Space
Regions, imported as tsr) are installed as dependencies; the mujoco extra
pins the exact MuJoCo the extension is built against. sscbirrt-assets packages
the MuJoCo Menagerie UR5e and Robotiq 2F-85 so the demos need no clone.
From a checkout or the sdist, the extension compiles on install and needs CMake 3.16+ and a C++20 compiler; the build fetches scikit-build-core, pybind11, ninja, ssik, sstsr, and mujoco itself, and Eigen if none is installed:
uv pip install -e ".[all]" # every extra, the example dependencies, and the dev tools
Plan in MuJoCo
Describe the arm once, then plan from where it is to a region:
import mujoco
import numpy as np
import sscbirrt_assets
from tsr import TSR

from sscbirrt import TrajectoryOptions
from sscbirrt.mujoco import Arm, plan

xml = sscbirrt_assets.ur5e_xml()                       # the Menagerie UR5e, packaged
model = mujoco.MjModel.from_xml_path(str(xml))
data = mujoco.MjData(model)
data.qpos[:] = [0, -1.57, 1.57, -1.57, -1.57, 0]       # where the arm is now

joints = ["shoulder_pan_joint", "shoulder_lift_joint", "elbow_joint",
          "wrist_1_joint", "wrist_2_joint", "wrist_3_joint"]
arm = Arm(model, joints, ee_site="attachment_site", mjcf=xml)   # SSIK built from the same MJCF

# Goal: the flange pointing down, within 2 cm of (0.5, 0.2, 0.3) and up to 5 cm above it, any yaw
T = np.eye(4)
T[:3, :3] = np.diag([1.0, -1.0, -1.0])
T[:3, 3] = [0.5, 0.2, 0.3]
goal = TSR(T0_w=T, Bw=[[-0.02, 0.02], [-0.02, 0.02], [0, 0.05], [0, 0], [0, 0], [-np.pi, np.pi]])

limits = TrajectoryOptions(velocity_limits=1.57, acceleration_limits=4.0)   # rad/s and rad/s^2, every joint
result = plan(model, data, arm, goal=goal, seed=0, trajectory=limits)
print(result.success, result.backend, len(result.path), f"{result.planning_time:.3f} s")
print(f"{result.trajectory.duration:.2f} s to execute")   # result.trajectory.sample(2_000_000): a 2 ms command
plan(model, data, arm, goal=..., start=..., constraint=..., holding=...)
takes each role in whatever form you have it: a configuration, a list of
configurations, a TSR, a list of TSRs (any of them, for a start or goal; all
of them, for a constraint), or any set. start defaults to
where the arm is now. holding="can" carries a body rigidly with the gripper
and lets it touch the gripper, with the grasp taken from the current poses.
The goal's Bw bounds the pose in the frame T, one [min, max] row each
for x, y, z, roll, pitch and yaw (Task Space Regions).
Collision checking runs on a native copy of the MuJoCo world. The search runs
natively when every piece of the problem has a native form, and in Python
otherwise. result.backend says which ran; result.backend_reasons is empty
for a native solve and otherwise names each piece that kept it in Python
(Backends).
For a gripper, the tsr package's hand models give the grasp regions:
tsr.Robotiq2F85().grasp_cylinder_side(radius, height) returns templates for
every side grasp of a cylinder, and template.instantiate(T_world_cylinder_bottom)
places each as a TSR on the gripper's grasp frame. Pass them all as the goal
and the planner chooses among them; result.goal_index says which.
Quick start without a simulator
Three roles, three kinds of set: a finite start, a goal induced by a pose
region, and a path constraint written for this problem that only implements
membership. Run against the two-link reference arm in sscbirrt.testing.
import numpy as np
from tsr import TSR
from sscbirrt import CBiRRT, CBiRRTConfig, FiniteSet, PlanningProblem, TSRConfigurationSet
from sscbirrt.testing import NoCollision, PlanarArm, PlanarIK

robot, ik, collision = PlanarArm(), PlanarIK(), NoCollision()
planner = CBiRRT(robot, ik, collision, CBiRRTConfig(step_size=0.1, timeout=10.0))

# Goal: end effector within 10 cm of (0, 1.5), orientation free
T = np.eye(4)
T[:3, 3] = [0.0, 1.5, 0.0]
near = TSR(T0_w=T, Tw_e=np.eye(4), Bw=np.array([[-0.1, 0.1], [-0.1, 0.1], [0, 0], [0, 0], [0, 0], [-np.pi, np.pi]]))


class RightOfWall:
    """The end effector stays at x >= -0.2 along the whole path. Membership only."""

    def contains(self, q):
        return robot.forward_kinematics(q)[0, 3] >= -0.2


problem = PlanningProblem(
    space=planner.space,
    start=FiniteSet([np.array([-0.5, 0.5])], metric=planner.space.distance),
    goal=TSRConfigurationSet(near, robot, ik, planner.space),
    validator=collision,
    path_constraint=RightOfWall(),
)
result = planner.solve(problem, seed=0)
result.success        # True
result.path           # 47 waypoints; every one has end-effector x >= -0.2
result.goal_source    # () : the goal is a single leaf, no choice to record
result.backend        # "python": result.backend_reasons names PlanarIK and RightOfWall, which have no native form
The path constraint has no projector, so the planner rejects any extension
that would leave it. Give the class a project method and extensions are
pulled onto the set instead, which is what TSRConfigurationSet does.
For problems whose sets are all TSRs or configuration lists, CBiRRT.plan(...)
is the shorthand. It builds the PlanningProblem for you: configuration lists
become a FiniteSet whose members are roots, TSR lists an AnyOf weighted by
TSR volume, and several constraint_tsrs an AllOf with
MostViolatedProjection. Its arguments differ from sscbirrt.mujoco.plan's:
TSRs go in start_tsrs, goal_tsrs and constraint_tsrs. In this fragment,
q_current, grasp_above, object_pose and upright stand for your own values:
result = planner.plan(
    start=q_current,                       # or a list of configurations
    goal_tsrs=[grasp_above(object_pose)],  # any of these regions
    constraint_tsrs=[upright],             # all of these, along the whole path
    seed=0,
    return_details=True,
)
Two search-strategy components are replaceable on the problem, each with a
default. A custom motion_validator owns the whole edge check, and
RestrictedMotionValidator(base, accepts) adds a restriction on top of the
default discretized check. A custom sampler proposes the free-space
targets the trees grow toward and defaults to the space's uniform sampling;
replacing it trades away probabilistic completeness unless it has full
support over the space. docs/design.md has the
definitions, the composition rules, what the planner requires of each role,
the tolerances, and the reference behavior artifact that pins the planner's
semantics (python tools/reference_artifact.py --check).
Result
sscbirrt.mujoco.plan and CBiRRT.solve return a PlanResult; CBiRRT.plan
returns the path, or the PlanResult with return_details=True:
| Field | Meaning |
|---|---|
path |
joint waypoints from a start member to a goal member, or None |
success, failure_reason |
failure_reason is None on success |
start_source, goal_source |
provenance through the start and goal set expressions |
start_index, goal_index |
index into CBiRRT.plan's start/goal list or TSR list; 0 for single inputs |
iterations, planning_time, tree_sizes |
search statistics |
tree_start, tree_goal |
the two trees, for inspection |
backend, backend_reasons |
"native" or "python", and why not native when "auto" chose Python |
provenance |
dependency versions, and for MuJoCo the scene and snapshot hashes and the SSIK family |
stats |
the cost of the solve by component (counts and seconds) |
trajectory |
with trajectory=TrajectoryOptions(...), the timed trajectory along path (Timed trajectories); otherwise None |
When planning fails
A plan fails in one of two ways.
No start or goal configuration survives. Before searching, the planner
collects the roots of each tree: every explicit configuration, and every IK
solution of every pose drawn from a region. A root must be inside the joint
limits, valid (collision-free), and inside the path constraint, if there is
one. If none survives for a role, solve, CBiRRT.plan and
sscbirrt.mujoco.plan raise a PlanningError:
AllStartConfigurationsInCollision or AllGoalConfigurationsInCollision when
every candidate was in collision, and AllStartConfigurationsInvalid or
AllGoalConfigurationsInvalid otherwise. The message counts each cause, for
example 12 IK unreachable, 3 in collision:
| Cause in the message | What to check |
|---|---|
| IK unreachable | the region is out of the arm's reach, or the IK's frames do not match the robot model's |
| outside joint space | the region needs joint values beyond the limits |
| in collision | the scene at the start or goal, or a held object (holding=) touching something |
| constraint violated | the start or goal is outside the path constraint, which every point of the path, ends included, must satisfy |
The search ends without connecting the trees. The result has
success=False and a failure_reason that starts with Timeout,
Max iterations or Aborted by user, and gives the iteration count and tree
sizes. Raise timeout, or num_tree_roots to start from more members of the
sets. With a path constraint, a small tree that stops growing usually means
projection onto the constraint keeps failing: check that the constraint
leaves room to move between the start and the goal.
backend="native" raises NativeUnsupported, listing every component without
a native form, instead of planning; the default backend="auto" plans in
Python with that list in result.backend_reasons.
Timed trajectories for execution
A planned path is a polyline. A robot executing it under finite acceleration has to stop at every corner. Given the joints' velocity and acceleration limits, sscbirrt also returns a timed trajectory that carries velocity through corners and cuts them where it is safe. It is usually much faster.
from sscbirrt import TrajectoryOptions

limits = TrajectoryOptions(velocity_limits=1.57, acceleration_limits=4.0)   # rad/s, rad/s^2: one, or one per joint
result = plan(model, data, arm, goal=goal, seed=0, trajectory=limits)

traj = result.trajectory                   # result.path is unchanged
q, qd, qdd = traj.evaluate([0.0, 0.5, traj.duration])
times_ns, positions = traj.sample(2_000_000)   # a command every 2 ms, for your runtime
The same trajectory= works on CBiRRT.solve and CBiRRT.plan
(return_details=True). CBiRRT.smooth_trajectory(problem, path, options)
times a path you already have.
Three things, kept apart.
- The path (
result.path): the planner's validated waypoints, never changed. - The trajectory (
result.trajectory): the exact source law. Each joint follows piecewise-constant acceleration (law="piecewise-parabolic"), andevaluategivesq,qdotandqddotexactly. It records:joint_names,startandgoal;- the limits it used;
- the
resolutionit was validated at; seed,backendand why itstopped;- a per-attempt log in
diagnostics.
- A command (
traj.sample(dt_ns)): positions everydt_nsnanoseconds. It is a discretization for one command period, not the source law. A runtime that interpolates between samples deviates from the trajectory, so validate the command under your runtime's own interpolation and limits.
How it works. It starts from the path at rest at every corner, which is
exactly the planned geometry. It then repeatedly picks two times t1 < t2.
It replaces the motion between them with the fastest motion between the two
states that respects every joint's limits, with all joints finishing
together. A replacement is kept only if it is faster and passes the planning
problem's own checks: samples at most edge_resolution apart, each in the
joint limits, collision-free and inside the path constraint, with the motion
validator accepting every chord between them. That is the planner's own
guarantee for an edge, no stronger. Every piece records how it was checked:
"planned" (the planner's edge) or "shortcut". Smoothing never fails: at
worst you get the path with a stop at every corner. After Hauser and
Ng-Thow-Hing (ICRA 2010).
When it stops. These are TrajectoryOptions defaults, each easy to
change:
| Option | Default | Why |
|---|---|---|
convergence_window, convergence_tolerance |
40, 0.005 | stop once the last 40 attempts shortened the trajectory by less than 0.5% |
iterations |
400 | a hard cap on attempts |
time_budget |
None |
a wall-clock limit (seconds) for slow computers; the only machine-dependent rule |
patience |
None |
stop after this many attempts in a row without improvement |
seed |
None |
the solve's seed, or 0 |
Apart from time_budget, every rule depends only on the trajectory, so a
seed gives the same trajectory on any machine. abort_fn (in
CBiRRTConfig) also stops smoothing, keeping the trajectory so far.
What it claims. Each shortcut is the fastest motion between its two states under the limits. The whole trajectory is not globally time-optimal. It models joint position, velocity and acceleration limits only: no jerk, torque, contact or tracking-error limits. Acceleration jumps at piece boundaries. With an equality path constraint (zero width), most shortcuts leave the constraint and are rejected, so most stops remain.
Measured on the pick and transport demos, 100 seeds each, at 1.57 rad/s
and 4 rad/s² (#214,
tools/trajectory_benchmark.py):
| Path with stops | Blends + TOPP-RA | Timed trajectory | Smoothing time (p90) | |
|---|---|---|---|---|
| pick, median duration | 6.23 s | 4.47 s | 3.61 s | 0.04 s |
| transport, median duration | 3.97 s | 2.78 s | 2.42 s | 0.015 s |
Every timed trajectory passed validation. The blends + TOPP-RA baseline failed it on 8–9% of seeds. On these demos, smoothing took less time than the solve that found the path (p90 0.076 s and 0.070 s).
How it works
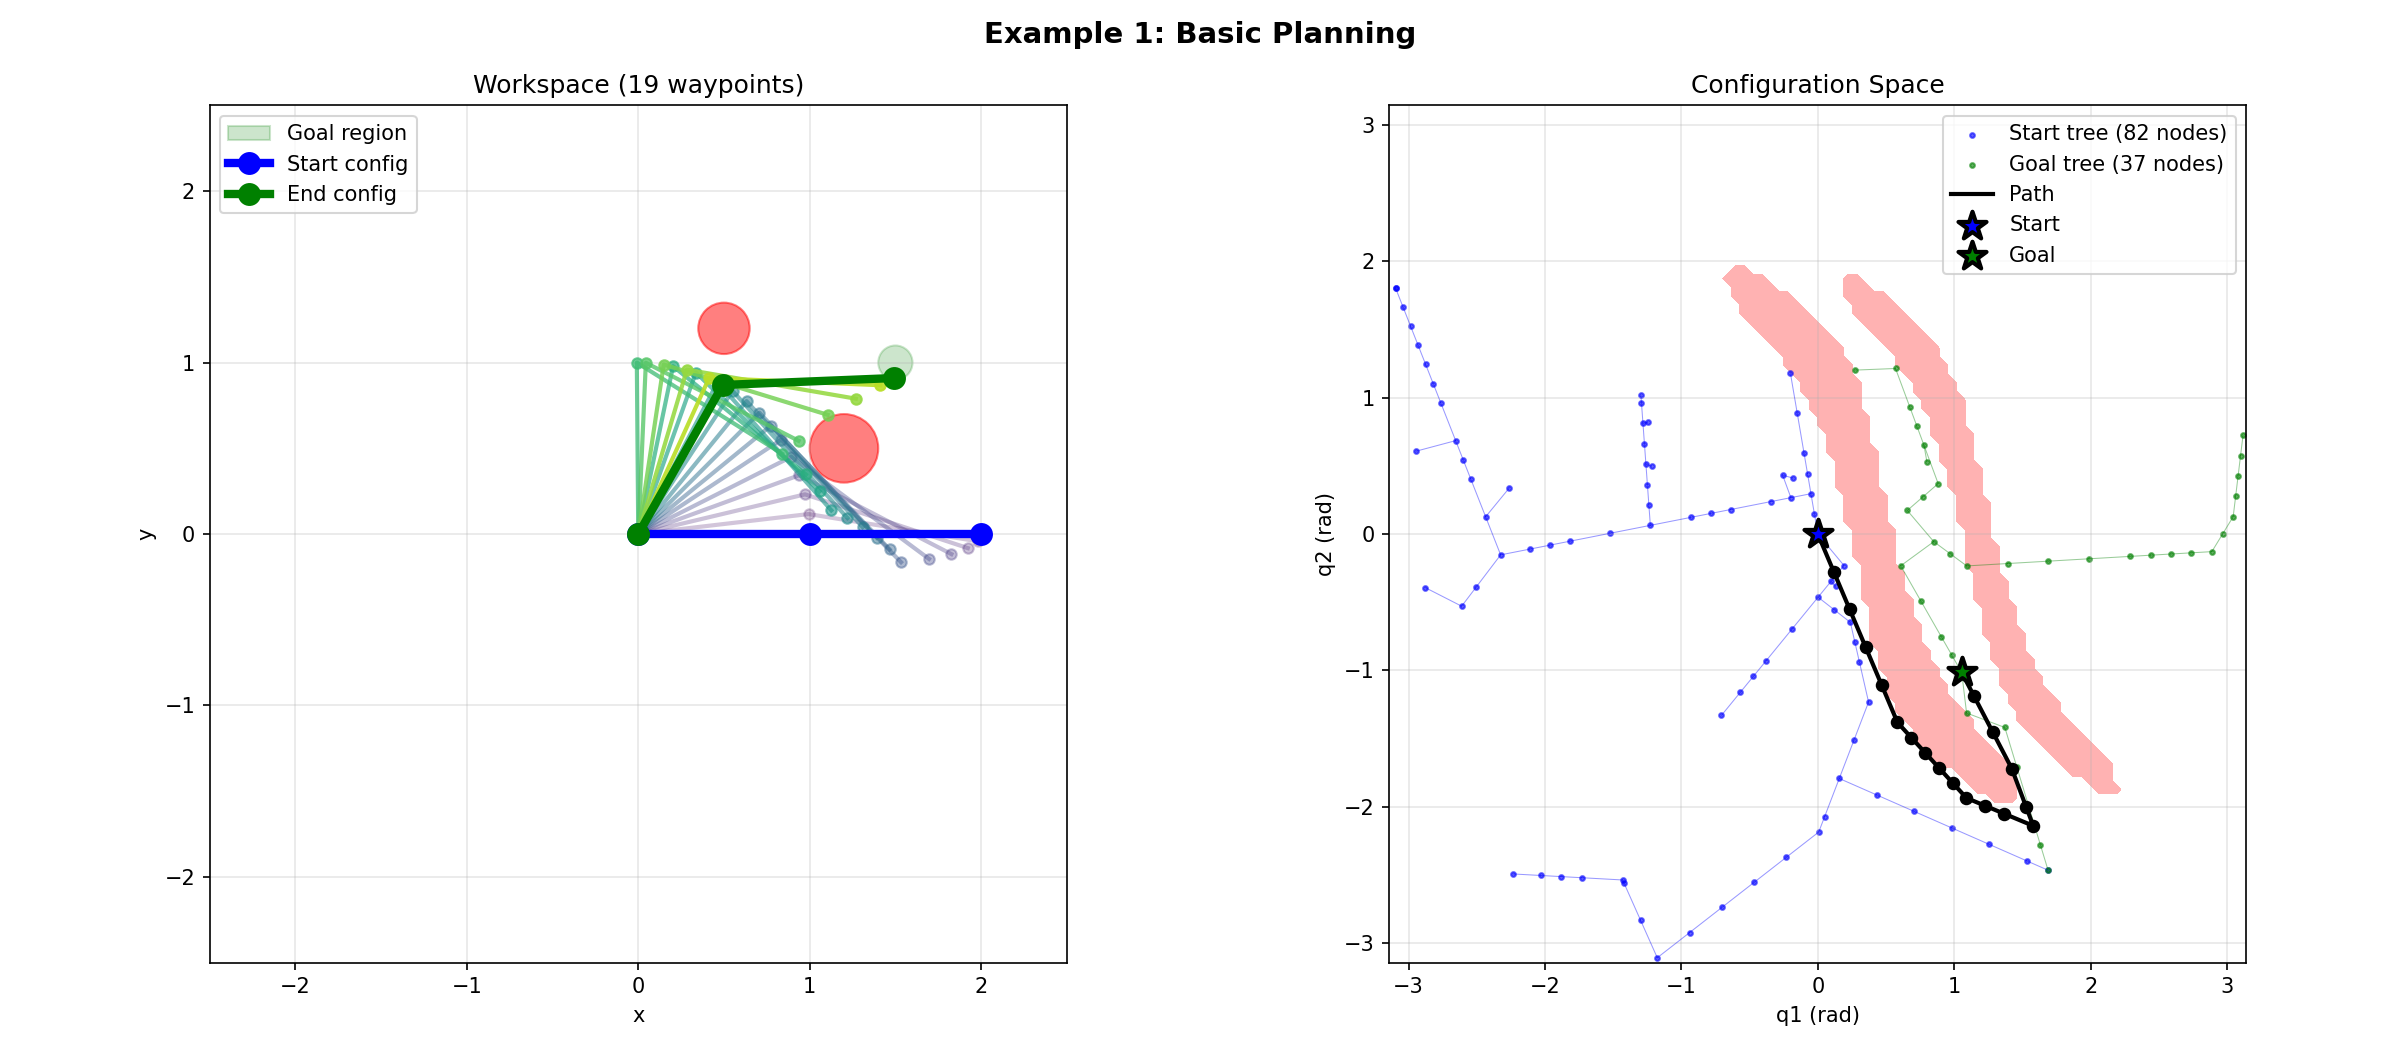
Two trees grow at once, blue from the start set and green from the goal set. The right panel is configuration space; red regions are in collision.
- Grow a set, or sample. The trees take turns. On a tree's turn, with
probability
start_sample_probability(start tree) orgoal_sample_probability(goal tree), the turn draws new members of that tree's own set and adds them as roots, and that is the whole turn. This is CBiRRT'sP_sample: the trees keep gaining start and goal members throughout the search, not only before it. Otherwise the turn samples a random configuration. A finite set's members are all roots from the start, so its tree always samples. - Extend the tree whose turn it is toward the random configuration, in
steps of
step_size. - Project each new configuration onto the path-admissible set when a path constraint is present.
- Connect the trees when one reaches the other within
connection_tolerancealong a validated edge. - Smooth by shortcutting; a shortcut is kept only if it is shorter and passes the same validation as a tree edge.
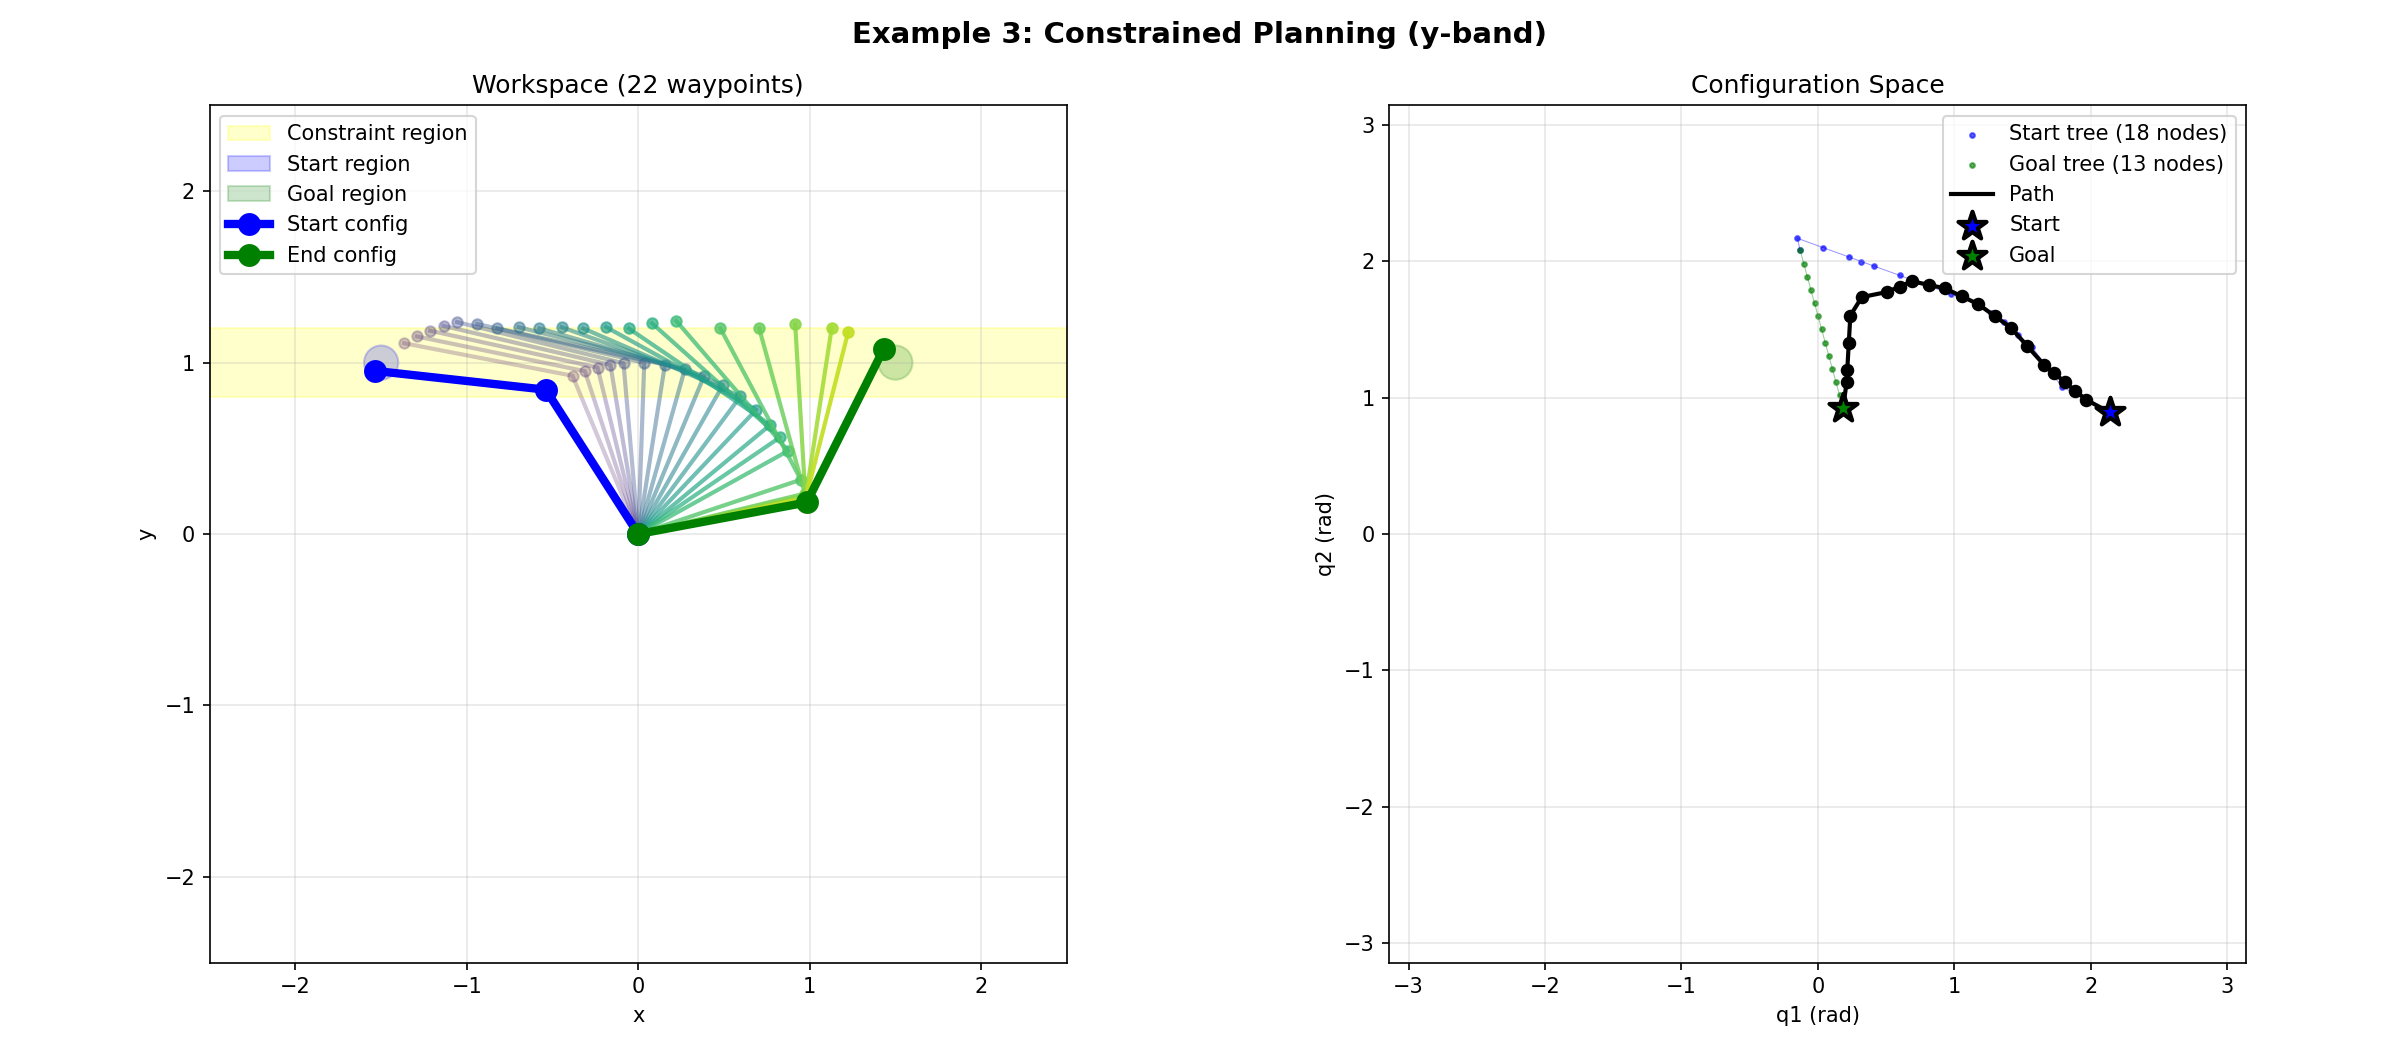
With a path constraint, the end effector stays within the yellow band throughout the motion.
Why sets
A point-to-point planner takes one start configuration and one goal configuration. Manipulation tasks are not specified that way. A grasp is valid anywhere around the rim of a mug. A placement is valid anywhere on a shelf. The arm can begin from any IK solution of its current end-effector pose. A carried cup must stay upright at every point of the motion, not only at its ends. Each of these is a set of configurations, and using a point planner means choosing one member of each set before planning.
That choice is made with the least information available. Whether a given grasp configuration is reachable from a given start, under a given path constraint, is what the search determines. Choosing first means the chosen grasp may collide with the shelf, or lie on an IK branch the arm cannot reach without leaving the constraint set, and the failure is found only after planning. The usual remedy is an outer loop over IK solutions and grasp candidates, replanning each time and rebuilding the same start tree.
Taking the sets moves the choice into the search. Both trees grow from many roots at once, one per member drawn from the start and goal sets, so every alternative is explored in one search and the reachable member is found rather than guessed. Path constraints are enforced during tree growth, by projecting each new configuration onto the constraint set or rejecting it, not by filtering the path afterward. The result records which start and goal member the path uses. And because the planner asks a set for nothing beyond membership, the sets are open: a pose region, a list of configurations, a predicate on forward kinematics, or a set of your own design are all admitted on equal terms.
What a set is
A state set is anything with contains(q) -> bool. The planner never
branches on a set's concrete type. Four capabilities are separate protocols;
a set provides them by defining the method, and supports(s, Capability)
asks.
| Capability | Method | Contract |
|---|---|---|
SetSampler |
sample(rng) -> list[Sample] |
candidate members from one draw, unfiltered; the planner validates them |
SetDistance |
distance(q) -> float |
nonnegative geometric distance to the set, before tolerance |
SetViolation |
violation(q) -> float |
nonnegative and exactly zero iff contains(q) |
SetProjector |
project(q_previous, q_proposed) -> q or None |
move a configuration onto the set, or give up |
What each role requires:
| Role | Requires | Uses if present |
|---|---|---|
| start, goal | explicit members (a finite set anywhere in the expression) or SetSampler, so the tree has roots |
SetDistance for nearest-member queries |
| path constraint | membership only; an extension that leaves the set is rejected | SetProjector, so extensions are projected instead of rejected |
| validator | is_valid(q); applied to every root and every configuration along every edge |
Composition is explicit. AnyOf(children, weights) is the union: a single
child delegates every capability; with several, sampling draws a child by
weight and each Sample records which one. AllOf(children, projection=, sampling=) is the intersection: a single child delegates; with several, the
caller names how to project (MostViolatedProjection) and how to sample
(RejectionSampling(source)), because there is no canonical way to do either
for an intersection. An intersection of finite sets is finite and
enumerable. A Sample carries the configuration and a provenance tuple,
the sequence of choices that produced it, which is what
PlanResult.start_source and goal_source report; a leaf contributes no
choices, so provenance is empty when the set expression has none.
Leaves provided: FiniteSet(configs, tolerance, metric), PredicateSet(fn),
EmptySet(), and TSRConfigurationSet(tsr, robot, ik, space), which is
${q : \mathrm{FK}(q) \in \mathrm{TSR}}$ with all four capabilities.
Defining your own set
A set is a class. Implement contains; add capabilities as the role needs
them.
class MySet:
    def contains(self, q: np.ndarray) -> bool:
        ...                                   # required; the only thing every role needs

    def sample(self, rng: np.random.Generator) -> list[Sample]:
        ...                                   # start/goal roots: every candidate from one draw, unfiltered

    def violation(self, q: np.ndarray) -> float:
        ...                                   # zero iff contains(q); lets strategies rank children

    def project(self, q_previous: np.ndarray, q_proposed: np.ndarray) -> np.ndarray | None:
        ...                                   # path constraints: move q_proposed onto the set, or None
Rules the planner relies on: sample returns every candidate a draw
produces (for example every IK branch of one pose) and applies no collision
or other external filter, since which branch is valid is the validator's
call; violation is on the set's own scale and agrees with contains at
zero; project may use q_previous to seed an iterative solve or to reject
a result that moved too far. Every configuration a set returns is checked
against the joint space and the validator before it is stored, so a set
cannot put an invalid configuration into a tree.
Task Space Regions
A TSR is a pose region in SE(3): a reference frame T0_w, an end-effector
offset Tw_e, and bounds Bw on x, y, z, roll, pitch, yaw in the reference
frame. TSRConfigurationSet lifts it through the robot into the set of
configurations whose end effector lies in the region, and the TSR's geometry
supplies every capability: sampling (draw a pose, solve IK for every
branch), distance and violation (TSR distance of the forward kinematics),
and projection (the closest pose in the region, then IK seeded from the
previous configuration).
from tsr import TSR

grasp_tsr = TSR(
    T0_w=object_pose,     # reference frame at the object
    Tw_e=gripper_offset,  # gripper offset from that frame
    Bw=np.array([
        [-0.01, 0.01], [-0.01, 0.01], [0, 0],  # position: ±1 cm in x and y, exact z
        [0, 0], [0, 0], [-np.pi, np.pi],       # roll and pitch fixed; yaw free
    ]),
)
Several TSRs in goal_tsrs or start_tsrs form a union; sampling is
proportional to each TSR's volume. Configuration lists and TSRs can be mixed
in the same role (the names below stand for your own configurations and
TSRs):
path = planner.plan(start, goal_tsrs=[top_grasp_tsr, side_grasp_tsr])
path = planner.plan(start=[home1, home2, home3], goal_tsrs=[grasp_tsr])
path = planner.plan(start=current, goal=[ik_sol1, ik_sol2, ik_sol3])
path = planner.plan(start=[home], start_tsrs=[start_region], goal=[q_grasp], goal_tsrs=[grasp_region])
A TSRChain couples TSRs in series (a handle on a swinging door) and defines
one region of end-effector poses. It goes anywhere a TSR goes. A complete,
runnable chain is the door demo's door_chain in
src/sscbirrt/demo/scenarios/door.py:
from tsr import TSRChain

door = TSRChain(TSRs=[hinge_tsr, handle_tsr])
path = planner.plan(start_config, goal_tsrs=[door])
For a chain of two or more TSRs, membership and projection search
numerically for the links' values (sstsr's bounded inverse). The search can
miss a pose that is in the chain, but never accepts one that is not, so every
configuration on a returned path is in the set. A miss costs coverage: fewer
start or goal roots, and some extensions under a chain path constraint
rejected. If a chain problem finds no roots or does not connect, raise
sample_draws and num_tree_roots, or widen the chain's bounds where the
task allows. Chains plan natively like single TSRs: the door demo's chain
plans in about 0.3 s natively, against 5 to 9 s in Python.
Configuration
from sscbirrt import CBiRRTConfig

config = CBiRRTConfig(
    # Termination
    timeout=30.0,                       # Wall-clock seconds
    max_iterations=100000,              # Safety limit
    abort_fn=None,                      # Callable returning True to stop early

    # Tolerances
    membership_tolerance=1e-3,          # TSR distance at which a configuration is in the set
    connection_tolerance=1e-3,          # Joint-space distance at which growth has reached its target
    edge_resolution=0.05,               # Spacing of collision checks along an edge, independent of step_size
    progress_tolerance=1e-6,            # Growth stops when it gains less than this per step
    projection_progress_tolerance=1e-6, # Projection gives up when the violation shrinks less than this

    # Tree growth
    step_size=0.1,                      # Max joint-space step per iteration
    start_sample_probability=0.1,       # On the start tree's turn, probability of adding start roots instead
    goal_sample_probability=0.1,        # On the goal tree's turn, probability of adding goal roots instead
    max_projection_iters=50,            # Iterations to project onto the constraint set

    # Set sampling
    sample_draws=100,                    # Pose samples to try from each TSR
    num_tree_roots=100,                 # Root configs to seed each tree before the search
    max_per_draw=None,                  # Candidates kept per draw; None keeps every one (3 until 3.4)

    # Extension behavior (None = connect until blocked)
    extend_steps=None,                  # Steps toward a random sample
    connect_steps=None,                 # Steps toward the other tree

    # Smoothing
    smooth_path=True,
    smoothing_iterations=50,
    smoothing_patience=15,              # Stop early after this many attempts without improvement

    # Joints with no limits (see below); None = every joint is bounded
    continuous_joints=None,
)
tsr_tolerance is a deprecated alias that sets both membership_tolerance
and connection_tolerance and warns.
membership_tolerance, max_projection_iters and
projection_progress_tolerance configure the sets that plan(...) builds
from its arguments. A set you construct yourself and pass to solve keeps
its own constructor values (FiniteSet(tolerance=1e-6),
TSRConfigurationSet(tolerance=1e-3, ...)).
Continuous joints
Mark a joint continuous (continuous_joints) only if it has no limits. The space never infers
this: a bounded joint must have finite limits, and a robot model that
reports an unlimited joint (the MuJoCo model reports ±∞) fails at planner
construction until you either mark the joint continuous or give it finite
planning limits. A continuous joint ignores whatever limits were stored for
it, samples over one full turn, and its distance wraps at 2π so the planner
may join the trees across the seam. Joints with limits
wider than one turn, such as the UR5e's ±2π joints, are not continuous: their
windings are distinct configurations and the planner respects the limits.
Returned paths are unwrapped forward from the start, so on a continuous joint
consecutive waypoints never differ by more than a step and an executor can
interpolate them directly. The goal may therefore be re-expressed by a
multiple of 2π.
Planning variants
| extend_steps | connect_steps | Behavior |
|---|---|---|
| None | None | CON-CON: both trees march until blocked (default) |
| 5 | 5 | EXT-EXT: both trees take limited steps |
| 5 | None | EXT-CON: extend limited, connect unlimited |
| None | 5 | CON-EXT: extend unlimited, connect limited |
Interfaces
class RobotModel(Protocol):
    @property
    def dof(self) -> int: ...

    @property
    def joint_limits(self) -> tuple[np.ndarray, np.ndarray]: ...

    def forward_kinematics(self, q: np.ndarray) -> np.ndarray:
        """Return the 4x4 end-effector pose."""


class IKSolver(Protocol):
    def solve(self, pose: np.ndarray, q_init: np.ndarray | None = None) -> list[np.ndarray]:
        """Return every IK solution, unfiltered; q_init is an optional seed."""


class CollisionChecker(Protocol):
    def is_valid(self, q: np.ndarray) -> bool:
        """Return True if collision-free."""
Two optional declarations make root collection cheaper. They are declared,
never inferred. An IK solver's revolute_joints names the joints on which q
and q + 2πk put the arm in the same place; SSIK declares all of its joints. A
collision checker's full_turn_invariant = True says that a full turn of a
joint never changes its verdict; the MuJoCo checkers declare it when every
planned joint is a hinge. With both, the many windings that SSIK returns for
one pose are collision-checked once, not each separately (#200). The result
is the same, only faster.
Together with StateSet, these are the planner's extension points. Each has
a native counterpart in the C++ core (StateSet, StateValidator,
ForwardKinematics, IKSolver), and the shipped integrations below are
implementations of them, not special cases; see
Adding an integration.
Backends: native and Python
The C++20 core in cpp/ implements the same contract as the Python planner
(docs/native-design.md). It is built into the wheel
as sscbirrt._native, and since 2.0 the planner selects it by default:
planner = CBiRRT(robot, ik, collision, config)                    # backend="auto": native where it can, else Python
planner = CBiRRT(robot, ik, collision, config, backend="native")  # native or NativeUnsupported; never a silent fallback
planner = CBiRRT(robot, ik, collision, config, backend="python")  # the reference implementation, always
result = planner.solve(problem, seed=0)
result.backend          # "native" or "python"
result.backend_reasons  # under "auto": why Python was chosen, one entry per component; also logged at INFO
Selection is decided by the problem's components, never by which optional
packages happen to import: a missing extension or adapter is itself one of
the stated reasons. The native core plans problems whose components all have
a native form: finite sets, AnyOf/AllOf with the named strategies,
EmptySet, the validators in sscbirrt.testing, any validator or IK solver
that implements the integration protocols below (the MuJoCo scene and SSIK
do), and TSRConfigurationSets whose region is a TSR or TSRChain and whose IK
has a native form (SSIK around an ssik.Manipulator of a verified family,
the UR family ikgeo.three_parallel). TSRs and SSIK then run entirely in
C++: TSRs and TSR chains are sstsr's own C++ core (sstsr 3.3), and the SSIK
adapter is checked against the Python one on the UR5e. Anything else
(Python-only IK, predicates, Python-only validators, samplers, or motion
validators) makes backend="native" raise NativeUnsupported listing every
blocker, and the default fall back to Python with the same list on the
result; Adding an integration is how to give a
component a native form. Before a native solve, sscbirrt translates the
problem into the core's C++ objects ("lowering"); lowering also checks that the robot model's forward kinematics
agrees with the native IK model's on the problem's explicit configurations.
The native solve releases the GIL and calls no Python after entry. Same
seed, same path within a backend; the two backends agree on outcomes and
validated paths but not on waypoints, because they use different
random-number engines. tools/reference_artifact.py --backend {python,native,auto} --check
runs the behavior artifact through each selection.
Integrations
sscbirrt ships three integrations. Each implements one interface the core defines and each lives in its own module, so none is required by the others:
| Integration | Implements | C++ target | Python |
|---|---|---|---|
Task Space Regions (sstsr) |
StateSet |
sscbirrt::tsr |
sscbirrt.tsr_set |
| SSIK | ForwardKinematics, IKSolver |
sscbirrt::ssik (the only target that uses Eigen) |
sscbirrt.backends.ssik, native_ssik |
| MuJoCo | StateValidator |
sscbirrt::mujoco, module sscbirrt._native_mujoco |
sscbirrt.backends.mujoco, native_mujoco |
sscbirrt::core depends on none of them and on nothing but the C++ standard
library. import sscbirrt and the native planner work with no simulator and
no IK library installed; a missing one is reported as a reason, never an
import error. Another simulator or IK library is a fourth module of the same
shape (Adding an integration).
MuJoCo
sscbirrt.mujoco (above) is the way in. The pieces it is
built from are usable on their own:
from sscbirrt.backends.mujoco import MuJoCoCollisionChecker, MuJoCoIKSolver, MuJoCoRobotModel

robot = MuJoCoRobotModel(model, data, ee_site="attachment_site", joint_names=joints)
collision = MuJoCoCollisionChecker(model, data, joint_names=joints)   # any contact is a collision
ik = MuJoCoIKSolver(model, data, ee_site="attachment_site", joint_names=joints, collision_checker=collision, seed=0)
Name the arm's joints: a model with free bodies (objects on a table) refuses
joint_names=None. MuJoCoRobotModel(joint_limits=(lower, upper)) replaces the
model's limits, for example to give an unlimited joint finite planning limits.
The differential solver is stateful and, when called without a seed
configuration, tries a few random restarts within each joint's limits. Pass
seed= for reproducible runs; CBiRRT.plan(seed=...) seeds the planner only.
Native MuJoCo scene (collision checking in C++)
With sscbirrt[mujoco] (pinned to mujoco==3.14.0, the version the extension
is built against), collision checking can run natively against a MuJoCo world
the planner owns:
from sscbirrt.backends.native_mujoco import NativeScene, Snapshot, NativeCollisionChecker

scene = NativeScene.from_model(model, joint_names)              # an owned mjModel from the compiled model's MJB bytes
snap = Snapshot.capture(scene, data, attachments={"can": ("robot/gripper/base", T_gripper_can)})
checker = NativeCollisionChecker(scene, snap)                   # a CollisionChecker for either backend
sscbirrt.mujoco.plan builds the scene, the snapshot, and the checker for
you. plan_native(model, data, joint_names, ...) in this module did the same
before 3.1.0 and is deprecated.
The snapshot is a value: qpos, mocap poses, and attachments copied at capture,
so later changes to data do not reach a running solve. Downstream integration
is described in docs/migration-mj-manipulator.md. The contact policy is
mj_manipulator's (a grasped object may touch its gripper; everything else that
touches the robot is a collision) and is checked against it on a checked-in
corpus. PlanResult.provenance records the scene's MJB hash and the snapshot
hash alongside the dependency versions; PlanResult.stats breaks the solve's
cost down by component on both backends.
SSIK (analytical IK, recommended)
uv pip install "sscbirrt[ssik]" # ssik >= 7.0
SSIKRobotModel(ik) is a RobotModel whose forward kinematics and limits
come from the wrapped manipulator, for planning without a simulator.
SSIK is the analytical IK backend. The EAIK backend, deprecated in 1.3.0, was
removed in 2.0 with its eaik extra; SSIKSolver(ssik.Manipulator.from_prebuilt("ur5e"))
replaces EAIKSolver.for_ur5e(...).
SSIK solves 6R and 7R arms in closed form, accepts a seed, and returns every
in-limit winding of each geometric branch on joints wider than one turn, so
the planner sees the complete TSR-induced configuration set. The adapter does
no collision checking and applies no solution cap; joint limits are enforced
by JointSpace and collision by the planner's validator.
SSIK runs on the native backend for a 6-DOF ssik.Manipulator of a verified
family, today the UR family (ikgeo.three_parallel). Any other arm, a 7R arm
such as a Franka included, plans with SSIK on the Python backend, and
result.backend_reasons says so.
sscbirrt.mujoco.Arm(..., mjcf=path) builds SSIK for you, computes both
frame offsets from the MuJoCo model (so the arm can stand anywhere in the
world), and checks that the two agree. By hand:
import ssik
import sscbirrt_assets
from sscbirrt.backends.mujoco import site_offset_in_body
from sscbirrt.backends.ssik import SSIKSolver

# From the same MJCF as the MuJoCo model, so the frames agree to machine precision
arm = ssik.Manipulator.from_mjcf(sscbirrt_assets.ur5e_xml(), base="world", ee="wrist_3_link")
ik = SSIKSolver(arm, T_ee=site_offset_in_body(model, "attachment_site"))  # the site is on wrist_3_link

# Or the prebuilt model (vendor nominal geometry); ssik.Manipulator.from_urdf takes a URDF
ik = SSIKSolver(ssik.Manipulator.from_prebuilt("ur5e"))
The SSIK model and the RobotModel must agree on joint order and sign, base
frame, end-effector frame, and which joints are continuous. If the frames
differ by fixed transforms, pass T_base and T_ee so that
robot.forward_kinematics(q) == ik.fk(q), and assert that before planning.
Prebuilt models use the vendor's nominal geometry and can differ from a
simulator model by a millimeter, which matters at the default membership
tolerance.
Adding an integration
The native backend runs a solve only when every component has a native form.
One Python-only validator, IK solver or set sends the whole solve, every
sample, extension and collision check, to the Python planner: the cost is the
whole speedup, not that component's share. The door demo shows the size. Its
TSR chain had no native form before 3.2.0; the same problem now plans in
about 0.3 s natively, against 5 to 9 s in Python. result.backend_reasons
names each component that kept a solve in Python, so it is the list of what
to port.
The native lowering (sscbirrt.backends.native) recognizes validators and IK
solvers by two protocols, never by type, so a new collision or IK backend
plugs in without a change to sscbirrt:
from sscbirrt.backends.native import ValidatorIntegration, KinematicsIntegration

class MyChecker:                       # a CollisionChecker for the Python backend ...
    def is_valid(self, q) -> bool: ...
    def fresh(self):                   # ... and, for the native one, a sscbirrt StateValidator per solve
        return my_native_module.Validator(self.world_handle)
    @property
    def provenance(self) -> dict:      # what it checked against; merged into PlanResult.provenance
        return {"my_world_sha256": self.world_hash}

class MyIK:                            # an IKSolver ...
    def solve(self, pose, q_init=None) -> list: ...
    def native_kinematics(self):       # ... that is also a sscbirrt ForwardKinematics and IKSolver,
        return my_native_module.Arm(self.spec)   # or raises NativeUnsupported([reason])
    provenance = {"ik_backend": "mine"}
On the C++ side, subclass sscbirrt::StateValidator (one virtual, is_valid)
or sscbirrt::ForwardKinematics and sscbirrt::IKSolver in a target that
links sscbirrt::core, and bind it with pybind11 in your own extension
module, declaring the base registered by sscbirrt._native so a native
PlanningProblem accepts your object. NativeCollisionChecker and
SSIKSolver are the two shipped implementations of these protocols and are
the templates to copy. The rules that made them trustworthy apply to a new
one too: the native form and the Python form are one implementation or are
checked against each other on a corpus (MuJoCo: 490 configurations against
mj_manipulator; SSIK: the UR5e artifact), the library version is pinned and
verified at import, and per-solve scratch state comes from fresh() so a
validator is never shared between concurrent solves. Lowering itself checks
that your native_kinematics() agrees with the problem's RobotModel on the
explicit configurations, and refuses with a reason if it does not.
Examples
# MuJoCo: a UR5e with a Robotiq 2F-85, rendered to MP4 (pip install "sscbirrt[demo]")
sscbirrt-demo                           # pick, transport, and door
sscbirrt-demo --list                    # what each one shows
sscbirrt-demo pick --seed 3             # one scenario, another seed

# A 2-DOF planar arm with matplotlib plots of the trees (no simulator)
uv pip install -e ".[examples]"
python examples/planar_arm.py           # all four
python examples/planar_arm.py -e 1      # basic planning
python examples/planar_arm.py -e 2      # start and goal TSRs
python examples/planar_arm.py -e 3      # a path constraint
python examples/planar_arm.py -e 4      # several start and goal configurations
The demos are the MuJoCo examples to read: each scenario in
src/sscbirrt/demo/scenarios/ is one file
built on sscbirrt.mujoco, and sscbirrt-demo runs them.
References
- Berenson, D., Srinivasa, S., Ferguson, D., & Kuffner, J. (2009). Manipulation planning on constraint manifolds. ICRA.
- Berenson, D., Srinivasa, S., & Kuffner, J. (2011). Task Space Regions: A framework for pose-constrained manipulation planning. IJRR.
License
MIT
1 maintainer

Metadata
1 maintainer
Release files for sscbirrt 3.5.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| sscbirrt-3.5.0.tar.gz | 5.7 MB | Details |
Built distributions (wheels)
| File | Reset | |||
|---|---|---|---|---|
| sscbirrt-3.5.0-cp314-cp314-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl | CPython 3.14 | CPython 3.14 | Linux glibc 2.28+ x86-64, Linux glibc 2.27+ x86-64 | Details |
| sscbirrt-3.5.0-cp314-cp314-macosx_11_0_arm64.whl | CPython 3.14 | CPython 3.14 | macOS 11.0+ ARM64 | Details |
| sscbirrt-3.5.0-cp313-cp313-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl | CPython 3.13 | CPython 3.13 | Linux glibc 2.28+ x86-64, Linux glibc 2.27+ x86-64 | Details |
| sscbirrt-3.5.0-cp313-cp313-macosx_11_0_arm64.whl | CPython 3.13 | CPython 3.13 | macOS 11.0+ ARM64 | Details |
| sscbirrt-3.5.0-cp312-cp312-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl | CPython 3.12 | CPython 3.12 | Linux glibc 2.27+ x86-64, Linux glibc 2.28+ x86-64 | Details |
| sscbirrt-3.5.0-cp312-cp312-macosx_11_0_arm64.whl | CPython 3.12 | CPython 3.12 | macOS 11.0+ ARM64 | Details |
| sscbirrt-3.5.0-cp311-cp311-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl | CPython 3.11 | CPython 3.11 | Linux glibc 2.28+ x86-64, Linux glibc 2.27+ x86-64 | Details |
| sscbirrt-3.5.0-cp311-cp311-macosx_11_0_arm64.whl | CPython 3.11 | CPython 3.11 | macOS 11.0+ ARM64 | Details |
| sscbirrt-3.5.0-cp310-cp310-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl | CPython 3.10 | CPython 3.10 | Linux glibc 2.28+ x86-64, Linux glibc 2.27+ x86-64 | Details |
| sscbirrt-3.5.0-cp310-cp310-macosx_11_0_arm64.whl | CPython 3.10 | CPython 3.10 | macOS 11.0+ ARM64 | Details |
Total release size: 13.5 MB
Release files / sscbirrt-3.5.0.tar.gz
| Download URL | sscbirrt-3.5.0.tar.gz |
|---|---|
| Size | 5.7 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
17aab6321c978779e4ebc0cf4770d585bff7dc6f731a39bf9da8804bad14b341
|
|
BLAKE2b-256 checksum How to use checksums |
8fd282a992bf278293e9fec9e8b9015eb597d1946870bd680d7de6e5f8f8ba91
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 12, 2026.
Transparency logRelease files / sscbirrt-3.5.0-cp314-cp314-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl
| Download URL | sscbirrt-3.5.0-cp314-cp314-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl |
|---|---|
| Size | 899.9 kB |
| Tags | CPython 3.14 Linux glibc 2.27+ x86-64 Linux glibc 2.28+ x86-64 |
|
SHA-256 checksum How to use checksums |
17f0952d4feedde7117799b725e289e8425bb9dc8f59595ba1b09818687f47e9
|
|
BLAKE2b-256 checksum How to use checksums |
7d1e4e445c868bbe04b1b2cd6ee92fd98a3092a1d7a0d571b490c1c70e628486
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 12, 2026.
Transparency logRelease files / sscbirrt-3.5.0-cp314-cp314-macosx_11_0_arm64.whl
| Download URL | sscbirrt-3.5.0-cp314-cp314-macosx_11_0_arm64.whl |
|---|---|
| Size | 658.6 kB |
| Tags | CPython 3.14 macOS 11.0+ ARM64 |
|
SHA-256 checksum How to use checksums |
c0dfeca96e649dd5557811d2f567d72750bb2d74c9194651104652756a98b17f
|
|
BLAKE2b-256 checksum How to use checksums |
afcfec6090884a03901d7569716eaba8be2da9f218a5ac64902f85583ebf5ffd
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 12, 2026.
Transparency logRelease files / sscbirrt-3.5.0-cp313-cp313-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl
| Download URL | sscbirrt-3.5.0-cp313-cp313-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl |
|---|---|
| Size | 899.4 kB |
| Tags | CPython 3.13 Linux glibc 2.27+ x86-64 Linux glibc 2.28+ x86-64 |
|
SHA-256 checksum How to use checksums |
6fe866bab2c63fa4c537207efd1a8bb0f765f51bb04f7806f55db4fcc6cbae80
|
|
BLAKE2b-256 checksum How to use checksums |
26887925c180310609ba270fb16f9db9f147c3ee1526539c4372e9baa55bf292
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 12, 2026.
Transparency logRelease files / sscbirrt-3.5.0-cp313-cp313-macosx_11_0_arm64.whl
| Download URL | sscbirrt-3.5.0-cp313-cp313-macosx_11_0_arm64.whl |
|---|---|
| Size | 657.9 kB |
| Tags | CPython 3.13 macOS 11.0+ ARM64 |
|
SHA-256 checksum How to use checksums |
7f81639de5a3527abf98cc422b4c081732be24f0d0c3f8cf02260260d863d934
|
|
BLAKE2b-256 checksum How to use checksums |
d4b4b31e4bfa625d7d7e7812c648a71ab4bba30adb9c11949cb9c9367f9e731f
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 12, 2026.
Transparency logRelease files / sscbirrt-3.5.0-cp312-cp312-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl
| Download URL | sscbirrt-3.5.0-cp312-cp312-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl |
|---|---|
| Size | 899.3 kB |
| Tags | CPython 3.12 Linux glibc 2.27+ x86-64 Linux glibc 2.28+ x86-64 |
|
SHA-256 checksum How to use checksums |
e191fb40d0fbadd41e8055d6df5ab23fea94bdea4156e3825abb54d721567276
|
|
BLAKE2b-256 checksum How to use checksums |
02eedd42879270fcb587b43680b842ea61514c05189cd4e4909a7f8dd70a25b8
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 12, 2026.
Transparency logRelease files / sscbirrt-3.5.0-cp312-cp312-macosx_11_0_arm64.whl
| Download URL | sscbirrt-3.5.0-cp312-cp312-macosx_11_0_arm64.whl |
|---|---|
| Size | 657.8 kB |
| Tags | CPython 3.12 macOS 11.0+ ARM64 |
|
SHA-256 checksum How to use checksums |
4d3385b6c1e91f1c80b2245f3c57493a52c6a7e2b6659ce623d5eb9f9013d508
|
|
BLAKE2b-256 checksum How to use checksums |
3aa2a1f2ba41c5bd3c569da129a0ffb624bd25458aab3812b821ab4f8a742770
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 12, 2026.
Transparency logRelease files / sscbirrt-3.5.0-cp311-cp311-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl
| Download URL | sscbirrt-3.5.0-cp311-cp311-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl |
|---|---|
| Size | 893.8 kB |
| Tags | CPython 3.11 Linux glibc 2.27+ x86-64 Linux glibc 2.28+ x86-64 |
|
SHA-256 checksum How to use checksums |
cccd163cb5c8561fc8d99d41d4c73cf46ab02381755a6156f99ec5c018e05500
|
|
BLAKE2b-256 checksum How to use checksums |
98ab7962dd41a69df4569156f916511bf44485eecf521c32d5d934ab0de3a280
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 12, 2026.
Transparency logRelease files / sscbirrt-3.5.0-cp311-cp311-macosx_11_0_arm64.whl
| Download URL | sscbirrt-3.5.0-cp311-cp311-macosx_11_0_arm64.whl |
|---|---|
| Size | 655.2 kB |
| Tags | CPython 3.11 macOS 11.0+ ARM64 |
|
SHA-256 checksum How to use checksums |
fea977c4aa800a8b37333a36396a3ee307c08edc143dfa48504d49754fe7f409
|
|
BLAKE2b-256 checksum How to use checksums |
38d9d9821dbf41d812180589737edbe2f19b52d1c14c58e169191c9f2b271140
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 12, 2026.
Transparency logRelease files / sscbirrt-3.5.0-cp310-cp310-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl
| Download URL | sscbirrt-3.5.0-cp310-cp310-manylinux_2_27_x86_64.manylinux_2_28_x86_64.whl |
|---|---|
| Size | 891.9 kB |
| Tags | CPython 3.10 Linux glibc 2.27+ x86-64 Linux glibc 2.28+ x86-64 |
|
SHA-256 checksum How to use checksums |
ae3eaa5dfab9eedacc364272647c5d4155c8c17947e295c0e891e23fa2ac4853
|
|
BLAKE2b-256 checksum How to use checksums |
9a19e27986cd8ef64eef37df359958a5e970853dac803528a68605325d4c2f1f
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 12, 2026.
Transparency logRelease files / sscbirrt-3.5.0-cp310-cp310-macosx_11_0_arm64.whl
| Download URL | sscbirrt-3.5.0-cp310-cp310-macosx_11_0_arm64.whl |
|---|---|
| Size | 651.9 kB |
| Tags | CPython 3.10 macOS 11.0+ ARM64 |
|
SHA-256 checksum How to use checksums |
099287b4c64223979ec831516198b5ebecfd873e65a194bd284d7cac35fdd64a
|
|
BLAKE2b-256 checksum How to use checksums |
aa64cccdff663dd69947ce0d04f04ffabe3d298a14717659cf79bbef0a06f2d4
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 12, 2026.
Transparency log













