
Probe any vision backbone across high-, mid- and low-level computer vision tasks.



Status: v0.17.0. Seventeen probes across high, mid and low level, thirteen backbones from three families, and a committed corpus covering 204 board cells — seventeen boards, twelve backbones each, every one of them reproducible from the flags in its own record. The full documentation, including a generated API reference, is at https://turhancan97.github.io/VisBench.
Try it in thirty seconds
No dataset, no configuration, no large download:
pip install visbench
visbench demo
drawing 20 images per class for 4 shapes...
loading resnet18 (torchvision, ~45 MB on first run)...
running the classification probe...

  top1         0.8125

  chance is 0.25 — the shapes differ in outline only.
That is a real probe, on a real pretrained backbone, through the same code path every other run uses. The images are generated: four shapes with colour, size, position and rotation randomised, so only geometry identifies a class and a backbone that has not learned shape scores about chance.
The number is deliberately not 1.0. Turn the difficulty up and watch it fall:
visbench demo --noise 90 # top1 ~0.31, against a chance of 0.25
--noise |
28 | 45 (default) | 60 | 75 | 90 |
|---|---|---|---|---|---|
| top1 | 0.975 | 0.812 | 0.550 | 0.438 | 0.312 |
A probe whose score does not move when you destroy the signal is not measuring the signal. That slide into chance is the demo's actual point.
Install
pip install visbench                    # core: DINOv2, every probe, the CLI
pip install 'visbench[clip,timm]'       # + CLIP and timm backbones
pip install 'visbench[hub]'             # + push/pull probes to Hugging Face
A backbone whose extra is missing stays listed — visbench list backbones
marks it — and constructing one tells you which extra to install rather than
pretending the name does not exist.
Full instructions, including a source install and what each extra buys: installation.
What it is
The name is literal: Vis(ion) Bench(mark). Both halves are a scope commitment. Vis — the subject is a vision backbone's features, not a multimodal or language model's behaviour; a text tower is only ever used to build the visual one. Bench — the output is a comparable number rather than a score: every run writes a record saying which backbone, dataset, pooling, layers and protocol produced it, and explicit rules decide which records may be ranked against each other at all.
VisBench answers one question with as little ceremony as possible: what does this vision backbone actually encode?
as root/<class_name>/<image>:
import visbench
from visbench.data import ImageFolderDataset

result = visbench.run(
    "dinov2_vitb14",
    "retrieval",
    ImageFolderDataset("data/tiny", split="val"),
    results="results/visbench.jsonl",
)
result.metrics    # {"recall@1": 0.94, "recall@5": 0.99, "mAP": 0.87}
result.record     # the ResultRecord that says exactly how they were produced
run() resolves pooling, extracts through the cache, fits the probe if it
trains, evaluates, and appends the record. The pieces are public if you want
them separately — see
the quickstart.
Installing the package also puts a visbench command on your path, a thin
wrapper over the same call:
visbench demo                       # a real probe on generated data, no setup
visbench list                       # backbones, probes and heads that exist
visbench run retrieval --data /path/to/imagenette2 --split val
visbench show depth --data /path/to/nyuv2 --out panels.png
Each probe is its own subcommand, because they do not take the same data — the CLI reference.
Look before you measure
visbench show <probe> draws what a probe saw beside what it predicted. It
measures nothing — it exists because a dense target that has drifted from its
image fails silently: the probe trains, and the number merely comes out
mediocre. Two of the most expensive bugs in this project were exactly that, and
both are obvious in one frame.
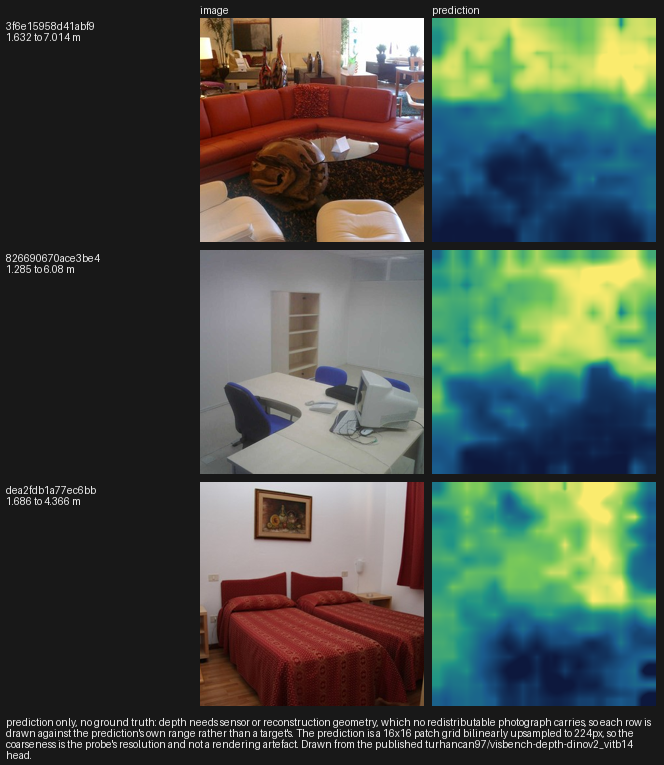
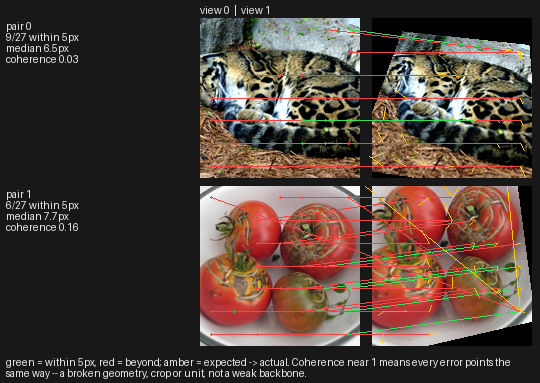
Every probe is drawable, and every figure here is a real photograph run through the real command — see looking at a probe for all seventeen and how to read them.
Task levels
Following Chen, Marks & Cheng (arXiv:2411.17474):
| Level | Tasks | Status |
|---|---|---|
| High-level — semantic / category | classification, retrieval | v0.1 |
| semantic (multi-class) segmentation | v0.2 | |
| detection (anchor-free, single-scale) | v0.3 | |
| Mid-level — geometry & generic structure | geometric correspondence | v0.1 |
| depth, surface normals, generic (binary) segmentation, mid-level similarity | v0.2 | |
| occlusion-edge detection | v0.5 | |
| Low-level — signal properties | edge detection (dense magnitude regression) | v0.4 |
| 2D keypoint detection | v0.5 | |
| optical flow, texture, IQA | scope only |
Mid-level is where VisBench aims to be strongest relative to existing tooling. Note that mid-level image similarity and high-level retrieval are separate tasks — one judges perceptual/geometric resemblance, the other category membership.
Design in three points
One extraction method. backbone.extract_features(image, pooling=..., layers=...)
returns {"dense": (B, C, H, W), "pooled": (B, C), "grid_hw": (H, W)} — both
representations from one forward pass. ViTs and CNNs share the exact same
signature and return shape despite completely different internals.
Tasks choose pooling, backbones don't. A task passes pooling="cls" or
"mean" down into extraction. Backbones stay dumb and interchangeable; the
"what representation does this task need" decision lives in one place.
The cache is not optional. Disk-backed, keyed by
(image_hash, backbone_name, layer, pooling). Every task reads through it, so
the backbone forward pass runs at most once per image per backbone.
Documentation
| Install, first run, the CLI | Getting started |
| Backbones, datasets, dense probes, sharing | Guides |
| Every probe, its data layout and its board | The probes |
| How to read a board before quoting one | Reading a board |
| Every class, function and attribute | API reference |
| Sixteen probes against twelve backbones | LEADERBOARD.md |
| What each board means, and what it does not | CORPUS_FINDINGS.md |
| Setting up, the checks, adding a probe | CONTRIBUTING.md |
| How it was built, and what might come next | docs/roadmap.md |
| What changed, release by release | CHANGELOG.md |
| The reference, page by page | docs/probes/overview.md, docs/api/index.md |
Reproducibility
Sixteen probes against twelve backbones, as records:
LEADERBOARD.md. Every board is generated from
results/corpus/visbench.jsonl, the
committed corpus, by scripts/render_tables.py.
A test in the fast suite fails if any of them drifts, so a published number and
the run behind it cannot disagree.
Every run logs a structured JSON record — backbone, weights key, task, dataset,
pooling, feature mode, metrics, seed, timestamp — under one additive-only
schema, so leaderboard tooling never needs a retrofit. Dependencies are pinned
in uv.lock, and CI fails if it drifts from pyproject.toml.
Before quoting any board, read
how to read one. The short version: "which
backbone is best" is not a well-formed question against this corpus —
mae_vitb16 is first on six of the seventeen boards and last on four.
Prior art
VisBench reuses established protocols rather than re-deriving them, and cites them at the point of use in the code:
- probe3d (El Banani et al., CVPR 2024) — evaluation protocols for depth, surface normal and correspondence.
- Probing the Mid-level Vision Capabilities of Self-Supervised Learning (Chen, Marks & Cheng) — the task categorization used throughout.
- vismatch (Berton) — API philosophy, and the matching logic mirrored in the correspondence task.
Citing VisBench
If VisBench contributed to work you are publishing, please cite it. GitHub's Cite this repository button generates APA and BibTeX from CITATION.cff, or use:
@software{kargin_visbench,
  author  = {Kargın, Turhan Can},
  title   = {VisBench: probing vision backbones across high-, mid- and low-level tasks},
  doi     = {10.5281/zenodo.21822684},
  url     = {https://doi.org/10.5281/zenodo.21822684},
  license = {MIT},
  version = {0.12.0}
}
If you are reporting numbers, cite the version you ran. Every VisBench
result record carries the schema, the resolved pooling, the layers and the
protocol that produced it, so a number is reproducible — but only against the
release that produced it. visbench.__version__ is in every record.
The DOI above is the concept DOI: it always resolves to the newest release, which is what you want when citing the software itself. Zenodo also mints a version DOI per release, listed on the archive page under Versions — pin that one in a paper reporting measured numbers, for the same reason every record carries its schema and protocol.
License
MIT — see LICENSE.
VisBench borrows evaluation protocols from prior work, all permissively licensed and MIT-compatible; NOTICE records what came from where. Backbone weights are downloaded at runtime, never redistributed here, and carry their own upstream terms.
1 maintainer

Metadata
1 maintainer
Release files for visbench 0.17.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| visbench-0.17.0.tar.gz | 1.3 MB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| visbench-0.17.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 1.7 MB
Release files / visbench-0.17.0.tar.gz
| Download URL | visbench-0.17.0.tar.gz |
|---|---|
| Size | 1.3 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
2d41ae4e31393485630e3253b04e2e16b10993af94479f75b361103cc2457bc1
|
|
BLAKE2b-256 checksum How to use checksums |
d7195b94bfdda4aa2f79de241aa6d75ad7c955e3534c44cc843d149da9e330ec
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.12.8
|
Release files / visbench-0.17.0-py3-none-any.whl
| Download URL | visbench-0.17.0-py3-none-any.whl |
|---|---|
| Size | 407.1 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
3cd28f6ffc1a2c0948f978a14c9ff88321871e48bc531e5c9a7ff88546823292
|
|
BLAKE2b-256 checksum How to use checksums |
8daa1d2254233ec4c672093349597ed3886f48c414c5695072a2057d3e21bbe5
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.12.8
|














