


yourdfpy
Yet anOther URDF parser for Python. Yup, it's another one. Deal with it.
Yourdfpy is a simpler and easier-to-use library for loading, manipulating, validating, saving, and visualizing URDF files.
Installation
You can install yourdfpy directly from pip:
pip install yourdfpy
Visualization
Once installed, you can visualize a URDF model from the command line:
yourdfpy ./my_description/urdf/robot.urdf
You can use the following keyboard shortcuts to inspect your model:
a: Toggle rendered XYZ/RGB axis markers (off, world frame, every frame)w: Toggle wireframe mode (good for looking inside meshes, off by default)c: Toggle back face culling (on by default but in wireframe mode it is sometimes useful to see the back sides)
But why another one?!?
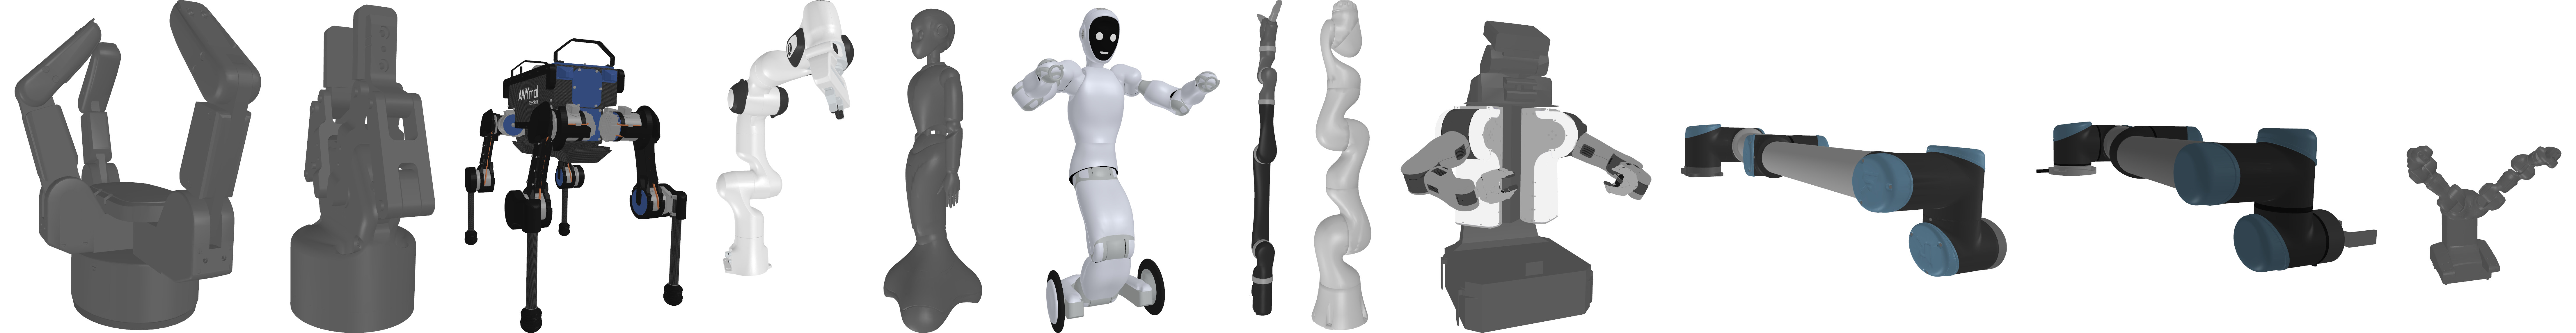
Why are you wasting not only your but also our time? you might ask. Fair point. There are already urdfpy and urdf_parser_py that deal with URDFs. Unfortunately, none of these solutions allow customizable URDF parsing that is fully independent of validation and mesh loading. Dealing with filenames, outdated dependencies, open bug reports, and limited flexibility when it comes to serialization are other disadvantages. As shown in the table below, yourdfpy is the most robust one when it comes to loading URDFs in the wild.
| urdfpy | urdf_parser_py | yourdfpy | |
|---|---|---|---|
| Decouple parsing from validation | :heavy_check_mark: | ||
| Decouple parsing from loading meshes | :heavy_check_mark: | :heavy_check_mark: | |
| Visualize URDF | :heavy_check_mark: | :heavy_check_mark: | |
| Forward Kinematics | :heavy_check_mark: | :heavy_check_mark: | |
| Robustness test: loading 12 URDF files from here | 4/12 | 6/12 | 12/12 |
| Avg. loading time per file (w/ mesh loading) | 480 ms | 370 ms | |
| (w/o mesh loading) | 3.2 ms | 6.2 ms | |
Test on 4 URDF files on which urdfpy succeeds |
347.5 ms | 203 ms | |
Test on 6 URDF files on which urdf_parser_py succeeds |
2.6 ms | 3.8 ms |
Click to expand code listing that produces the above table entries.
robot_assets = ['robot-assets/urdfs/robots/barret_hand/bhand_model.URDF', 'robot-assets/urdfs/robots/robotiq_gripper/robotiq_arg85_description.URDF', 'robot-assets/urdfs/robots/anymal/anymal.urdf', 'robot-assets/urdfs/robots/franka_panda/panda.urdf', 'robot-assets/urdfs/robots/ginger_robot/gingerurdf.urdf', 'robot-assets/urdfs/robots/halodi/eve_r3.urdf', 'robot-assets/urdfs/robots/kinova/kinova.urdf', 'robot-assets/urdfs/robots/kuka_iiwa/model.urdf', 'robot-assets/urdfs/robots/pr2/pr2.urdf', 'robot-assets/urdfs/robots/ur10/ur10_robot.urdf', 'robot-assets/urdfs/robots/ur5/ur5_gripper.urdf', 'robot-assets/urdfs/robots/yumi/yumi.urdf']

import urdfpy
import urdf_parser_py
import yourdfpy

from functools import partial

def load_urdfs(fnames, load_fn):
    results = {fname: None for fname in fnames}
    for fname in fnames:
        try:
            x = load_fn(fname)
            results[fname] = x
        except:
            print("Problems loading: ", fname)
            pass
    print(sum([1 for x, y in results.items() if y is not None]), "/", len(fnames))
    return results

# parsing success rate
load_urdfs(robot_assets, urdfpy.URDF.load)
load_urdfs(robot_assets, urdf_parser_py.urdf.URDF.load)
load_urdfs(robot_assets, yourdfpy.URDF.load)

# parsing times
%timeit load_urdfs(robot_assets, urdfpy.URDF.load)
%timeit load_urdfs(robot_assets, urdf_parser_py.urdf.URDF.load)
%timeit load_urdfs(robot_assets, yourdfpy.URDF.load)
%timeit load_urdfs(robot_assets, partial(yourdfpy.URDF.load, load_meshes=False, build_scene_graph=False))

# fairer comparison with yourdfpy
urdfpy_fnames = [x for x, y in load_urdfs(robot_assets, urdfpy.URDF.load).items() if y is not None]
%timeit load_urdfs(urdfpy_fnames, yourdfpy.URDF.load)

# fairer comparison with urdf_parser_py
urdfparser_fnames = [x for x, y in load_urdfs(robot_assets, urdf_parser_py.urdf.URDF.from_xml_file).items() if y is not None]
%timeit load_urdfs(urdfparser_fnames, functools.partial(yourdfpy.URDF.load, load_meshes=False, build_scene_graph=False))
1 maintainer

Metadata
1 maintainer
Release files for yourdfpy 0.0.60
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| yourdfpy-0.0.60.tar.gz | 538.2 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| yourdfpy-0.0.60-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 560.4 kB
Release files / yourdfpy-0.0.60.tar.gz
| Download URL | yourdfpy-0.0.60.tar.gz |
|---|---|
| Size | 538.2 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
2af2d8bdeea1b85b642590a3b4236fdb35746d7b3e38ce460a169c18d9c4f868
|
|
BLAKE2b-256 checksum How to use checksums |
ff1920c50861f30aff7720f9a601f386d73760c2df9961de1f98d0dbf3b85e69
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.2.0 CPython/3.9.25
|
Release files / yourdfpy-0.0.60-py3-none-any.whl
| Download URL | yourdfpy-0.0.60-py3-none-any.whl |
|---|---|
| Size | 22.2 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
8a187a8b18c98db87c76e9a950581b3c875b761e00df83942526c17ea693166c
|
|
BLAKE2b-256 checksum How to use checksums |
c8604ea0d6df0b497d51bf2ef87eaab0eb26f8bc3b3313c012da5df3383cced9
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/6.2.0 CPython/3.9.25
|














