
DS-MSP
Double Sphere & Multi-model Spherical-camera Platform — one interface to calibrate, convert, and reason about every wide-FOV camera model, from a single lens to a full rig.



A clean, tested, OpenCV-compatible Python platform for wide-FOV (fisheye / omnidirectional) cameras.
One interface covers calibration, model conversion, 3D geometry, multi-camera rigs, and hardware export — so you can swap camera models in a single line and convert between them without re-shooting images.
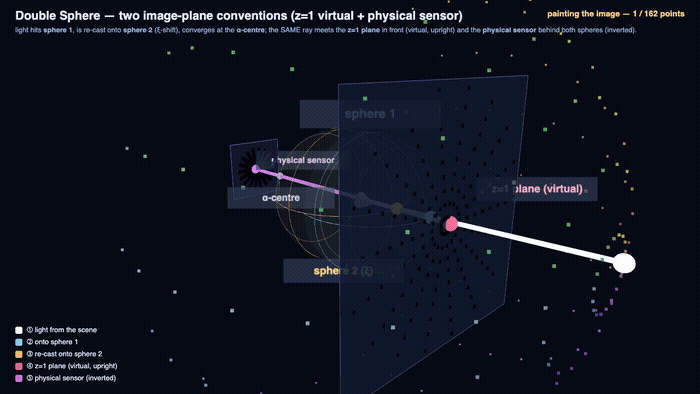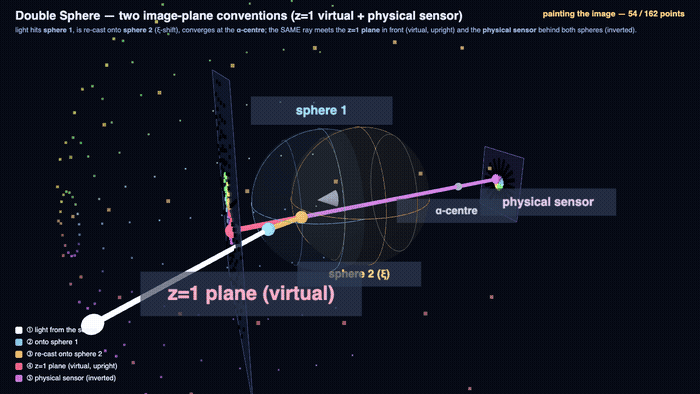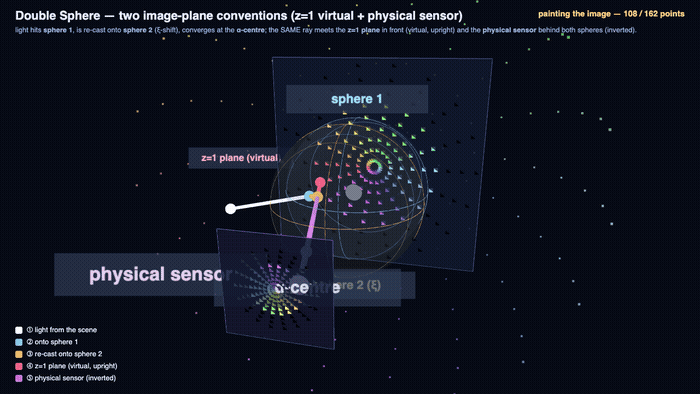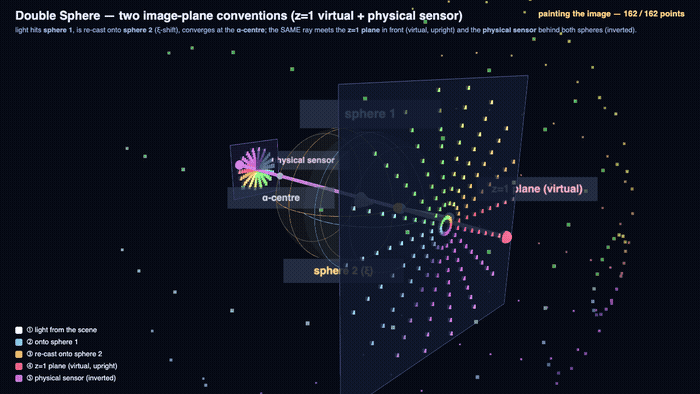
The namesake Double Sphere model in motion: each 3D point is traced through two spheres and projected to the fisheye image. Cross-checked against the library itself (
std = 2e-16). Drive it live →
Install
pip install ds-msp                 # core library
pip install "ds-msp[calib]"        # + AprilGrid detector
What do you want to do?
| Task | Recipe |
|---|---|
| Project & unproject 3D points | → Project & unproject |
Rectify a fisheye to a pinhole image (+ new K) |
→ Pinhole image & new K |
| Estimate 2D/3D pose (PnP & two-view) | → 2D/3D pose |
| Calibrate any camera from scratch | → Calibrate from scratch |
| Convert one model to another (no images, no data) | → Convert between models |
| Calibrate a multi-camera rig (any FOV) for extrinsics | → Multi-camera rig |
| Run stereo depth on raw fisheye | → Stereo depth |
| Export to TI hardware | → Hardware LDC export |
| Pick the right model | → Choosing a model |
| Learn the geometry | → Learn |
Recipes
Every recipe below is a copy-paste starting point. Each links to a fuller guide; the code uses the real API.
Project & unproject
Build any model from its intrinsics, then project 3D points to pixels and unproject pixels back to unit bearing rays — exact inverses.
Every model also exposes analytic point and parameter Jacobians (no autodiff, no finite differences), so these drop straight into bundle adjustment.
import numpy as np
from ds_msp import DoubleSphereCamera

cam = DoubleSphereCamera(fx=711.57, fy=711.24, cx=949.18, cy=518.81,
                         xi=0.183, alpha=0.809, width=1920, height=1080)

pts_3d = np.array([[0., 0., 1.], [1., 1., 2.]])
px,   ok = cam.project(pts_3d)     # (N,2) pixels + validity mask
rays, ok = cam.unproject(px)       # (N,3) unit rays (exact inverse of project)
Round-trips to ~1e-13 px. The recipes below reuse this cam. → Multi-model guide
Pinhole image & new K
Rectify a raw fisheye frame to an undistorted pinhole image and get the new pinhole intrinsics K_new for it.
The balance knob trades field of view against crop:
0.0keeps the widest FOV (more black border).1.0is the tightest crop (no border).
import cv2, ds_msp.cv as ds_cv

img = cv2.imread("frame.png")      # your raw fisheye frame

# object API — rectified pinhole image AND its new pinhole intrinsics
img_undist, K_new = cam.undistort_image(img)

# OpenCV-style equivalent, with explicit size + balance (0 = widest FOV … 1 = tightest crop)
K_new      = ds_cv.estimateNewCameraMatrixForUndistortRectify(cam.K, cam.D, (1920, 1080), balance=0.0)
img_undist = ds_cv.undistortImage(img, cam.K, cam.D, Knew=K_new)
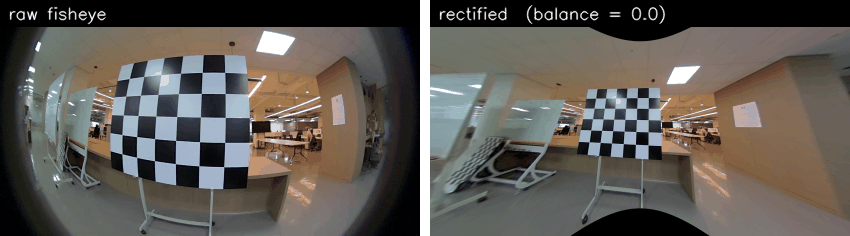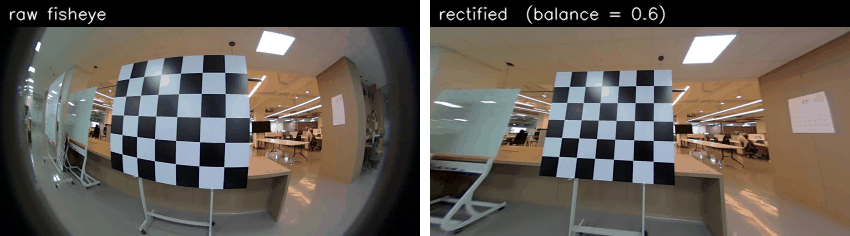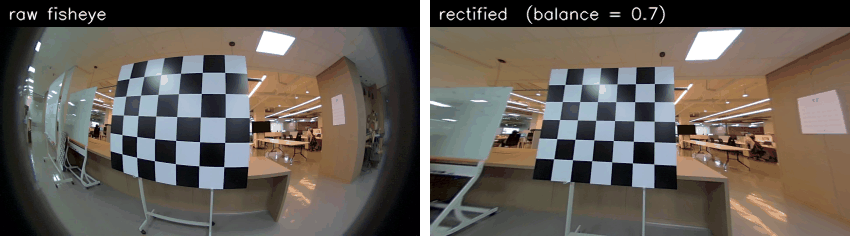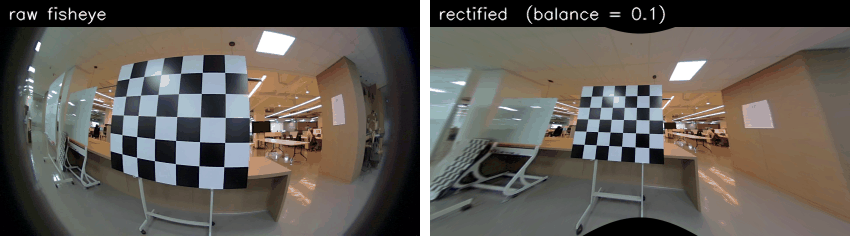
Inverse-projection error across all undistort modes is < 0.00003 px. → Multi-model guide
2D/3D pose
cam.solve_pnp unprojects pixels through whichever of the 7 models you use, then selects a
solver that matches the target geometry and visible sphere. Forward-only data uses the
standard normalized-plane cv2.solvePnP(K=I, dist=None) path. If valid rays extend past 90°,
non-coplanar targets use a bearing-vector DLT and coplanar boards use a bearing homography,
so DS / UCM / EUCM / KB / OCam / DS+ share one full-sphere API.
Warning
cv2.solvePnPonly goes wrong if you hand it raw fisheye pixels with a pinholeK— the wrong distortion model for a wide-FOV lens.cam.solve_pnpavoids that by unprojecting first.
For noisy or mismatched correspondences, solve_pnp_robust(cam, ...) is the recommended
multi-model estimator. It runs deterministic GNC-TLS directly on unit bearings, uses each model's
analytic projection Jacobian to keep the noise bound locally calibrated in pixels at wide FOV, and
returns a hard inlier mask. The legacy DoubleSphereCamera also exposes the same operation as a
convenience method.
solve_pnp_ransac(cam, ...) remains available for callers that explicitly need classic random
minimal-set consensus. On its bearing-capable path, the optional polish is full-sphere: a candidate
is kept only when it preserves support and does not worsen the truncated all-data local-pixel score.
Note With the geometry-specific bearing support available,
solve_pnp,solve_pnp_robust, andsolve_pnp_ransackeep every model-valid bearing, including peripheral correspondences past 90°. A coplanar target needs at least 4 valid points; a non-coplanar full-sphere solve needs at least 6. The clean and compatibility APIs retain a normalized-plane forward-only fallback for an undersized non-coplanar bearing set; the recommended robust API reports failure instead.
from ds_msp import relative_pose, solve_pnp_ransac, solve_pnp_robust, triangulate_rays

# 3D pose from 2D–3D correspondences (PnP), straight on raw fisheye
points_3d = ...   # (N,3) world points (from your board / detector)
points_2d = ...   # (N,2) matching fisheye pixels
ok, rvec, tvec = cam.solve_pnp(points_3d, points_2d)

# noisy matches? deterministic GNC-TLS rejects gross outliers + returns an inlier mask
ok, rvec, tvec, inliers = solve_pnp_robust(cam, points_3d, points_2d)

# compatibility path when classic RANSAC behavior is explicitly required
ok, rvec, tvec, inliers = solve_pnp_ransac(cam, points_3d, points_2d, seed=0)

# 2D–2D → relative pose + triangulated 3D points, on bearing rays
px1 = ...         # (N,2) pixels in image 1
px2 = ...         # (N,2) matching pixels in image 2
f1, _ = cam.unproject(px1)
f2, _ = cam.unproject(px2)
R, t         = relative_pose(f1, f2)           # camera-2 pose relative to camera-1
pts_3d, _, _ = triangulate_rays(f1, f2, R, t)  # (N,3) triangulated points
Measured PnP + reprojection RMS on bundled real images: 0.43 px / 0.85 px. → Two-view geometry
Calibrate from scratch
calibrate() is model-agnostic — the same call fits any of the 7 models from a generic seed; only the seed class changes.
It runs manifold Levenberg–Marquardt with analytic Jacobians and an optional robust loss (huber / cauchy); per-view poses are re-seeded internally, so a rough focal is fine.
from ds_msp.calib import calibrate
from ds_msp.models import KannalaBrandtModel        # or DoubleSphereModel, DSPlusModel, EUCMModel, …

# your detected correspondences, per frame (e.g. from cv2 / AprilGrid):
X_world    = ...   # list of (M,3) board points
keypoints  = ...   # list of (M,2) detected pixels
visibility = ...   # list of (M,) bool masks
w, h = 1920, 1080  # image size

seed = KannalaBrandtModel(fx=0.5 * w, fy=0.5 * w, cx=0.5 * w, cy=0.5 * h)   # generic seed
result = calibrate(seed, X_world, keypoints, visibility, loss="huber", f_scale=1.0)
print(result["model"], result["rms_px"])           # calibrated model + reprojection RMS
On the capstone (real TUM-VI fisheye + AprilGrid) this matches the published intrinsics to ~0.02% focal at 0.08 px median. → Calibration capstone
Just have a folder of images, no correspondences yet? ds-msp-calibrate is a real console
command from pip install ds-msp alone — detection (checkerboard / ChArUco / AprilGrid) +
calibrate() above, config-driven, same pattern as the rig CLI below:
ds-msp-calibrate --init-config calib_config.yml   # write a starter config
ds-msp-calibrate --config calib_config.yml        # detect -> bundle-adjust -> report -> save
Prints the full reprojection-error distribution (not just one RMS number) and a PASS/WARN/FAIL
verdict; ds_msp.calib.load_camera("camchain.yaml") loads the result straight back into a
ready CameraModel instance. → Single-camera calibration guide
Convert between models (no images, no data)
Translate a calibration between any two models with no images and no recalibration: DS-MSP samples the image grid, unprojects through the source model, builds a linear seed for the target, then refines on pixel reprojection.
The result agrees to sub-pixel accuracy; the design follows Fisheye-Calib-Adapter (see Credits).
from ds_msp import convert
from ds_msp.models import DoubleSphereModel, KannalaBrandtModel

# convert() takes a model (not a Camera); same DS intrinsics as `cam` above
ds = DoubleSphereModel(fx=711.57, fy=711.24, cx=949.18, cy=518.81, xi=0.183, alpha=0.809)
kb, report = convert(ds, KannalaBrandtModel, width=1920, height=1080)   # DS → OpenCV fisheye
print(report["rms_px"])            # sub-pixel agreement; no images, no recalibration
Multi-camera rig extrinsics (any FOV)
Note Shipped in
pip install ds-msp(ds_msp.rig) — validated on a real 8-camera rig and the MC-Calib Blender datasets (extrinsics within ~0.16% of ground truth).
pip install ds-mspalone gives you theds-msp-calibrate-rigcommand; no repo clone needed. A git clone can usepython scripts/calibrate_rig.pyinstead — same CLI either way.
A drop-in for MC-Calib: same calib_param.yml config schema, same output files (calibrated_cameras_data.yml, calibrated_objects_data.yml, …), interoperable both directions.
It calibrates the extrinsics (where each camera sits relative to the others) plus per-camera intrinsics from a folder of ChArUco images.
It adds one extension over MC-Calib: a different camera model per camera, so one bench can mix kb fisheye, radtan pinhole, and dsplus at any FOV.
pip install ds-msp
ds-msp-calibrate-rig --init-config calib_param.yml   # write a starter config
ds-msp-calibrate-rig --config calib_param.yml        # detect → reconstruct → bundle-adjust → MC-Calib output
Config options
- Point it at a
camera_parametersYAML withfix_intrinsic=trueto hold intrinsics fixed and solve extrinsics only. - Point it at the same YAML without that flag to refine intrinsics too.
- Omit the YAML to calibrate everything from scratch.
- If the chosen model differs from the one in the YAML, the same lens is carried into it via
convert()plus a warning.
Detected corners are saved to detected_keypoints_data.yml and reused via keypoints_path, so re-calibrating with different models takes seconds.
Measured accuracy
On the MC-Calib Blender datasets, extrinsics land within 0.16% of ground truth at sub-pixel reprojection, matching MC-Calib's own published per-camera RMS (0.92–1.07×). → Rig guide · Blender evaluation
Stereo depth
Estimate metric depth directly on raw fisheye with a sphere sweep — no rectification to pinhole, so the full wide FOV is kept.
Give the reference camera + image and the source views (each as (camera, image, R, t)), sweep a set of inverse-depth planes, and back-project to a point cloud.
from ds_msp.stereo import sphere_sweep, sweep_to_points, inverse_depth_samples

ref_cam, ref_img = cam, ...        # reference camera + its image  (... = your image)
sources = ...                      # list of (camera, image, R, t) for the other posed views
depths  = inverse_depth_samples(near=0.5, far=20.0, n=64)

depth, cost, valid = sphere_sweep(ref_cam, ref_img, sources, depths)
points = sweep_to_points(ref_cam, depth, valid)        # (N,3) metric point cloud
Hardware LDC export
Generate a TI Jacinto LDC displacement-mesh lookup table (J7 / TDA4) directly from a calibrated model:
from ds_msp.ldc import TI_LDC_MeshGenerator

res = TI_LDC_MeshGenerator(cam).generate_mesh_and_intrinsics(1920, 1080, downsample_factor=4, balance=0.5)
mesh_lut, K_new = res["mesh_lut"], res["K_new"]
Choosing a model
All 7 models live behind one CameraModel contract with analytic Jacobians, convert, and Kalibr + MC-Calib I/O.
| model | params | role |
|---|---|---|
radtan |
9 | OpenCV pinhole (Brown-Conrady); mild distortion, not a fisheye model |
kb |
8 | OpenCV fisheye (Kannala-Brandt); dependable baseline, iterative unproject |
ucm |
5 | Unified Camera Model |
eucm |
6 | Enhanced UCM |
ds |
6 | Double Sphere (Usenko 2018); exact >180° half-space validity |
dsplus |
9 | DS+ — best accuracy, closed-form-invertible, differentiable |
ocam |
10 | OCamCalib (Scaramuzza) |
Rule of thumb (directional, not a guarantee)
- ≥170° FOV → start with Double Sphere (the cheapest closed form that fits).
- ~120–150° → the spherical family (UCM/EUCM/DS) can collapse at these angles; if it does, use KB, or DS+ when you need a closed-form inverse.
- Always confirm with the median reprojection error, not the model class.
About DS+
- DS+ is the best-accuracy model tested and the only closed-form-invertible model that matches KB on hard lenses (~21% win on a demanding 158° full-FOV lens: 0.224 vs KB 0.285 px). The trade-off: its unproject is ~2× slower than KB (Ferrari quartic). Pick it when you need a differentiable / closed-form unproject with deterministic latency — not for raw throughput.
- KB stays the right default when unproject throughput rules and an iterative inverse is acceptable.
→ Choosing a model · DS+/EUCM+/KB case study (historical)
Verify it
Every claim is backed by a reproducible measurement; the live CI badge above is the authoritative suite status.
- Inverse projection (all undistort modes): mean error < 0.00003 px.
- 3D reconstruction of checkerboard corners: 0.835 mm mean; recovered 20.00 cm square (target 20.00).
- PnP + reprojection RMS on real test images: 0.43 px / 0.85 px.
- KB / RadTan vs OpenCV: agree to ~1e-13.
- Bundled DS calibration (both test views) converges to fx≈733.9, fy≈733.0, cx≈951.7, cy≈517.9, xi≈0.230, alpha≈0.817 at 0.57 px RMS. The reference intrinsics for this bundled data are fx≈711.6, xi≈0.183.
Note A single-view or two-view planar fit doesn't fully pin the DS focal/xi/alpha gauge (see are two models the same camera?). Judge the fit above by reprojection RMS, not by how closely the raw parameters match the reference.
pytest
bash verify_all.sh
python benchmarks/benchmark.py
Learn
DS-MSP doubles as a runnable curriculum in wide-FOV geometry. Every chapter in docs/learn/ prints a verifiable number — from the projection models through real calibration, model conversion, and the DS+/KB case study.
That case study openly documents a hypothesis the authors had to retract. Start at the Learn index.
Credits
DS-MSP stands on prior work, and credit stays prominent:
- Fisheye-Calib-Adapter — Sangjun Lee, arXiv:2407.12405. The conversion design and model set follow it.
- MC-Calib — Rameau, Park, Bailo, Kweon, CVIU 2022. The rig pipeline follows MC-Calib's design (config schema, result format, workflow); files interoperate both ways. Full credit to the MC-Calib authors.
- Double Sphere — Usenko, Demmel, Cremers, 3DV 2018 (arXiv:1807.08957; basalt-headers).
- Kannala-Brandt (2006), RadTan / Brown-Conrady (1966), OCamCalib (Scaramuzza), EUCM (Khomutenko et al. 2016), UCM (Geyer & Daniilidis / Mei & Rives).
- Kalibr (Furgale et al.), dscamera, and Muhammadjon Boboev (the original Python DS calibration this project grew from).
- Termynal — Ines Montani, MIT. Powers the animated terminal blocks in these docs; vendored from Typer, whose docs also inspired this site's style.
License
MIT-licensed (see LICENSING.md):
- MIT for the whole project — the generic library, the DS+ model, and the robust calibration/conversion engine.
SPDX: MIT. Please cite via CITATION.cff.
1 maintainer

Metadata
1 maintainer
Release files for ds-msp 0.14.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | Provenance | |
|---|---|---|---|---|
| ds_msp-0.14.0.tar.gz | 327.6 kB | With provenance | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| ds_msp-0.14.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 700.2 kB
Release files / ds_msp-0.14.0.tar.gz
| Download URL | ds_msp-0.14.0.tar.gz |
|---|---|
| Size | 327.6 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
058109f5d7d79b5761baa09d80d2a3b7a0a48267faeb4bb38959f845d73f0ab0
|
|
BLAKE2b-256 checksum How to use checksums |
0e02032842ade987c061acf1ed7539e6b36c070ed8cba9a9c9bc4d1b907fa7c9
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Aug 8, 2026.
Transparency logRelease files / ds_msp-0.14.0-py3-none-any.whl
| Download URL | ds_msp-0.14.0-py3-none-any.whl |
|---|---|
| Size | 372.7 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
ed7d57c92d0fc0c9c4a558ef47c5dd0a4a1e3776a10f11c797a096e5b0461a61
|
|
BLAKE2b-256 checksum How to use checksums |
552152aea1971dec6fe2ae8664c4d6b67c2e31eded26bb1caa8133eec0cf24f5
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Aug 8, 2026.
Transparency logSecurity for ds-msp 0.14.0
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
Full provenance
All 2 files in this release have been uploaded with provenance metadata.
Attestation for ds_msp-0.14.0.tar.gz
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Aug 8, 2026.
Transparency logA note on package security
PyPI is a repository for distributing packages, not a service for auditing them. While third-party security researchers and our staff do their best to detect and remove malicious packages, PyPI cannot guarantee the quality, security or suitability of any given package.
To learn more about protecting yourself from malicious actors, visit our package security documentation.














