

Free Energy Landscape Analysis
Builds the free energy landscape of a molecular dynamics simulation from two collective variables, finds its metastable states, and gives you a representative frame for each one.
Input is two text files of frame value. Output is five figures, an animation and two tables.
Install
pip install free-energy-landscape
Requires Python 3.10 or newer; tested through 3.14.
Usage
free_energy_landscape cv1.txt cv2.txt --names "CV1 (Angle)" "CV2 (Distance)"
Every figure below was produced by that same command run on the two files in inputs/:
free_energy_landscape inputs/proj1Out.txt inputs/proj2Out.txt --names "CV1 (Angle)" "CV2 (Distance)"
Everything else is default. The run is deterministic — no seed, no k, no initialisation — so the
same input gives byte-identical output on any machine and for any number of cores.
Each CV file is two columns, frame index and CV value. Both must describe the same trajectory: same number of rows, same frame index on every row. See docs/OPTIONS.md for every command-line flag.
Theoretical background
The free energy landscape is a conceptual and computational tool used to understand the energetics and dynamics of molecular systems. It is particularly useful for interpreting molecular dynamics simulations, where it condenses a trajectory of millions of coordinates into the energetics of the processes the system actually undergoes: protein folding, chemical reactions, and phase transitions.
Collective variables (CVs) are the coordinates that make this possible. They reduce the full set of atomic coordinates to the few degrees of freedom that matter — a principal component, a distance, an angle, a dihedral — so the state of the system can be described by a handful of numbers.
How it works
1. Density. A Gaussian kernel density estimate turns the frames, one point each in the 2D CV
space, into a smooth probability density f on a regular grid. One kernel is fitted over the whole
trajectory; parallelism splits only its evaluation.
2. Free energy. Boltzmann inversion, shifted so the global minimum sits at zero:
G = -kB · T · ln f then G <- G - min G
3. Sampling mask. A kernel estimate returns a number even where no frame exists, and that number is extrapolation, not measurement. A cell counts as sampled only when the estimate expects at least one frame inside it:
f(cell) · area(cell) · N >= mask_min_count (default 1 frame)
The rest is left out of the analysis and of the colour scale.
4. Steepest descent. Each cell points at its lowest neighbour among the eight surrounding it, or at itself if none is lower. Following those pointers to their fixed point gives the local minimum each cell drains into — its basin of attraction, which is the operational definition of a metastable state.
5. Saddles. Neighbouring basins meet along a ridge. The saddle between them is the lowest point of that ridge, the cheapest way across:
saddle(A,B) =   min      max( G(x), G(y) )
              x in A
              y in B
              adjacent
6. Depth. How far a basin must climb to escape — its topological persistence:
depth(A) =  min saddle(A,B)  -  min  G(x)
             B                 x in A
7. Merging. Basins shallower than the cut are absorbed by the neighbour across their lowest
saddle. The cut is chosen at the largest step in the sorted depths, where real structure and
estimator ripple separate, and never exceeds kB·T. What it chose and what it merged is printed
on every run:
Watershed found 12 local minima; --basin_min_depth 1.01 kJ/mol (auto) merged 7 of them.
Barrier depths (deepest first): 2.10, 1.81, 1.59, 1.43, 1.41, 0.61, 0.47, 0.27, 0.17, ...
Largest step is 1.41 -> 0.61 kJ/mol: --basin_min_depth between them keeps 6 basins.
8. Representatives. Each frame inherits the basin of its cell. The representative of a basin is the frame of lowest free energy inside it — an actual conformation, ready to extract from the trajectory.
Result
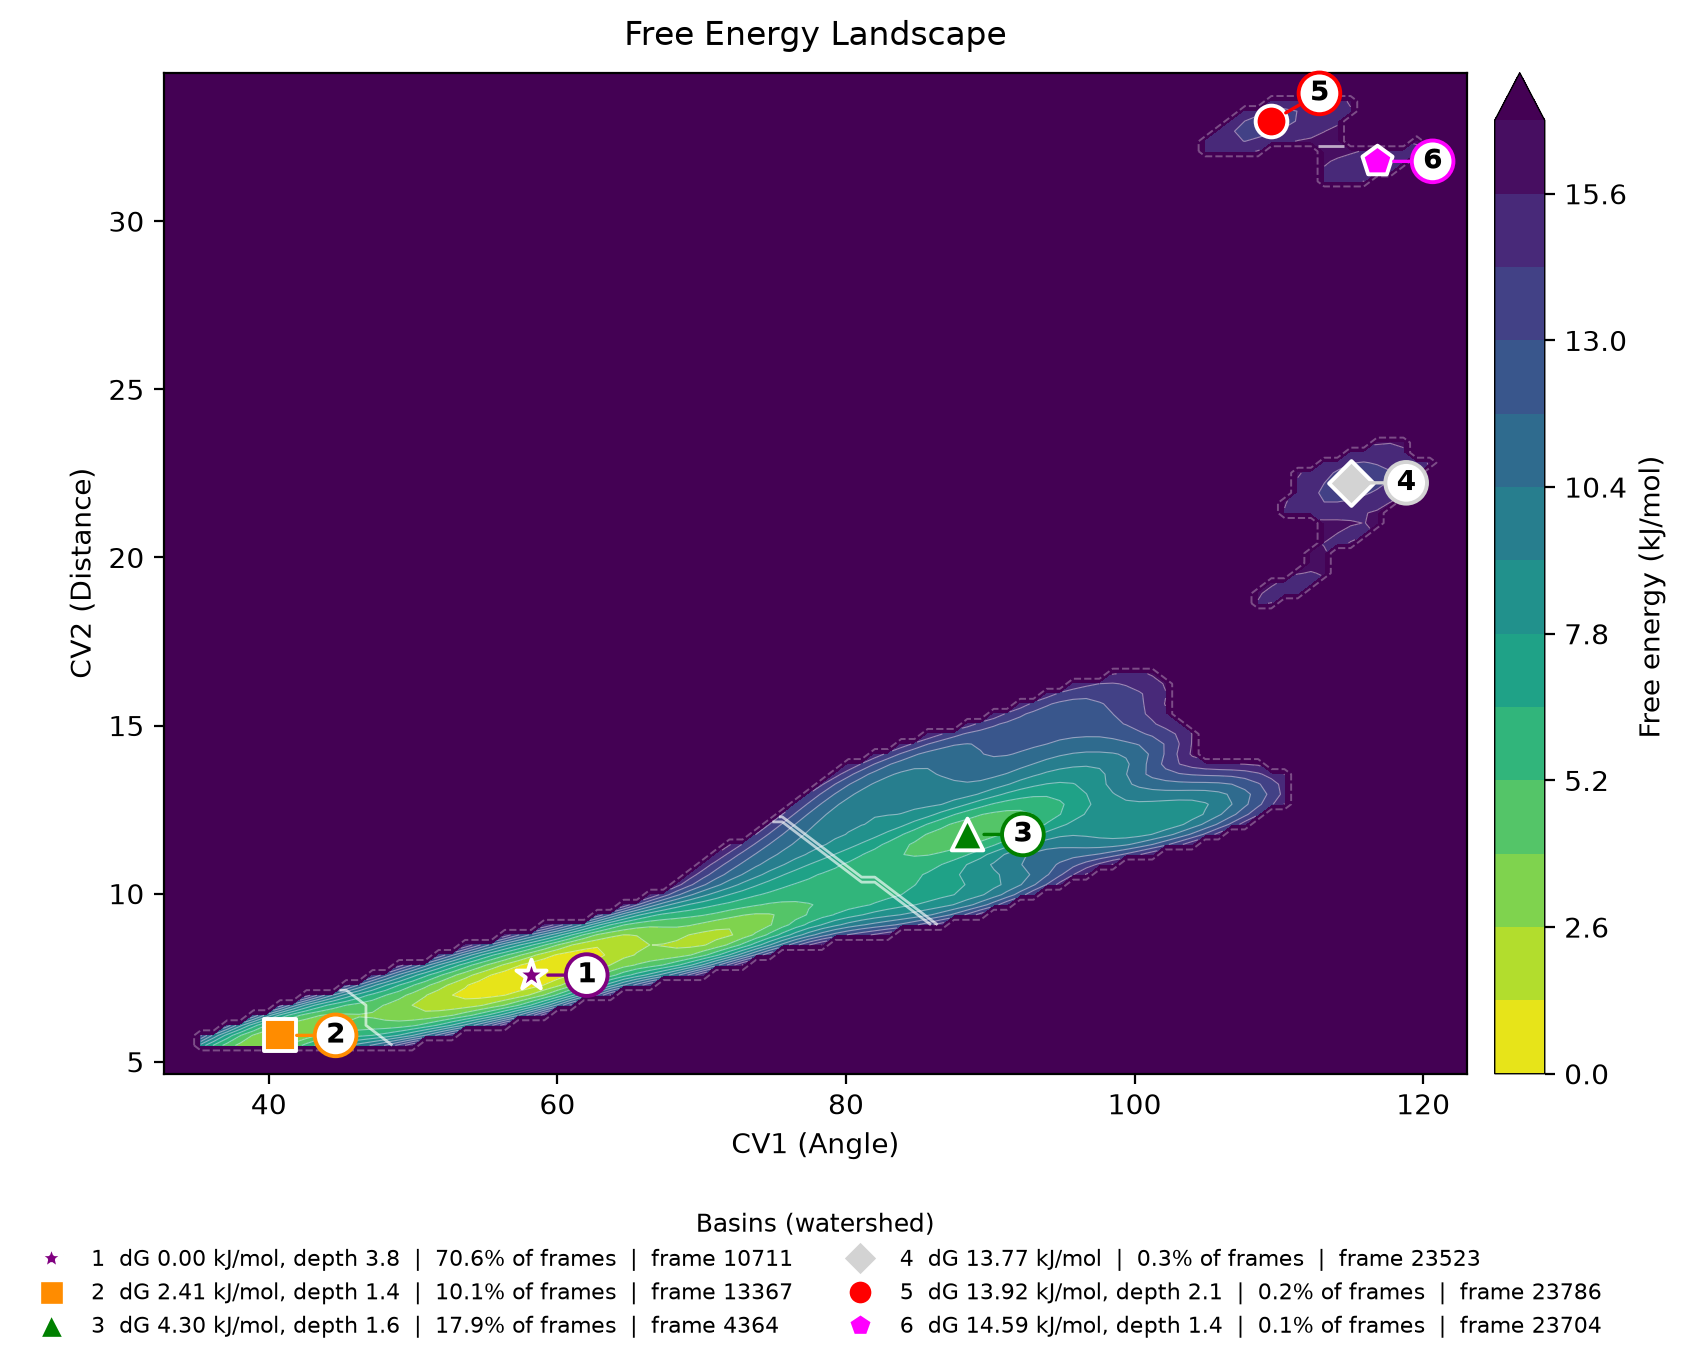
The two collective variables combined. Bright is low energy, dark is high; the region beyond the dashed line was never sampled, so no energy is claimed there. White lines are the watershed ridges separating basins, and each numbered callout marks a basin minimum — the legend gives its depth, its share of the trajectory, and its representative frame.
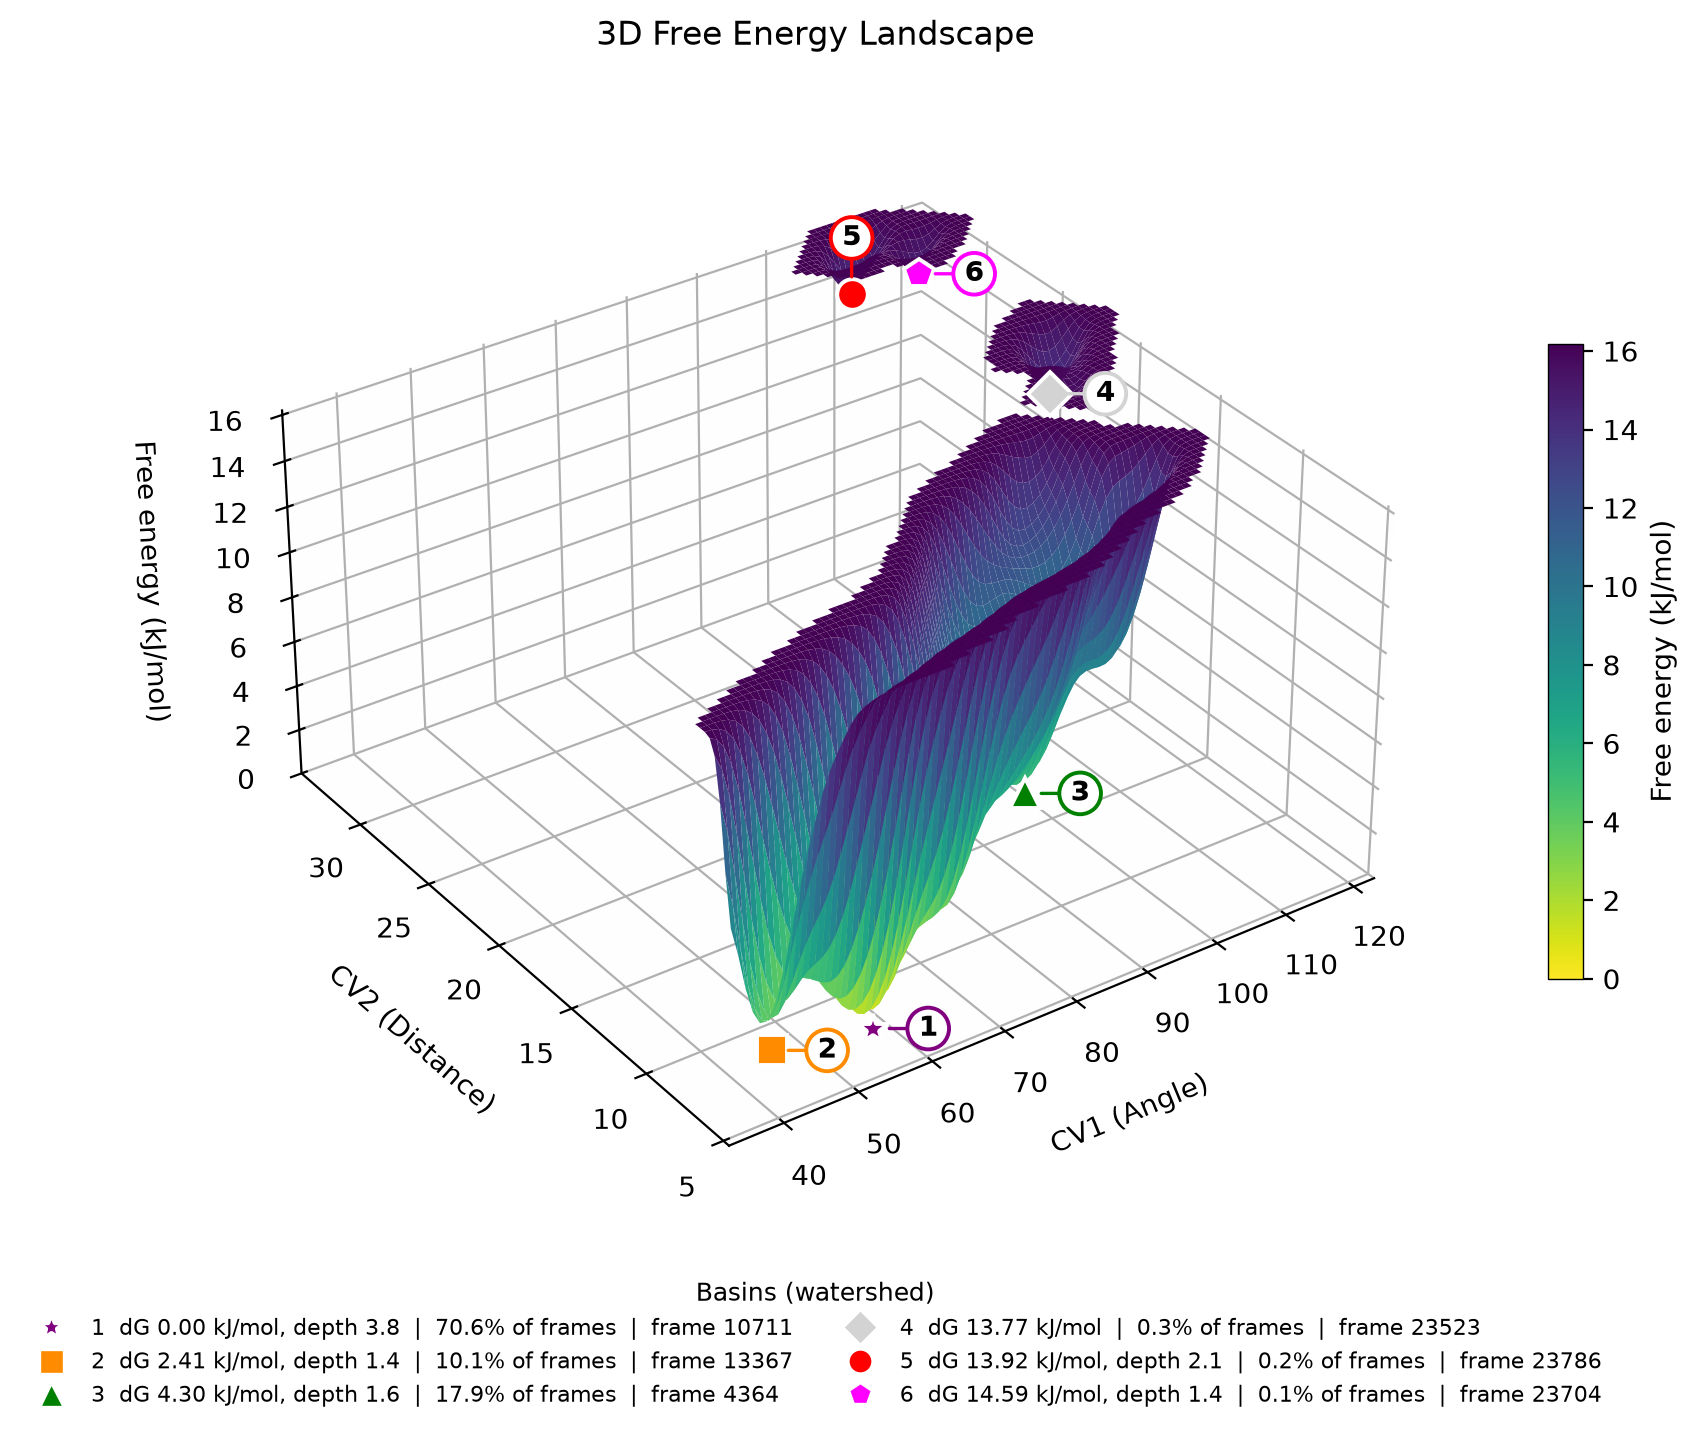
The same surface as relief, which makes the depth of each basin and the height of the barriers between them directly comparable.
The run also writes the free energy profile and distribution of each CV separately, both CVs against frame number, and a rotating animation of the 3D surface — all six are described in docs/FIGURES.md.
Tables
basins.tsv — one row per metastable state:
  #        CV1        CV2       dG    depth   frames    pop%  rep frame
-----------------------------------------------------------------------
  1     58.181      7.578     0.00     3.82    36447   70.58      10711
  2     40.777      5.786     2.41     1.41     5201   10.07      13367
  3     88.408     11.761     4.30     1.59     9263   17.94       4364
  4    114.971     22.219    13.77        -      164    0.32      23523
  5    109.475     32.975    13.92     2.10       98    0.19      23786
  6    116.803     31.780    14.59     1.43       43    0.08      23704
dG is the basin minimum relative to the global minimum, depth how far it must climb to reach a neighbour, pop% its share of the trajectory, and rep frame the conformation to extract. A dash under depth means the basin has no neighbour: it sits on its own island of sampled space.
discrete_values_energy_frames.tsv — every frame with its energy and basin id, sorted by energy.
Documentation
- docs/METHOD.md — the method in full, with a worked example and the reasoning behind each choice
- docs/FIGURES.md — all six figures, with what each axis means
- docs/OPTIONS.md — every command-line flag, input format, output files
- CHANGELOG.md — what changed in 2.0.0 and why results differ from 1.x
1 maintainer

Metadata
1 maintainer
Release files for free-energy-landscape 2.0.1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| free_energy_landscape-2.0.1.tar.gz | 38.0 kB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| free_energy_landscape-2.0.1-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 66.3 kB
Release files / free_energy_landscape-2.0.1.tar.gz
| Download URL | free_energy_landscape-2.0.1.tar.gz |
|---|---|
| Size | 38.0 kB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
4ae8423b2a68a4defc00ca939b8c48a169582de4b235ea9f3dd97670096b1b3c
|
|
BLAKE2b-256 checksum How to use checksums |
25a9cfabd395a2c1d68e7a2764073a71999c11c0b6fb096b5f674de11f456775
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Aug 15, 2026.
Transparency logRelease files / free_energy_landscape-2.0.1-py3-none-any.whl
| Download URL | free_energy_landscape-2.0.1-py3-none-any.whl |
|---|---|
| Size | 28.3 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
0ade7dc21185e427564bbfaa493142a6d7d670a76d9b465f7ead124c817f8ec6
|
|
BLAKE2b-256 checksum How to use checksums |
79bba530df5c03a4da4137e350f2c47cfb4c44d73804912c07c8f5218488625e
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Aug 15, 2026.
Transparency log













