
Fullseye


Documentation: furuse.work — the operator index (3,083
operators in the machine-readable index, docs/OP_INDEX.json: 936 single-input 2-D operators +
17 n-ary + 2,130 in the typed ledgers, each with a per-operator note), the family guides, and the
release notes.
What it can do: CAPABILITIES.md — an index organised by what you want to do, every entry tied to operators that exist and an example that runs. What the PoCs hardened: HARDENING.md — the ledger of defects the PoC series found, what changed, and which gate now stops each one coming back.
Real-hardware and real-data results wanted. Fullseye is developed without physical measurement rigs, so it is validated against virtual optical systems and simulated ground truth. Results from real hardware or real data are very welcome — your data does not have to be shared: results-only reports are accepted, and
python -m fullseye.validation_kitwrites only aggregate numbers from your local data. Report form · Discussions › Show and tell · how reports are judged
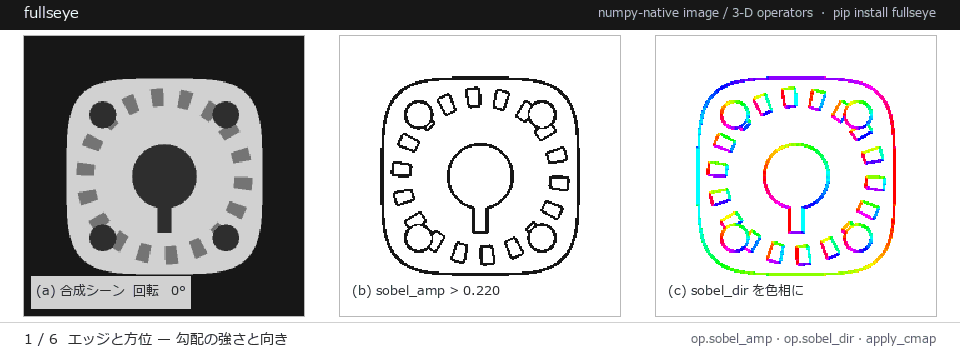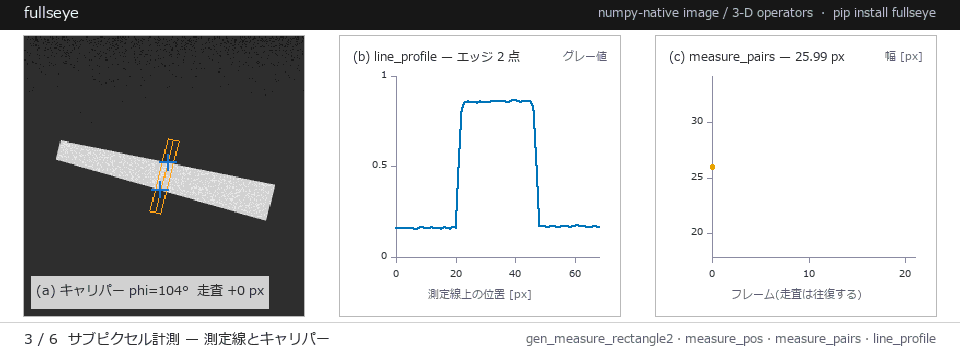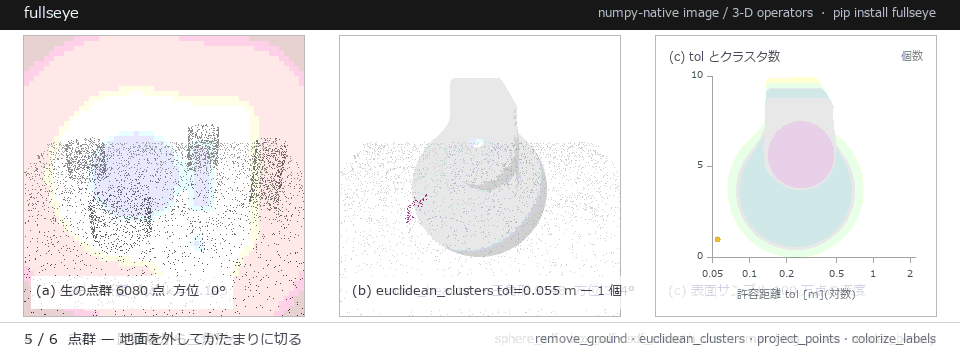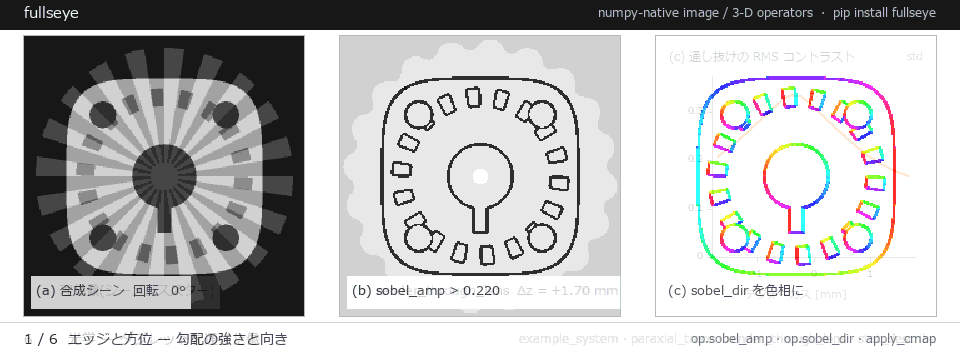
Every frame is real operator output — no mockups. 960x360, 13.5 s, regenerated by tools/gen_hero_gif.py.
An in-house, numpy-native image-processing operator library and evolutionary pipeline designer. Every operator is reimplemented from published algorithms and open-source libraries (OpenCV, scikit-image, SciPy, Pillow, PyWavelets, SimpleITK, mahotas, kornia/torch), given a single typed interface, and contract-tested (finite, deterministic, sort-typed). On top of the operators sits an evolutionary search that designs pipelines and gates them honestly on a held-out set.
Two ways to use it: apply known operators (most of the time), or evolve a new
pipeline when no single operator solves the task. It is pip-installable and works
on plain numpy arrays, so other projects can drop it into a vision pipeline directly.
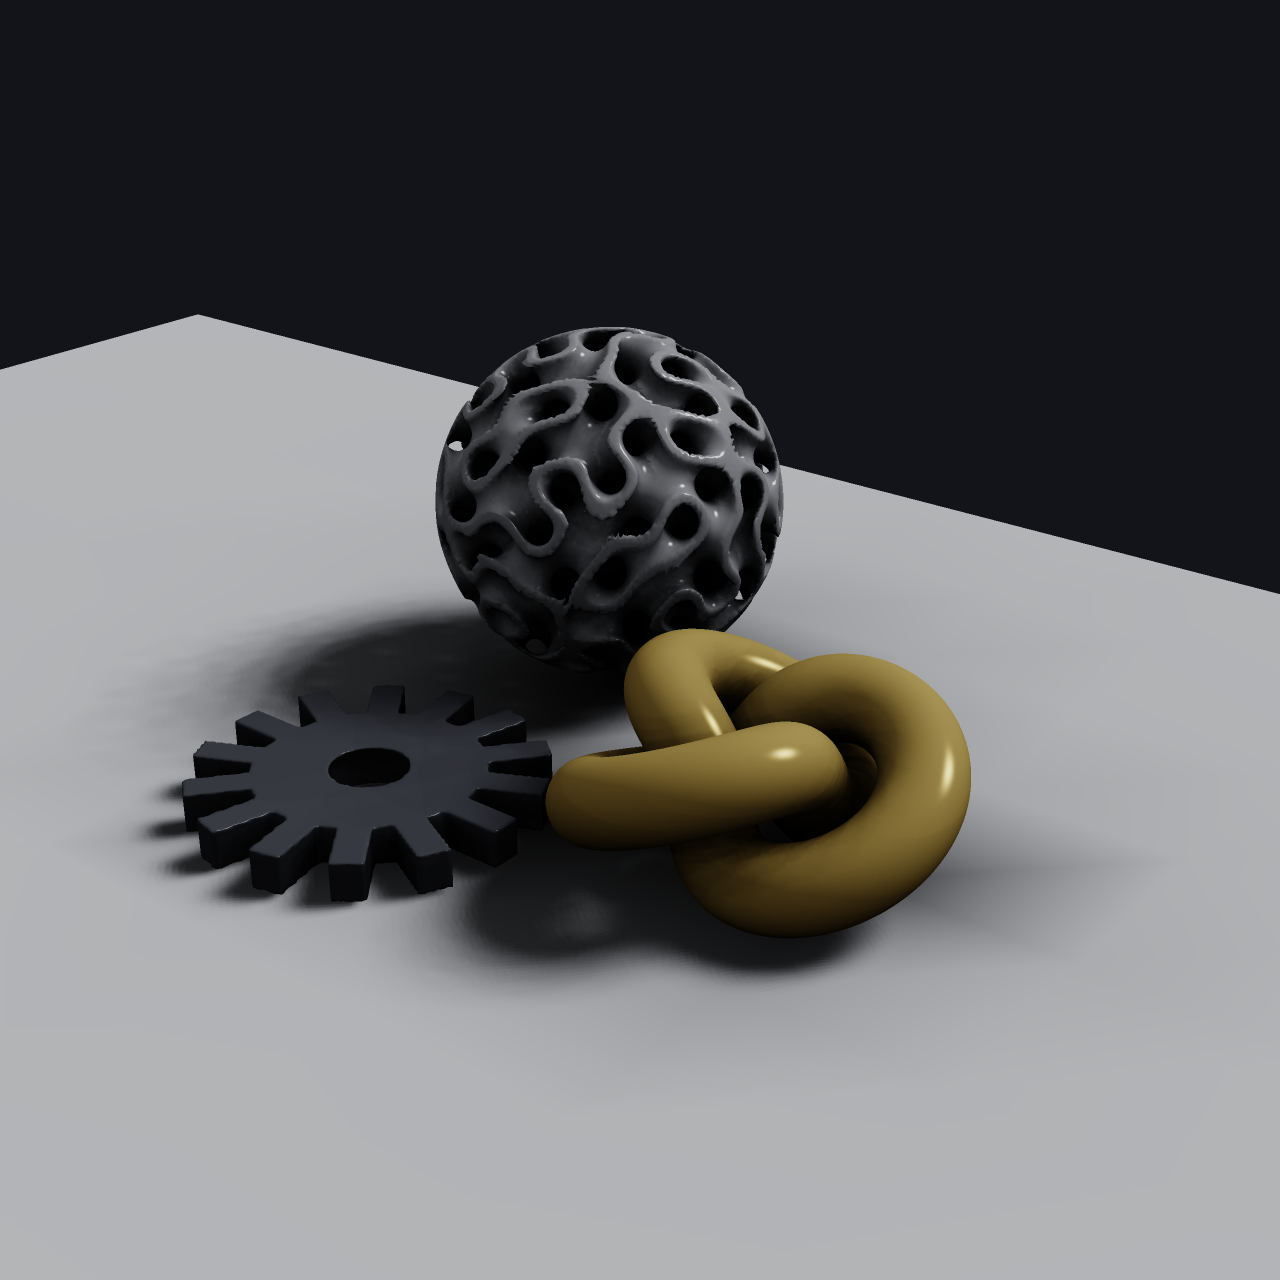
Rendered by Fullseye's numpy renderer (SDF → marching cubes → AO / soft shadows / ACES). More real outputs below.
New here? Read the full introduction. A single long-form article walks through the whole system — the three layers, the Studio IDE, the honest-evaluation discipline, and 151 worked exhibits, all illustrated with real operator output. English · 日本語
Three ways in
Fullseye is wide; the hard part is picking the first file to open. These are not new demos — every command below is an example a gate already runs on each push, so if one of them breaks, CI goes red.
| Course | For | Run this first (5 min) | Then read (30 min) |
|---|---|---|---|
| Explainable inspection | inspection / QA engineers | py -3.11 examples/poc_solder_fillet_aoi.py — solder-fillet AOI |
examples/poc_fabric_defect.py — misses and false alarms counted separately |
| 3-D vision for robotics | robotics / 3-D metrology | py -3.11 examples/perception_pipeline.py — stereo → depth → point cloud → traversability |
examples/grasp_pose.py — register a cloud to a model, get 6-DoF pose and approach |
| Physics-based NDT | X-ray / optics / measurement | py -3.11 examples/ct_reconstruction.py — projections → reconstruction → dimensions in mm and a void count |
examples/poc_ct_void_morphology.py — why one pass/fail number is blind to shape |
Every one of them carries a ground truth and prints the null (do-nothing) result beside
the method. How far each capability is actually verified is a generated ledger:
docs/MATURITY.md.
Two more doors, both new since 0.1.11 and both honest about their limits:
| Door | For | Run this first | Status |
|---|---|---|---|
| From an LLM (MCP) | Claude Code / Claude Desktop users | py -3.11 -m fullseye.mcp --demo — search an op, read its note, load a sample, run a pipeline, get a verdict |
PoC. 9 tools, strict by default, runs from the wheel (the catalog index and the notes' front matter ship as package data; note bodies fall back to the shipped help HTML). docs/MCP.md |
From C / C++ / C# / Lua (and Python ctypes) |
embedding into an existing product | cargo build --release in rust/fullseye_core, then one example per language in rust/fullseye_core/examples/ — all four print the same five lines |
A C ABI (fullseye_abi.h) with one generic entry point, fs_apply, that reaches the whole 2-D registry (936 single-input operators, by name + JSON parameters; 0.2.0, the registry runs in an embedded CPython, cargo build --features embed — the 17 n-ary 2-D operators and the 1,049 typed-ledger operators, whose inputs are not one image or region, are refused with a reason, not yet routed), plus a 5-operator contract that also has a native Rust route. The contract's job is to find specification bugs by being a second implementation (nine found so far); fs_apply always reports which route ran |
Install
pip install fullseye        # PyPI (numpy + scipy core)
pip install "fullseye[all]" # + opencv, scikit-image, Pillow, PyWavelets, SimpleITK, kornia/torch, PySide6
# from a checkout: pip install -e .   (per-backend extras: .[opencv] .[skimage] .[gpu] ...)
PyPI: https://pypi.org/project/fullseye/ · Source / issues / operator corpus:
GitHub (linked from the PyPI sidebar). After installing, fullseye-rag sets up the
Claude Code RAG skill; py -3.11 tools/update_fullseye.py updates a checkout without
touching your environment (see docs/AI_RAG_GUIDE.md).
Only numpy and scipy are required; every other backend is optional and only its own operators are affected when it is absent (graceful degradation). GPU is opt-in.
Quickstart (programmatic API)
import fullseye, numpy as np

frame = np.asarray(img, np.float64)                 # gray H×W in [0,1] (H×W×3 for color)
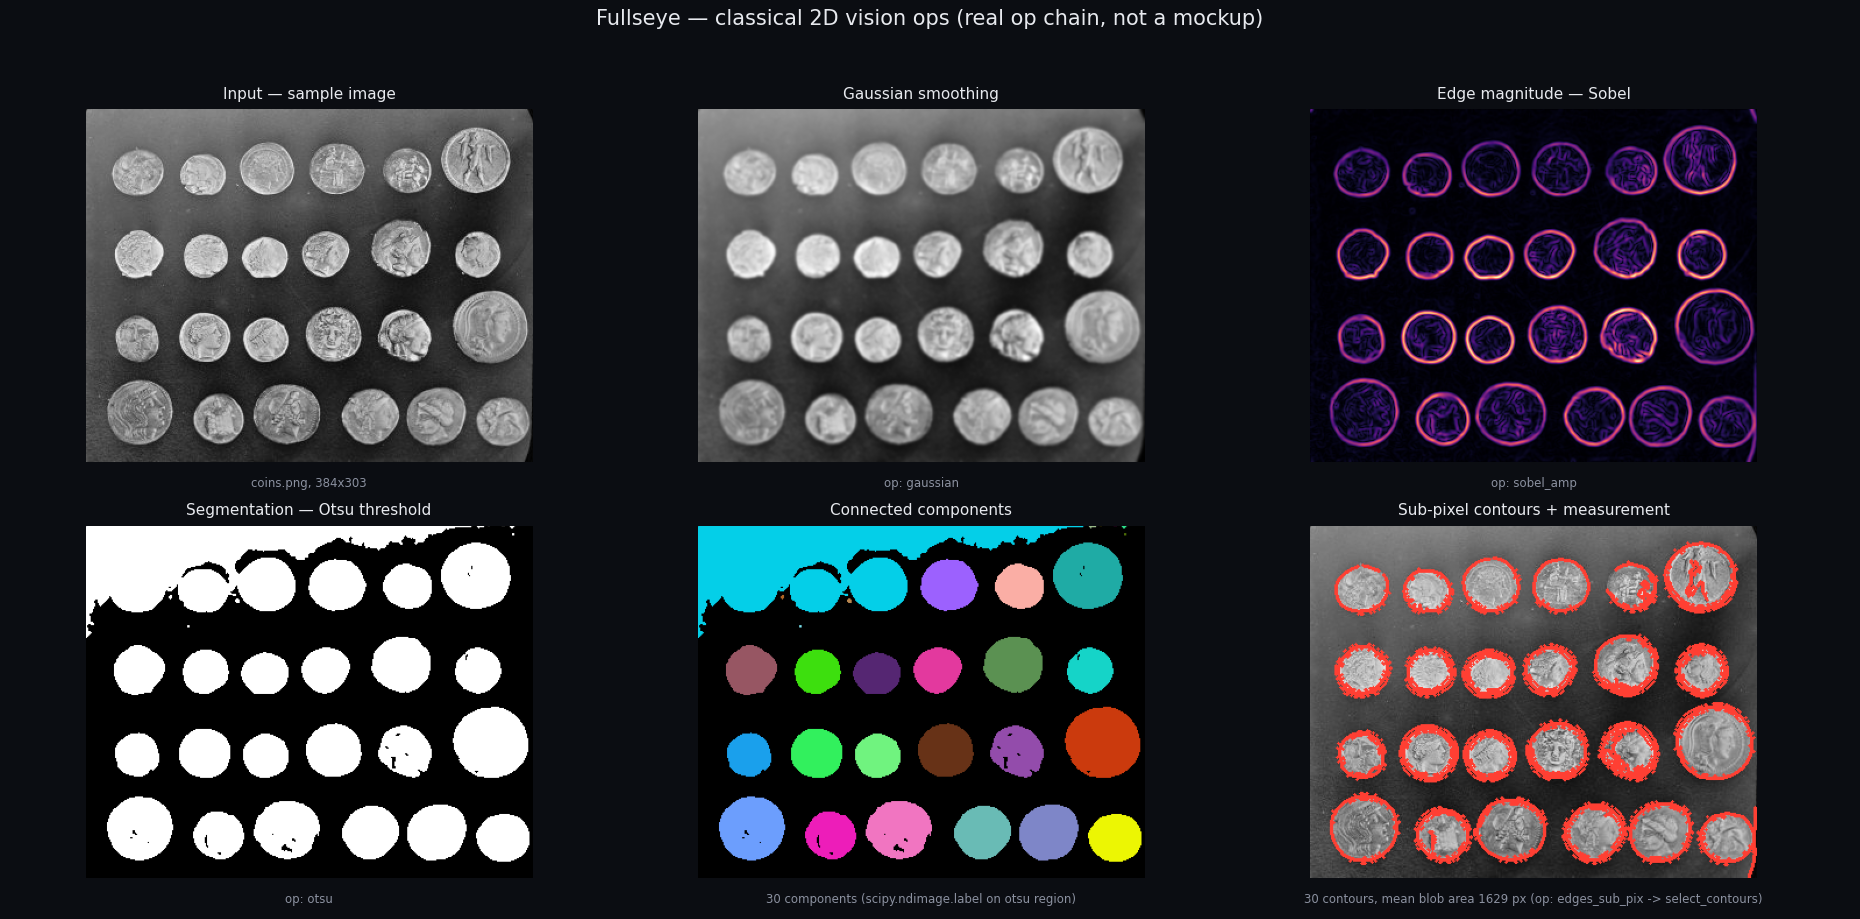
edges = fullseye.apply(frame, "sobel_amp")          # numpy in, numpy out
seg   = fullseye.apply(frame, "otsu")               # image → region (binary {0,1})
n     = fullseye.apply(seg,   "count_obj")          # region → feature → a float
out   = fullseye.run_pipeline(frame, ["gaussian", "sobel_amp", "otsu"])          # shared knobs
out   = fullseye.run_pipeline(frame, [("gaussian",0.3,0.5), ("otsu",0.4,0.5)])   # per-stage knobs
fullseye.list_ops(sort="region"); fullseye.op_names()   # discover
fullseye.apply([a, b], "add_image")                      # n-ary ops take a LIST of inputs
fullseye.apply(img, "ncc_locate", template=patch)        # match ops take the template here
fullseye.apply(frame, "otsu", on_error="raise")          # fail-closed (default: sort-valid fallback,
fullseye.fallbacks()                                     #   recorded + one warning per op)
Argument order is
apply(image, name, a, b)— array first, op name second. Swapped arguments raiseTypeError: ... arguments look swapped(0.1.9+).
apply(image, name, a=0.5, b=0.5) and run_pipeline take an operator name and two
knobs in [0, 1]. Feature operators return a Python float; contour operators a dict.
Operator library
3,083 typed operators (953 2-D in the registry, 17 of them n-ary, + 2,130 in the typed ledgers,
the 3-D ledger among them), covering denoising, smoothing, sharpening,
thresholding/segmentation, morphology, edge/corner/blob detection, distance
transforms, color-space conversion, texture/shape features, contours, and the 3-D
modality (point clouds / meshes / volumes / SDF / 6-DoF pose). Sorts: image (gray
[0,1]), color (RGB), region (binary), feature (scalar), contour, volume.
Every operator carries a machine-readable Markdown note under docs/ops/
(call form, type contract, HALCON counterpart, references, author/license/version
fingerprint) — a single source of truth that generates the Studio help pages and
doubles as a retrieval (RAG) corpus for AI coding assistants: an agent such as
Claude Code can look up operators by contract, chain them by sort, and inspect every
intermediate result. One command installs the bundled Claude Code skill and pins the
corpus path (py -3.11 tools/setup_claude_rag.py — see docs/AI_RAG_GUIDE.md).
Coverage against HALCON's 2313 operators is measured, not asserted
(py -3.11 imgevolve.py coverage).
py -3.11 imgevolve.py ops --search edge      # search implemented operators
py -3.11 imgevolve.py apply gaussian in.png out.png --a 0.6
py -3.11 imgevolve.py pipeline in.png out.png --ops "gaussian,sobel_amp,otsu"
py -3.11 imgevolve.py coverage               # honest coverage numbers
Adding one operator makes evolution, code generation, the catalog, and the
machine-readable index (docs/OP_INDEX.json) follow automatically.
Perception stack (robotics-friendly)
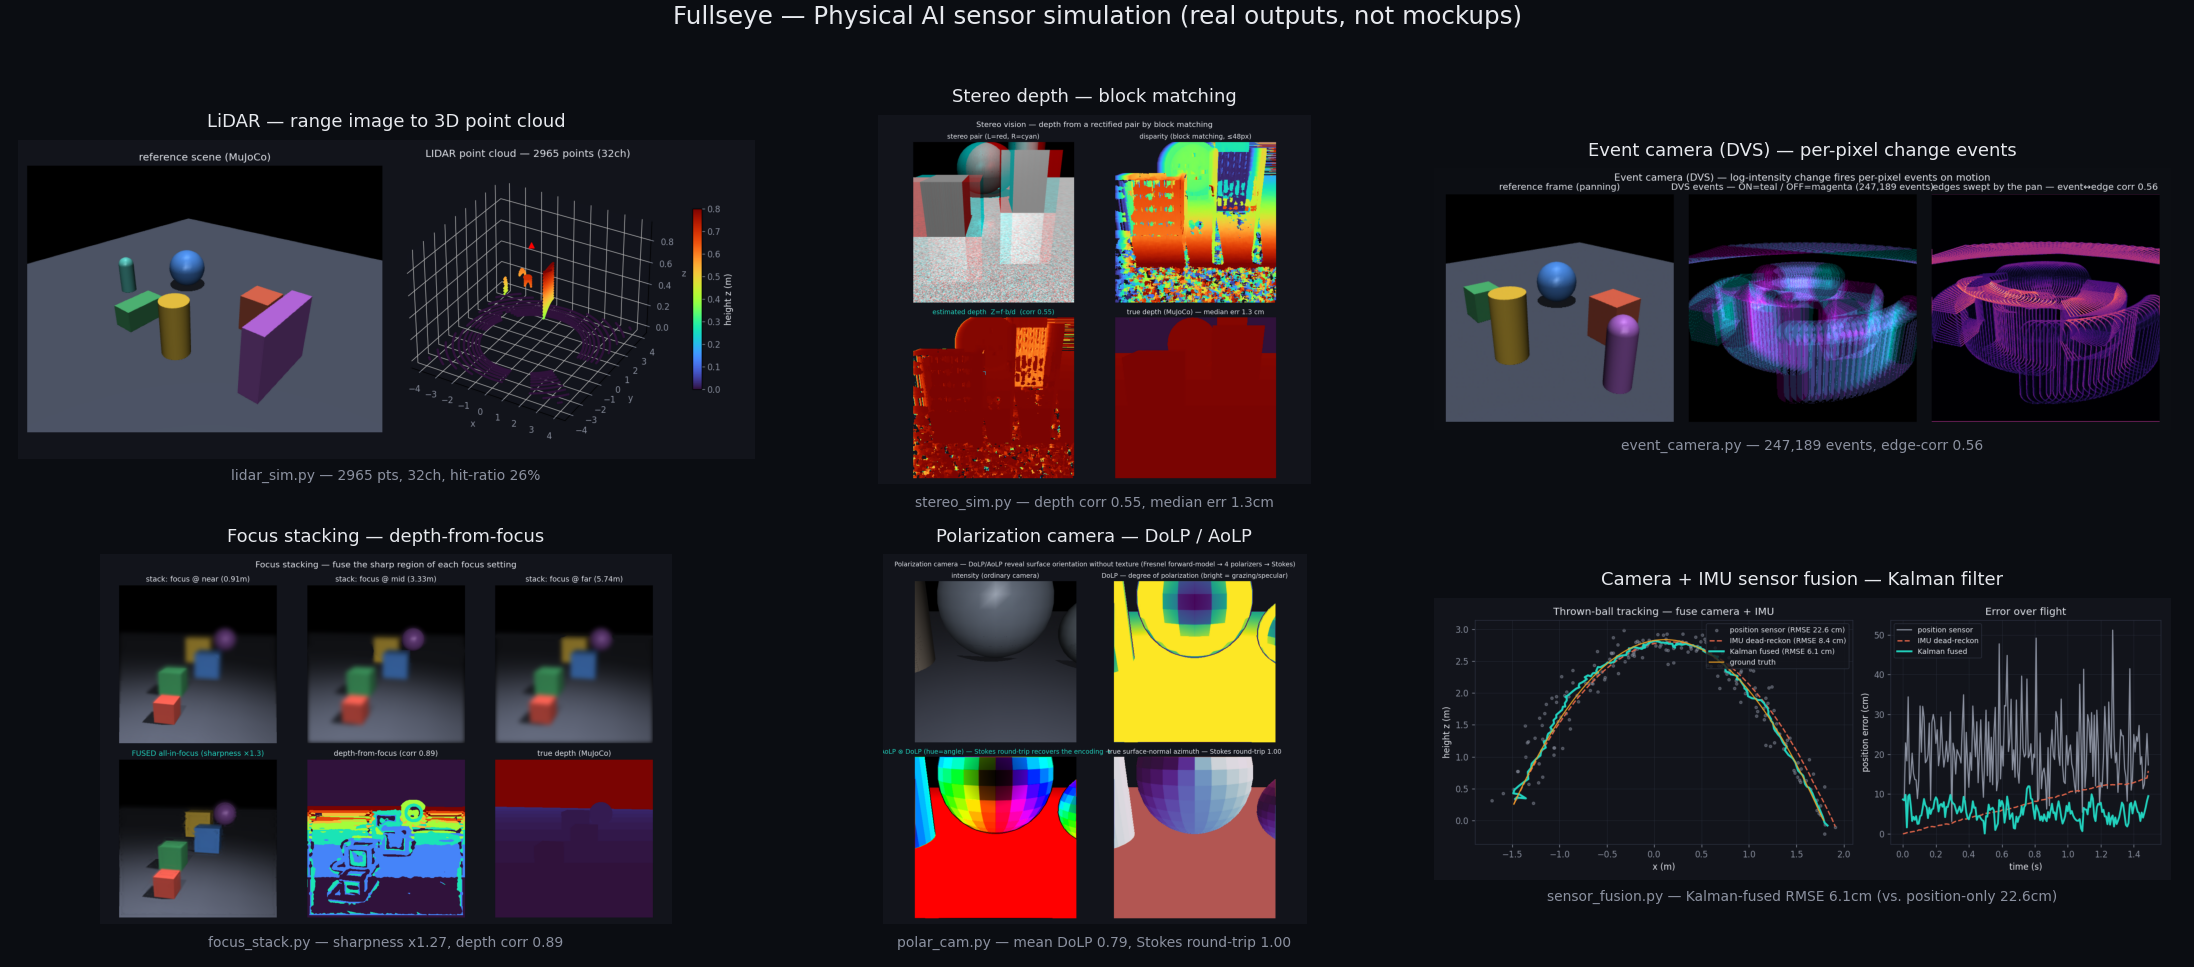
Building blocks that turn frames into geometry and objects — the pieces a robot needs to perceive, measure, and act. A sensor-simulation suite (pseudo-LiDAR, stereo, event camera / DVS, photometric stereo, TSDF fusion, polarization, focus stacking) lets you develop and test perception pipelines without hardware:
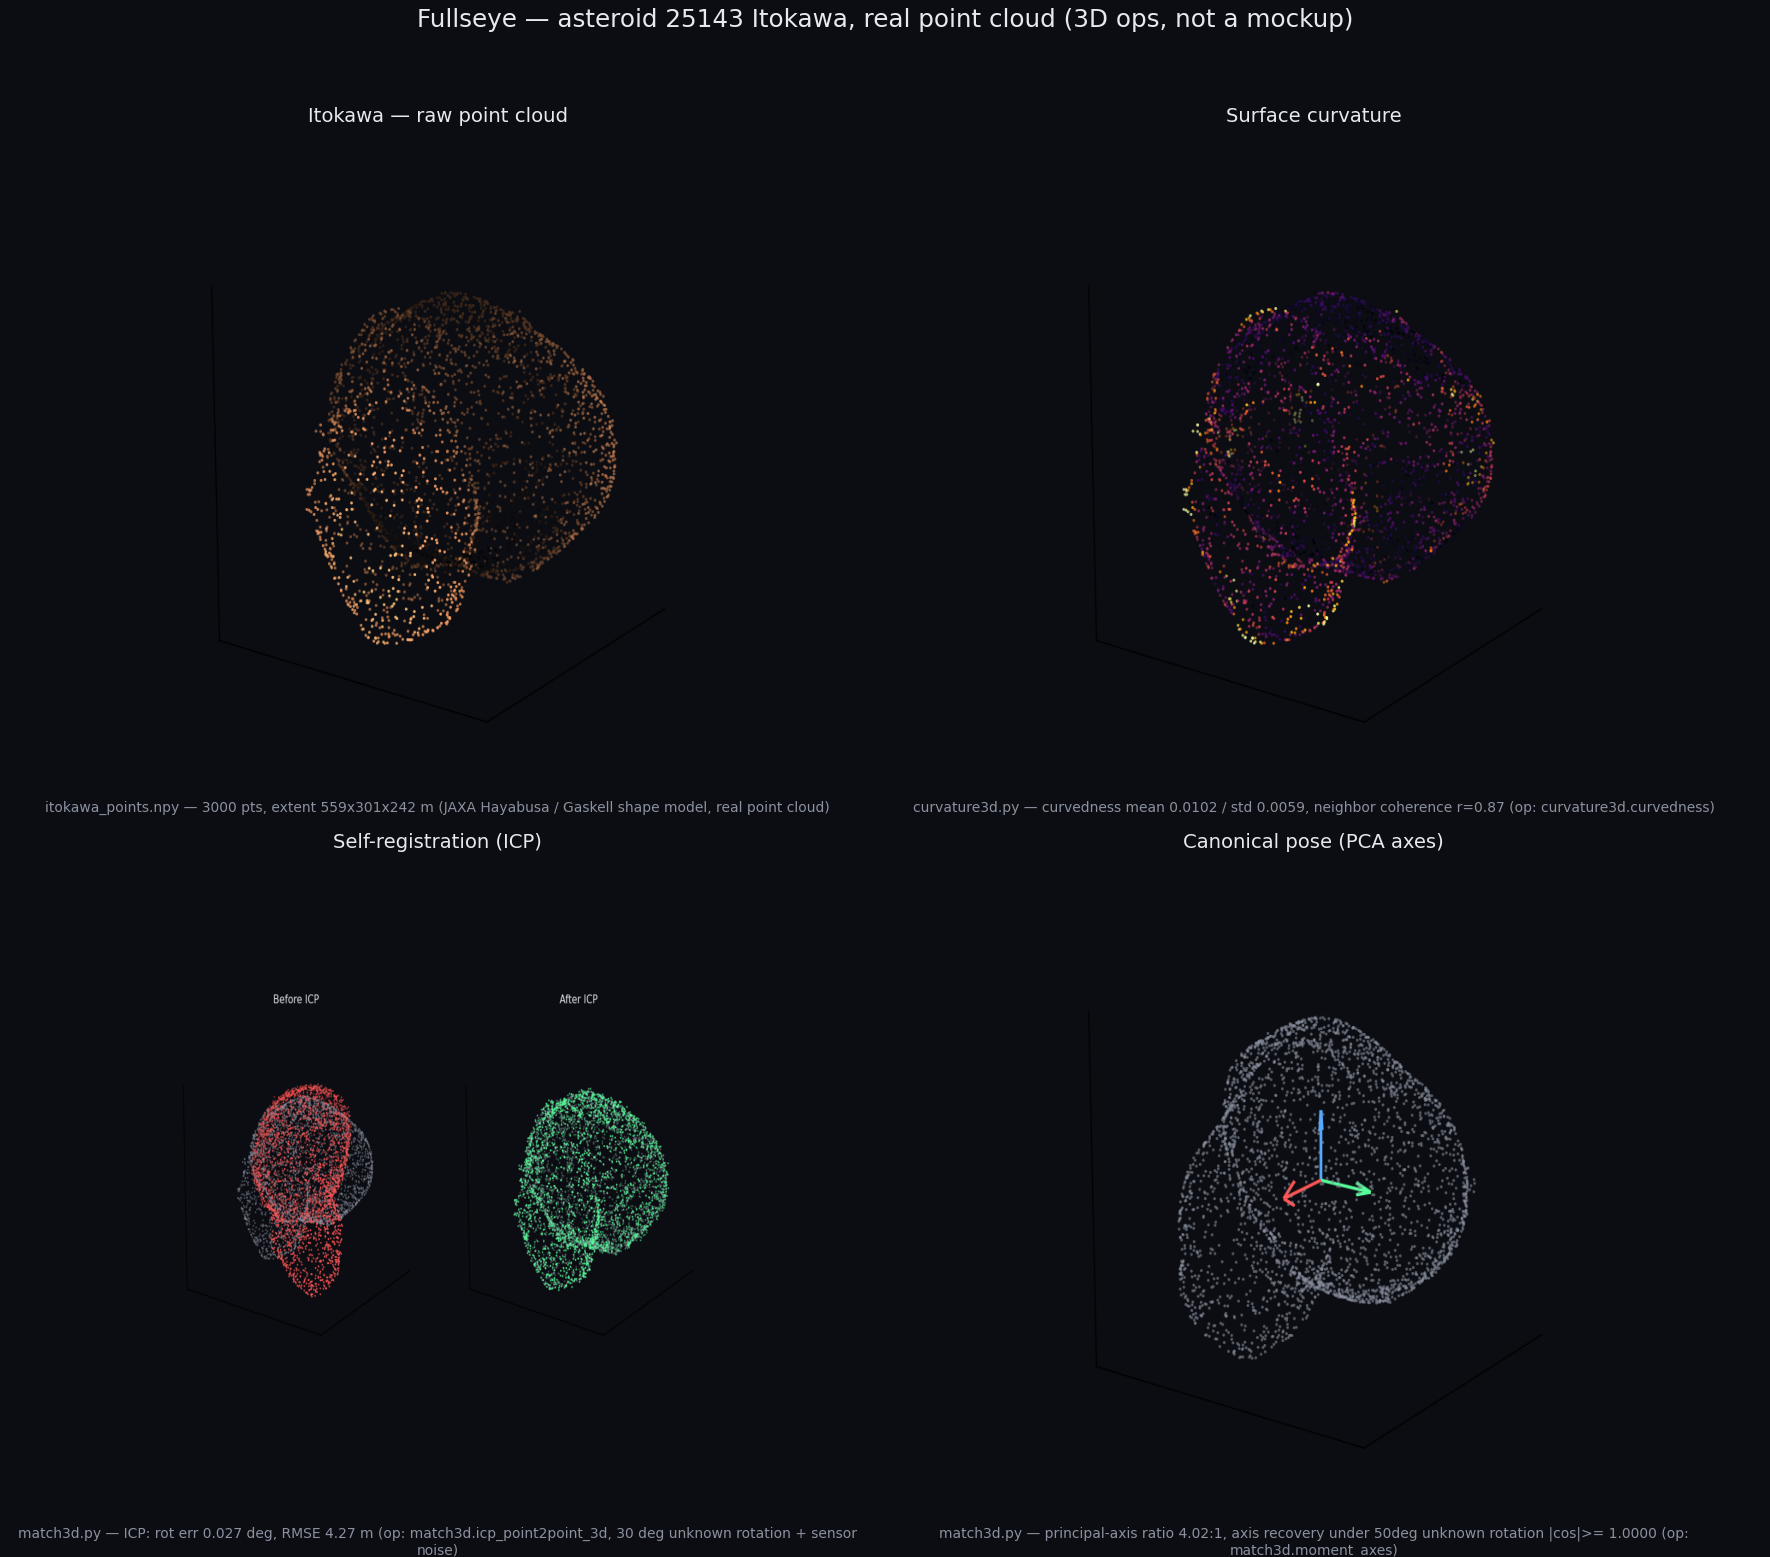
The 3-D side is where Fullseye differentiates most: 372 typed 3-D operators spanning point clouds / meshes / volumes / SDF — 3-D feature descriptors (SHOT, FPFH, spin images), TSDF fusion, fringe projection, photometric stereo, superquadric fitting, medial axis, geodesic distance, visual hull, and boundary-preserving manifold-strict QEM decimation — all pure numpy behind one typed registry. Real data, real numbers (asteroid 25143 Itokawa, JAXA Hayabusa / Gaskell shape model):
import fullseye as fs
disp  = fs.disparity_map(left, right, max_disp=16)         # dense stereo (block matching)
Z     = fs.depth_from_disparity(disp, focal=f, baseline=B) # Z = f·B/d
pts   = fs.reproject_to_points(Z, fx=f, fy=f)              # point cloud (N,3)
grid,_= fs.elevation_map(world_pts, cell=0.05)            # 2.5-D terrain heightmap
ok    = fs.traversability(grid, cell=0.05, max_step=0.1)  # foothold / obstacle mask
objs  = fs.segment_objects(frame, threshold="otsu")       # per-object records (geometry + descriptors)
rgb   = fs.colorize_depth(Z); fs.save_ply("cloud.ply", pts)   # visualise / export (no matplotlib)
Motion, over time — feed it a real clip:
frames = fs.read_frames("clip.mp4", gray=True, step=2)     # (T,H,W) float64 [0,1] (mp4/gif)
for a, b in fs.frame_pairs(frames):
    u, v = fs.optical_flow_lk(a, b)                         # dense flow; also track_points / motion_*
fs.to_float01(x) coerces uint8/uint16/bool/PIL/path inputs to float64 [0,1];
fs.read_frames / iter_frames / write_video / probe handle video I/O (see
docs/PERCEPTION_REALDATA.md for measured results on real footage).
Evolutionary pipeline design
When the task is "find an algorithm that maximizes metric M on my data", evolve one. Fitness is measured on the training split only; a held-out split is tracked but never selected on, so the reported generalization is honest rather than a fit to the evaluation set.
py -3.11 baseline.py --problem denoise --workdir out/mine     # honest floor first
py -3.11 evolve.py   --problem denoise --workdir out/mine --gens 40 --pop 24
py -3.11 robust.py   --problem denoise --workdir out/mine --seeds 5   # best-of-N, train-selected
Performance (optional GPU batch backend)
The default per-image path uses scipy/OpenCV. A batched torch fast path (accel.py,
--device cuda) accelerates the compute-heavy vectorizable operators. Honest note: on
CPU the batch path speeds up heavy operators (≈1.6–2.2×) but loses on trivial
pointwise ops (tensor-conversion overhead); the real win is on GPU, where that overhead
amortizes over large parallelism.
Fullseye Studio (HDevelop-style IDE)
fullseye-studio (or py -3.11 studio.py from a checkout) opens the visual
workbench: operator browser with generated help
(2-D and 3-D), pipeline editor with per-stage timing, breakpoints, continue /
run-from-line execution control, a variable window with watch expressions and
right-click inspection, multi-window graphics scriptable from programs
(dev_open_window / dev_set_window / dev_set_window_extents), worked-example
galleries, and a tabbed Python Editor that opens any sample as editable, runnable
code (F5, subprocess). Combined with the RAG corpus this is aimed at being an
integrated environment for Physical-AI perception work: the AI writes and runs the
pipeline, and the human inspects what it "sees" in the same windows.
Academic use
Fullseye is designed to be citable and reproducible: per-operator notes carry real
literature references (no fabricated DOIs), versions are pinned to the code by a
registry fingerprint with a CI drift test, and evaluation follows the honest
held-out discipline above. If you use it in academic work, please cite via
CITATION.cff.
Archival status, stated plainly: archived on Zenodo from v0.1.11 onwards.
Concept DOI (always resolves to the newest version):
10.5281/zenodo.22761195; the v0.2.1
version DOI is 10.5281/zenodo.22851588 (v0.2.0: 10.5281/zenodo.22772164). Each GitHub Release mints a new version
DOI (.zenodo.json describes the record and is kept in step with CITATION.cff
and pyproject.toml by a CI gate — see "Zenodo" in CONTRIBUTING.md). Versions
before 0.1.11 exist only as git tags and on PyPI, not as Zenodo records.
Documentation map
Everything below lives in the repo — start at the guide that matches what you want to do:
| You want to… | Read |
|---|---|
| Read the whole story end to end (long-form) | docs/articles/fullseye_overview_qiita_en.md · 日本語 |
| See what the operators produce (result gallery) | docs/GALLERY.md |
| Browse the paper exhibits (151 op demos, en/ja) | docs/articles/exhibits/ |
| Look up any of the 3,083 operators in the machine-readable index | docs/ops/INDEX.md (full TOC) · docs/OP_CATALOG.md (one-page catalog) |
| Find real sample data (meshes / volumes / images, with licenses) | docs/ops/SAMPLES.md |
| Use Fullseye as an AI/RAG knowledge base | docs/AI_RAG_GUIDE.md (+ fullseye-rag) |
| Drive the Studio IDE | docs/STUDIO_GUIDE.md · docs/HDEVELOP_DEV_OPS.md (dev_* window ops) |
| Add an operator | docs/ADDING_OPS.md · CONTRIBUTING.md |
| Read the Studio and its operator help in your language | Studio ▸ Tools ▸ Language — 日本語 / English / 简体中文 / 繁體中文 / 한국어 / Deutsch |
| Understand the language policy and what is not translated | docs/I18N.md |
| Update a checkout safely | tools/update_fullseye.py --check |
| See what is actually verified (and how) | docs/MATURITY.md + docs/maturity.json (generated, not written) |
| Report results from real hardware or real data (data may stay private) | docs/VALIDATION_CONTRIBUTING.en.md · issue form |
| Read why it is built this way | docs/DESIGN_NOTES.md — 606 load-bearing ★ comments collected from the source, in 6 languages (translated as we go; untranslated entries are shown as such) |
| Cite Fullseye | CITATION.cff |
Design principles
- Reimplemented from public knowledge — published algorithms and open-source libraries, unified behind one typed interface; not derived from any proprietary product.
- Honest by construction — held-out data is never used for selection; coverage and benchmark numbers are measured, not asserted; limitations are disclosed, not hidden.
- Optional heavy dependencies — a numpy+scipy core always works; richer backends and GPU are opt-in.
License
Apache-2.0.
1 maintainer

Metadata
1 maintainer
Release files for fullseye 0.6.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| fullseye-0.6.0.tar.gz | 37.9 MB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| fullseye-0.6.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 74.5 MB
Release files / fullseye-0.6.0.tar.gz
| Download URL | fullseye-0.6.0.tar.gz |
|---|---|
| Size | 37.9 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
84559b5c4cb4c18f1f7d971fe7cfec1104ef89f9b562b3d020db400bb1e230f4
|
|
BLAKE2b-256 checksum How to use checksums |
af56f4a039da3747e3f3474c341fd0db425705ea82c9c7567534e15f232de778
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Release files / fullseye-0.6.0-py3-none-any.whl
| Download URL | fullseye-0.6.0-py3-none-any.whl |
|---|---|
| Size | 36.6 MB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
859a5530eea1f1490b2a6acad54a744c6a09802f061056a2f7c6b91f05ef4415
|
|
BLAKE2b-256 checksum How to use checksums |
e24f2361b4862d57df8b05a898818ca1e3d80090e7f8d55c30f6c8b1811c62c1
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|














