
gym-xarm
A gym environment for xArm
Installation
Create a virtual environment with Python 3.10 and activate it, e.g. with miniconda:
conda create -y -n xarm python=3.10 && conda activate xarm
Install gym-xarm:
pip install gym-xarm
Quickstart
# example.py
import gymnasium as gym
import gym_xarm

env = gym.make("gym_xarm/XarmLift-v0", render_mode="human")
observation, info = env.reset()

for _ in range(1000):
    action = env.action_space.sample()
    observation, reward, terminated, truncated, info = env.step(action)
    image = env.render()

    if terminated or truncated:
        observation, info = env.reset()

env.close()
To use this example with render_mode="human", you should set the environment variable export MUJOCO_GL=glfw or simply run
MUJOCO_GL=glfw python example.py
Description for Lift task
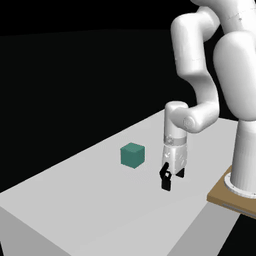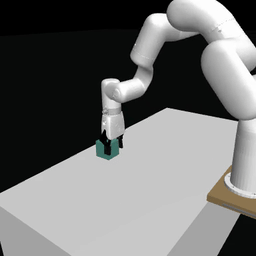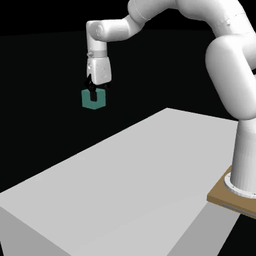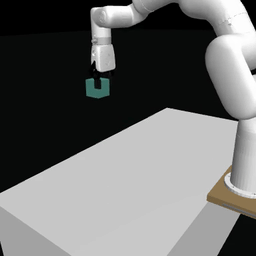
The goal of the agent is to lift the block above a height threshold. The agent is an xArm robot arm and the block is a cube.
Action Space
The action space is continuous and consists of four values [x, y, z, w]:
- [x, y, z] represent the position of the end effector
- [w] represents the gripper control
Observation Space
Observation space is dependent on the value set to obs_type:
"state": observations contain agent and object state vectors only (no rendering)"pixels": observations contains rendered image only (no state vectors)"pixels_agent_pos": contains rendered image and agent state vector
Contribute
Instead of using pip directly, we use poetry for development purposes to easily track our dependencies.
If you don't have it already, follow the instructions to install it.
Install the project with dev dependencies:
poetry install --all-extras
Follow our style
# install pre-commit hooks
pre-commit install

# apply style and linter checks on staged files
pre-commit
Acknowledgment
gym-xarm is adapted from FOWM and is based on work by Nicklas Hansen, Yanjie Ze, Rishabh Jangir, Mohit Jain, and Sambaran Ghosal as part of the following publications:
- Self-Supervised Policy Adaptation During Deployment
- Generalization in Reinforcement Learning by Soft Data Augmentation
- Stabilizing Deep Q-Learning with ConvNets and Vision Transformers under Data Augmentation
- Look Closer: Bridging Egocentric and Third-Person Views with Transformers for Robotic Manipulation
- Visual Reinforcement Learning with Self-Supervised 3D Representations
2 maintainers


Metadata
2 maintainers
Release files for gym-xarm 0.1.1
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| gym_xarm-0.1.1.tar.gz | 2.2 MB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| gym_xarm-0.1.1-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 4.5 MB
Release files / gym_xarm-0.1.1.tar.gz
| Download URL | gym_xarm-0.1.1.tar.gz |
|---|---|
| Size | 2.2 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
e455524561b02d06b92a4f7d524f448d84a7484d9a2dbc78600e3c66240e0fb7
|
|
BLAKE2b-256 checksum How to use checksums |
2a1c77aac8cbf50b8f8715f5ebeb68214452e3adf4531c9b9f6fefdff09f7267
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
poetry/1.8.2 CPython/3.12.3 Darwin/23.4.0
|
Release files / gym_xarm-0.1.1-py3-none-any.whl
| Download URL | gym_xarm-0.1.1-py3-none-any.whl |
|---|---|
| Size | 2.3 MB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
3bd7e3c1c5521ba80a56536f01a5e11321580704d72160355ce47a828a8808ad
|
|
BLAKE2b-256 checksum How to use checksums |
11961f96ac0803032596e8483ae133ce04b52b10f151c3dbcefbba029f7290a7
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
poetry/1.8.2 CPython/3.12.3 Darwin/23.4.0
|














