
linkgym


linkgym is a Gymnasium environment for 5G NR link adaptation (MCS selection) built on NVIDIA Sionna SYS, with TDL and ray-traced channels, classical baselines and a fixed evaluation protocol.
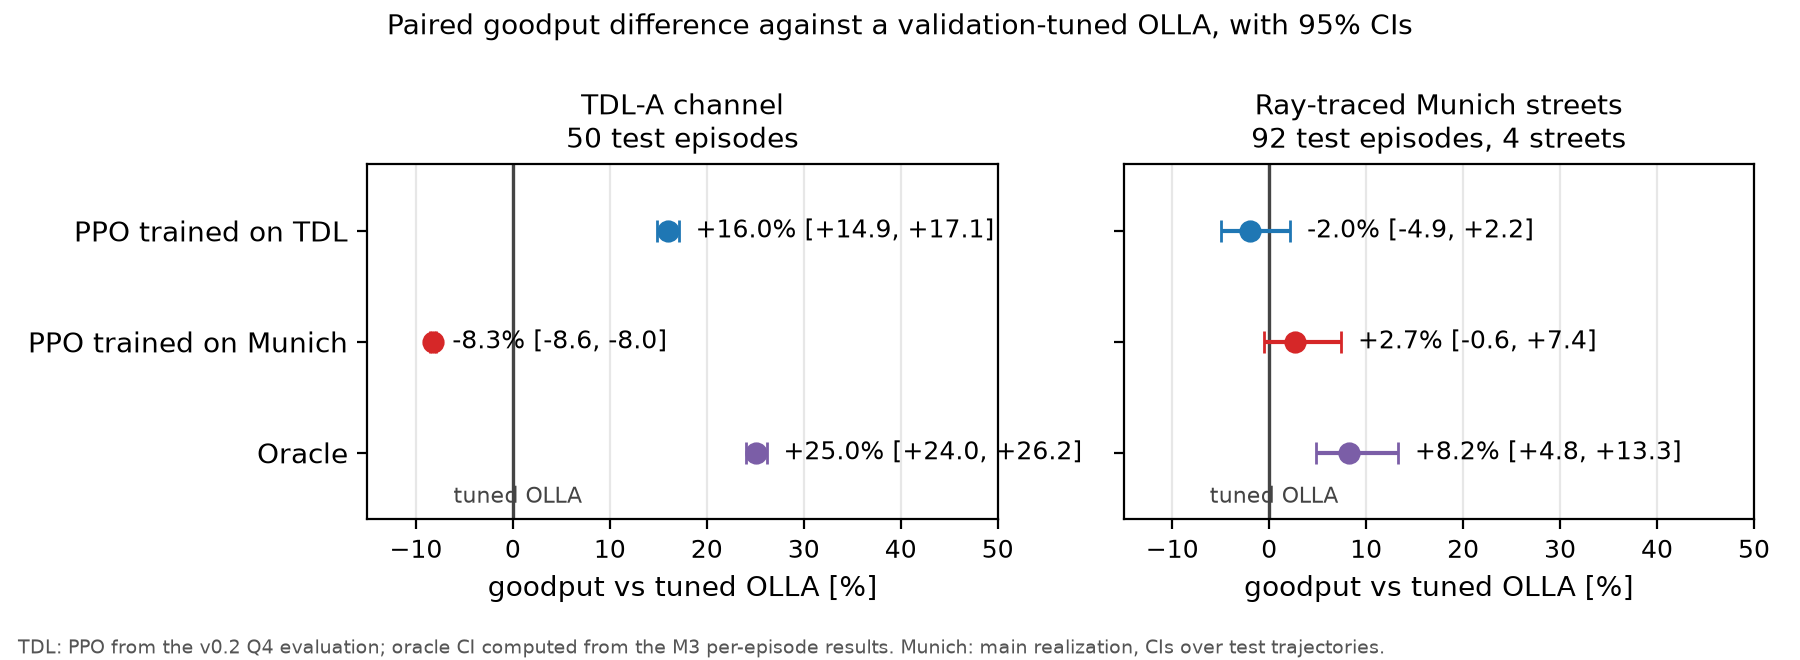
Paired goodput difference against Sionna's OLLA tuned on validation data, with 95% CIs. Left: the default TDL-A scenario, 50 held-out test episodes. Right: 92 episodes on four held-out ray-traced Munich streets (main ray-tracing realization; the CIs resample the 23 test trajectories). Each PPO is the mean of three training seeds; the CIs do not include training-seed variance. The oracle knows the channel of the slot being decided; its CI on TDL is computed from the M3 per-episode results. Details: TDL results, Munich results.
On the default TDL channel, PPO trained on linkgym delivers +16.0% goodput over a validation-tuned OLLA (95% CI [+14.9%, +17.1%], 50 held-out episodes). On ray-traced streets in Munich (Sionna RT, four held-out streets), that advantage is gone: there is no detectable difference from tuned OLLA, neither for PPO trained on TDL (-2.0%, CI [-4.9%, +2.2%]) nor for PPO trained on the Munich training streets (+2.7%, CI [-0.6%, +7.4%]). Training on the site does beat training on TDL, by +4.8% (CI [+4.0%, +5.5%]), in every route category and on two ray-tracing realizations. Each policy does best on the kind of channel it was trained on: PPO trained on Munich is 8.3% below tuned OLLA on TDL.
Why
Recent RL link-adaptation studies on Sionna (see Related work) each build their own
environment. linkgym is a reusable, pip-installable Gymnasium environment,
registered as linkgym/LinkAdaptation-v0, with built-in baselines (fixed MCS, ILLA, OLLA,
oracle) and a fixed evaluation protocol. All policies are evaluated with common random
numbers: for a given seed, every policy faces the same channel and the same ACK draws.
Besides 3GPP TDL fading, the environment runs on channel traces: a published ray-traced
dataset of Munich streets, traces you generate from your own Sionna RT scene, or any
channel you can write as an array of gains.
Installation
pip install linkgym           # environment and baselines
pip install "linkgym[train]"  # adds Stable-Baselines3 and TensorBoard for the PPO example
From source, with the training extras:
git clone https://github.com/Tempip/linkgym.git
cd linkgym
pip install -e ".[train]"
Requires Python >= 3.11 (tested on 3.11 and 3.12); sionna-no-rt 2.1.x is installed
automatically. A CPU-only PyTorch build is enough. To avoid downloading CUDA wheels, install
it first with pip install torch --index-url https://download.pytorch.org/whl/cpu. The
simulator runs faster with one torch thread; call torch.set_num_threads(1) in your own
script (the package does not change it).
To generate traces with Sionna RT, install pip install "linkgym[rt]" in a separate
environment: installing it where you train can break imports on machines without a CUDA
GPU or LLVM
(why).
Quickstart
Create the environment and evaluate Sionna's OLLA with linkgym.evaluate:
import gymnasium as gym

import linkgym
from linkgym.baselines import OLLAPolicy

env = gym.make("linkgym/LinkAdaptation-v0", speed=3.0)  # any ScenarioConfig field
obs, info = env.reset(seed=0)
obs, reward, terminated, truncated, info = env.step(env.action_space.sample())

result = linkgym.evaluate(
    OLLAPolicy(bler_target=0.1), env_kwargs={"speed": 3.0}, seeds=[1000, 1001]
)
print(result["goodput_mbps"]["mean"], result["observed_tbler"]["mean"])
Train PPO with Stable-Baselines3 and evaluate it the same way. This needs the [train] extra
(pip install "linkgym[train]"); it is a short run, the results below use 1M steps:
import gymnasium as gym
from stable_baselines3 import PPO
from stable_baselines3.common.env_util import make_vec_env

import linkgym
from linkgym.baselines import SB3Policy

vec_env = make_vec_env(lambda: gym.make("linkgym/LinkAdaptation-v0"), n_envs=4, seed=0)
model = PPO("MlpPolicy", vec_env, gamma=0.0, seed=0).learn(total_timesteps=8_192)
print(linkgym.evaluate(SB3Policy(model), seeds=[1000])["goodput_mbps"]["mean"])
A longer walk-through is in examples/quickstart.ipynb.
Results
TDL channel (v0.1)
Default scenario, held-out test seeds 1000-1009, 5 episodes each (50 episodes of 1000 slots). Means over the test seeds; PPO is the mean of 3 training seeds (std 0.04 Mbit/s across them). All policies except the oracle observe exactly the same delayed feedback (wideband SINR, HARQ ACK/NACK, MCS used).
| policy | goodput Mbit/s | observed TBLER |
|---|---|---|
| fixed MCS 14 | 23.34 | 0.277 |
| ILLA, no outer loop (target 0.1) | 19.45 | 0.524 |
OLLA, default step (target 0.1, delta_up 1 dB) |
30.35 | 0.103 |
OLLA, tuned on validation seeds (target 0.1, delta_up 0.25 dB) |
30.89 | 0.110 |
| PPO, gamma = 0 | 35.82 | 0.067 |
| oracle (ILLA on the channel of the current slot) | 38.62 | 0.026 |
PPO vs tuned OLLA, paired over the 50 test episodes: +4.93 Mbit/s (+16.0%) goodput per episode, 95% bootstrap CI [+4.65, +5.21] Mbit/s ([+14.9%, +17.1%]). The protocol, validation-based selection, the other comparisons and the figures are in docs/results/m3/README.md. These results hold for this TDL scenario only.
Ray-traced Munich streets (v0.2)
The Munich dataset: 15 streets around one rooftop base station, split by
street into train (8), val (3) and test (4). Test: 92 episodes of 1000 slots on 23
trajectories. OLLA was tuned on the val streets (target 0.05, delta_up 0.25 dB), PPO
trained on the train streets (3 training seeds, means reported), and the protocol was
committed before training. Paired differences with 95% cluster bootstrap CIs over test
trajectories; "holds" means the classification (better, worse, no detectable difference)
is the same on a second ray-tracing realization of the test streets.
| comparison | goodput difference | verdict |
|---|---|---|
| PPO trained on TDL - tuned OLLA | -0.71 Mbit/s (-2.0%), CI [-4.9%, +2.2%] | inconclusive |
| PPO trained on Munich - tuned OLLA | +0.96 Mbit/s (+2.7%), CI [-0.6%, +7.4%] | inconclusive |
| PPO trained on Munich - PPO trained on TDL | +1.67 Mbit/s (+4.8%), CI [+4.0%, +5.5%] | holds, in every route category |
| policy | goodput Mbit/s | observed TBLER |
|---|---|---|
| fixed MCS 14 | 21.79 | 0.325 |
| ILLA, no outer loop (target 0.1) | 30.64 | 0.320 |
OLLA, default step (target 0.1, delta_up 1 dB) |
35.52 | 0.172 |
OLLA, tuned on the val streets (target 0.05, delta_up 0.25 dB) |
35.82 | 0.129 |
| PPO trained on TDL | 35.11 | 0.125 |
| PPO trained on Munich | 36.78 | 0.113 |
| oracle | 38.77 | 0.110 |
Against tuned OLLA, by route category, PPO trained on TDL is worse on the line-of-sight street and PPO trained on Munich better on the NLoS streets; the other differences are inconclusive. Tuned OLLA is within 3 Mbit/s of the oracle here, which leaves less room than on TDL. With the default SNR normalization, 9% of the test slots are outages in which even the lowest MCS has a TBLER above 5%; a post hoc analysis shows that they account for tuned OLLA's observed TBLER of 0.129 against its 0.05 target. Protocol, per-category and per-route results, both realizations and the analysis: docs/results/v02/README.md.
Munich dataset
Ray-traced channel traces of 15 streets around one rooftop base station in Sionna RT's
munich scene: 76 trajectories of 4000 slots (2 s at 15 m/s), 52 PRBs at 3.5 GHz, split
by street into train, val and test, plus a second ray-tracing realization of the test
streets. Published on Zenodo under the Open Database License (ODbL) 1.0: version v1 has
the DOI 10.5281/zenodo.23135098, which is the one
to cite and the one fetch downloads; all versions, resolving to the latest, are under
10.5281/zenodo.23135097. The scene derives from
OpenStreetMap data, (c) OpenStreetMap contributors.
linkgym.datasets.fetch downloads a file once, verifies its SHA-256 and returns its path:
import gymnasium as gym

from linkgym.datasets import fetch

path = fetch("munich-v1")  # 67 MB, cached in ~/.cache/linkgym (or $LINKGYM_DATA_DIR)
env = gym.make(
    "linkgym/LinkAdaptation-v0", channel="trace", trace_path=str(path), trace_splits=["train"]
)
obs, info = env.reset(seed=0)
print(env.unwrapped.channel_info)  # trajectory, start slot, split, route category, SNR
How it was generated, its statistics and its known limitations (the ray tracing does not converge within the ray budget; refraction is off) are in docs/channels.md.
Bring your own channel or Sionna RT scene
Any channel you can write as linear power gains per trajectory, slot and PRB works: write
it with write_trace, label each trajectory with a split, and pass the file to the
environment.
import gymnasium as gym
import numpy as np

from linkgym.channels import write_trace

# |h|^2 for 3 trajectories of 2000 slots and 52 PRBs: here Rayleigh block fading
gain = np.repeat(np.random.default_rng(0).exponential(size=(3, 200, 52)), 10, axis=1)
write_trace(
    "my_channel.h5",
    gain,
    split=["train", "val", "test"],
    carrier_frequency_hz=3.5e9,  # must match the scenario
    subcarrier_spacing_hz=30e3,
    slot_duration_s=0.5e-3,
)
env = gym.make("linkgym/LinkAdaptation-v0", channel="trace", trace_path="my_channel.h5")
For ray-traced traces, the linkgym-traces command (from the rt extra) computes them
with Sionna RT from a JSON configuration: a scene (a built-in one or your own Mitsuba XML),
a transmitter and routes split by street. The
tutorial goes from a
scene to a trained and evaluated agent, step by step;
docs/channels.md documents
the trace format, the SNR modes and the generator.
Building blocks for your own environment
Two modules can be used outside LinkAdaptation-v0, for example in a multi-user or
beam-management environment of your own:
linkgym.phy(stable): the link-level functions the environment's simulator uses.effective_sinrgives the EESM effective SINR.transmitgives the ACK, delivered bits and TBLER of a transport block, from uniforms you provide, so different policies face the same draws. See docs/phy.md.linkgym.beams(experimental): DFT codebooks for linear and planar arrays, steering vectors, beam gain, RSRP and best beam, consistent with Sionna RT's arrays. See docs/beams.md.
Which parts of linkgym are stable, and what a patch or minor release may change, is set out in docs/api_stability.md.
Environment at a glance
linkgym/LinkAdaptation-v0 |
|
|---|---|
| Action | Discrete(26): MCS 3-28 of the 5G NR PDSCH MCS table 1 |
| Observation | Box(-1, 1, (12,)): the last 4 reports (wideband SINR, HARQ ACK/NACK, MCS used), delayed by the feedback delay |
| Reward | delivered bits of the slot divided by the TB size of MCS 28, in [0, 1] |
| Episode | 1000 slots, then truncated=True; never terminated |
| Channel | channel="tdl" (default): 3GPP TDL fading generated with Sionna; channel="trace": an HDF5 trace, a trajectory and window drawn per episode from trace_splits |
| Default scenario | single cell, single SISO link, 3GPP TDL-A, 100 ns delay spread, 3.5 GHz, 15 m/s, 52 PRB at 30 kHz, mean SNR drawn per episode from U(5, 20) dB, feedback delay 1 slot |
Every scenario field can be passed to gym.make. Timing, observation layout and info keys
are in docs/environment.md,
the channel options in
docs/channels.md.
Reproducing the results
TDL (v0.1), in Bash:
pip install -e ".[train]"
for gamma in 0 0.9; do
  for seed in 0 1 2; do
    python examples/train_ppo.py --gamma $gamma --seed $seed
  done
done
python examples/evaluate_all.py
PowerShell:
pip install -e ".[train]"
foreach ($gamma in "0", "0.9") {
  foreach ($seed in 0, 1, 2) {
    python examples/train_ppo.py --gamma $gamma --seed $seed
  }
}
python examples/evaluate_all.py
Munich (v0.2), after the TDL runs above (the evaluation also uses the gamma = 0 TDL
models). The first line downloads both dataset files to data/. In Bash:
LINKGYM_DATA_DIR=data python -m linkgym.datasets munich-v1 munich-v1-test-alt
for seed in 0 1 2; do
  python examples/train_ppo.py --gamma 0 --seed $seed --channel trace --trace-path data/munich-v1.h5 --eval-freq 100000
done
for phase in validation test q4 report; do python examples/evaluate_v02.py $phase; done
PowerShell:
$env:LINKGYM_DATA_DIR = "data"; python -m linkgym.datasets munich-v1 munich-v1-test-alt
foreach ($seed in 0, 1, 2) {
  python examples/train_ppo.py --gamma 0 --seed $seed --channel trace --trace-path data/munich-v1.h5 --eval-freq 100000
}
foreach ($phase in "validation", "test", "q4", "report") { python examples/evaluate_v02.py $phase }
Measured on an AMD Ryzen 7 7700X (8 cores, 16 threads), Windows 11, CPU only (torch 2.14.0+cpu, sionna-no-rt 2.1.0):
- TDL: each training run, 1,015,808 steps with 8
SubprocVecEnvworkers, took 654-657 s; the six runs took 67 minutes one after another.evaluate_all.py, on 8 worker processes: 42 s for the OLLA tuning grid on the validation seeds, then 535 s for all test evaluations. It writes the tables and figures todocs/results/m3/. - Munich: each training run took 1169-1201 s, including 12 validation passes. The
evaluate_v02.pyphases took 347 s (validation), 583 s (test) and 103 s (q4) on 8 worker processes;reportwrites the tables and figures todocs/results/v02/. The test phase refuses to run again once its results exist.
Numbers can differ slightly on other hardware, operating systems or library versions; the committed CSVs are the reference.
Limitations
- A simplified link-level simulator: a single SISO link, a SINR-to-BLER abstraction with coarse BLER tables, no HARQ retransmissions, no interference, no channel estimation error.
- Few channels: one TDL scenario, and one ray-traced site with one base station, where the test split has four streets (one line-of-sight, one transition, two NLoS). The Munich results describe these streets, not sites in general.
- The ray tracing does not converge within the ray budget: the dataset is one deterministic realization, with refraction off. All Munich verdicts were the same on a second realization, which is one other ray budget, not an independent channel.
- The default SNR normalization divides each trajectory by its mean linear gain, which puts the weak stretches of trajectories with a large dynamic range into outage (9% of the Munich test slots); these slots raise every policy's observed TBLER.
- PPO uses Stable-Baselines3 default hyperparameters, 1M steps and 3 training seeds; the confidence intervals do not include training-seed variance.
- OLLA and PPO optimise different objectives: OLLA holds a TBLER target, PPO maximises goodput; the comparison is in goodput, with TBLER reported alongside.
- The oracle knows the current slot's channel and is not achievable in practice.
- A policy learned in this simulator adapts to its abstraction; the results may not transfer to real systems.
Full lists: TDL results, Munich results, Munich traces, simulator, environment.
Roadmap
Multi-antenna channels and beam management, one small release at a time, on top of the
building blocks released in 0.3 (linkgym.phy, linkgym.beams); the published results
stay unchanged.
- 0.4: trace format 2, which stores the ray-traced paths at the anchors, so that the
per-antenna channel can be rebuilt for any array and codebook. It comes with the
generator option to write it, the reconstruction, an
ArrayChannelSourceinterface, and a Munich 3.5 GHz paths dataset on Zenodo. The element pattern and polarization are fixed at generation and recorded in the attributes. - 0.5: a cache of beam gains for a chosen array and codebook, and sampling and evaluation of several simultaneous users from a trace.
- 0.6 (optional): an FR2 (28 GHz) dataset and/or a statistical multi-antenna channel source based on 3GPP CDL.
Other planned work:
- A median-based normalization option for trace channels: the mean linear gain used now lets a short strong stretch push the rest of a trajectory into outage (channels).
- Include the agent's own pending actions in the observation when the feedback delay is larger than one slot.
- A variant with a continuous SINR-offset action.
- A reward variant with a TBLER constraint.
- Vectorised, batched environments for faster training.
Later:
- Ray-traced datasets of more sites and base stations, to test transfer across sites.
- PDSCH MCS table 2 (256-QAM, BLER data up to 25 dB).
Contributing
Setup, checks and commit conventions are in CONTRIBUTING.md.
Related work
- sionna-rl: a reproducible study comparing PPO against Sionna's OLLA for single-link MCS selection.
- M. Tsampazi, N. N. Santhi, N. Perrotta, F. Dressler, T. Melodia, "ARIADNE: AI-RAN Informed Link Adaptation in Digital Twin Network Environments", European Wireless 2026. arXiv:2605.29772. RL (PPO) link adaptation integrated with Sionna SYS over ray-traced channels, compared against OLLA and SALAD.
linkgym differs from these in that it is a reusable, pip-installable, registered Gymnasium environment rather than a single study.
Citation
If you use linkgym, please cite it:
@software{rodrigues2026linkgym,
  author  = {Rodrigues Souza, Pedro José},
  title   = {linkgym: A Gymnasium environment for 5G NR link adaptation},
  year    = {2026},
  version = {0.3.0},
  url     = {https://github.com/Tempip/linkgym}
}
and, if you use the Munich traces, the dataset version you used:
@dataset{rodrigues2026munich,
  author    = {Rodrigues Souza, Pedro José},
  title     = {linkgym Munich ray-traced channel traces, v1},
  year      = {2026},
  version   = {v1},
  publisher = {Zenodo},
  doi       = {10.5281/zenodo.23135098}
}
GitHub's "Cite this repository" button uses CITATION.cff.
License
The code is MIT licensed. See LICENSE.
The Munich dataset is licensed under the Open Database License (ODbL) 1.0; it derives from
OpenStreetMap data, (c) OpenStreetMap contributors. The same applies to the small sample of
it in tests/data/munich_sample.h5, and the route figure docs/assets/munich_routes.png
shows OpenStreetMap-derived buildings.
This project is not affiliated with or endorsed by NVIDIA. Sionna is a trademark of NVIDIA Corporation.
1 maintainer

Metadata
1 maintainer
Release files for linkgym 0.3.0
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Source distribution (sdist)
| File | Size | Uploaded | |
|---|---|---|---|
| linkgym-0.3.0.tar.gz | 2.2 MB | Details |
Built distribution (wheel)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| linkgym-0.3.0-py3-none-any.whl | Python 3 | none | any | Details |
Total release size: 2.2 MB
Release files / linkgym-0.3.0.tar.gz
| Download URL | linkgym-0.3.0.tar.gz |
|---|---|
| Size | 2.2 MB |
| Tags | Source |
|
SHA-256 checksum How to use checksums |
10ef7a9a03a892dc48c0f05c6af724b57e7ce54d4a0d2340bf6a38837463a928
|
|
BLAKE2b-256 checksum How to use checksums |
1a87fa1ef6f08adf92e56285a089640e1b35d8a2ad536a3c1d4b3a8847cae4c5
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.


PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 4, 2026.
Transparency logRelease files / linkgym-0.3.0-py3-none-any.whl
| Download URL | linkgym-0.3.0-py3-none-any.whl |
|---|---|
| Size | 62.1 kB |
| Tags | Python 3 |
|
SHA-256 checksum How to use checksums |
35deb7b6aaf820d88a6e9d1c918fa3381d275d29c69185847c800128fa923ff0
|
|
BLAKE2b-256 checksum How to use checksums |
8d2a65995968ce4c50409852692fdc9592b512ec27843b81d3076fb69bedf2e0
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
Yes |
| Uploaded via |
twine/7.0.0 CPython/3.13.14
|
Provenance
Provenance describes where a file came from. On PyPI, provenance is shared via attestations, which provide a verifiable record of the build or publishing details. View details, limitations and caveats.
PyPI Publish Attestation
PyPI verified that this artifact, at this checksum, originated from the publisher listed below.
Signed by GitHub Actions, verified by PyPI on Oct 4, 2026.
Transparency log













