
videosdk-teleop
Drive a robot arm over the internet, and know exactly what the operator was looking at when they moved it.
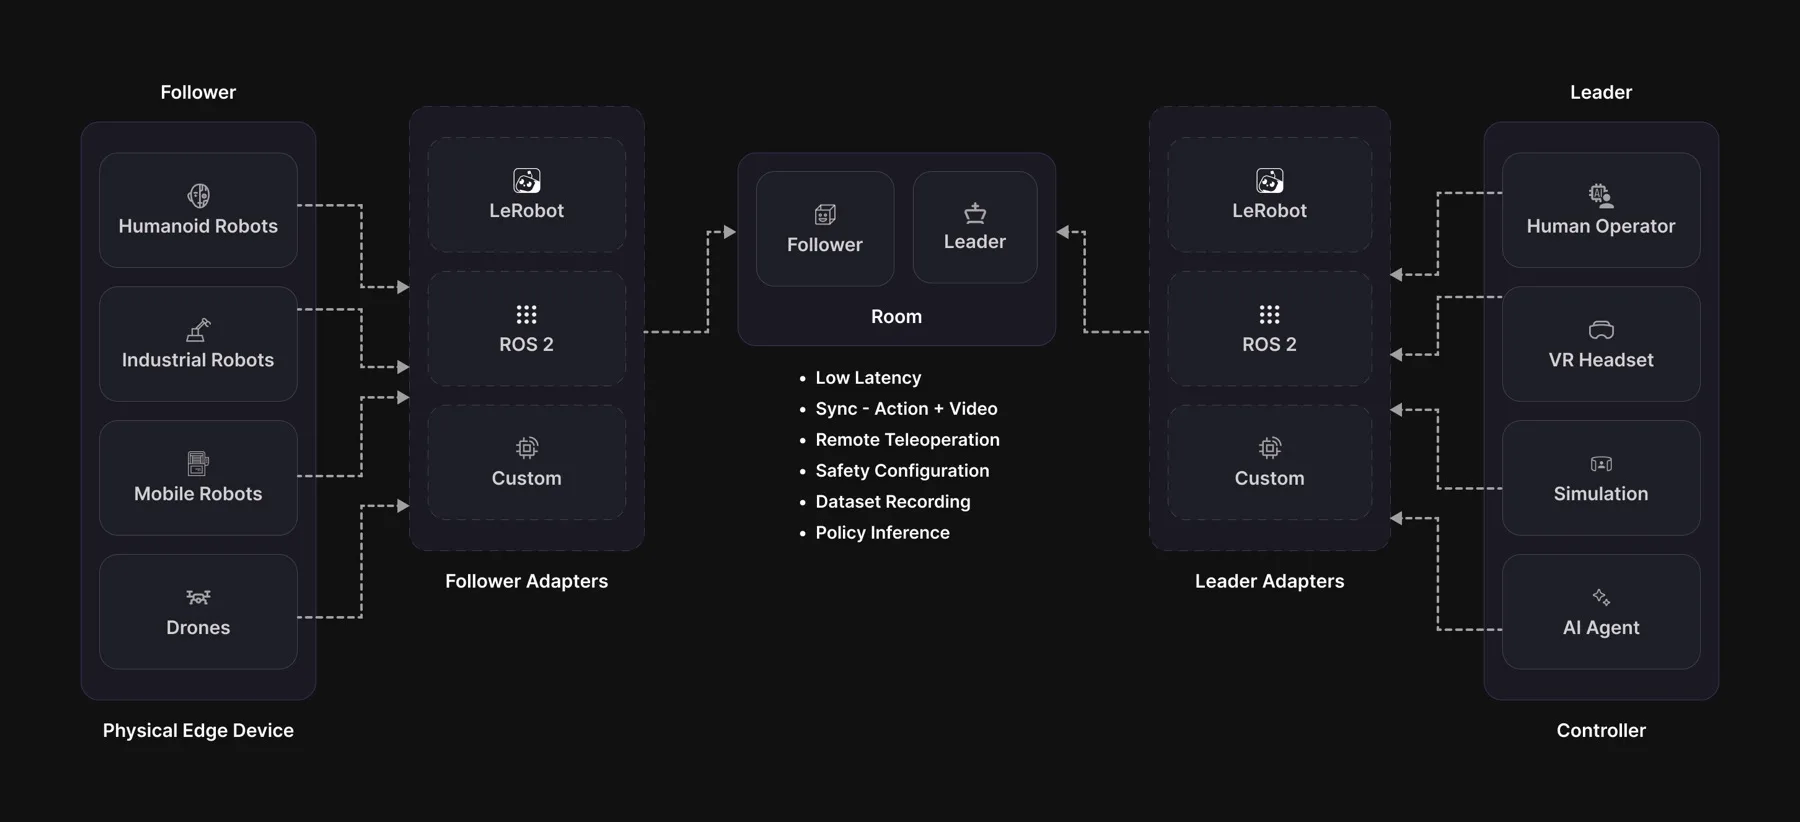
A WebRTC transport for robot teleoperation, with frame-accurate observation/action correlation, a safety envelope that cannot be bypassed, and a recorder that turns every session into training data.
Install
pip install videosdk-teleop               # transport + cameras, ready to run
pip install "videosdk-teleop[lerobot]"    # + the lerobot adapters
pip install "videosdk-teleop[ros2]"       # + the ROS 2 nodes
Your robot, in three methods
Everything else is inherited: lease negotiation, clamping, the watchdog, the e-stop latch, correlation, recording.
from videosdk_teleop import Follower, SafetyConfig, single_group_descriptor

class MyArm(Follower):
    def descriptor(self):            return single_group_descriptor(...)
    def read_joints(self):           return {"shoulder": 12.4, "elbow": -3.1}
    def write_joints(self, joints):  ...        # RAISE on failure

MyArm("abcd-efgh-ijkl", safety=SafetyConfig(slew=0.75)).run(hz=200)
Already on lerobot? Wrap the device instead of subclassing:
from videosdk_teleop.adapters.lerobot import (SO101FollowerAdapter,
                                              SO101LeaderAdapter)

follower = SO101FollowerAdapter("abcd-efgh-ijkl", robot=arm, token=TOKEN)
Run it locally, no robot needed
Runnable examples live in videosdk-teleops-examples:
git clone https://github.com/videosdk-live/videosdk-teleops-examples
cd videosdk-teleops-examples

python quickstart/remote_teleop.py --ticks 100   # full chain, in-process
python quickstart/my_arm.py                      # port your own arm
python quickstart/protocol_demo.py               # the correlation model, live
remote_teleop.py runs a real follower against a real leader: real gates,
real clamps, real correlation. Only the network is swapped for a loopback.
Safety
SafetyConfig(
    slew=0.75,                          # max change per joint per TICK:
                                        # at the default 200 Hz that is
                                        # 150 units/s, a full sweep in ~1.3 s
    watchdog_timeout_s=0.5,             # silence for this long -> failsafe
    max_staleness_ms=100.0,             # older commands are dropped
    require_deadman=True,
    on_starvation=FailsafeAction.HOLD,
    resume_requires_reclaim=False)
follower.estop()          # unauthenticated by design: anyone can stop an arm
follower.clear_estop()    # latched: only a human on the follower host resumes
Every command is checked before it reaches the motors: who sent it, whether it arrived too late, and how far it moves the arm. If the operator stops sending, the arm holds where it is.
Recording
follower.start_recording("./sessions")
follower.start_episode("pick up the cube")
...                                          # your loop runs
follower.end_episode(success=True)
follower.stop_recording()
On the follower this captures pixels before an encoder or a network touched them. Episodes open and close on the deadman by default.
VideoSDK can also record the session in the cloud:
follower = MyArm("abcd-efgh-ijkl", cloud_recording=True)

follower.cloud_recording_state    # idle / requested / starting / ready / failed
If the cloud recorder never comes up, recording carries on locally and the state says so.
Documentation
Full documentation at docs.videosdk.live.
Apache-2.0 · docs.videosdk.live · examples
1 maintainer

Release files for videosdk-teleop 0.1.7
For a detailed explanation of source distributions (sdists) and built distributions (wheels), please see the package formats documentation.
Built distributions (wheels)
| File | Interpreter | ABI | Platform | Reset |
|---|---|---|---|---|
| videosdk_teleop-0.1.7-py3-none-manylinux_2_35_x86_64.whl | Python 3 | none | Linux glibc 2.35+ x86-64 | Details |
| videosdk_teleop-0.1.7-py3-none-manylinux_2_35_aarch64.whl | Python 3 | none | Linux glibc 2.35+ ARM64 | Details |
| videosdk_teleop-0.1.7-py3-none-macosx_11_0_arm64.whl | Python 3 | none | macOS 11.0+ ARM64 | Details |
Total release size: 17.9 MB
Release files / videosdk_teleop-0.1.7-py3-none-manylinux_2_35_x86_64.whl
| Download URL | videosdk_teleop-0.1.7-py3-none-manylinux_2_35_x86_64.whl |
|---|---|
| Size | 6.3 MB |
| Tags | Linux glibc 2.35+ x86-64 Python 3 |
|
SHA-256 checksum How to use checksums |
51004c58f9589e2000f8239369b280ae609fd2fd250dc6c8d721671dc49687cc
|
|
BLAKE2b-256 checksum How to use checksums |
0b980ceb0e62ee3c0f6ae73e173a5d4cf6a09fb2d6994981830888bf6845b8c6
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.12.12
|
Release files / videosdk_teleop-0.1.7-py3-none-manylinux_2_35_aarch64.whl
| Download URL | videosdk_teleop-0.1.7-py3-none-manylinux_2_35_aarch64.whl |
|---|---|
| Size | 6.1 MB |
| Tags | Linux glibc 2.35+ ARM64 Python 3 |
|
SHA-256 checksum How to use checksums |
a81be06db23d07c2cf35d47ab14dc451affb8b1ffe9971c470a64237a4a098eb
|
|
BLAKE2b-256 checksum How to use checksums |
6d2934a4cb1815fa8fe51e05a8ad401e89fa48629f82b7026d6a3656ff6fdbb1
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.12.12
|
Release files / videosdk_teleop-0.1.7-py3-none-macosx_11_0_arm64.whl
| Download URL | videosdk_teleop-0.1.7-py3-none-macosx_11_0_arm64.whl |
|---|---|
| Size | 5.6 MB |
| Tags | Python 3 macOS 11.0+ ARM64 |
|
SHA-256 checksum How to use checksums |
b704eb3914f2cec1270c441b924bafdeb015c7312812ae52f09a0f8ccddcce98
|
|
BLAKE2b-256 checksum How to use checksums |
375f8953461d9515eb192c5361fb0f80f267aeaa53562b79f7625aa67a508190
|
| Upload date | |
|
Uploaded using Trusted Publishing? What is trusted publishing? |
No |
| Uploaded via |
twine/7.0.0 CPython/3.12.12
|














